Related Experiment Video
Updated: Feb 7, 2026
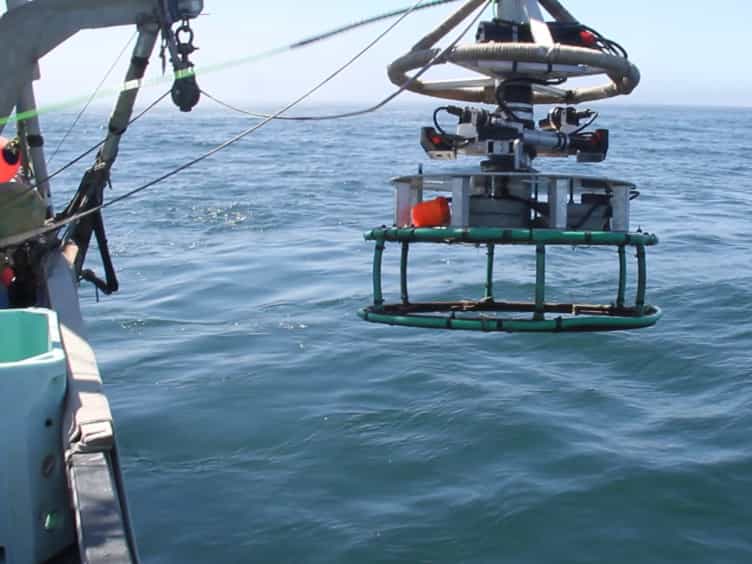

Development of New Methods for Quantifying Fish Density Using Underwater Stereo-video Tools
Published on: November 20, 2017
Fast Visual Odometry for a Low-Cost Underwater Embedded Stereo System †
Mohamad Motasem Nawaf1, Djamal Merad2, Jean-Philip Royer3
1Aix-Marseille Université, CNRS, ENSAM , Université De Toulon, LIS UMR 7020, Domaine Universitaire de Saint-Jérôme, Bâtiment Polytech, Avenue Escadrille Normandie-Niemen, 13397 Marseille, France. mohamad-motasem.NAWAF@univ-amu.fr.

Abstract:
This paper provides details of hardware and software conception and realization of a stereo embedded system for underwater imaging. The system provides several functions that facilitate underwater surveys and run smoothly in real-time. A first post-image acquisition module provides direct visual feedback on the quality of the taken images which helps appropriate actions to be taken regarding movement speed and lighting conditions. Our main contribution is a light visual odometry method adapted to the underwater context. The proposed method uses the captured stereo image stream to provide real-time navigation and a site coverage map which is necessary to conduct a complete underwater survey. The visual odometry uses a stochastic pose representation and semi-global optimization approach to handle large sites and provides long-term autonomy, whereas a novel stereo matching approach adapted to underwater imaging and system attached lighting allows fast processing and suitability to low computational resource systems. The system is tested in a real context and shows its robustness and promising future potential.
Related Concept Videos
 01:10
Fast Fourier Transform
The computational efficiency of the FFT becomes...
 01:24
Fast Decoupled and DC Powerflow
 02:05
Gene Evolution - Fast or Slow?
In contrast, regions which code...
02:05Gene Evolution - Fast or Slow?
 01:24
Metabolic States of the Body: Fasting and Starvation
 01:26
Visual System
Once through the pupil, the light passes through the lens, a...