Related Experiment Video
Updated: Feb 7, 2026

Author Spotlight: Enhancement of Salient Object Detection for Smart Grid Applications
Published on: December 15, 2023
Packing Convolutional Neural Networks in the Frequency Domain

Abstract:
Deep convolutional neural networks (CNNs) are successfully used in a number of applications. However, their storage and computational requirements have largely prevented their widespread use on mobile devices. Here we present a series of approaches for compressing and speeding up CNNs in the frequency domain, which focuses not only on smaller weights but on all the weights and their underlying connections. By treating convolution filters as images, we decompose their representations in the frequency domain as common parts (i.e., cluster centers) shared by other similar filters and their individual private parts (i.e., individual residuals). A large number of low-energy frequency coefficients in both parts can be discarded to produce high compression without significantly compression romising accuracy. Furthermore, we explore a data-driven method for removing redundancies in both spatial and frequency domains, which allows us to discard more useless weights by keeping similar accuracies. After obtaining the optimal sparse CNN in the frequency domain, we relax the computational burden of convolution operations in CNNs by linearly combining the convolution responses of discrete cosine transform (DCT) bases. The compression and speed-up ratios of the proposed algorithm are thoroughly analyzed and evaluated on benchmark image datasets to demonstrate its superiority over state-of-the-art methods.
Related Concept Videos
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:24
Frequency-Domain Interpretation of PD Control
The proportional control gain, combined with the...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:17
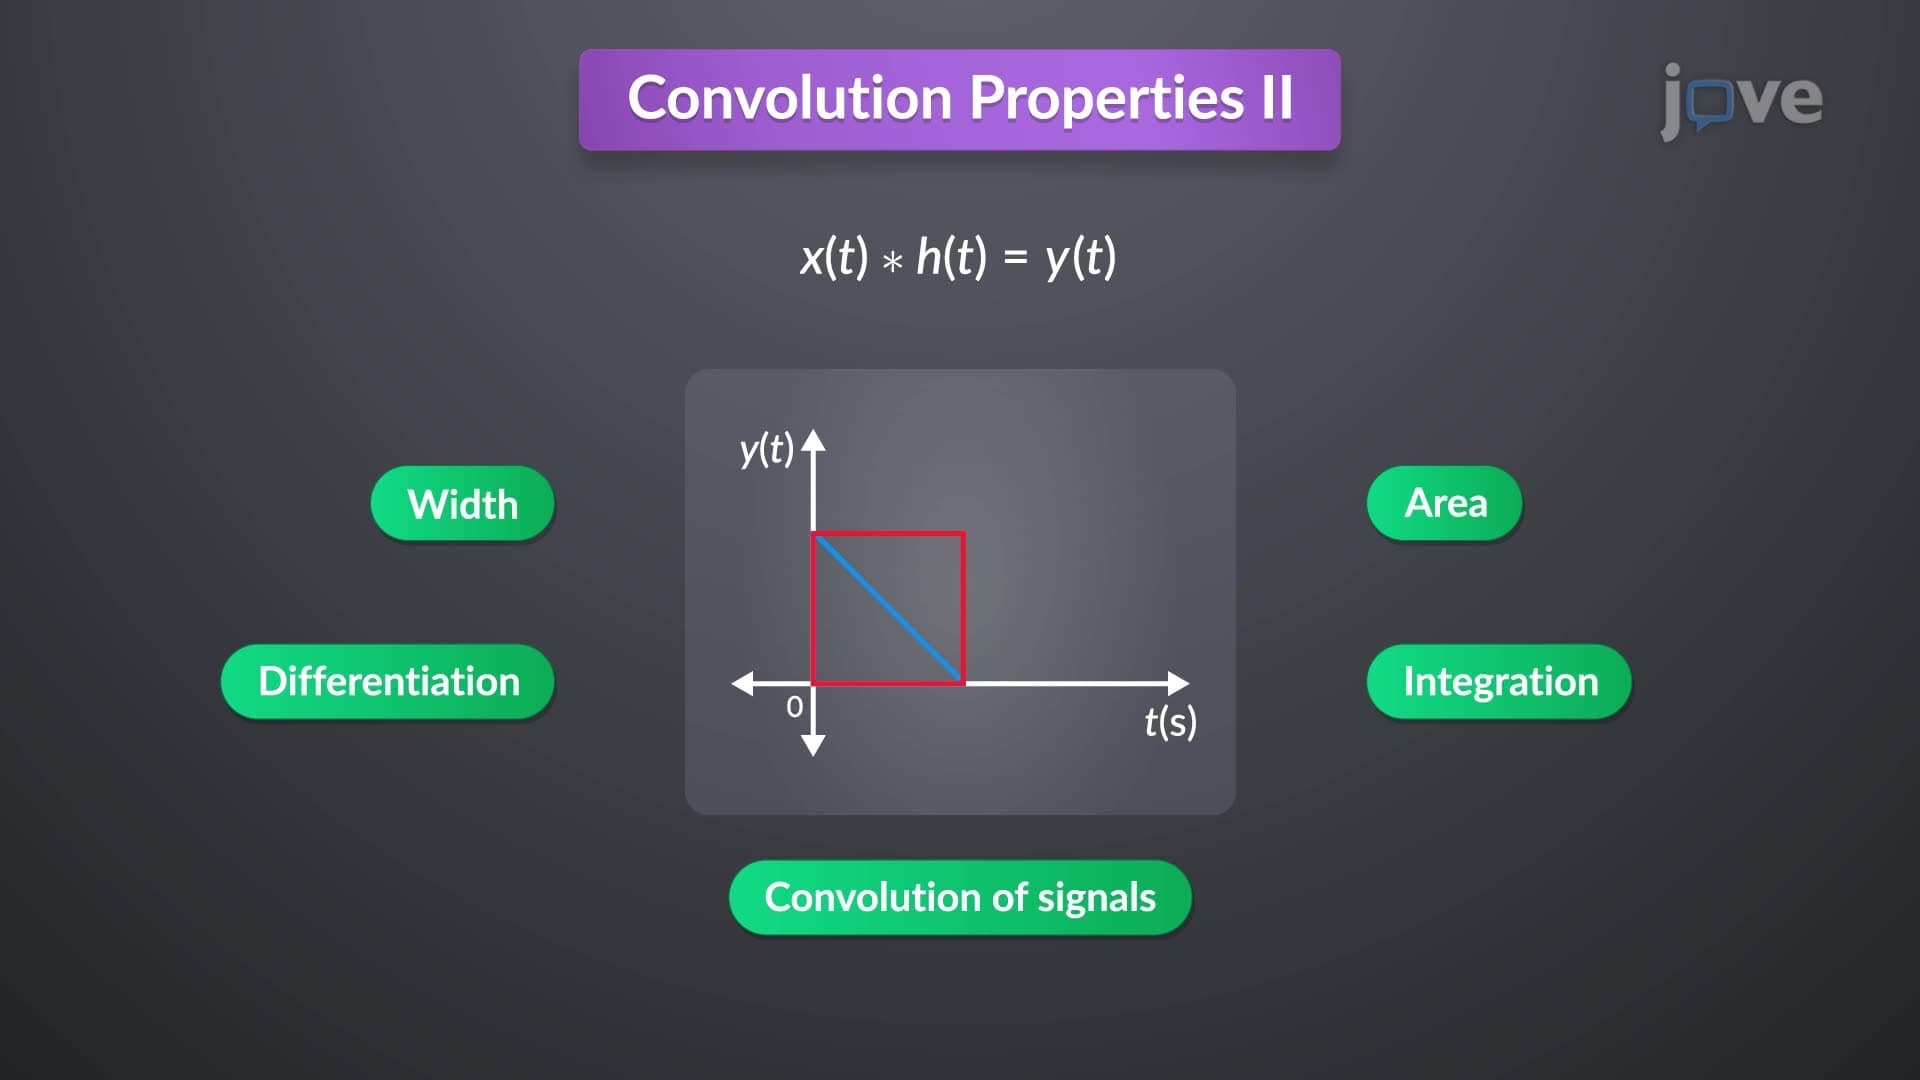
Convolution Properties II
The width property indicates that if the durations of input signals are T1 and T2, then the width of the output response equals the sum of both durations, irrespective of the shapes of the two functions. For instance, convolving two rectangular pulses with durations of 2 seconds and 1 second results in a function with a width of 3 seconds.
The area property asserts that the area under the...
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...