Related Experiment Video
Updated: Feb 7, 2026
Testing Tactile Masking between the Forearms
Published on: February 10, 2016
The mechanism of forearm rotation in Varanus exanthematicus
1Department of Anatomy and Embryology, University of Leiden, 2333 AL Leiden, The Netherlands.

Abstract:
In the sprawling gait of Varanus exanthematicus, the bicondylar distal humerus requires both the radius and ulna to rotate in the same direction. The joints between the radius and radiale and between the ulna and ulnare and pisiform accomodate these specific rotations. A ligament system between radius, ulna, radiale, and ulnare causes the radius and ulna to approximate one another during external rotation of the forearm. This approximation is conveyed distally resulting in a narrowing of the hand during external rotation of radius and ulna or during pronation of the free hand. The significance of these and related linkages is discussed.
More Related Videos
 07:30
Creating Radio-cephalic Arteriovenous Fistula in the Forearm with a Modified No-Touch Technique
Published on: April 1, 2022
 10:36
Vascularized Composite Hand Allograft Procurement and Preparation for Distal and Proximal Forearm Allotransplantation: A Stepwise Approach
Published on: May 23, 2025
Related Concept Videos
 01:16
Muscles that Move the Forearm
Forearm Flexors
The biceps brachii, brachialis, and brachioradialis are forearm flexors. The biceps brachii is made up of two heads. Its long head originates at the supraglenoid tubercle of the scapula, whereas that of the short head is...
 01:16
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:11
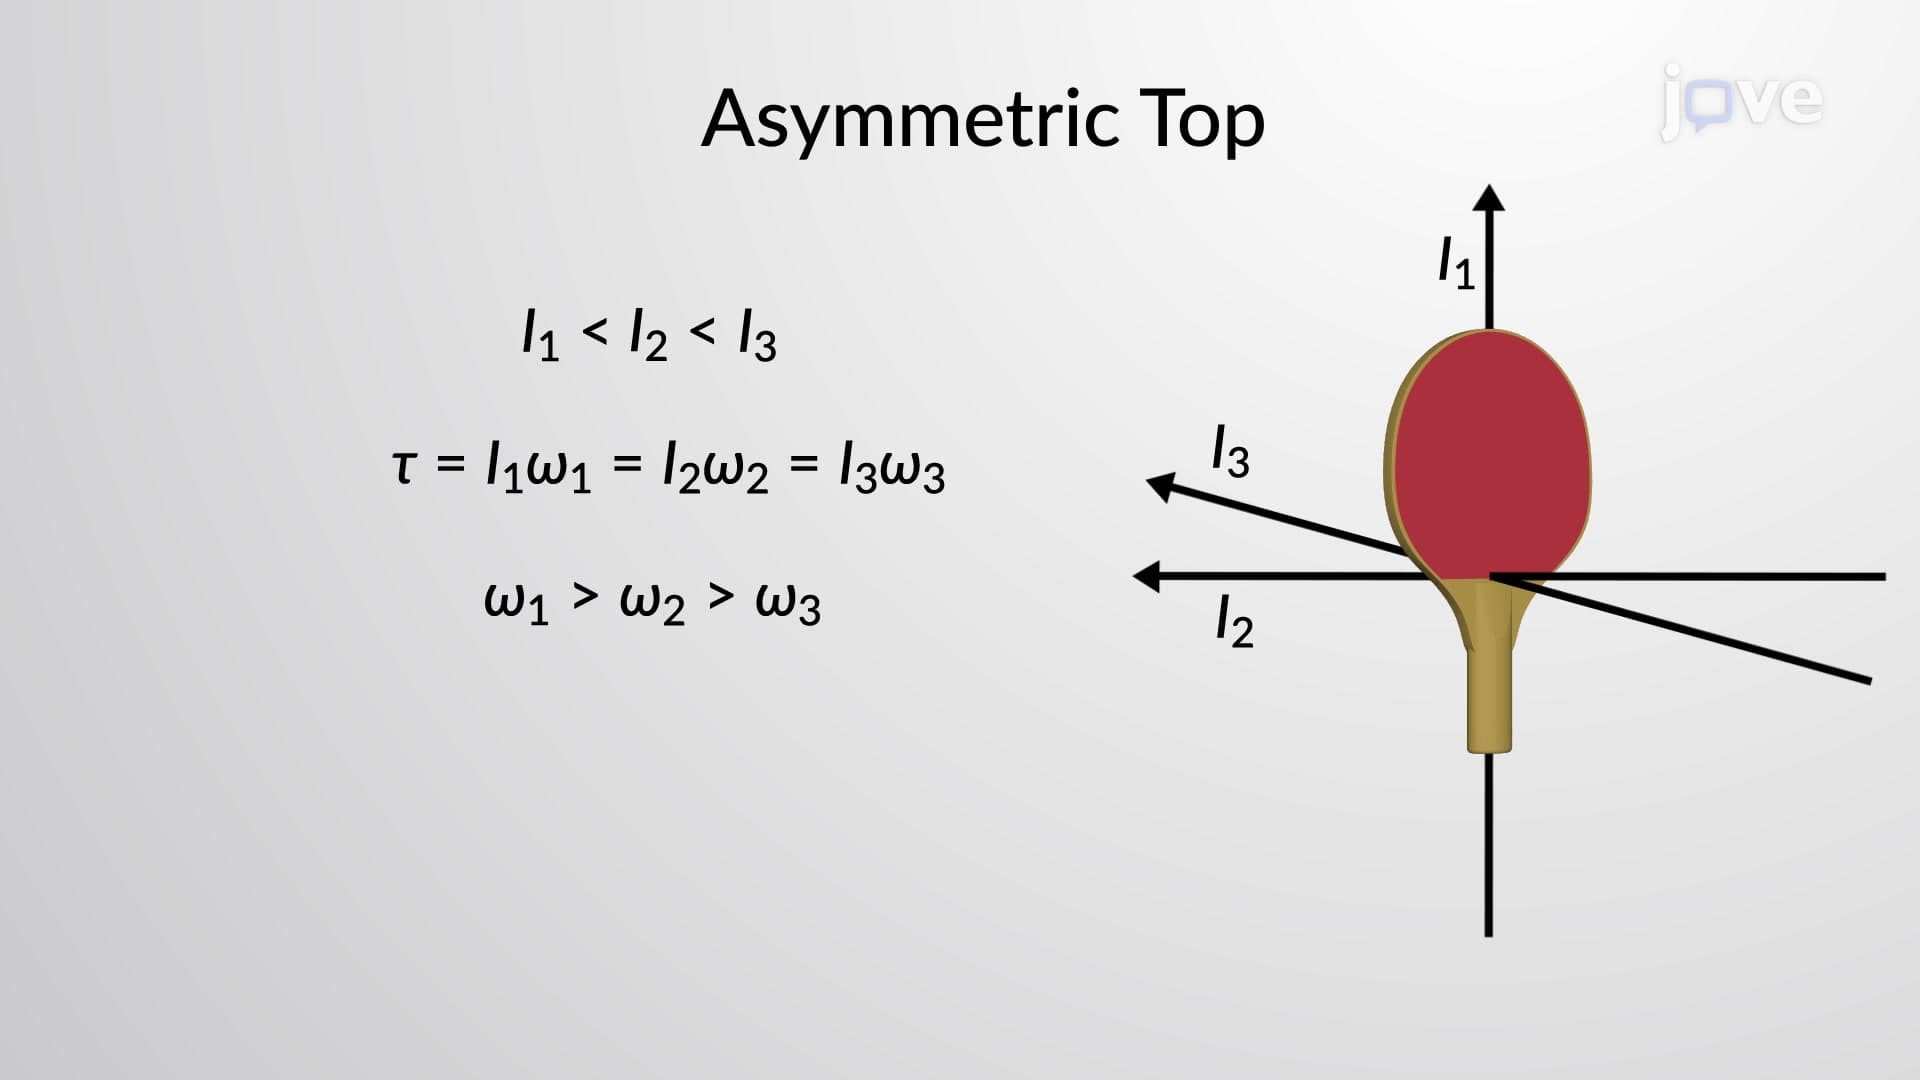
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
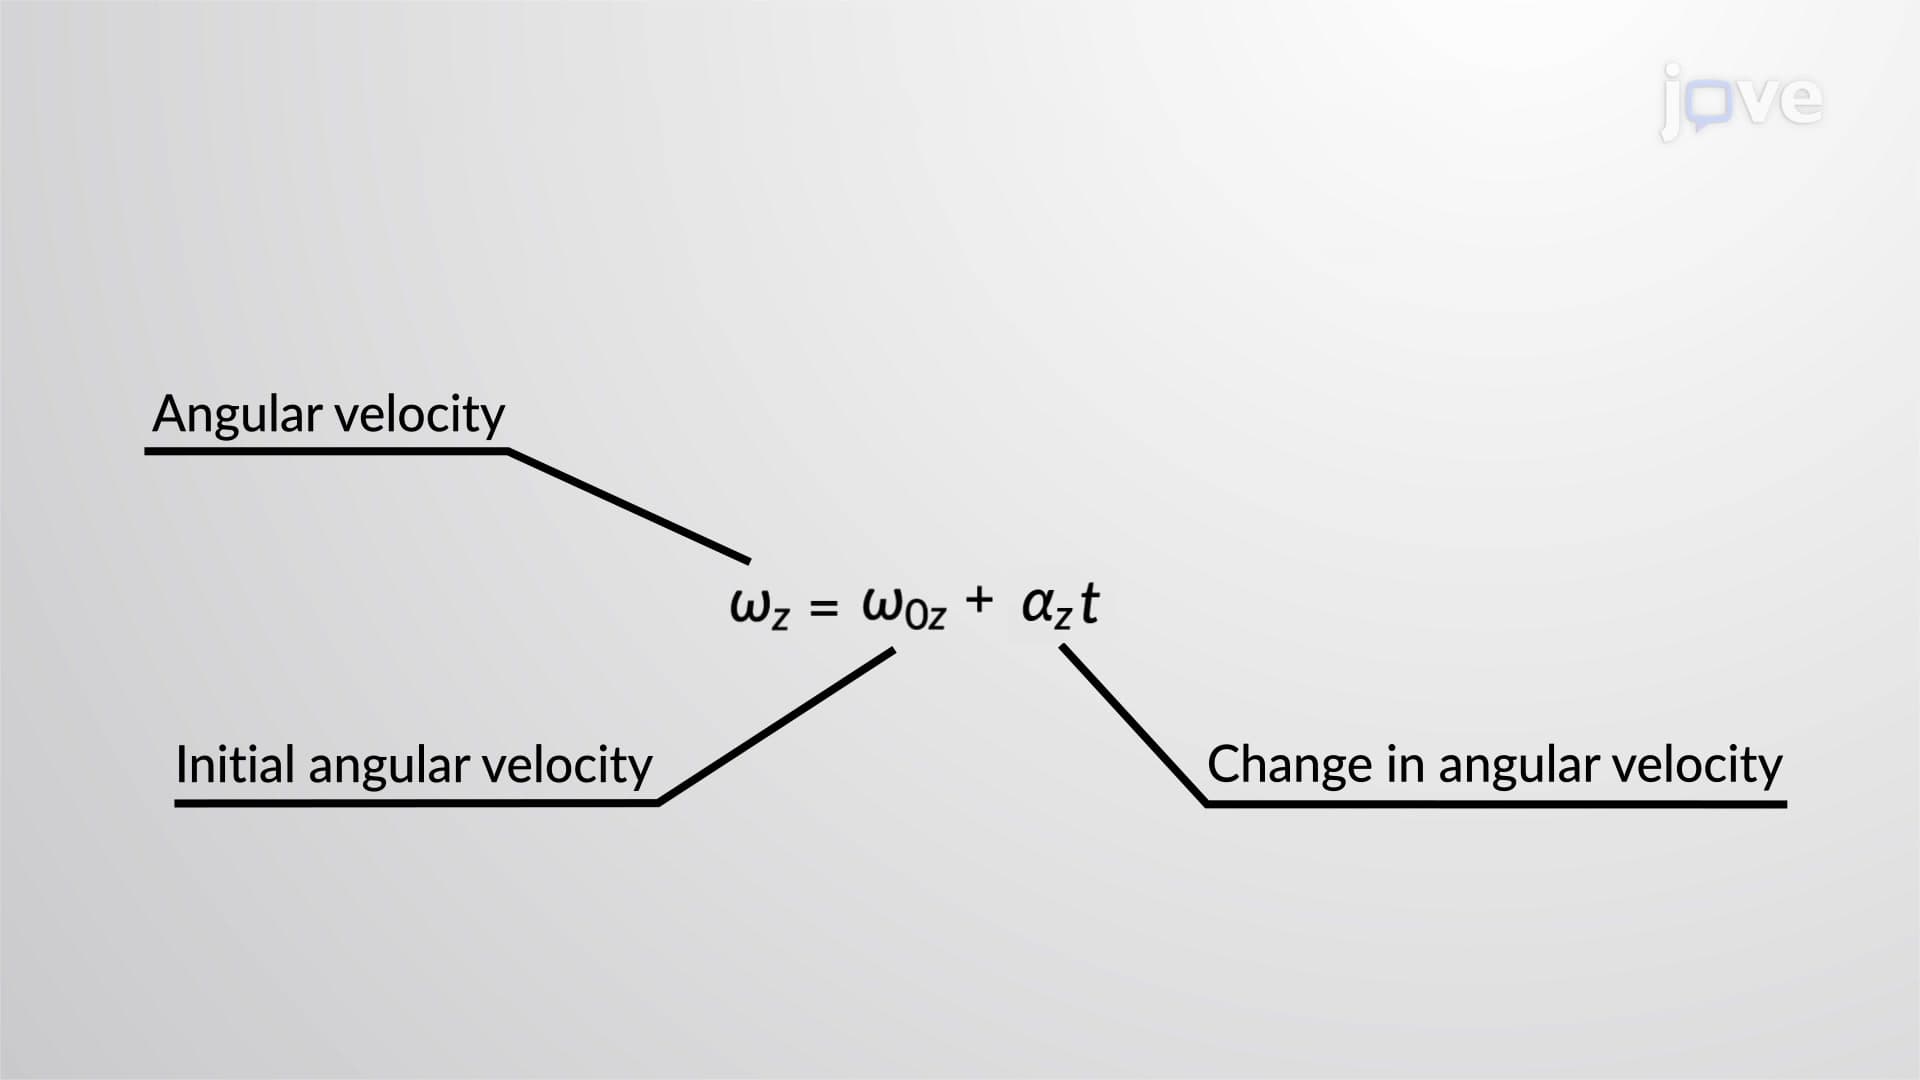 01:37
Rotation with Constant Angular Acceleration - I
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
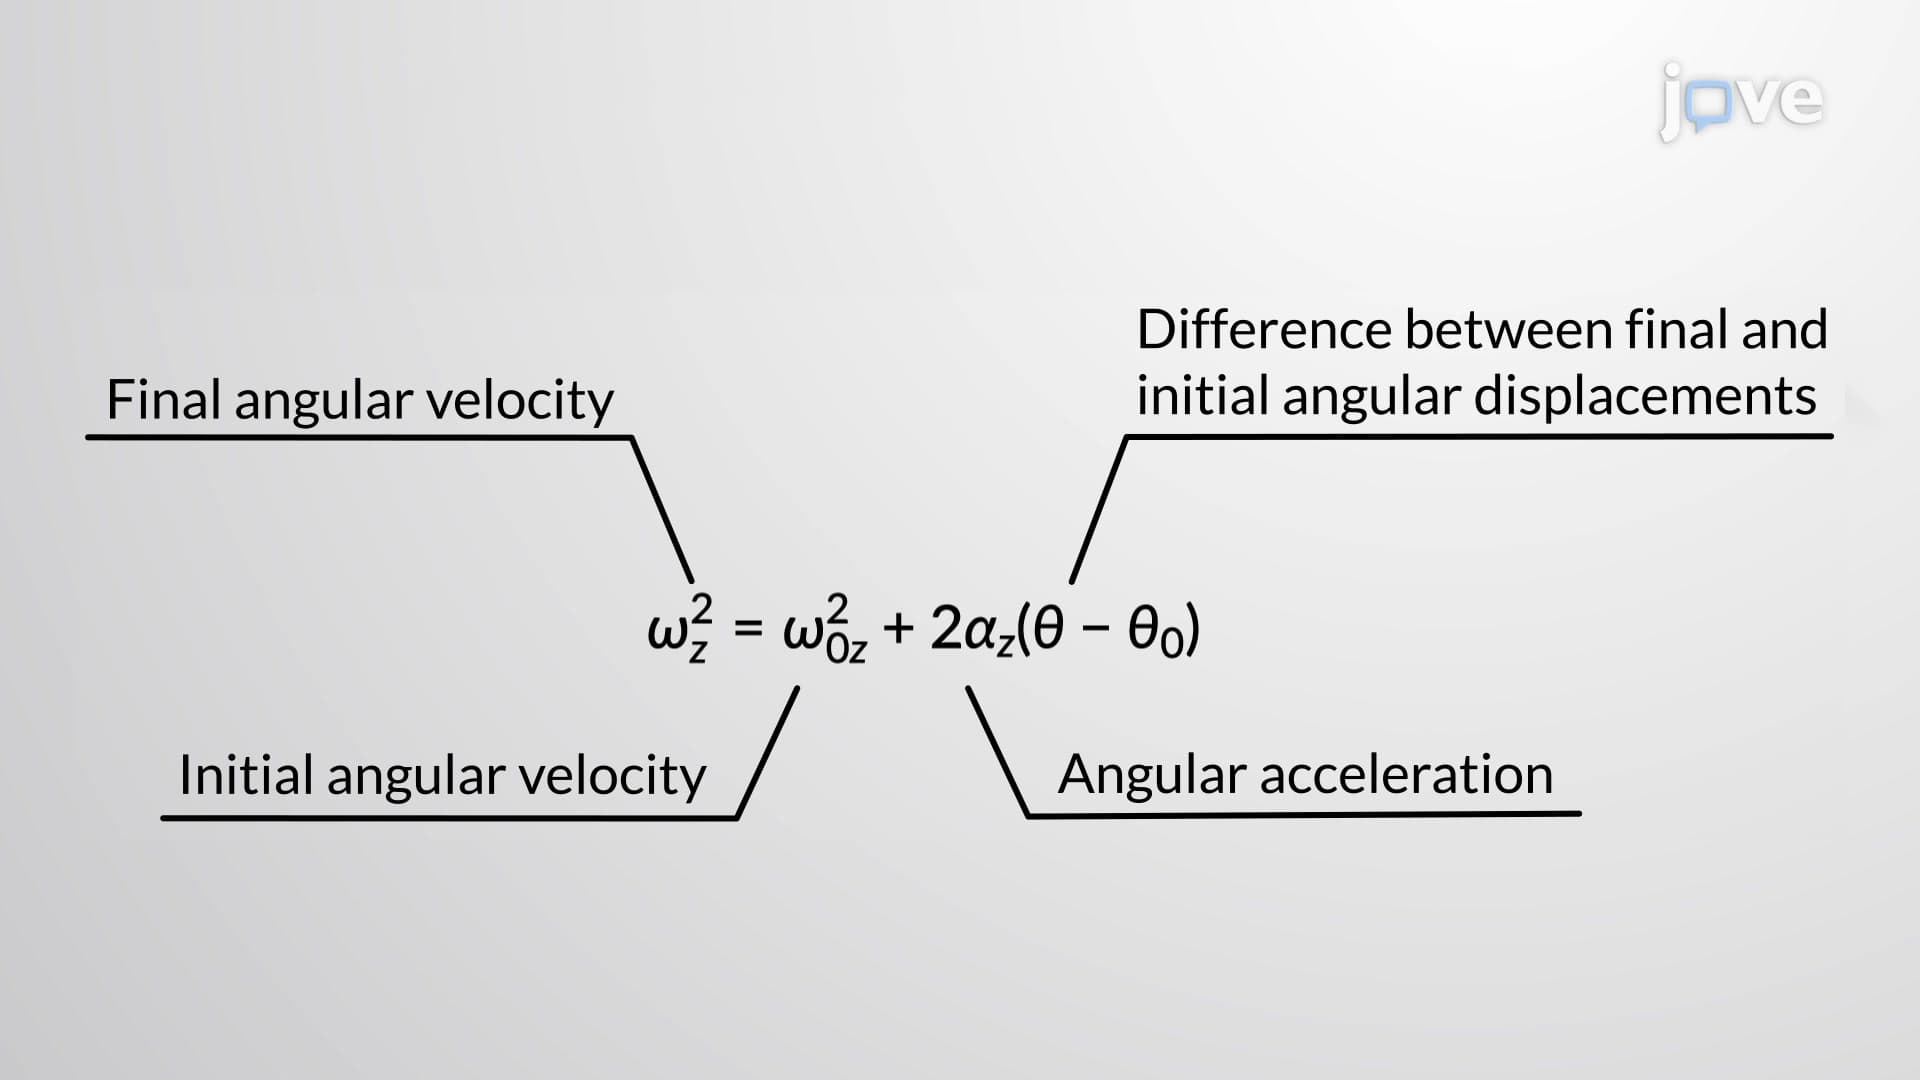 01:16
Rotation with Constant Angular Acceleration - II
The first...