
Model predictive-based reset gain-scheduling dynamic control law for polytopic LPV systems
Navid Vafamand1, Alireza Khayatian1
1School of Electrical and Computer Engineering, Shiraz University, Shiraz, Iran.

Abstract:
This paper proposes a novel systematic approach for designing a reset gain-scheduling dynamic controller based on a model predictive method for a class of nonlinear systems represented by polytopic linear parameter varying models. The proposed design procedure involves offline and online steps. In the offline step, sufficient conditions of the gain-scheduling dynamic controller design in terms of linear matrix inequalities are derived through a novel D-stability region. Thus, the feedback gain vertices are computed by the convex optimization techniques. Then in the online step, based on a predefined reset set, an affine after reset value function for the controller states is optimally selected by solving a generalized Eigenvalue problem. Also, the temporal regulation technique is utilized to avoid Zeno solution problem. Finally, the merits of the proposed controller are demonstrated by applying it on a nonlinear continuous stirred tank reactor.

Related Concept Videos
 01:10
Control Systems
At the heart...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
Reinforcement Schedules
Once a behavior is learned,...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
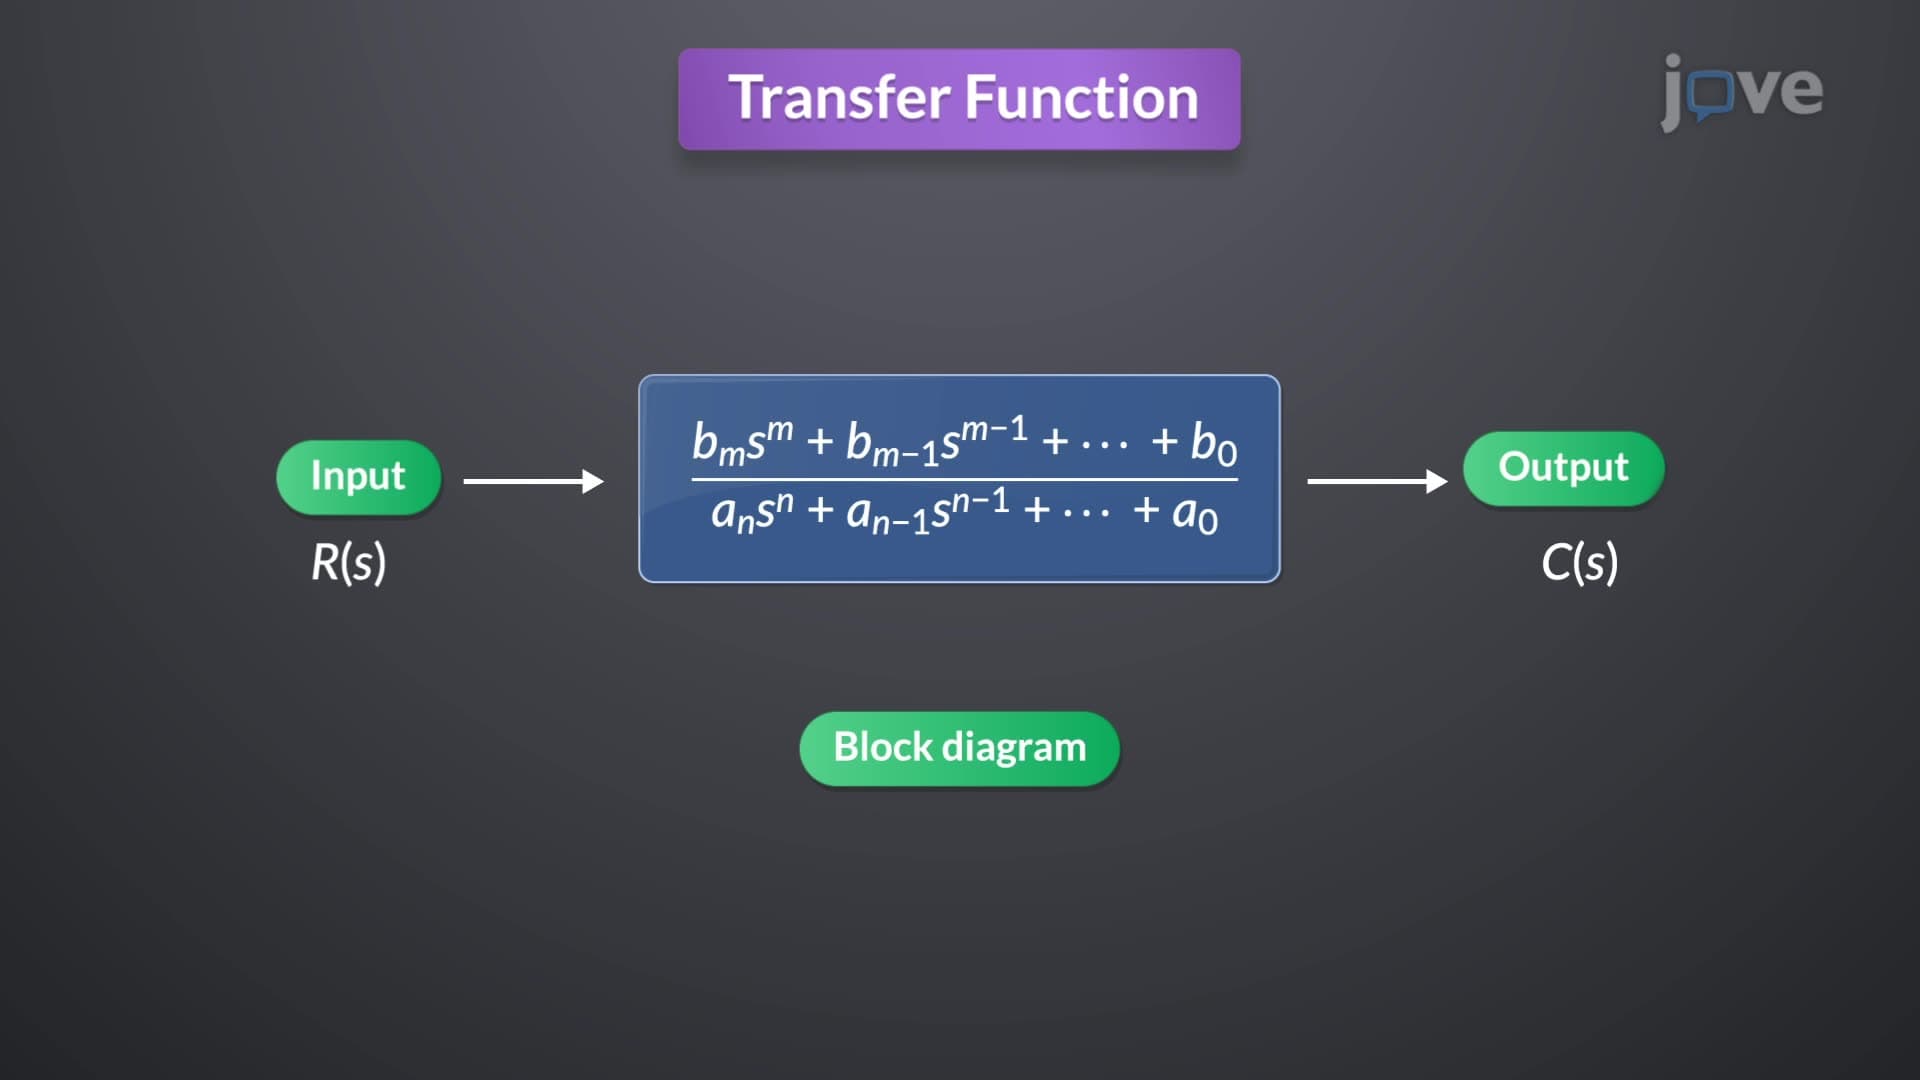
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...