Related Experiment Video
Updated: Feb 5, 2026
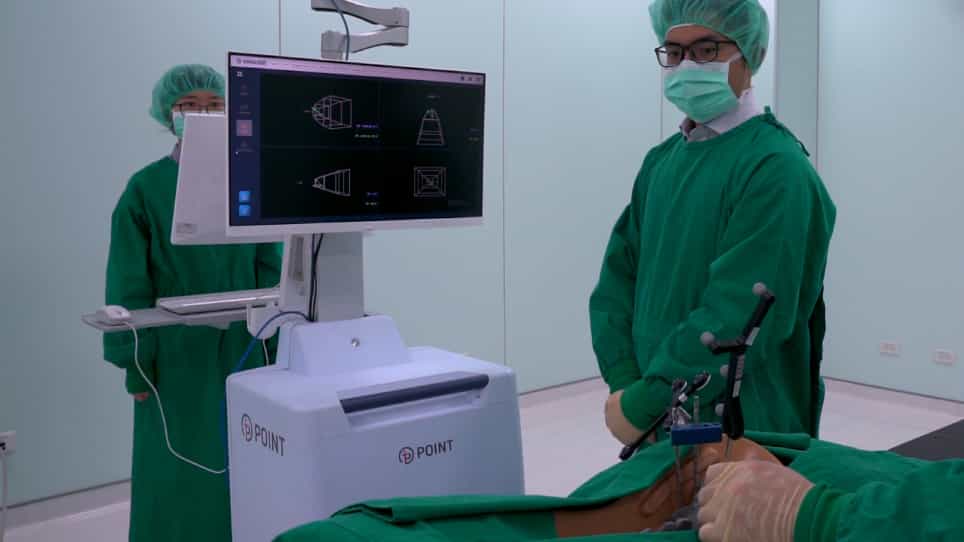

A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Robotic Guidance for the Insertion of Posterior Pedicle Screws: 2-Dimensional Operative Video
Joshua E Meyers1,2, Asham Khan1,2, John Pollina1,2
1Department of Neurosurgery, Jacobs School of Medicine and Biomedical Sciences at the University at Buffalo, Buffalo, New York.

Abstract:
Recent years have shown an increase in implementing robotics in surgical procedures. Utilizing robotic technology in spine surgery remains limited in comparison to other surgical fields. We present a surgical video of minimally invasive robotic-assisted insertion of posterior pedicle screws using the newest generation robotic technology (Mazor X, Mazor Robotics Ltd, Caesarea, Israel), in a 29-yr-old man who suffers from Grade I degenerative spondylolisthesis at L5-S1 levels and severe, right-sided foraminal stenosis. The plan was to perform anterior fusion at L5-S1 using robotic guidance with posterior pedicle screw supplementation due to his extensive smoking history. This technology has two distinct registration methods: (1) using a preoperative thin-cut computed tomography (CT) scan to create a surgical plan for screw placement; and (2) scan-and-plan using intraoperative 3-dimensional (3D) imaging to create a plan in real-time intraoperatively. We present the scan-and-plan technique. The widely used freehand technique allows the surgeon to manually direct tools and implants relying on the 6-degrees-of-freedom of the human arm. When Mazor X robotic technology is utilized, a pilot hole is drilled through a cannula docked to the bone above the entry point, which provides the surgeon with a planned trajectory and eliminates 4 of 6-degrees-of-freedom (up/down and yaw remain). This provides increased multidimensional control and reduces reliance on hand-eye coordination with simultaneous concentration on the imaging, potentially leading to increased rates of accuracy and reduction in severe complications of misplaced screws. Further prospective clinical studies are needed to determine the long-term effectiveness of this technology. Patient consent was obtained prior to performing the procedure. Institutional board review approval is not required for the report of a single case at the University at Buffalo.
More Related Videos
 04:50
Operative Technique and Nuances for the Stereoelectroencephalographic SEEG Methodology Utilizing a Robotic Stereotactic Guidance System
Published on: June 9, 2023
 12:25
C-arm-Free Simultaneous OLIF51 and Percutaneous Pedicle Screw Fixation in a Single Lateral Position
Published on: September 16, 2022
Related Concept Videos
 01:21
Screw: Problem Solving
To evaluate the...
 01:16
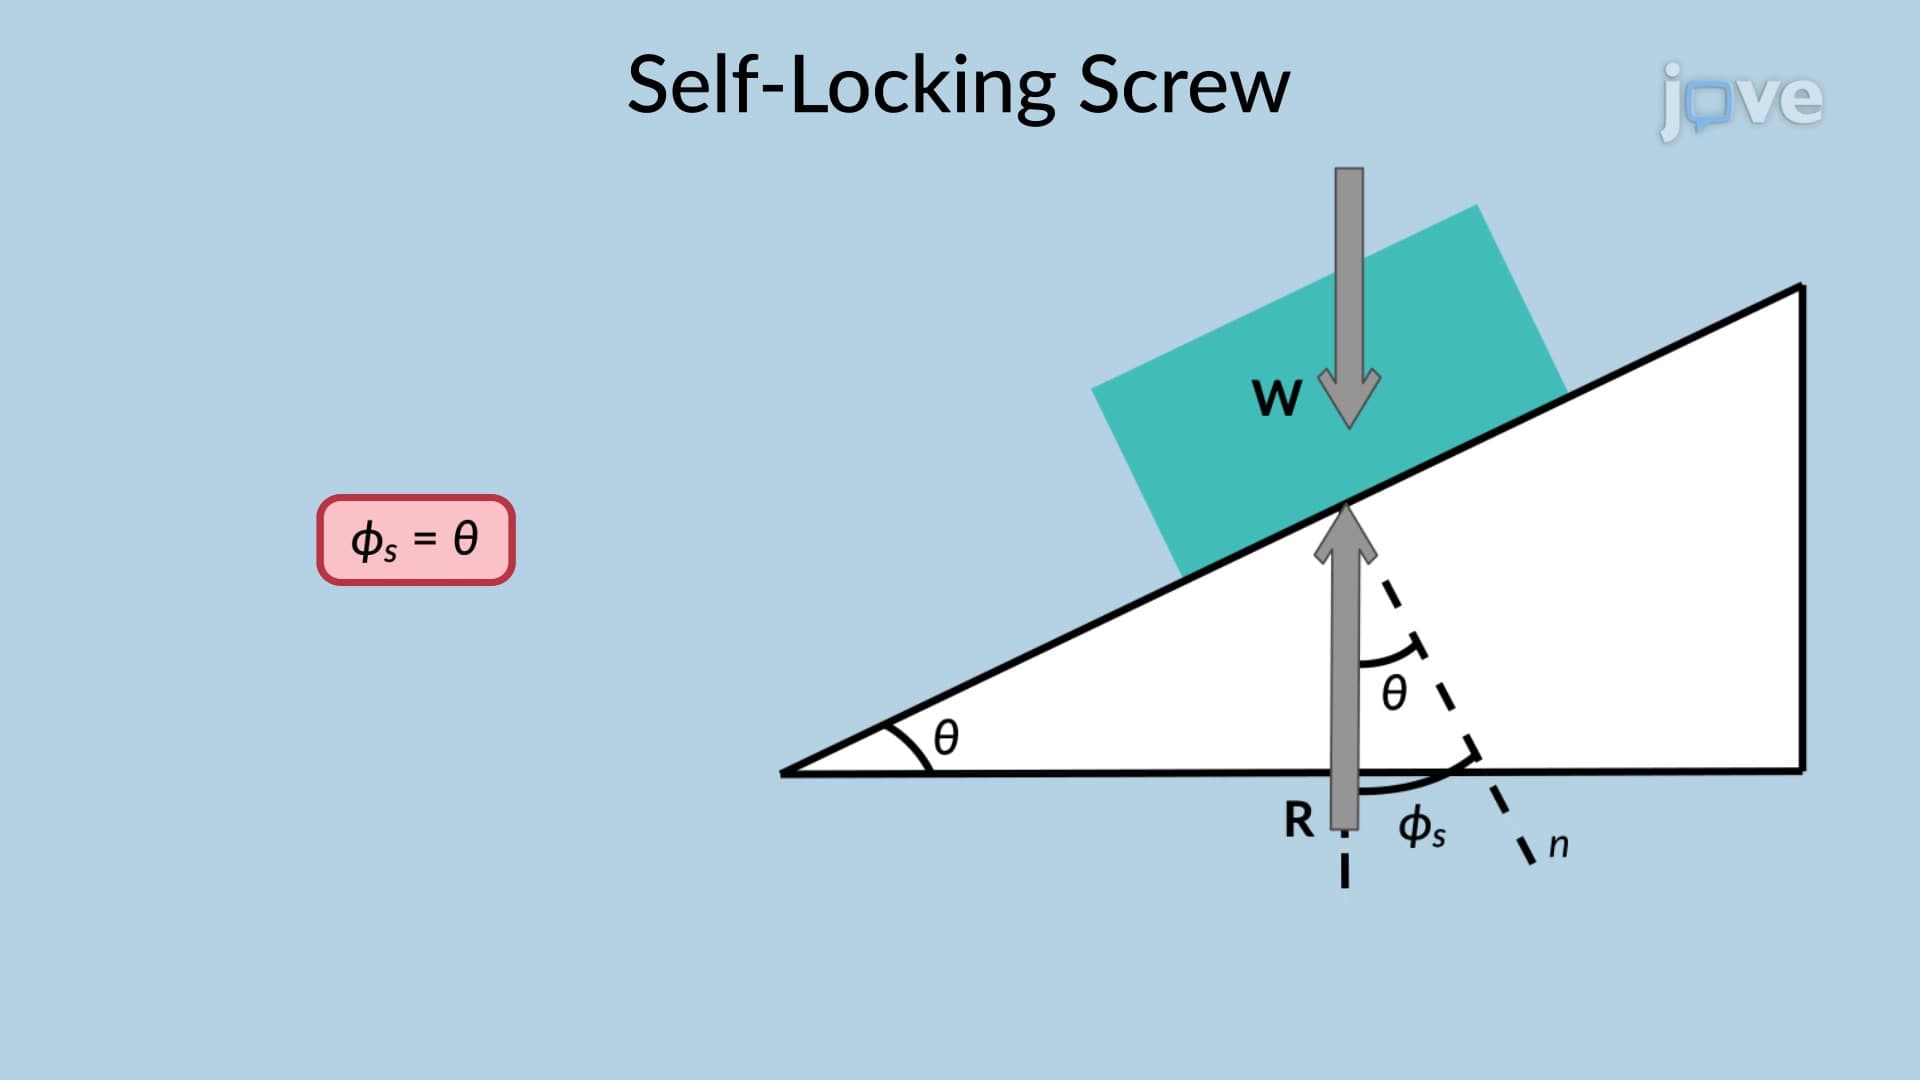
Self-Locking Screw
A square-threaded screw jack carrying a load is considered self-locking if the screw retains its position even after the moment applied to it is removed.
 03:40
Dimensional Analysis
Conversion Factors and Dimensional Analysis
The unit...
 01:17
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...
 01:17
Operational Amplifiers
 01:27
Real Number Operations