Related Experiment Video
Updated: Jun 6, 2026
Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Come on baby, let's do the twist: the kinematics of killing in loggerhead shrikes
Diego Sustaita1, Margaret A Rubega2, Susan M Farabaugh3
1Department of Ecology and Evolutionary Biology, University of Connecticut, 75 N. Eagleville Road, Unit 3043, Storrs, CT 06269-3043, USA dsustaita@csusm.edu.

Abstract:
Shrikes use their beaks for procuring, dispatching and processing their arthropod and vertebrate prey. However, it is not clear how the raptor-like bill of this predatory songbird functions to kill vertebrate prey that may weigh more than the shrike itself. In this paper, using high-speed videography, we observed that upon seizing prey with their beaks, shrikes performed rapid (6-17 Hz; 49-71 rad s-1) axial head-rolling movements. These movements accelerated the bodies of their prey about their own necks at g-forces of approximately 6 g, and may be sufficient to cause pathological damage to the cervical vertebrae and spinal cord. Thus, when tackling relatively large vertebrates, shrikes appear to use inertia of their prey's own body against them.
Related Concept Videos
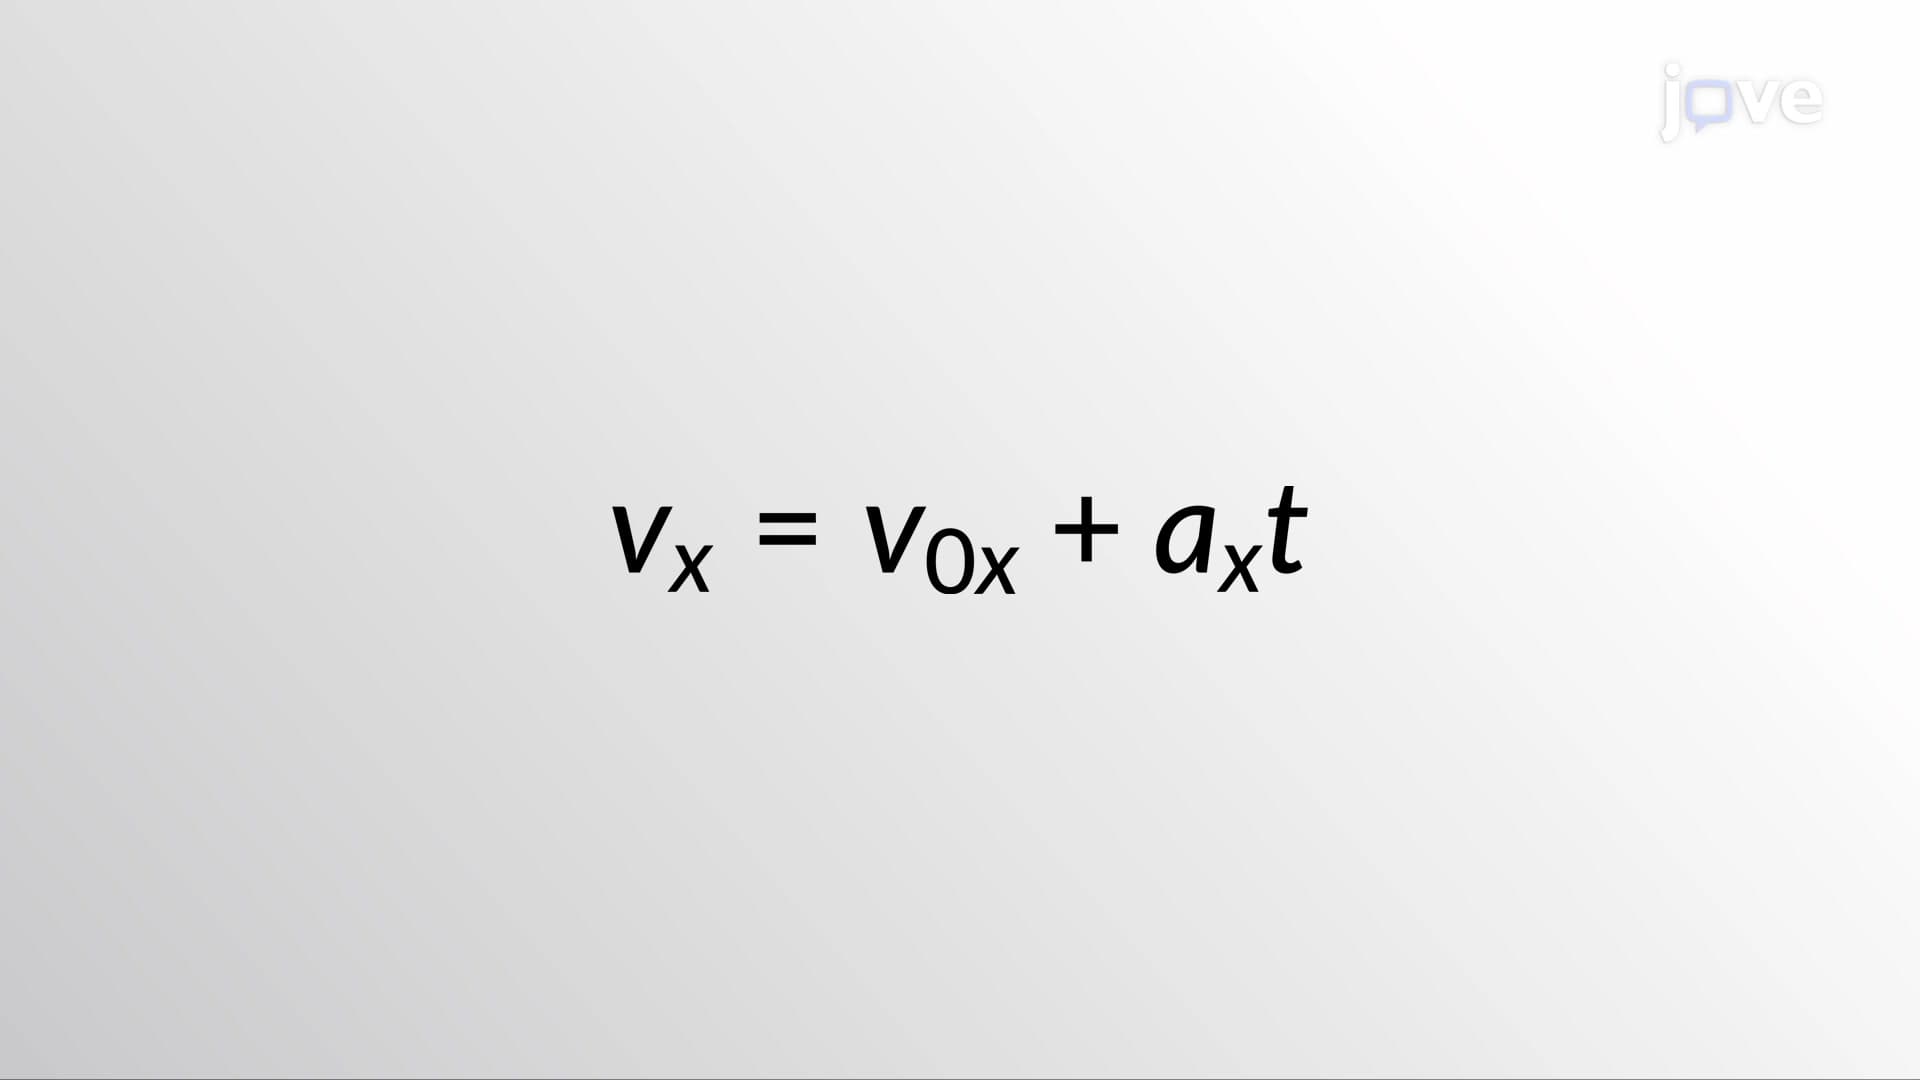 01:26
Kinematic Equations - I
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:18
Conservation of Angular Momentum: Application
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...