Related Experiment Video
Updated: Feb 5, 2026

A Novel Bayesian Change-point Algorithm for Genome-wide Analysis of Diverse ChIPseq Data Types
Published on: December 10, 2012
Fully Bayesian Prediction Algorithms for Mobile Robotic Sensors under Uncertain Localization Using Gaussian Markov
Mahdi Jadaliha1, Jinho Jeong2, Yunfei Xu3
1Monsanto, St. Louis, MO 63146, USA. jadaliha@gmail.com.

Abstract:
In this paper, we present algorithms for predicting a spatio-temporal random field measured by mobile robotic sensors under uncertainties in localization and measurements. The spatio-temporal field of interest is modeled by a sum of a time-varying mean function and a Gaussian Markov random field (GMRF) with unknown hyperparameters. We first derive the exact Bayesian solution to the problem of computing the predictive inference of the random field, taking into account observations, uncertain hyperparameters, measurement noise, and uncertain localization in a fully Bayesian point of view. We show that the exact solution for uncertain localization is not scalable as the number of observations increases. To cope with this exponentially increasing complexity and to be usable for mobile sensor networks with limited resources, we propose a scalable approximation with a controllable trade-off between approximation error and complexity to the exact solution. The effectiveness of the proposed algorithms is demonstrated by simulation and experimental results.
Related Concept Videos
 01:30
Gaussian Elimination: Problem Solving
 02:27
Predicting Molecular Geometry
 01:12
Trial and Error and Algorithm
 01:04
Random Error
 01:09
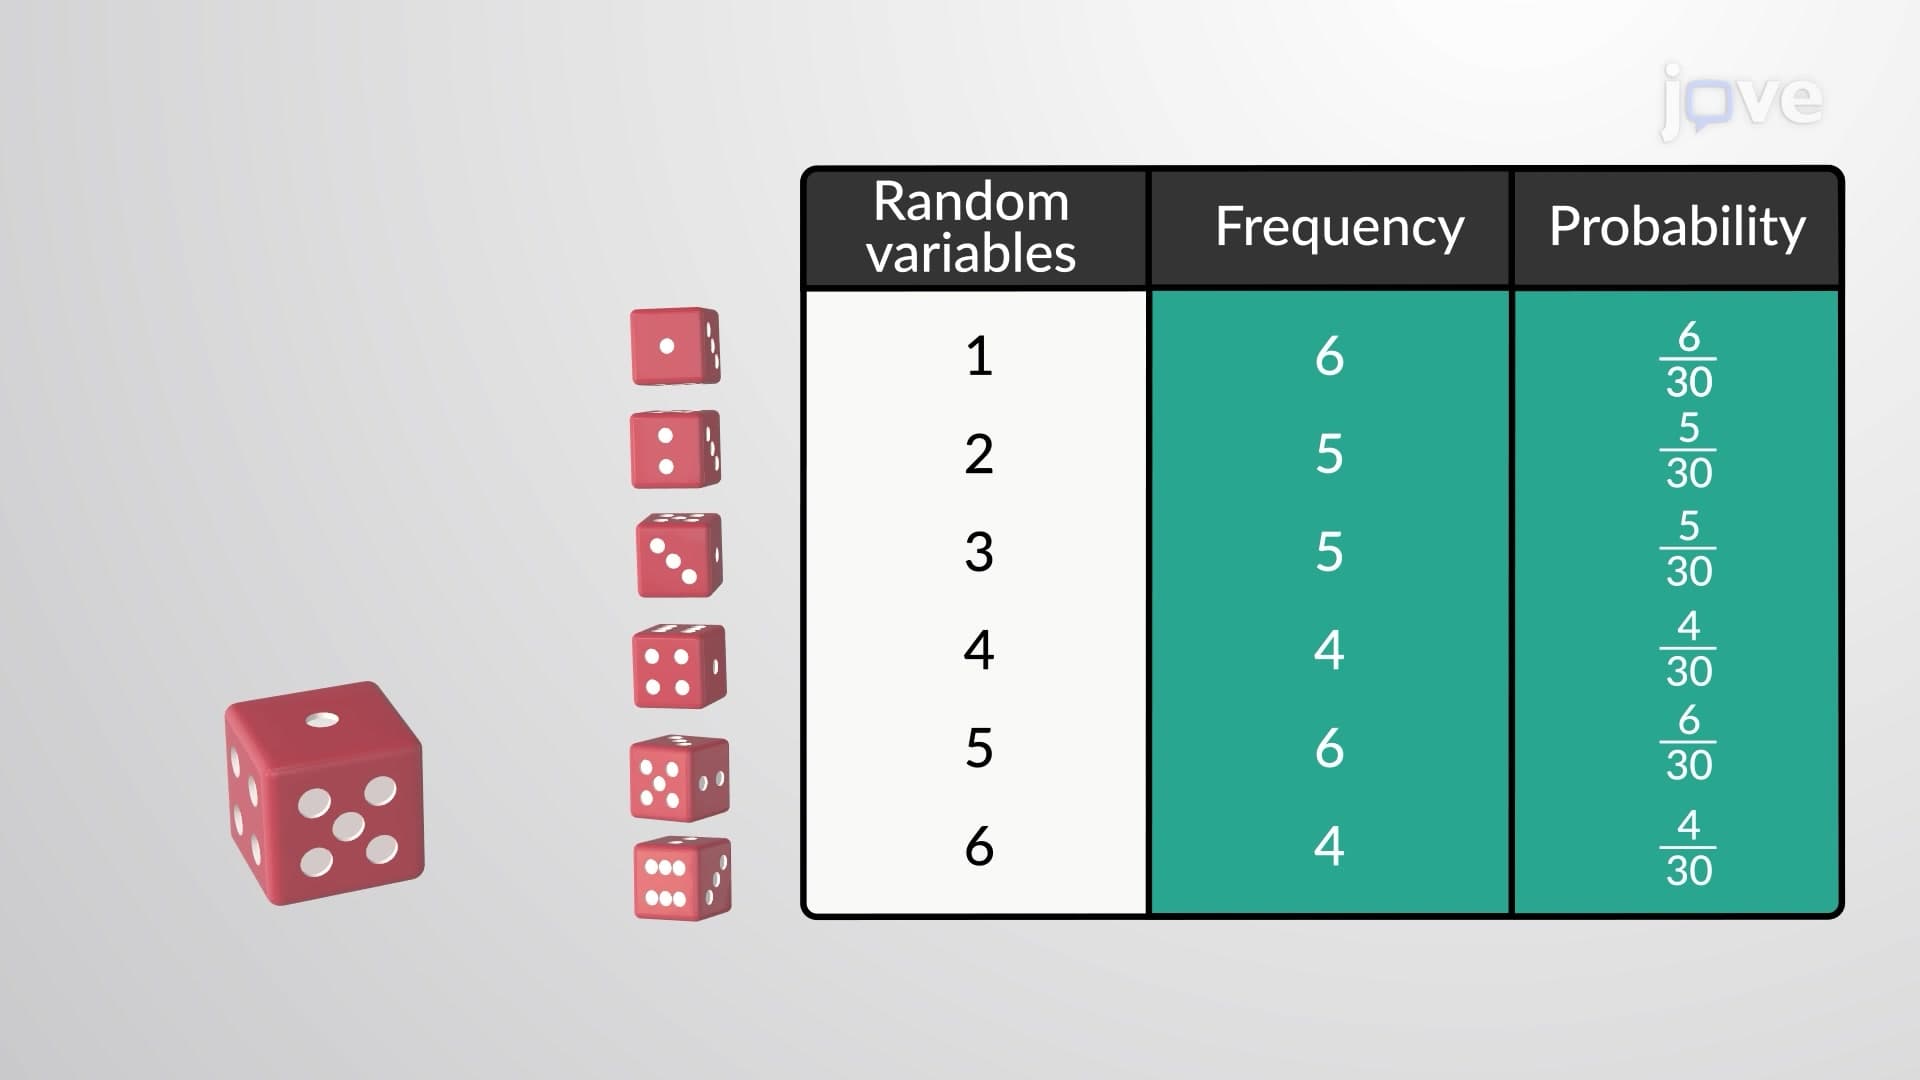
Random Variables
Uppercase letters such as X or Y denote a random variable. Lowercase letters like x or y denote the value of a random variable. If X is a random variable, then X is written in words, and x is given as a number.
For example, let X = the...
 01:13
Randomized Experiments
Simple randomization
Simple...