Related Experiment Video
Updated: Feb 5, 2026


Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
A Biologically Inspired Approach for Robot Depth Estimation
Ester Martinez-Martin1, Angel P Del Pobil2,3
1RoViT, University of Alicante, 03690 Sant Vicent del Raspeig, Spain.

Abstract:
Aimed at building autonomous service robots, reasoning, perception, and action should be properly integrated. In this paper, the depth cue has been analysed as an early stage given its importance for robotic tasks. So, from neuroscience findings, a hierarchical four-level dorsal architecture has been designed and implemented. Mainly, from a stereo image pair, a set of complex Gabor filters is applied for estimating an egocentric quantitative disparity map. This map leads to a quantitative depth scene representation that provides the raw input for a qualitative approach. So, the reasoning method infers the data required to make the right decision at any time. As it will be shown, the experimental results highlight the robust performance of the biologically inspired approach presented in this paper.

Related Concept Videos
 01:30
Mechanism of Breathing I: Inspiration
The respiratory system, an essential network for breathing, comprises the conducting and respiratory zones, each playing a crucial role in the overall process of respiration. Let us explore the detailed mechanism of inspiration, or inhalation, which is the first phase of the respiratory cycle.
Pathway of Air during Inspiration
During inspiration, air enters our body through the nose or mouth and moves through the conducting zone,...
 01:06
What are Estimates?
The estimate for the mean of a sample is denoted by ͞x, whereas the mean of the population is designated as μ. Further, parameters such...
 01:27
Uniform Depth Channel Flow
 01:57
What is Conservation Biology?
 01:15
Depth Perception and Spatial Vision
 01:20
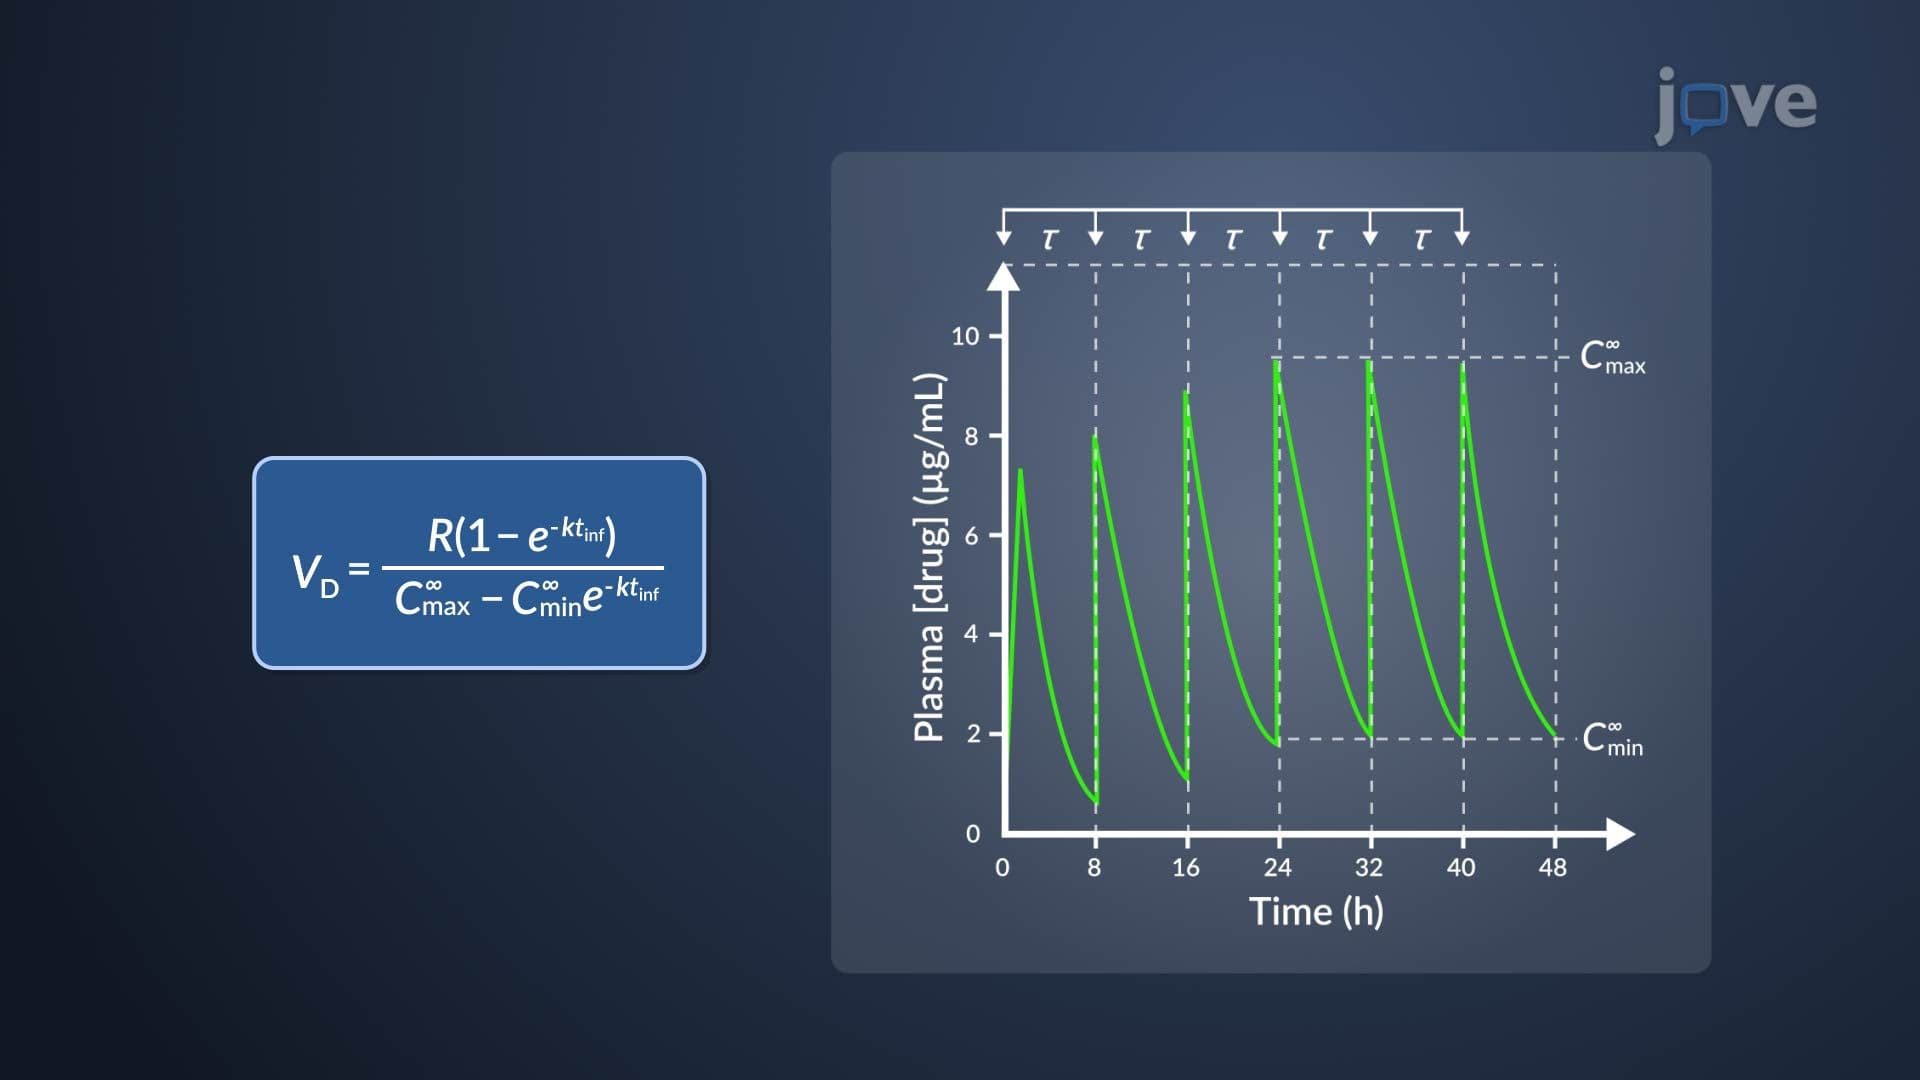
Estimation of k and VD of Aminoglycosides