Related Experiment Video
Updated: Feb 5, 2026


Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023
Effects of gait support in patients with spinocerebellar degeneration by a wearable robot based on synchronization
Atsushi Tsukahara1,2, Kunihiro Yoshida3,4, Akira Matsushima5
1Department of Mechanical Engineering and Robotics, Faculty of Textile Science and Technology, Shinshu University, 3-15-1 Tokida, Ueda, 386-8567, Japan. a_tsukahara@shinshu-u.ac.jp.

Background:
Spinocerebellar degeneration (SCD) mainly manifests a cerebellar ataxic gait, leading to marked postural sway and the risk of falling down. Gait support using a wearable robot is expected to be an effective solution to maintaining the status quo and/or delaying symptom progression. The aim of this study was to evaluate the effects of gait support in patients with SCD by using a wearable robotic system called curara ®; while undergoing walking tests.
Methods:
The curara system assists both the hip and knee joints and supports the wearer's rhythmic gait using a synchronization control based on a central pattern generator. The system reflects the wearer's intended motion in response to the gait support by detecting an interactive force that is generated from slight movements of the wearer. The degree of coordinated motion between the robot and the wearer can be adjusted by modifying the synchronization gain. In this study, we provided gait support using three high-gain conditions (A, B, C) to more easily follow the wearer's movement in each joint. The synchronization gains for both the hip and knee joints (i.e., Ch and Ck) were set at 0.5 for condition A and at 0.4 for condition B. Condition C had different gains for the hip and knee joints (i.e., Ch=0.4 and Ck=0.5). With the walking test, we assessed the effects of the gait support provided by the curara system on walking smoothness (measured using the harmonic ratio: HR) and spatiotemporal parameters (gait speed, stride length, cadence) in SCD patients (n=12). We compared the performance between the three high-gain conditions and without assistance from the robot.
Results:
Under condition C, the HRs in the anteroposterior, mediolateral, and vertical directions (HR-AP, HR-ML, and HR-V) were especially high compared with those under conditions A and B. The results of the statistical analyses using repeated measures analysis of variance followed by Tukey's test showed that gait support with condition C results in a statistically significant increase in the HR-AP (2.04 ±0.52; p=0.025) and HR-V (2.06 ±0.37; p=0.032) when compared with walking without assistance from the system. In contrast, the gait speed, stride length, and cadence under condition C were no major changes in most patients, compared with the patient's walking without assistance.
Conclusions:
The significantly increased HR indicates that gait support under condition C achieved smoother walking than when not wearing the power unit of the system. Consequently, we suggest that gait support using the curara system has the potential to improve walking smoothness in patients with SCD.
Related Concept Videos
 01:27
Pharmacodynamics in Geriatric Patients: Effects of Age
 01:28
Self-Help Support Groups
Accessibility and Cost-Effectiveness
One of the primary strengths of self-help...
 02:19
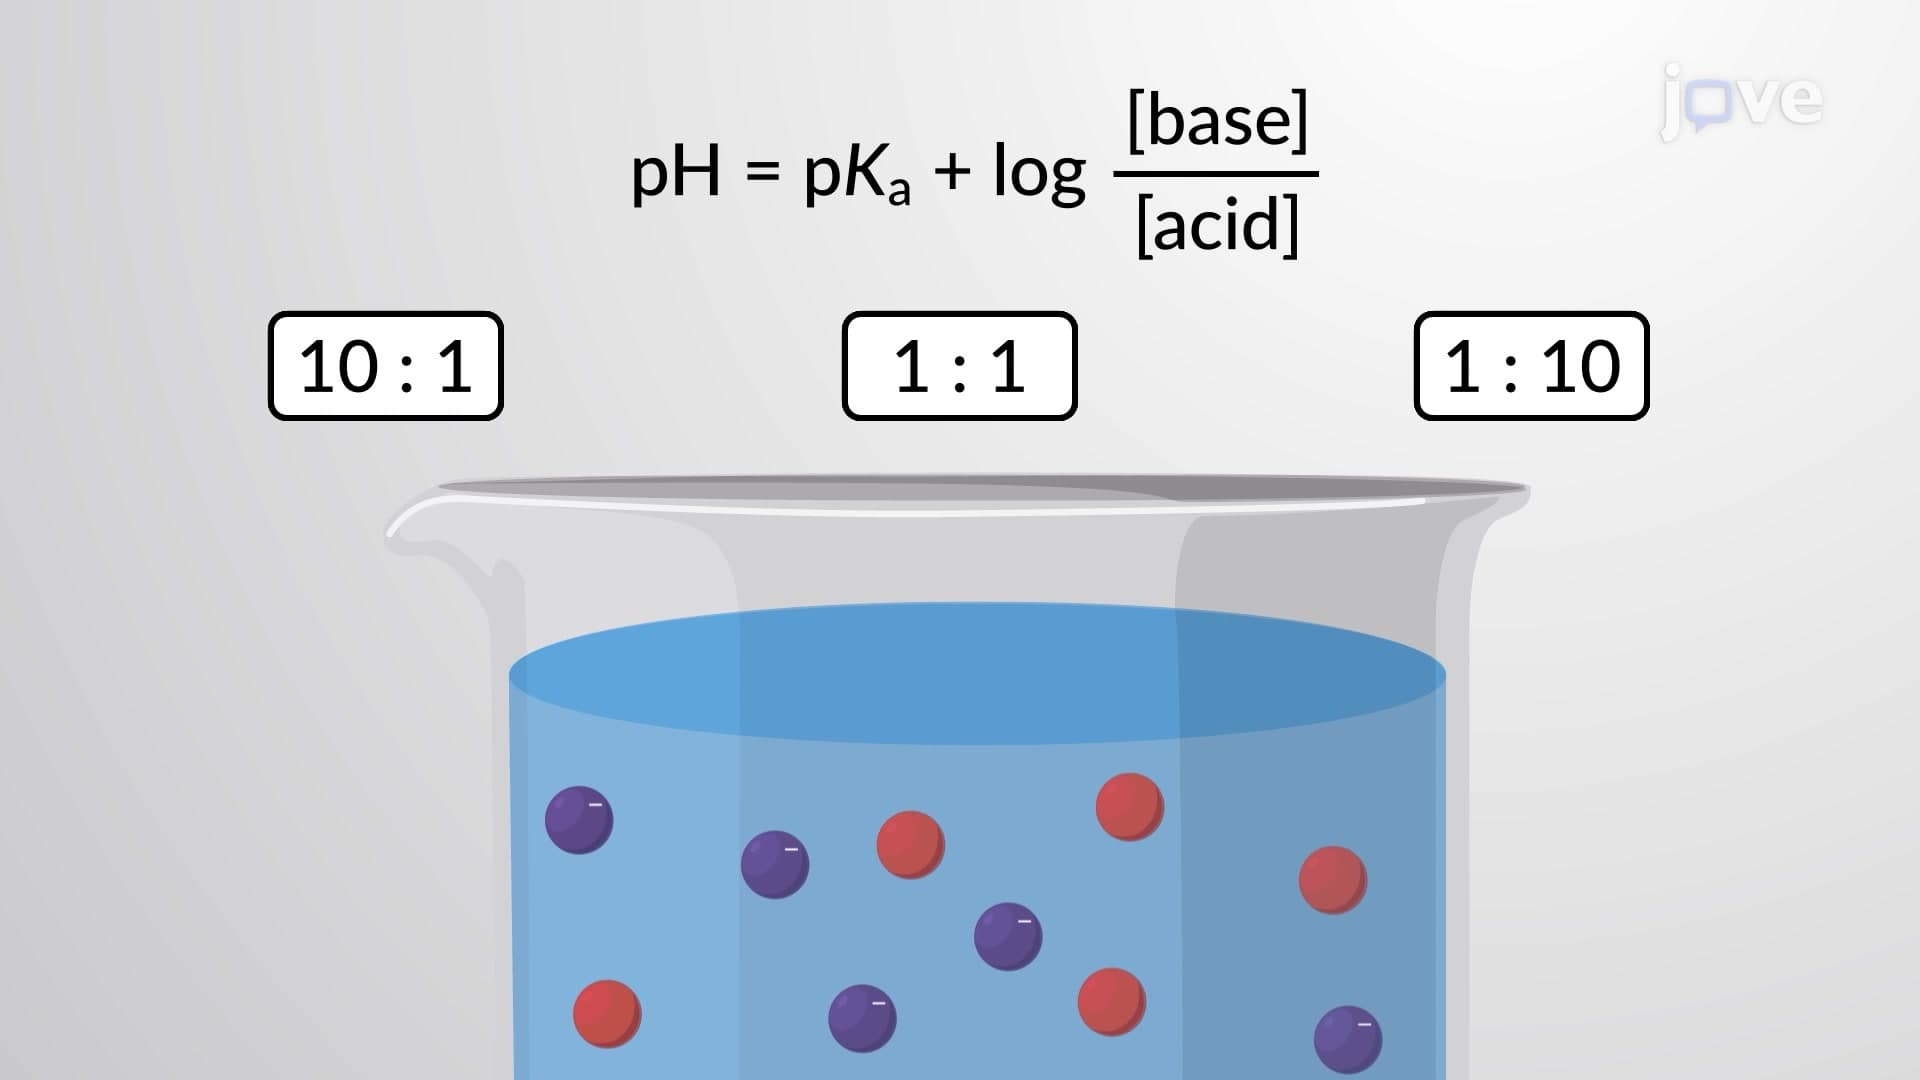
Buffer Effectiveness
The buffer capacity is the amount of acid or base that can be added to a given volume...
 01:30
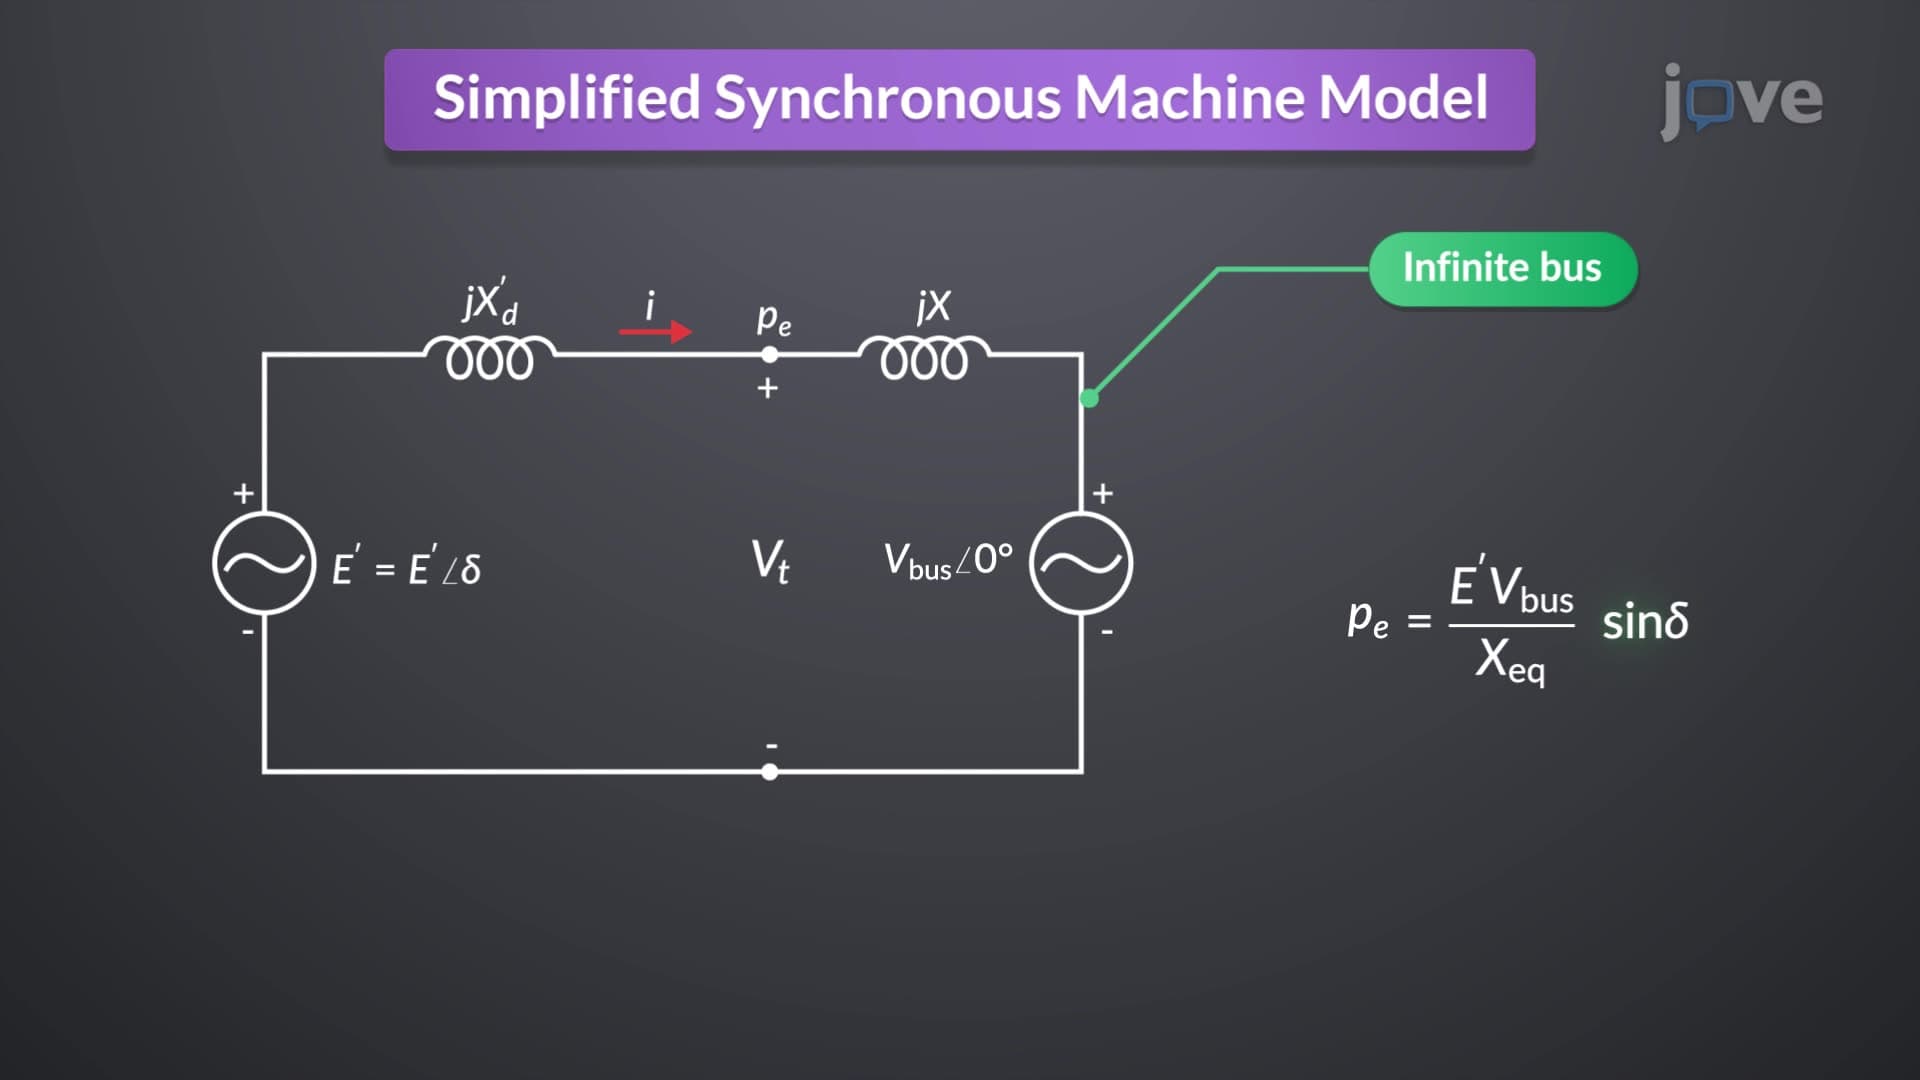
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:30
Support Reactions
The purpose of the supports is to prevent the translational motion of the system by applying an equal and opposite force and to prevent the system's rotation by applying...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...