Related Experiment Video
Updated: Feb 4, 2026

Failure of Cleaning Verification in Pharmaceutical Industry Due to Uncleanliness of Stainless Steel Surface
Published on: August 11, 2017
MLC positioning verification for small fields: a new investigation into automatic EPID-based verification methods
Joshua Hiatt1,2, Godfrey Mukwada3, Michael Barnes4,5
1Department of Radiation Oncology, Liverpool & Macarthur Cancer Therapy Centres, Liverpool, NSW, 2170, Australia. Joshua.Hiatt@health.nsw.gov.au.

Abstract:
Multileaf-collimator (MLC) defined small fields in radiotherapy are used in high dose, ultra-conformal techniques such as stereotactic radiotherapy and stereotactic radiosurgery. Proximity to critical structures and irreversible damage arising from inaccurate delivery mean that correct positioning of the MLC system is of the utmost importance. Some of the existing techniques for MLC positioning quality assurance make use of electronic portal imaging device (EPID) images. However, conventional collimation verification algorithms based on the full width at half maximum (FWHM) fail when applied to small field images acquired by an EPID due to overlapping aperture penumbrae, lateral electron disequilibrium and radiation source occlusion. The objective of this study was to investigate sub-pixel edge detection and other techniques with the aim of developing an automatic and autonomous EPID-based method suitable for MLC positional verification of small static fields with arbitrary shapes. Methods investigated included derivative interpolation, Laplacian of Gaussian (LoG) and an algorithm based on the partial area effect hypothesis. None of these methods were found to be suitable for MLC positioning verification in small field conditions. A method is proposed which uses a manufacturer-specific empirically modified FWHM algorithm which shows improvement over the conventional techniques in the small field size range. With a measured mean absolute difference from planned position for Varian linacs of 0.01 ± 0.26 mm, compared with the erroneous FWHM value of 0.70 ± 0.51 mm. For Elekta linacs the proposed algorithm returned 0.26 ± 0.25 mm, in contrast to the FWHM result of 1.79 ± 1.07 mm.
More Related Videos
 09:36
Continuous-Wave Propagation Channel-Sounding Measurement System - Testing, Verification, and Measurements
Published on: June 25, 2021
 06:27
Simple Surgical Induction of Conductive Hearing Loss with Verification Using Otoscope Visualization and Behavioral Clap Startle Response in Rat
Published on: October 26, 2019
Related Concept Videos
 03:00
Self-Evaluation: Self-Enhancement and Self-Verification
 01:17
Strategies of Self-Presentation II: Self-Verification
 01:28
Field Application of Global Positioning System
 01:28
Automatic Processing and Automatic Social Behavior
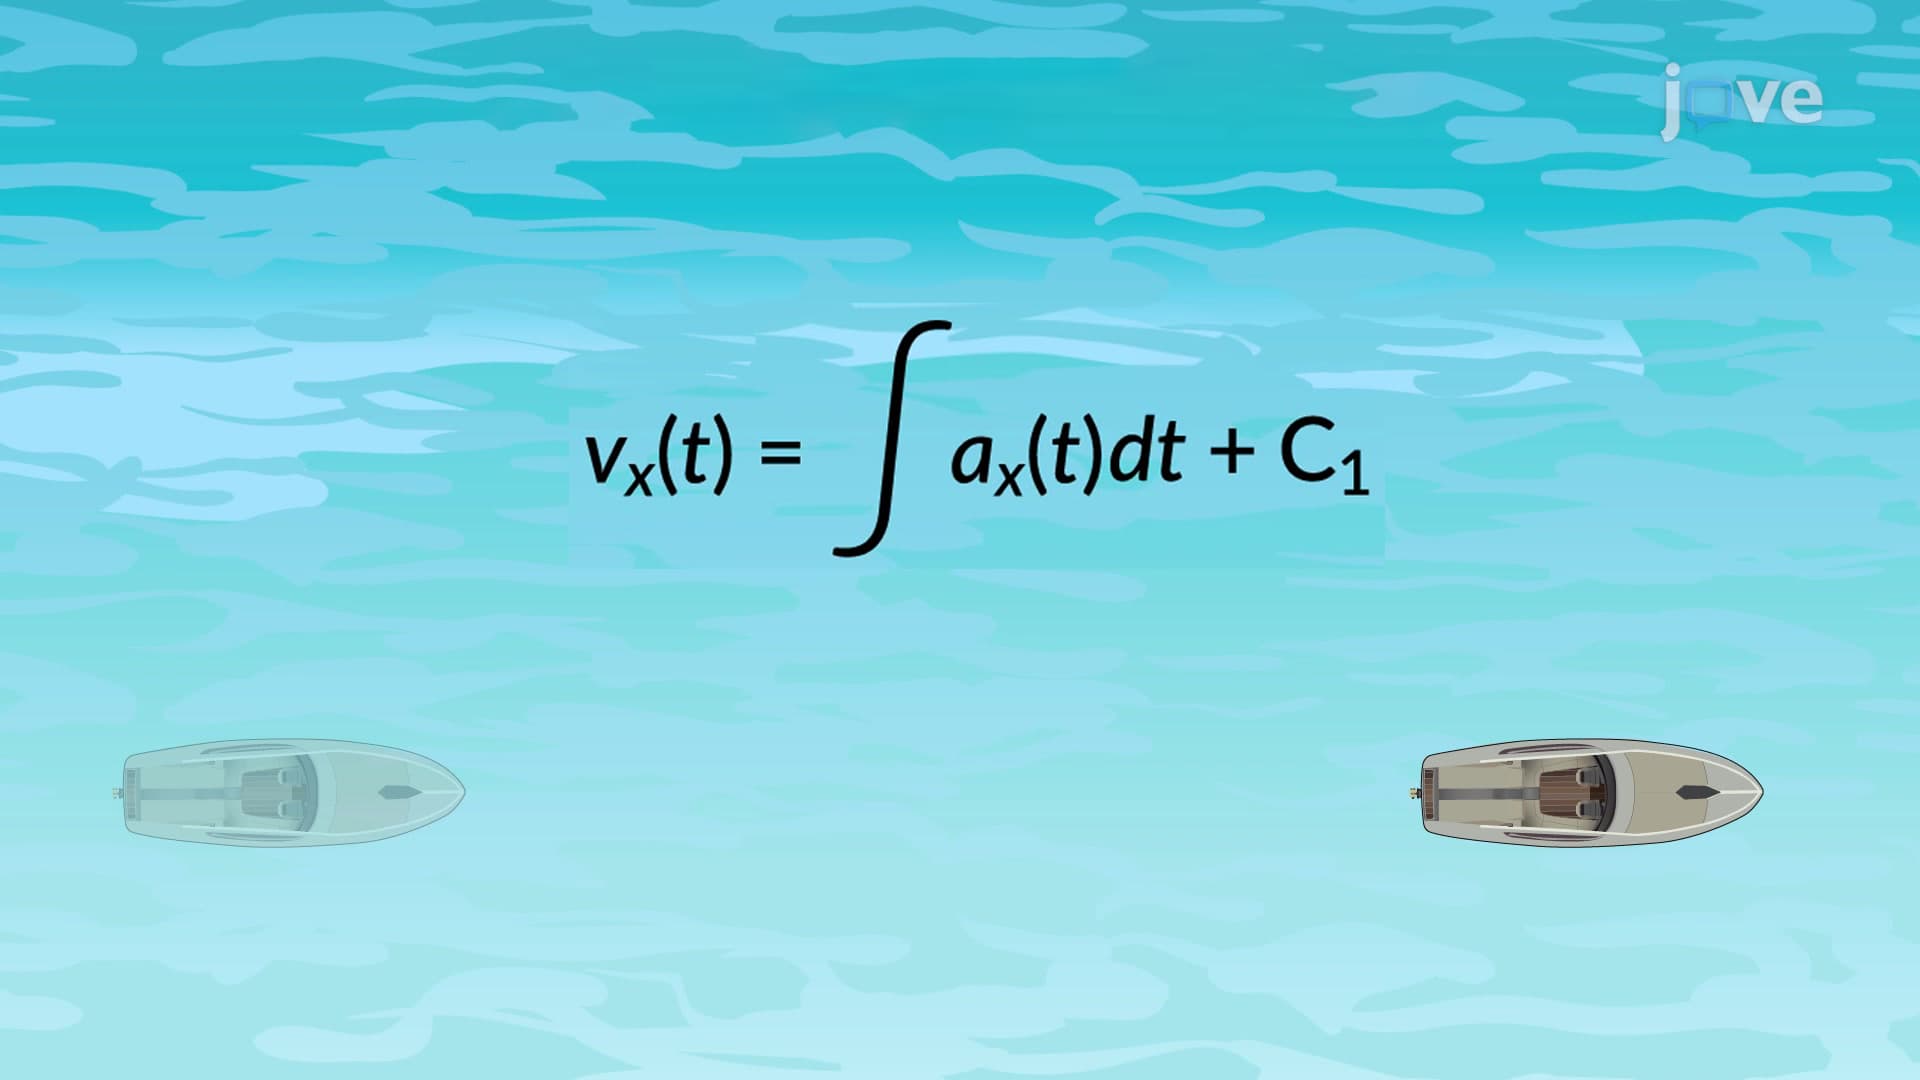 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:34
Velocity and Position by Graphical Method