Related Experiment Video
Updated: Feb 4, 2026

Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Hybrid Soft-Rigid Actuators for Minimally Invasive Surgery
Linda Paternò1, Giuseppe Tortora1, Arianna Menciassi1
1The BioRobotics Institute, Scuola Superiore Sant'Anna, Pontedera (PI), Italy .

Abstract:
Fluidic mechanisms have stimulated research and development in minimally invasive surgery instrumentations, because of their good performance in limited size and their force/torque generation with respect to other types of actuation systems. Fluidic solutions can be divided in two major classes: (i) elastic fluidic actuators and (ii) piston-cylinder actuators. Elastic fluidic actuators generate lower forces with smaller displacements; nevertheless, piston-cylinder solutions require seals, which can generate friction and require maintenance costs for a good reliability. The proposed solution is based on a hybrid soft-rigid actuation, which aims to overcome the limitations of both previous solutions while preserving the main advantages of the overall fluidic approach. This approach results in very compact, powerful, and low-cost actuators, which are highly customizable and adaptable to specific constraints, in medical applications but even beyond. This article proposes a novel design of hybrid soft-rigid actuators to be used as basic mechanical joints for enabling pitch and roll degrees of freedom for a miniature robotic arm. Forces up to 1.4 N and up to 2.77 N have been obtained for the above joints, respectively, and even better performance can be reached (up to 3 N) with further improvements, as demonstrated in this article.
Related Concept Videos
 02:29
Hybrid Zones
 00:49
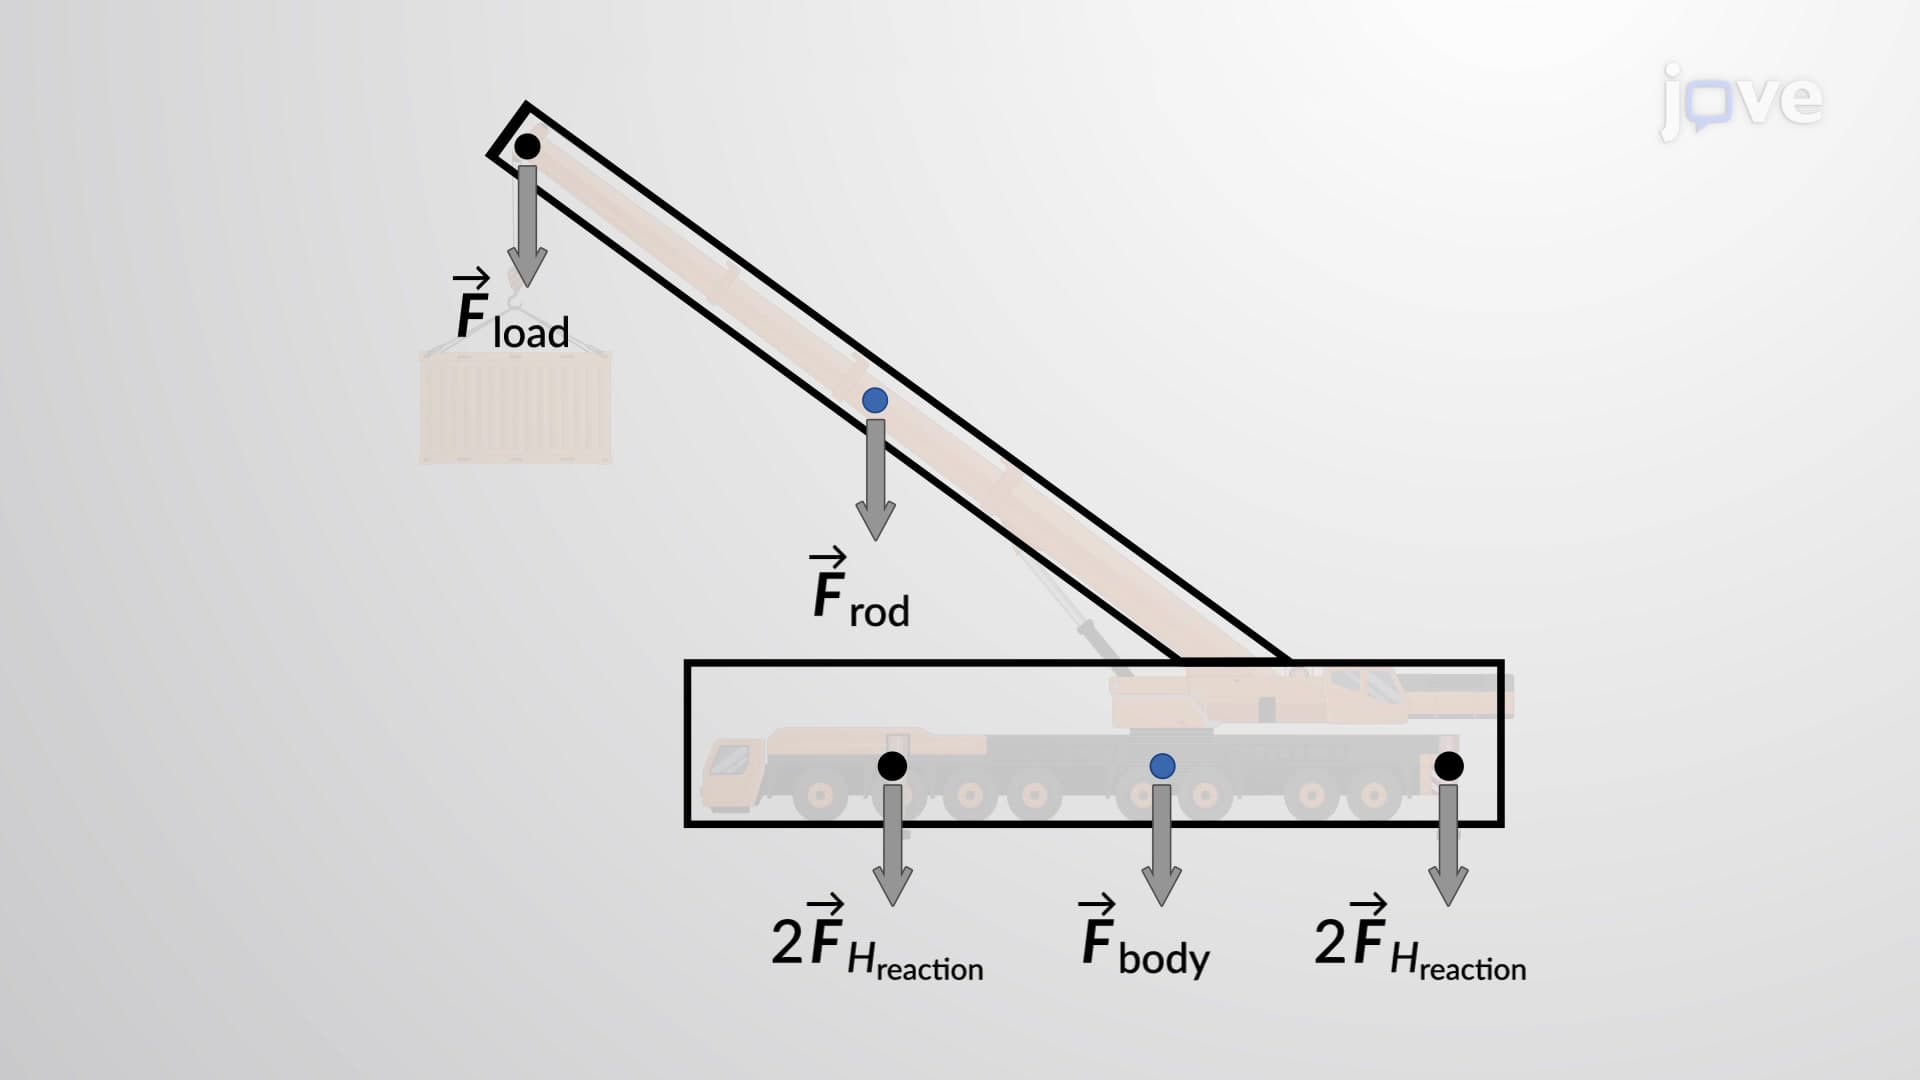
Rigid Body Equilibrium Problems - I
 03:24
Hybridization of Atomic Orbitals I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 03:35
Hybridization of Atomic Orbitals II
 01:11
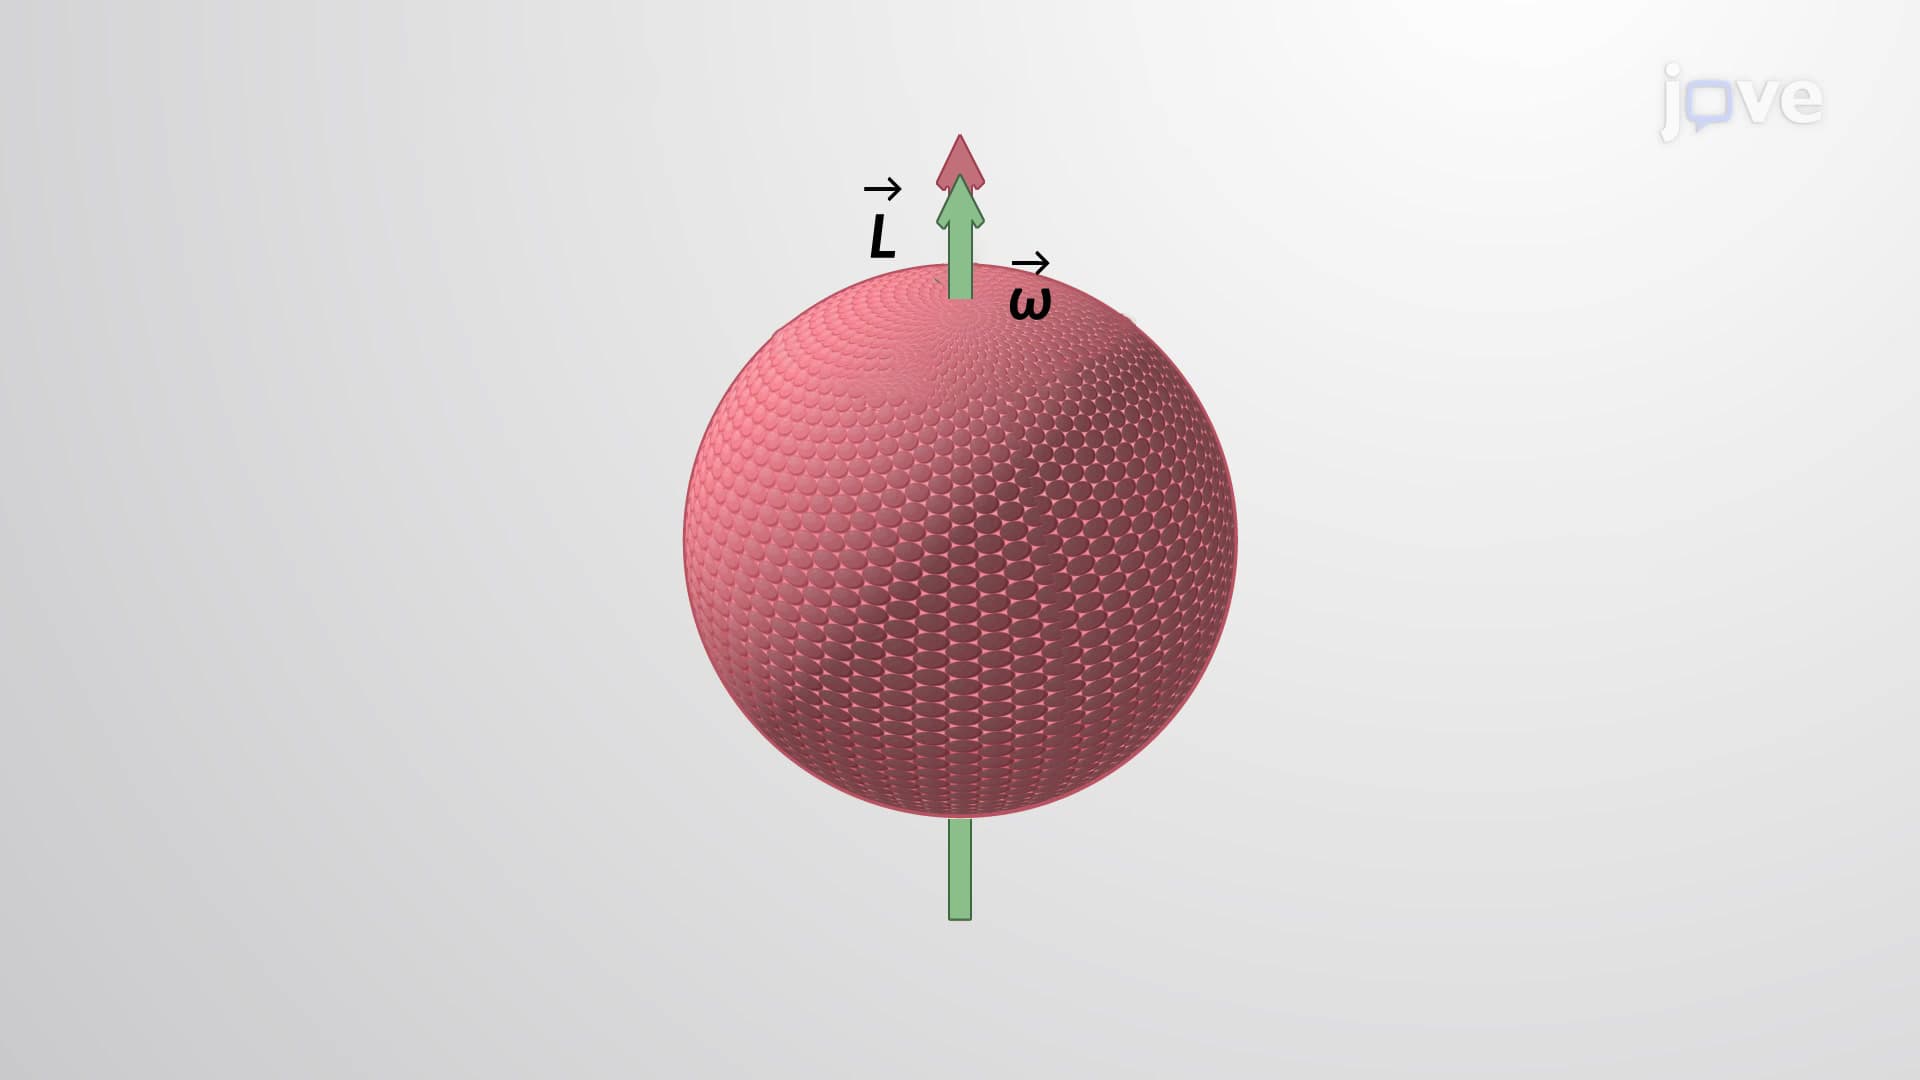
Angular Momentum: Rigid Body
This calculation can get complicated when tiny particles within the rigid body are not rotating in the same plane but have...