Related Experiment Video
Updated: Feb 4, 2026
A Conflict Model of Reward-seeking Behavior in Male Rats
Published on: February 20, 2019
Full Bayesian conflict-based models for real time safety evaluation of signalized intersections
1Department of Civil Engineering, University of British Columbia, 6250 Applied Science Lane, Vancouver, BC, V6T 1Z4, Canada.

Abstract:
Existing advanced traffic management and emerging connected vehicles (CVs) technology can generate considerable amount of data on vehicle positions and trajectories. This data can be used for real-time safety optimization of intersections. To achieve this, it is essential to first understand how changes in signal control affect safety in real-time. This paper develops conflict-based safety performance functions (SPFs) of signalized intersections at the cycle level using multiple traffic conflict indicators. The developed SPFs relate various dynamic traffic parameters to the number of rear-end conflicts at the signal cycle. The traffic parameters included: queue length, shock wave speed and area, and the platoon ratio. The Time-to-Collision, the Modified-Time-to-Collision, and the Deceleration Rate to Avoid the Crash were used as traffic conflict indicators. Traffic video-data collected from six signalized intersections was used in the analysis. The SPFs were developed using the Full Bayesian approach to address the unobserved heterogeneity and the variation among different sites. Overall, the results showed that all the developed SPFs have good fit with all explanatory variables being statistically significant. Also, the highest conflict frequency was noticed at the beginning of the green time, while the highest conflict severity was noticed at the beginning of the red time. Lastly, the results can be used most beneficially in real-time safety optimization of signalized intersection.

Related Concept Videos
 01:22
Basic Continuous Time Signals
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
 01:16
Basic Discrete Time Signals
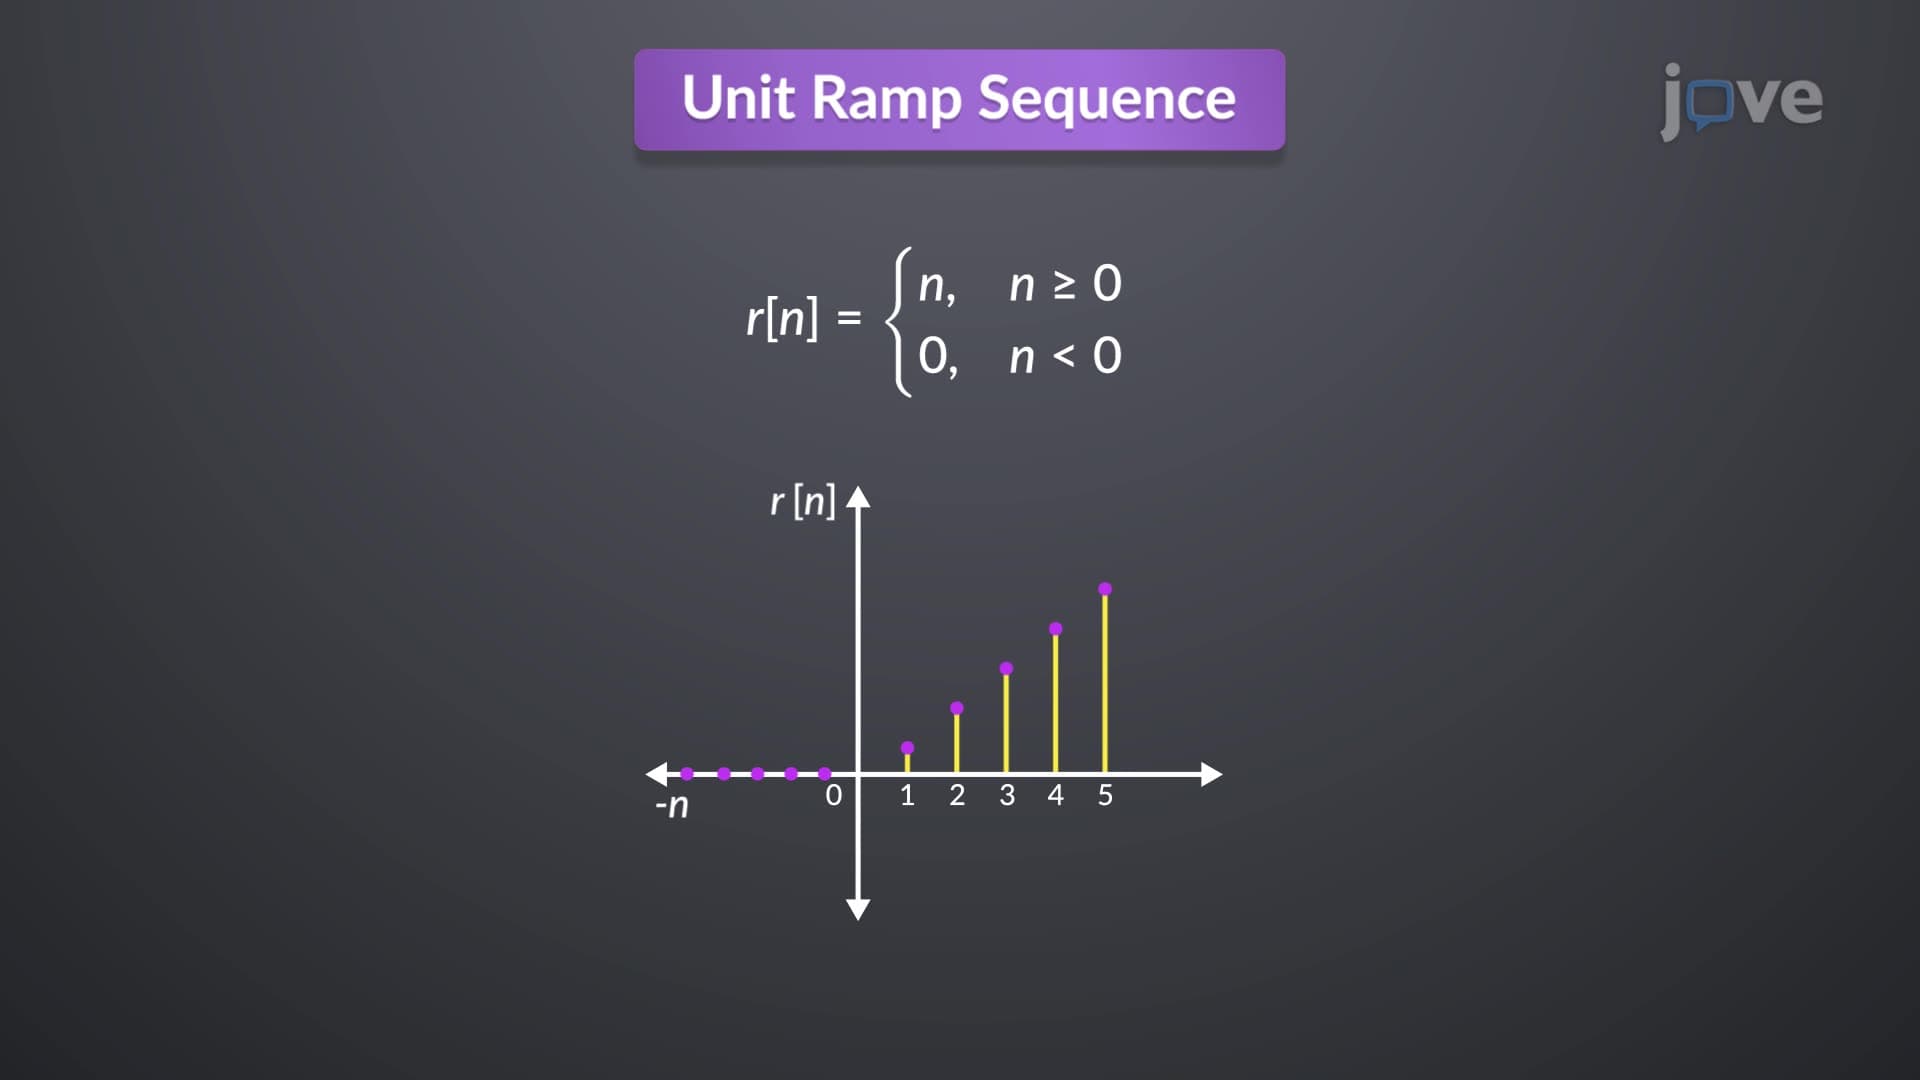
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:11
Sampling Continuous Time Signal
In the...
 02:57
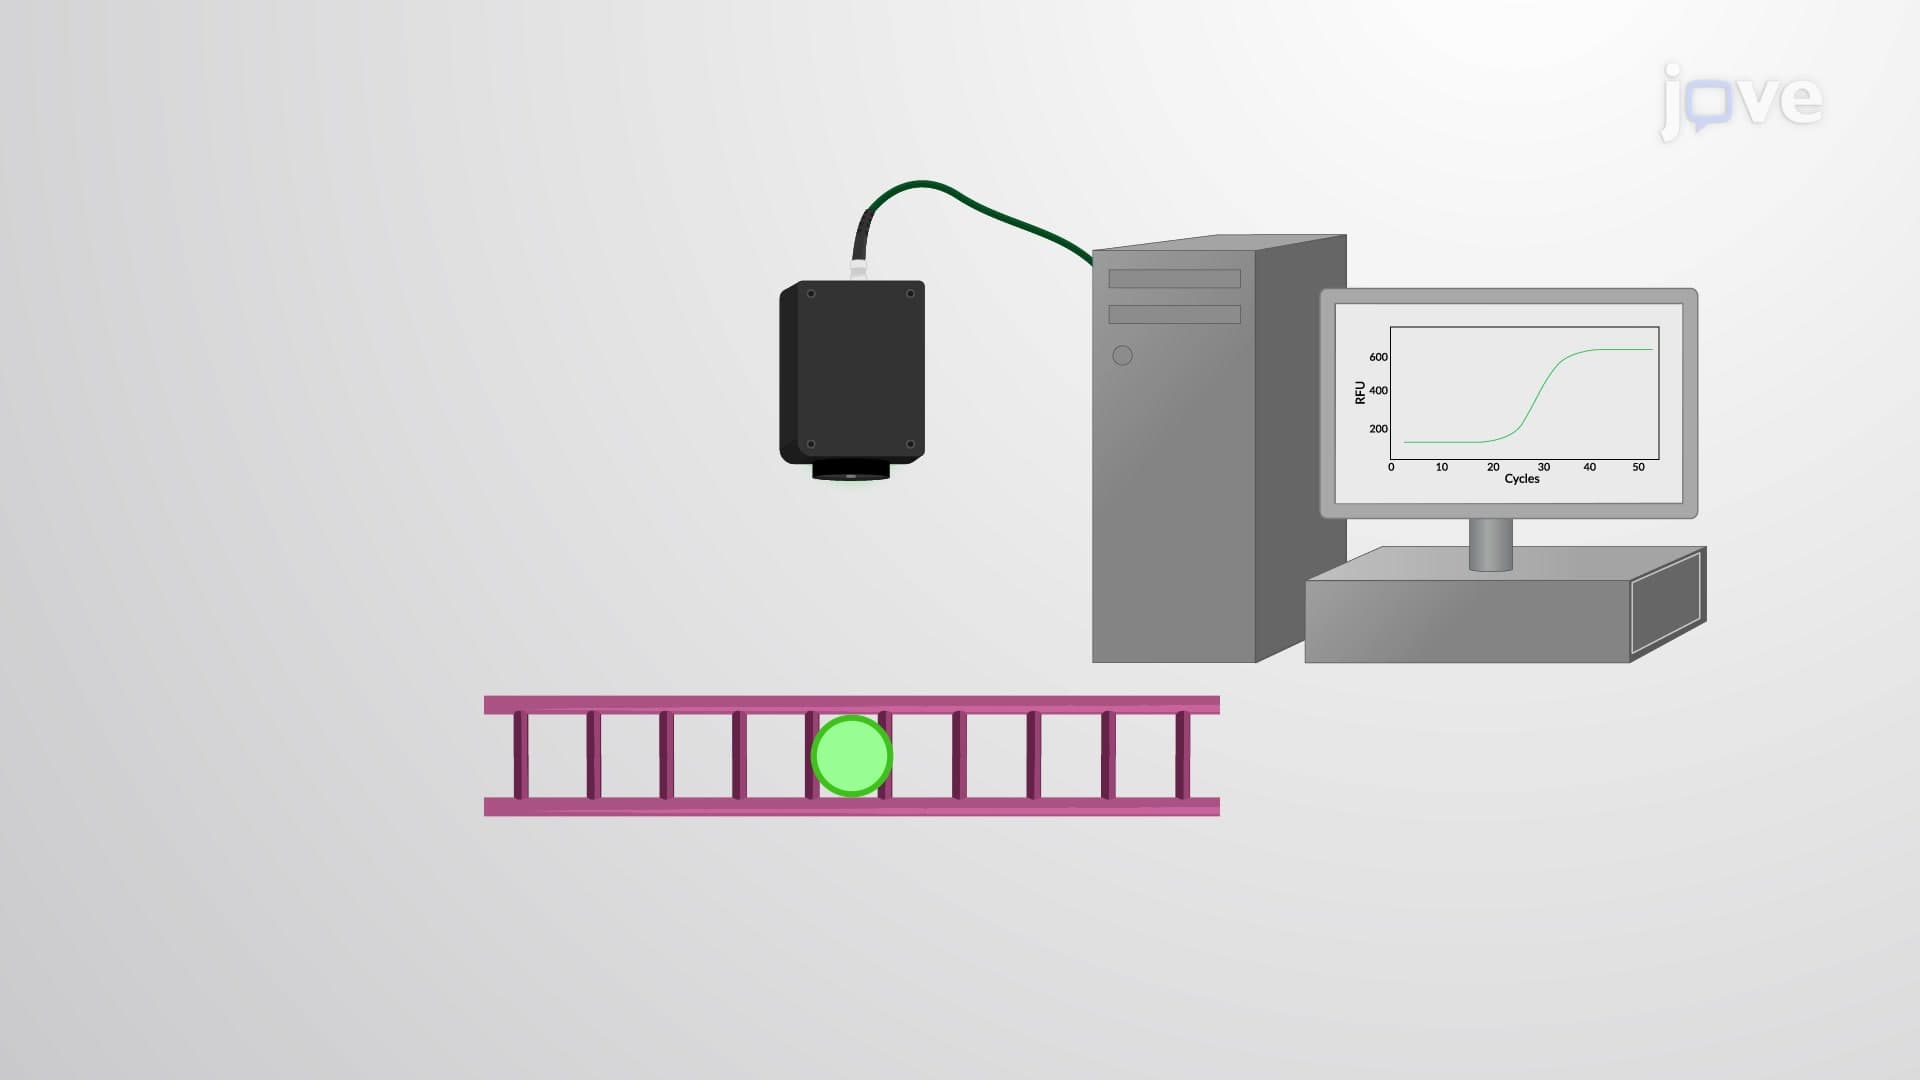
Real Time RT-PCR
The real-time quantification of the number of amplified products is...
 01:28
Survey Safety
 01:18
Small-signal Diode Model