Related Experiment Video
Updated: Feb 4, 2026

Technical Detail for Robot Assisted Pancreaticoduodenectomy
Published on: September 28, 2019
Robotically Assisted CBCT-Guided Needle Insertions: Preliminary Results in a Phantom Model
Antoine Pfeil1, Roberto Luigi Cazzato2, Laurent Barbé3
1ICube Laboratory, University of Strasbourg, CNRS, INSA Strasbourg, 1, place de l'Hôpital, 67091, Strasbourg Cedex, France. a.pfeil@unistra.fr.

Aim:
To compare robotic-assisted needle insertions performed under CBCT guidance to standard manual needle insertions.
Materials And Methods:
A homemade robotic prototype was used by two operators to perform robotic and manual needle insertions on a custom-made phantom. Both the operators had no experience with the prototype before starting the trial. The primary endpoint was accuracy (i.e., the minimal distance between the needle tip and the center of the target) between robotic and manual insertions. Secondary endpoints included total procedure time and operators' radiation exposure. The Wilcoxon test was used. A p value less than 0.05 was considered statistically significant.
Results:
Thirty-three (17 manual, 16 robotic) needle insertions were performed. Mean accuracy for robotic insertion was 2.3 ± 0.9 mm (median 2.1; range 0.8-4.2) versus 2.3 ± 1 mm (median 2.1; range 0.7-4.4) for manual insertion (p = 0.84). Mean procedure time was 683 ± 57 s (median 670; range 611-849) for the robotic group versus 552 ± 40 s (median 548; range 486-621) for the manual group (p = 0.0002). Mean radiation exposure was 3.25 times less for the robotic insertion on comparison to manual insertion for the operator 1 (0.4 vs 1.3 µGy); and 4.15 times less for the operator 2 (1.9 vs 7.9 µGy).
Conclusion:
The tested robotic prototype showed accuracy comparable to that achieved with manual punctures coupled to a significant reduction of operators' radiation exposure. Further, in vivo studies are necessary to confirm the efficiency of the system.

Related Concept Videos
 01:12
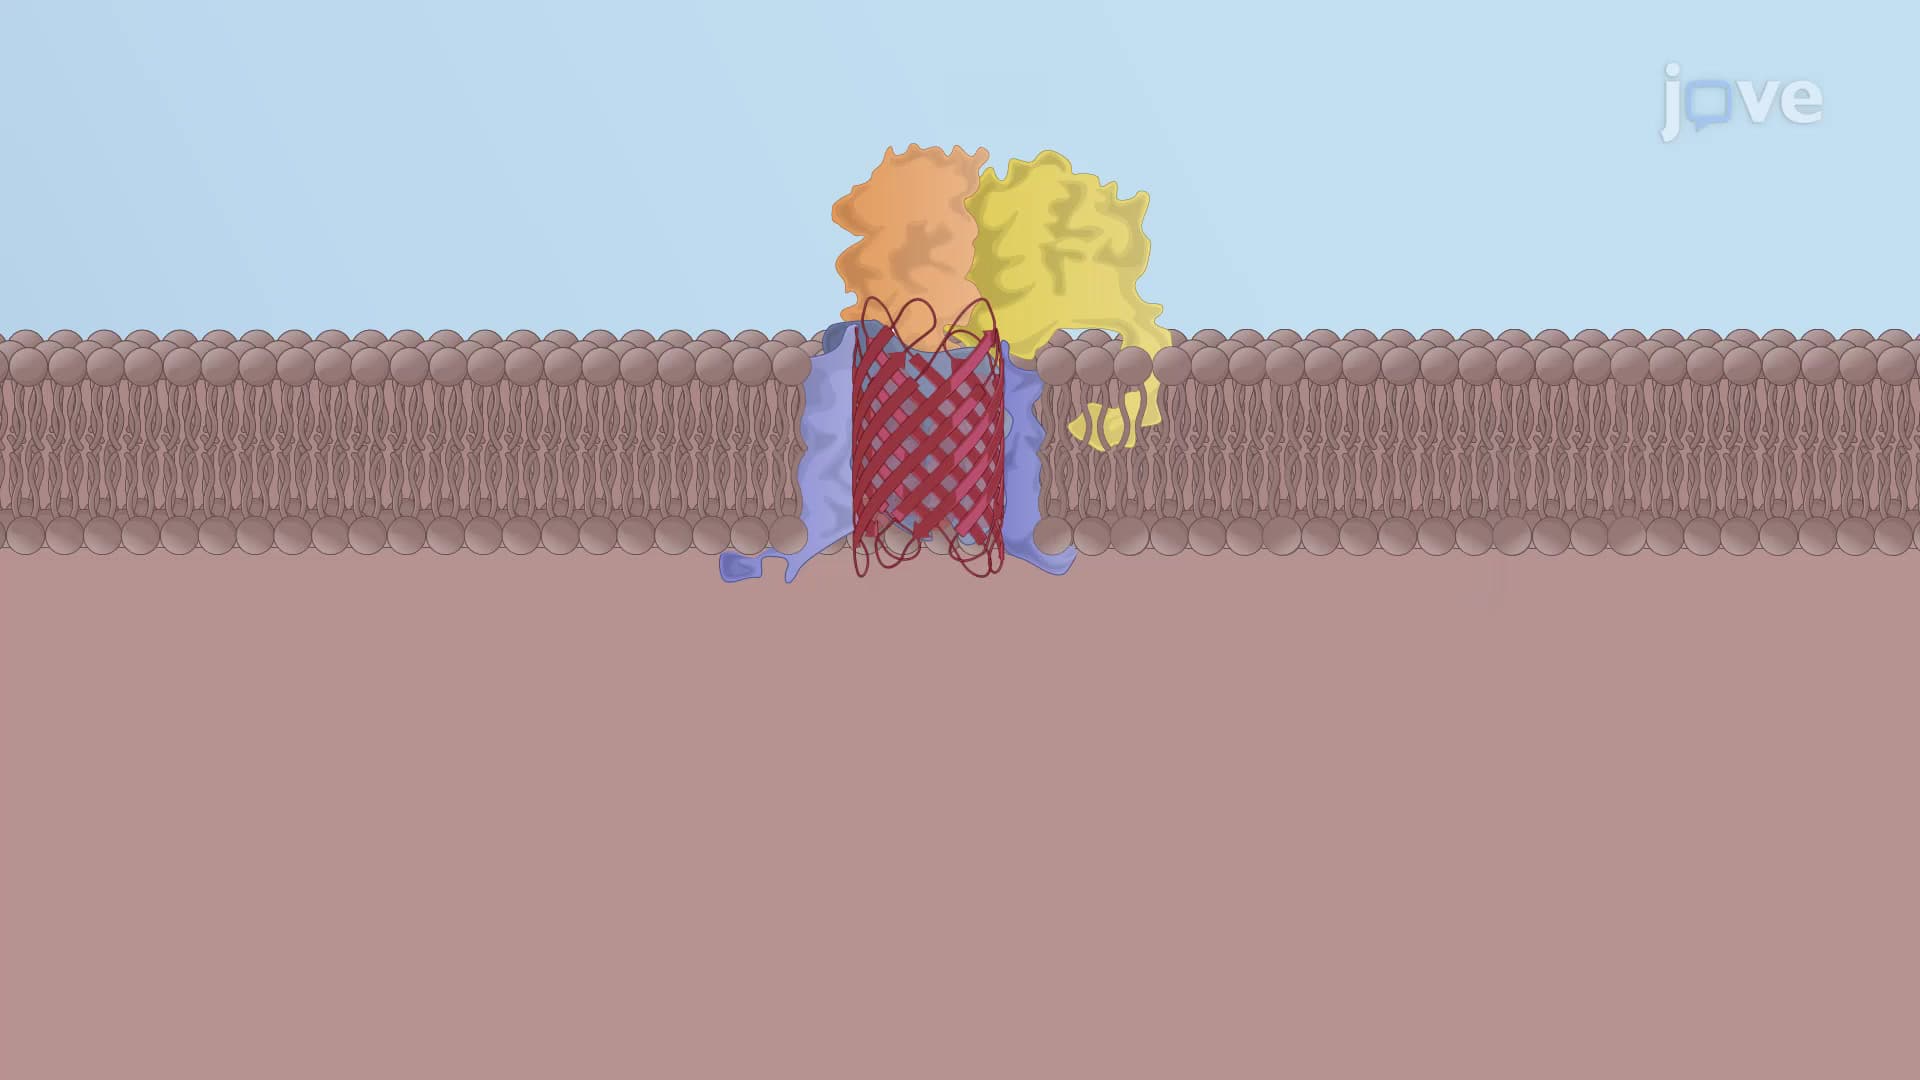
Porin Insertion in the Outer Mitochondrial Membrane
Three models describe the assembly of porins by the SAM complex and their insertion into the outer membrane. Model 1 suggests that porins are assembled outside the SAM channel as the...
 01:26
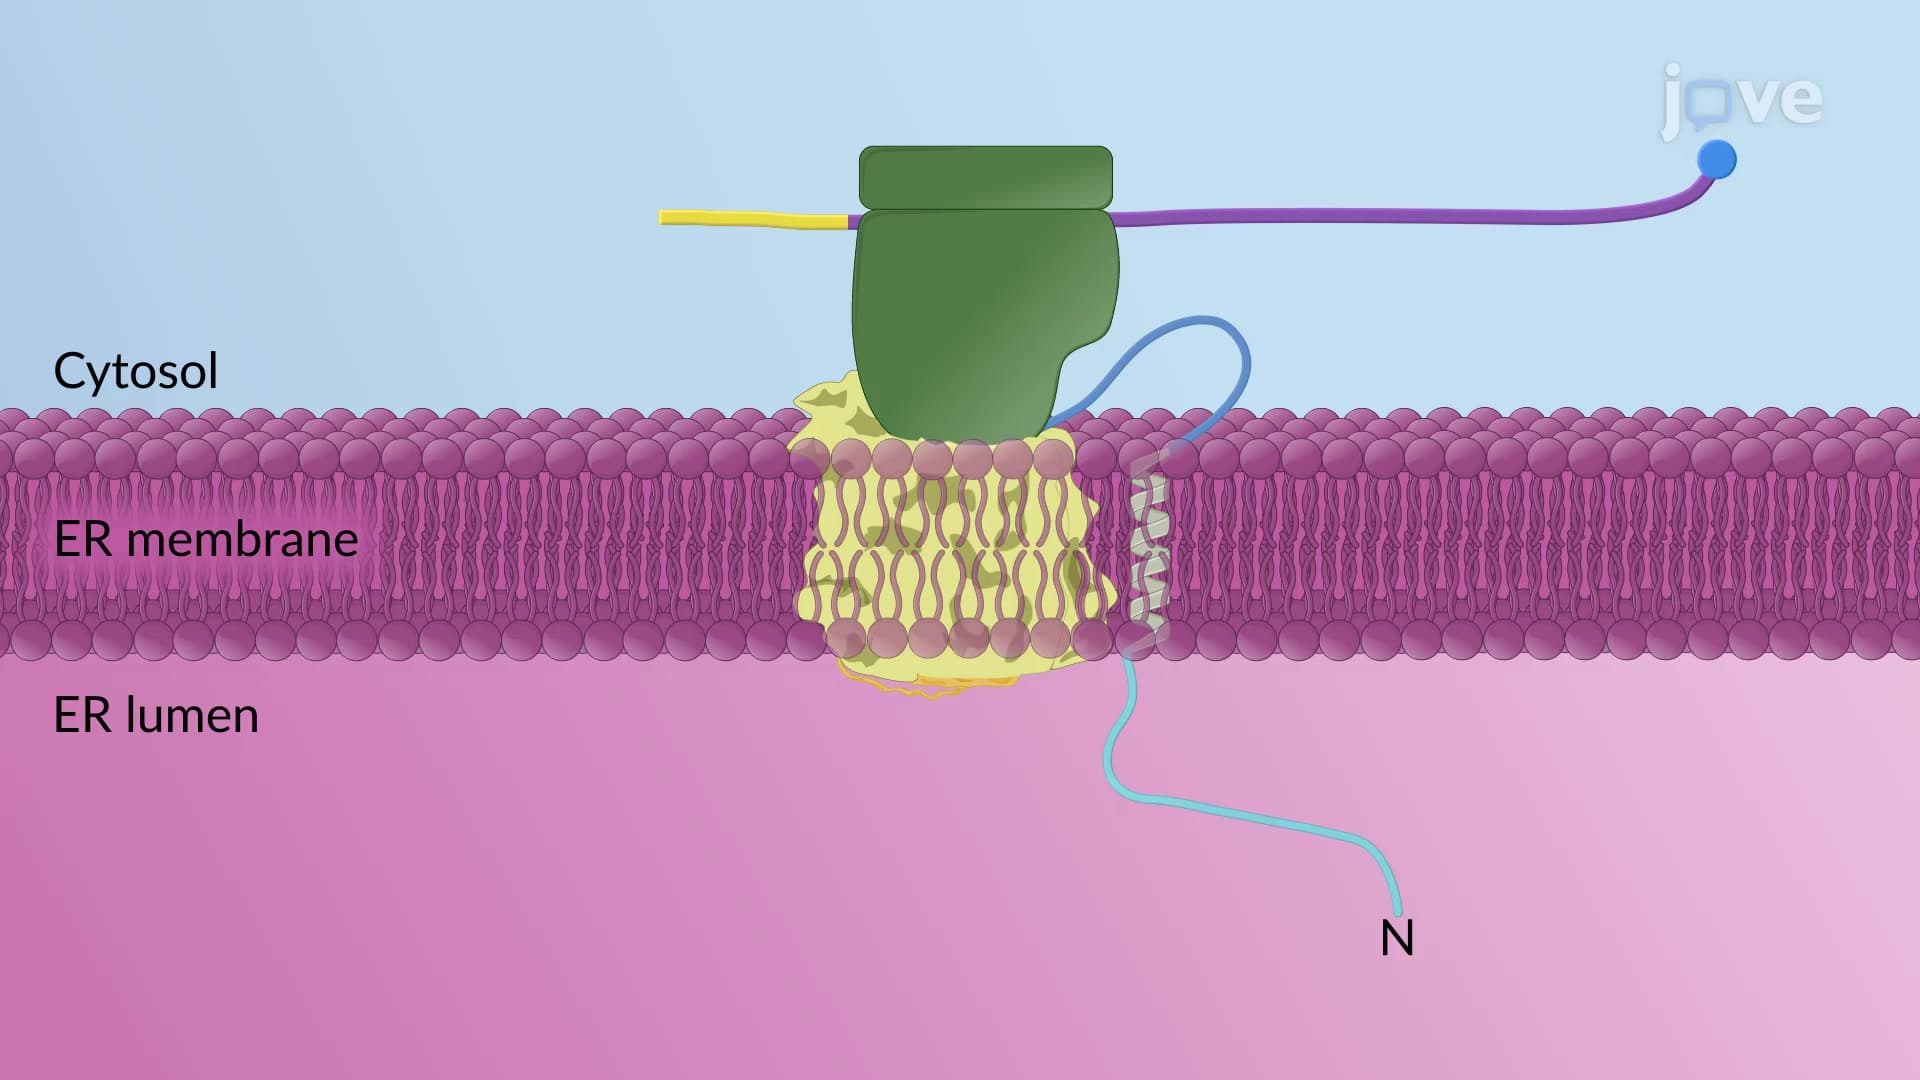
Insertion of Single-pass Transmembrane Proteins in the RER
Integral transmembrane proteins possess transmembrane and extra membrane domains. The transmembrane domains are primarily made of 20-25 hydrophobic amino acids arranged in a helical secondary confirmation. These...
 01:29
Insertion of Multi-pass Transmembrane Proteins in the RER
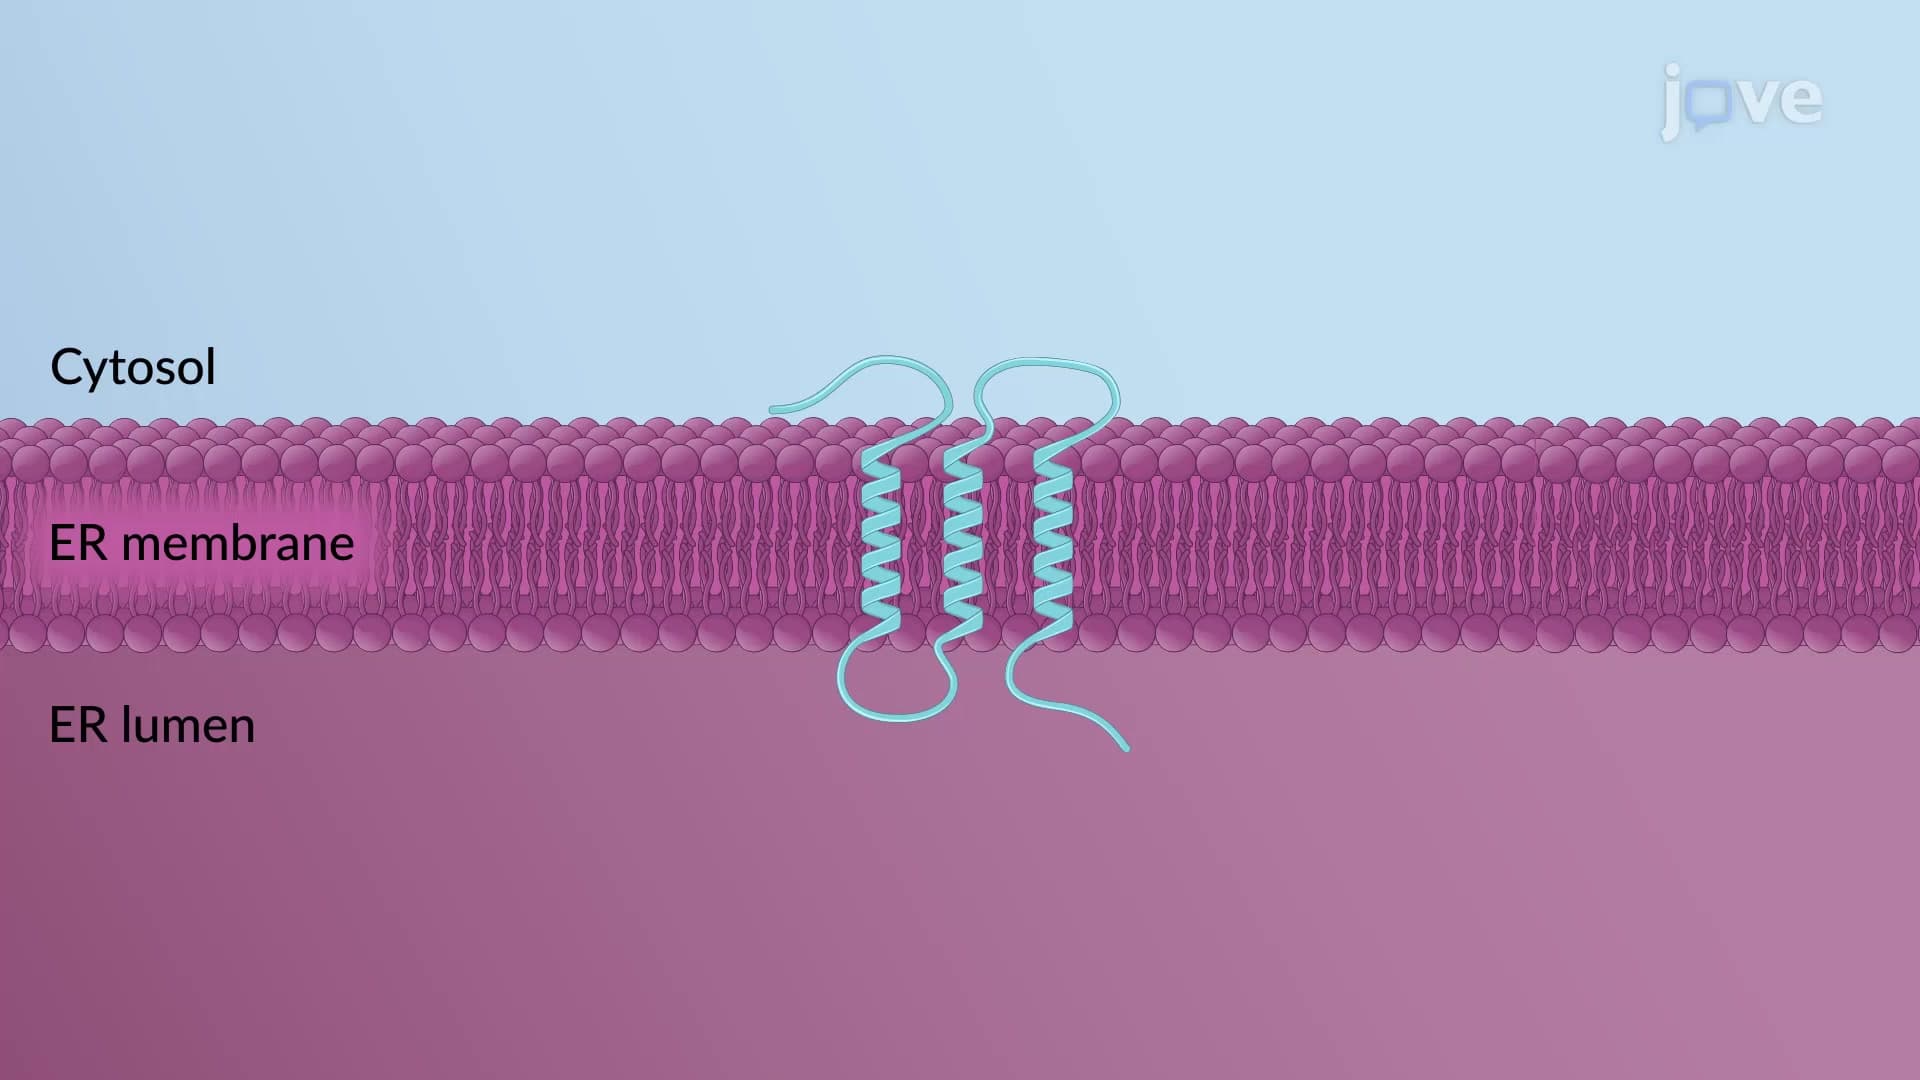
The multipass transmembrane proteins are the type IV integral membrane proteins with multiple topogenic sequences determining their spatial arrangement in the ER membrane. Nearly all multipass proteins lack a cleavable signal sequence and use...
 01:08
Matrix-Assisted Laser Desorption Ionization (MALDI)
 02:00
Molecular Models
 02:18
The Bohr Model