An improved force-based impedance control method for the HDU of legged robots
Related Experiment Video
Updated: Feb 4, 2026

Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Kaixian Ba1, Bin Yu2, Zhengjie Gao1
1School of Mechanical Engineering, Yanshan University, Qinhuangdao 066004, China.

Abstract:
Hydraulic drive mode enables legged robots to have excellent characteristics, such as greater power-to-weight ratios, higher load capacities, and faster response speeds than other robots. Nowadays, highly integrated valve-controlled cylinder, called hydraulic drive unit (HDU), is employed to drive the joints of these robots. However, various robot control issues exist. For example, during the walking process of legged robots, different obstacles are encountered, making it difficult to control such robots because the load characteristics of the ends of their feet change with the environment. Furthermore, although the adoption of HDU has resulted in high-performance robot control, the hydraulic systems of these robots still have problems, such as strong nonlinearity, and time-varying parameters. Consequently, robot control is very difficult and complex. This paper proposes an improved second-order dynamic compliance control system, impedance control, for HDU. The control system is designed to rectify the issues affecting the impedance control accuracy of the dynamic compliance serial-parallel composition between the HDU force control inner loop and the impedance control outer loop. Specifically, it consists of a compliance-enhanced controller and a feedforward compensation controller for the force control inner loop. Furthermore, the dynamic compliance composition of the inner and outer HDU control loops is rearranged. The results of experiments conducted indicate that the proposed method significantly improves the control accuracy compared to that of traditional force-based impedance control.

Related Concept Videos
 01:23
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
 01:22
Birth Control Methods
 01:29
Methods for Controlling Microbial Growth
 01:21
Impedance Combination
 01:28
Biological Methods for Microbial Control
 01:23
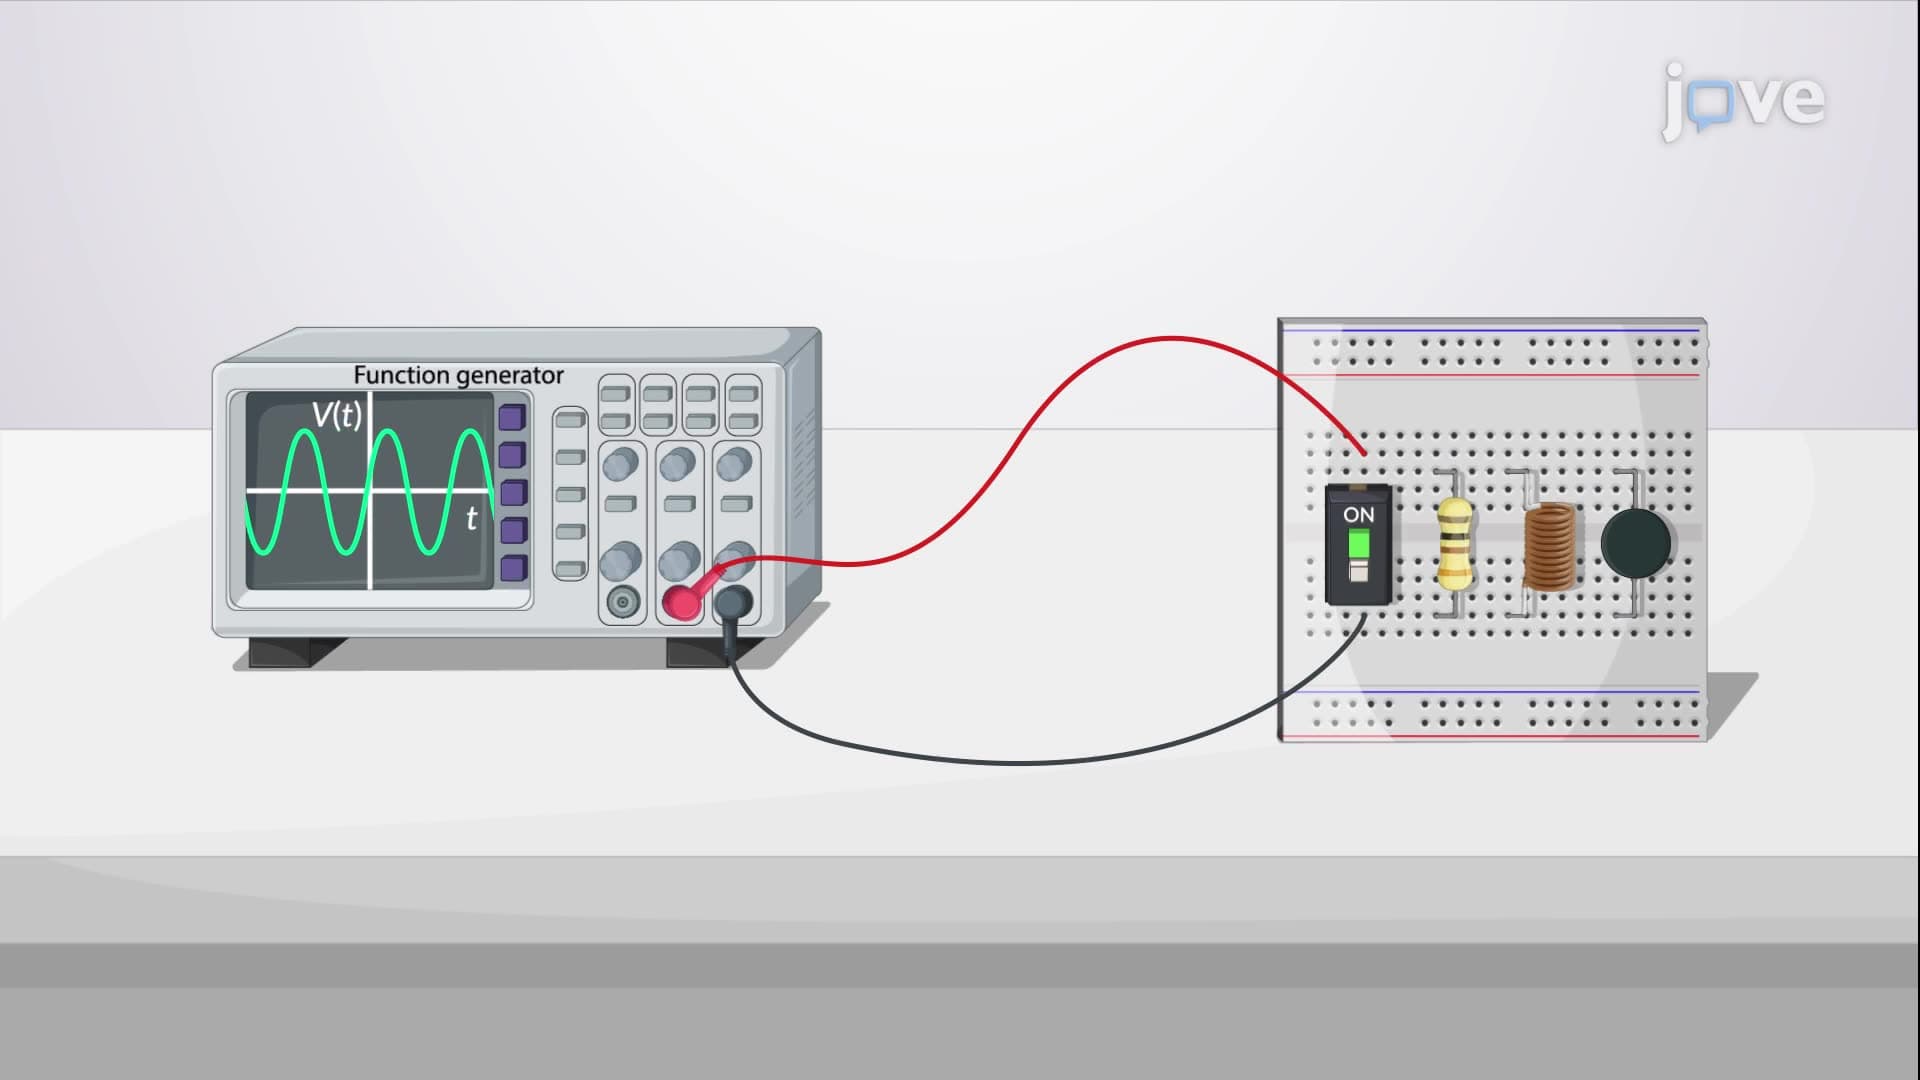
Impedances and Admittance
Impedance is a measure of resistance to sinusoidal current flow in an AC circuit. Unlike their behavior in DC circuits, where inductors appear as short circuits and capacitors as open circuits, the behavior of these components in AC...