Decentralized adaptive neural prescribed performance control for high-order stochastic switched nonlinear interconnected systems with unknown system dynamics
Related Experiment Video
Updated: Feb 4, 2026
Fabrication of Micropatterned Hydrogels for Neural Culture Systems using Dynamic Mask Projection Photolithography
Published on: February 11, 2011
Wenjie Si1, Xunde Dong2, Feifei Yang2
1School of Electrical and Control Engineering, Henan University of Urban Construction, Pingdingshan, 467036, China.

Abstract:
In this paper, the problem of decentralized adaptive neural backstepping control is investigated for high-order stochastic nonlinear systems with unknown interconnected nonlinearity and prescribed performance under arbitrary switchings. For the control of high-order nonlinear interconnected systems, it is assumed that unknown system dynamics and arbitrary switching signals are unknown. First, by utilizing the prescribed performance control (PPC), the prescribed tracking control performance can be ensured, while the requirement for the initial error is removed. Second, at each recursive step, only one adaptive parameter is constructed to overcome the over-parameterization, and RBF neural networks are employed to tackle the difficulties caused by completely unknown system dynamics. At last, based on the common Lyapunov stability method, the decentralized adaptive neural control method is proposed, which decreases the number of learning parameters. It is shown that the designed common controller can ensure that all the signals in the closed-loop system are semi-globally uniformly ultimately bounded (SGUUB), and the prescribed tracking control performance is guaranteed under arbitrary switchings. The simulation results are presented to further illustrate the effectiveness of the proposed control scheme.

Related Concept Videos
 01:10
Control Systems
At the heart...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:18
Neural Control of Respiration
Respiratory Centers in the Brainstem
Two primary areas comprise the respiratory center: the medullary respiratory center in the medulla oblongata and the pontine respiratory group in the pons. The...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
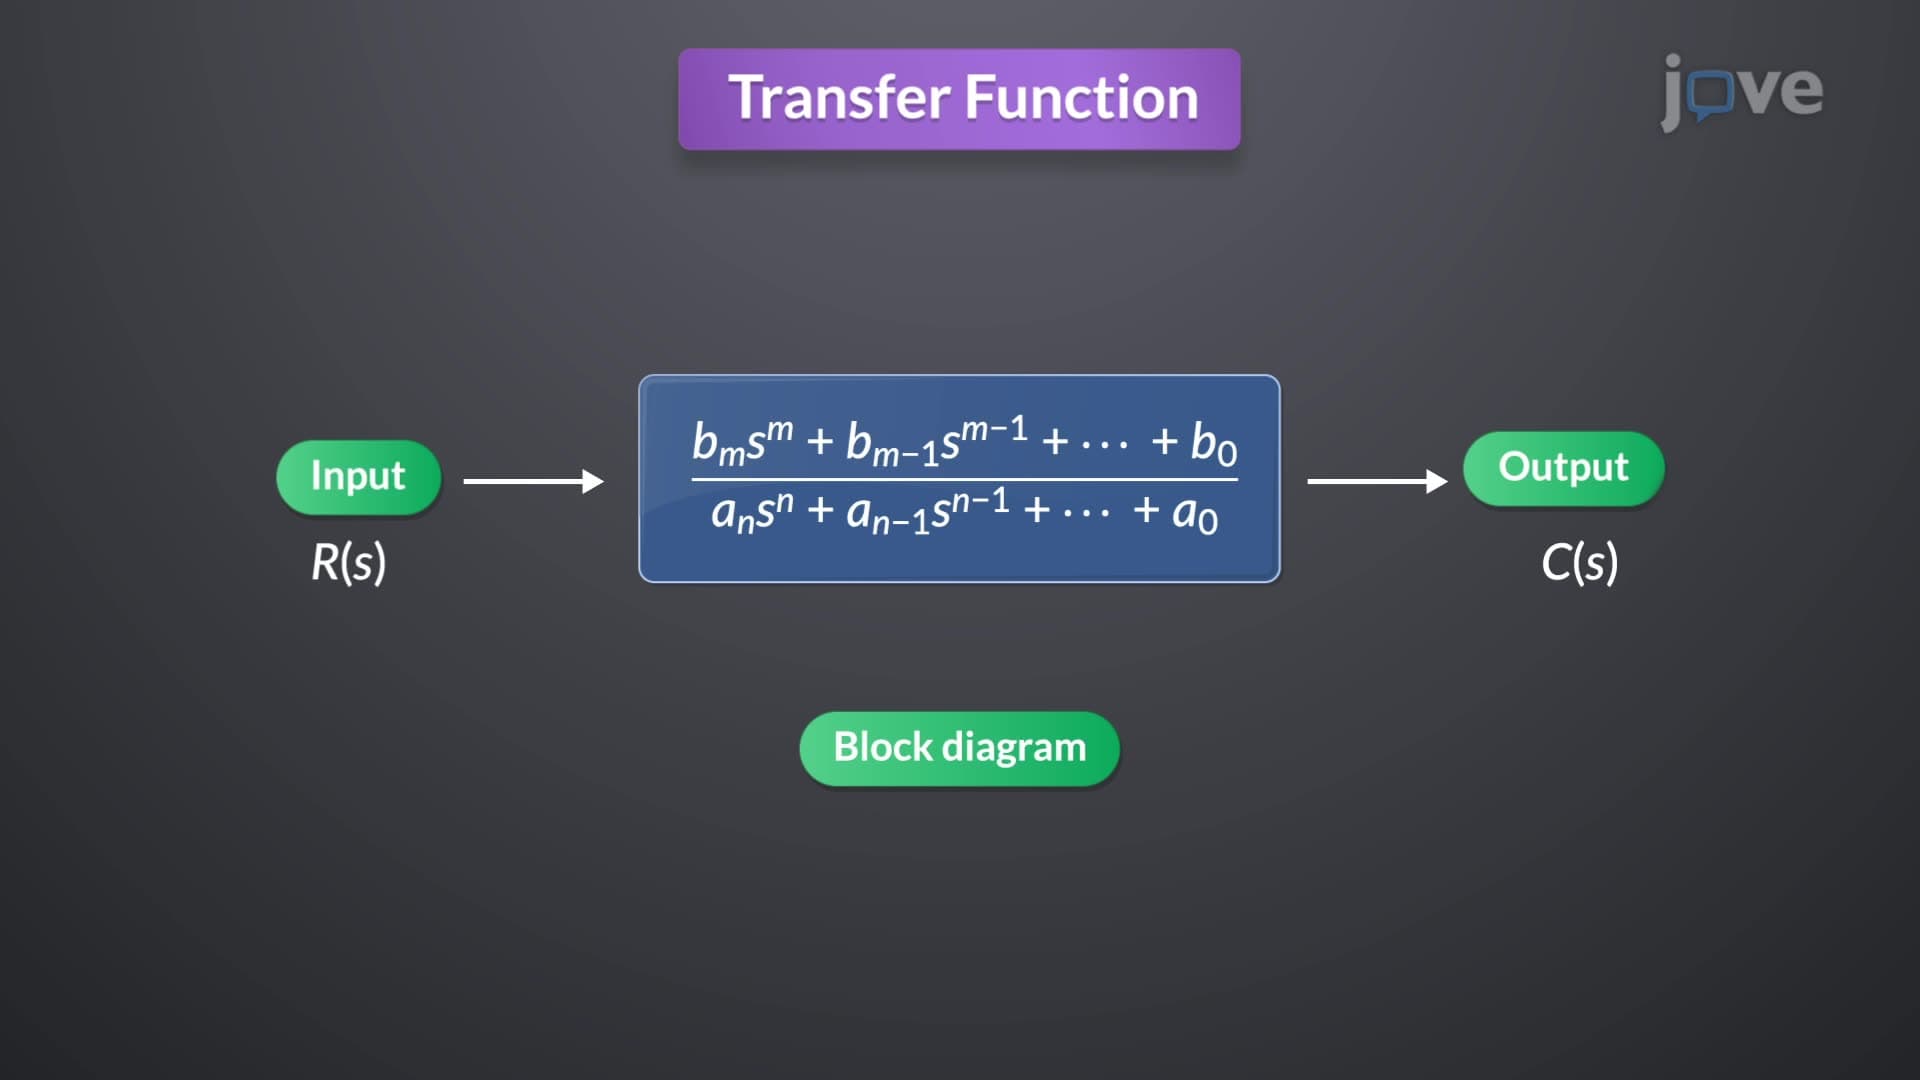
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...