Related Experiment Video
Updated: Feb 3, 2026
3D Kinematic Gait Analysis for Preclinical Studies in Rodents
Published on: August 3, 2019
Clustering of Self-Organizing Maps as a means to support gait kinematics analysis and symmetry evaluation
Rafael Caldas1, Diego Rátiva2, Fernando Buarque de Lima Neto2
1Institute of General Mechanics, RWTH Aachen University, Germany.

Abstract:
Gait analysis is relevant for the functional diagnostic of several musculoskeletal disorders. Walking patterns can be analyzed using techniques such as video processing and inertial measurement units (IMU). In this work, a Self-Organizing Maps (SOM) algorithm is applied to reduce the complexity of kinematic features obtained by IMU sensors of a sample of 40 individuals. Our system provides a simpler data representation (2-D graphic) than conventional methods, which often applies statistical analysis. We have tested the proposed method to analyze typical and simulated limping gait pattern under well-controlled conditions. Based on kinematic parameters and symmetry-related features, SOM algorithm was able to organize the sample in groups of subjects with three different gait patterns, normal and limping with each lower limb. Moreover, our system may be used to evaluate the recovery of a patient, offering intuitive information of his walking pattern in an assessment report. However, further research with atypical-gait subjects is necessary before applying such method as a clinical tool.
More Related Videos
Related Concept Videos
 01:26
Symmetry
 01:27
Gauss's Law: Planar Symmetry
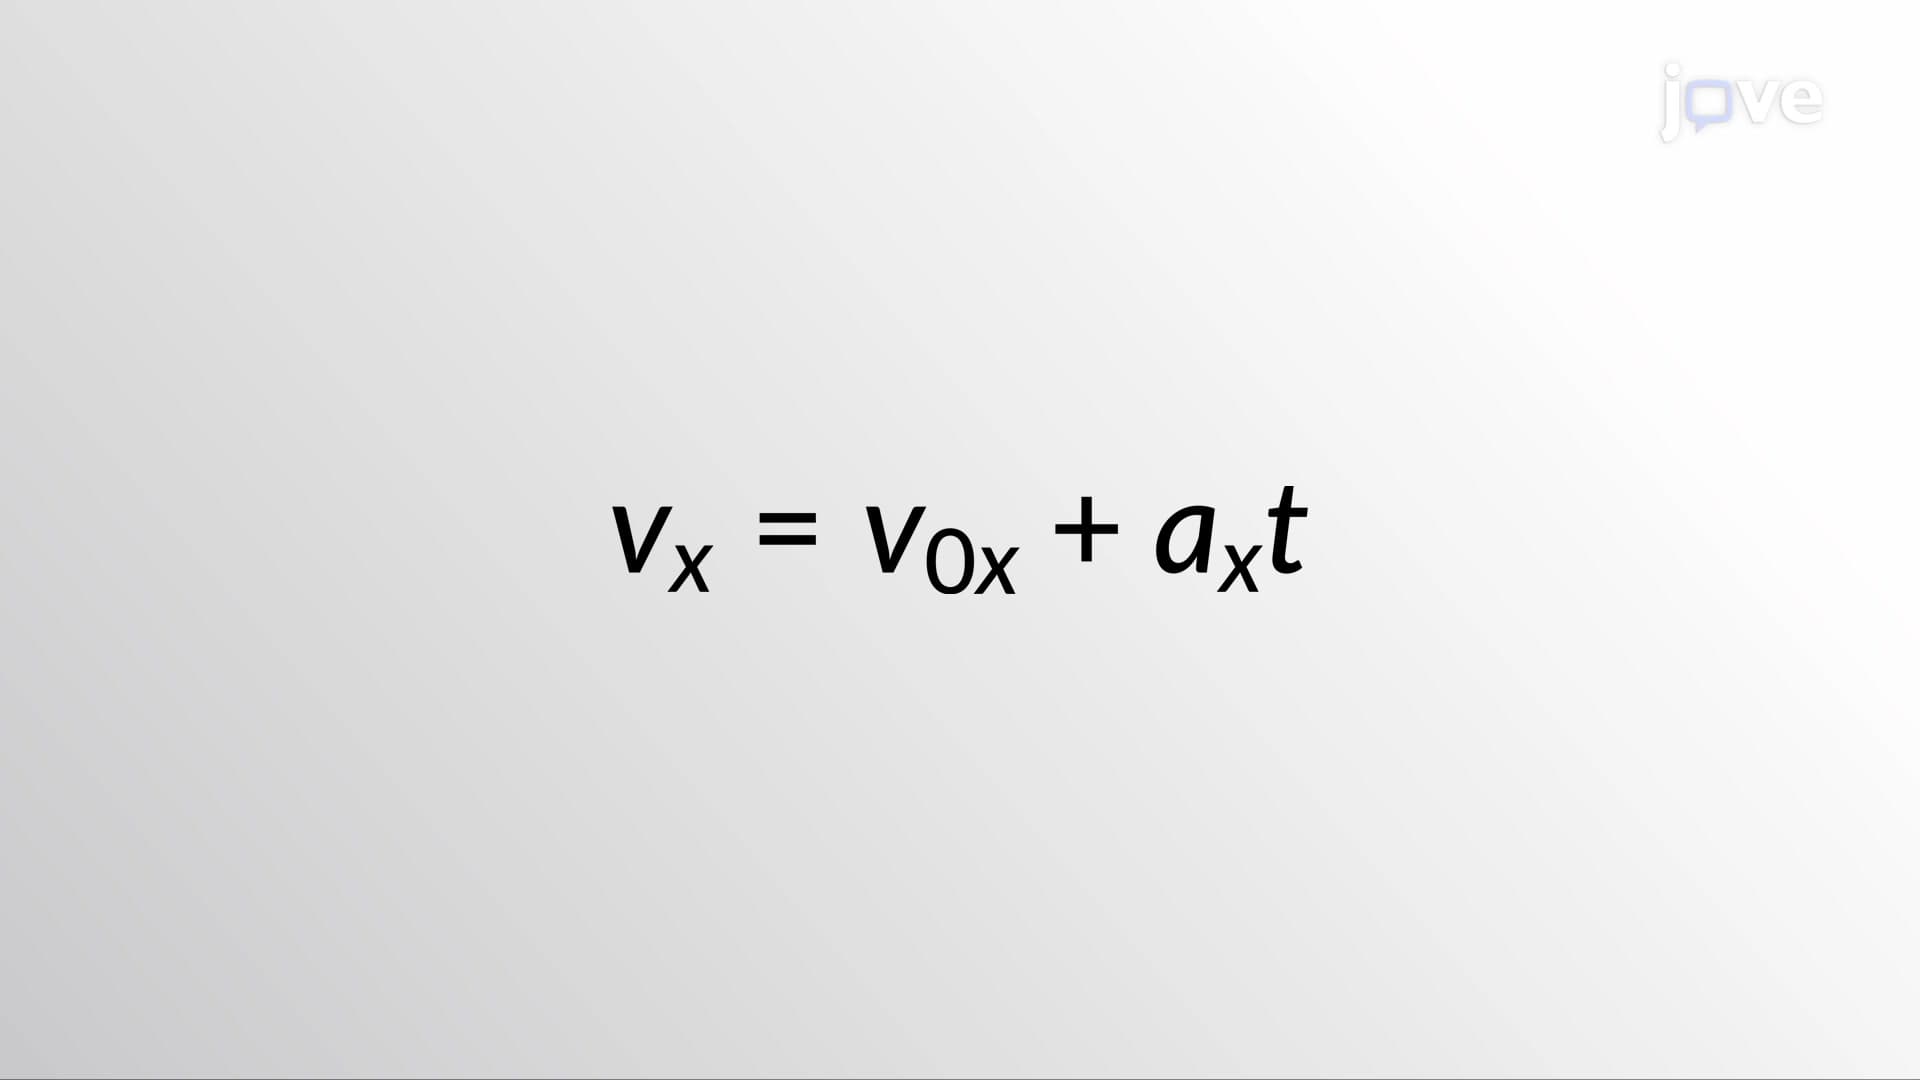 01:26
Kinematic Equations - I
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:28
Self-Help Support Groups
Accessibility and Cost-Effectiveness
One of the primary strengths of self-help...
 01:28
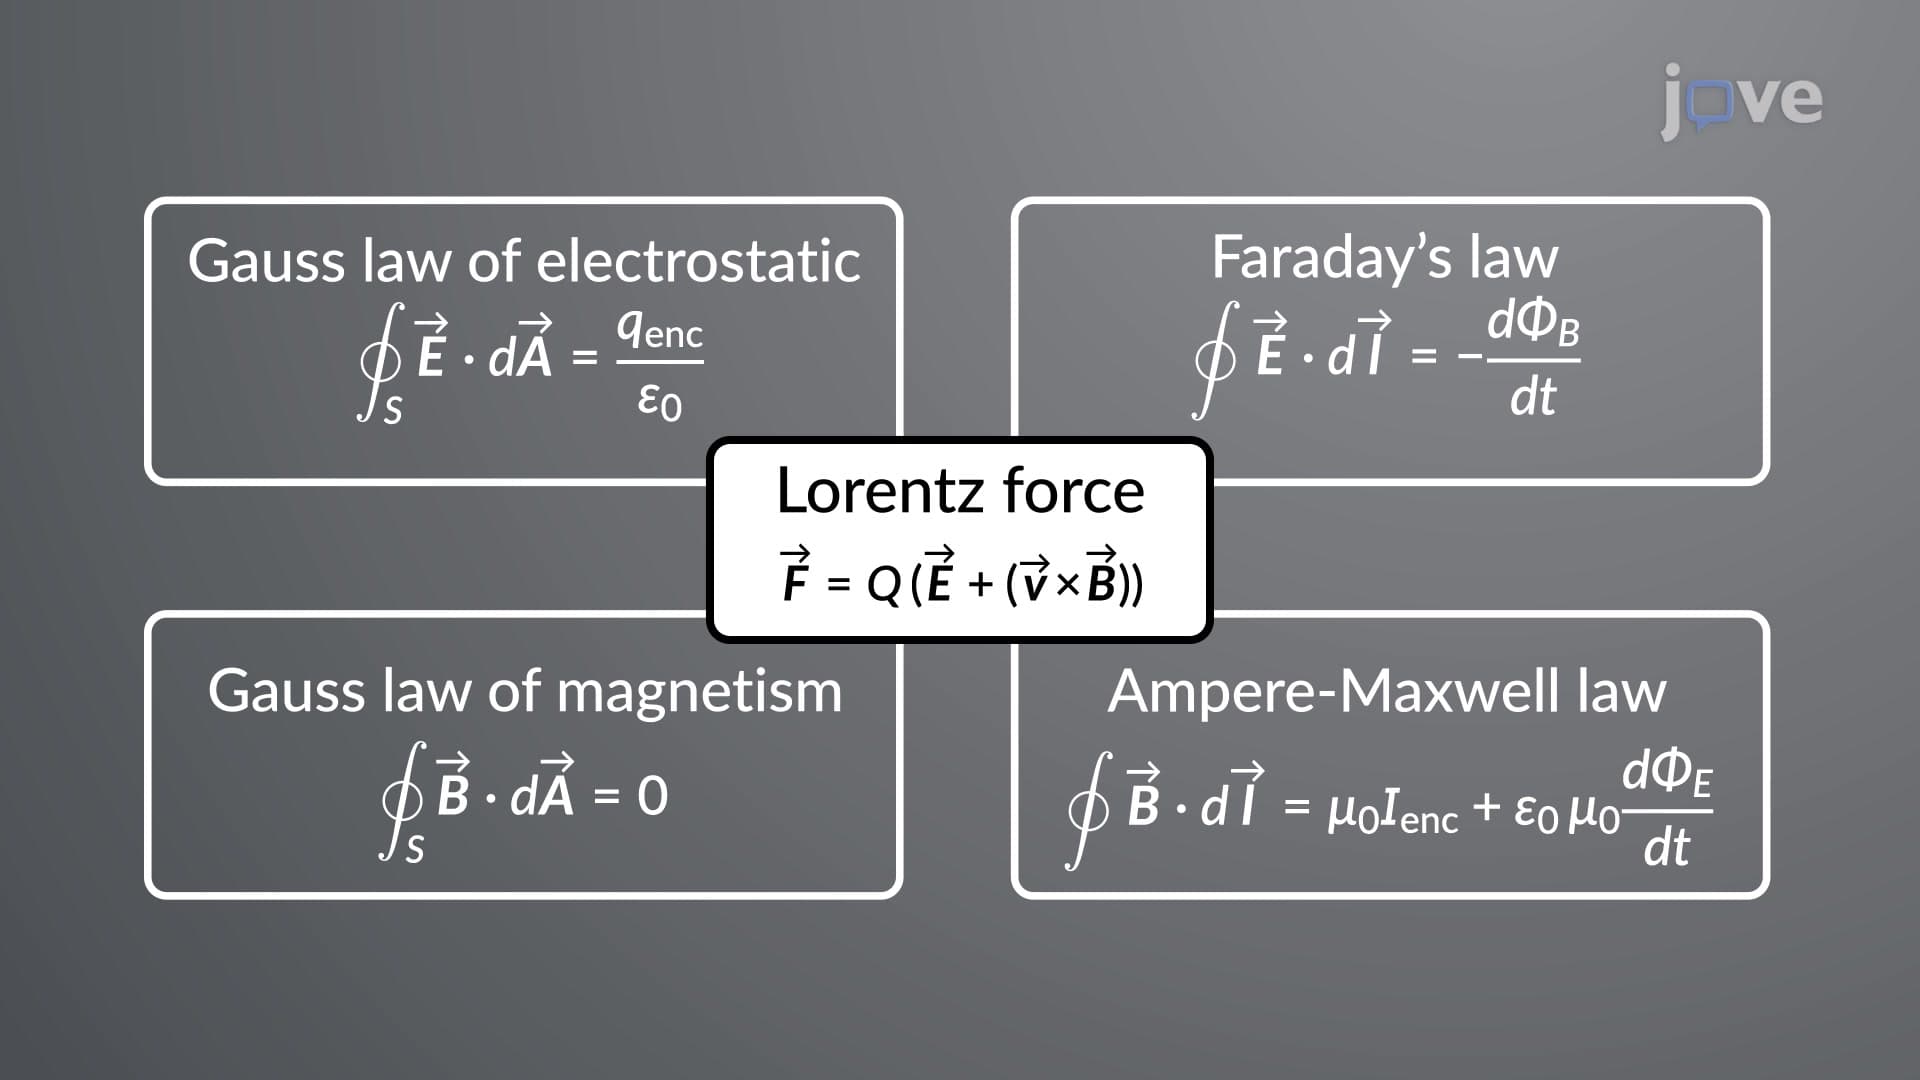
Symmetry in Maxwell's Equations