Related Experiment Video
Updated: Feb 3, 2026

Quantifying Yersinia pseudotuberculosis Type III Secretion System Activity Following Iron Starvation and Anaerobic Growth
Published on: May 31, 2024
Systemic Yersinia pseudotuberculosis as a Cause of Osteomyelitis in a Captive Ring-tailed Lemur (Lemur catta)
D Walker1, J Gibbons2, J D Harris1
1Royal (Dick) School of Veterinary Studies, The Roslin Institute, University of Edinburgh, Easter Bush, Edinburgh, UK.

Abstract:
Yersinia pseudotuberculosis and Yersinia enterocolitica are ubiquitous pathogens with wildlife and domestic animal reservoirs. Outbreaks of 'non-plague' yersiniosis in man and non-human primates are reported frequently (including zoological specimens and research breeding colonies) and are usually characterized by enteritis, mesenteric lymphadenitis and occasionally organ abscessation. In people, non-septic reactive arthritis is a common sequela to yersiniosis. However, there have been rare reports in people of septic arthritis and osteomyelitis because of active systemic infection with Y. pseudotuberculosis. Osteomyelitis has also been reported rarely in historical yersiniosis outbreaks in farmed turkeys in England and the USA. This paper reports the first case of osteomyelitis caused by systemic infection with Y. pseudotuberculosis O:1 in a non-human primate, a captive ring-tailed lemur (Lemur catta). The lemur had a short clinical history of hyporexia and weight loss with reduction in mobility, especially of the left hindlimb. On post-mortem examination there was evidence of multi-organ abscessation. In addition, severe necrosis, inflammation and large bacterial colonies were present in the musculature, periosteum and bone marrow in the hip, ribs and a vertebra at the cervicothoracic junction. Osteomyelitis should be considered as a rare clinical presentation in non-human primates with systemic Y. pseudotuberculosis infection.
Related Concept Videos
 01:18
Second Order systems II
 01:45
Tail-anchoring of Proteins in the ER Membrane
 01:21
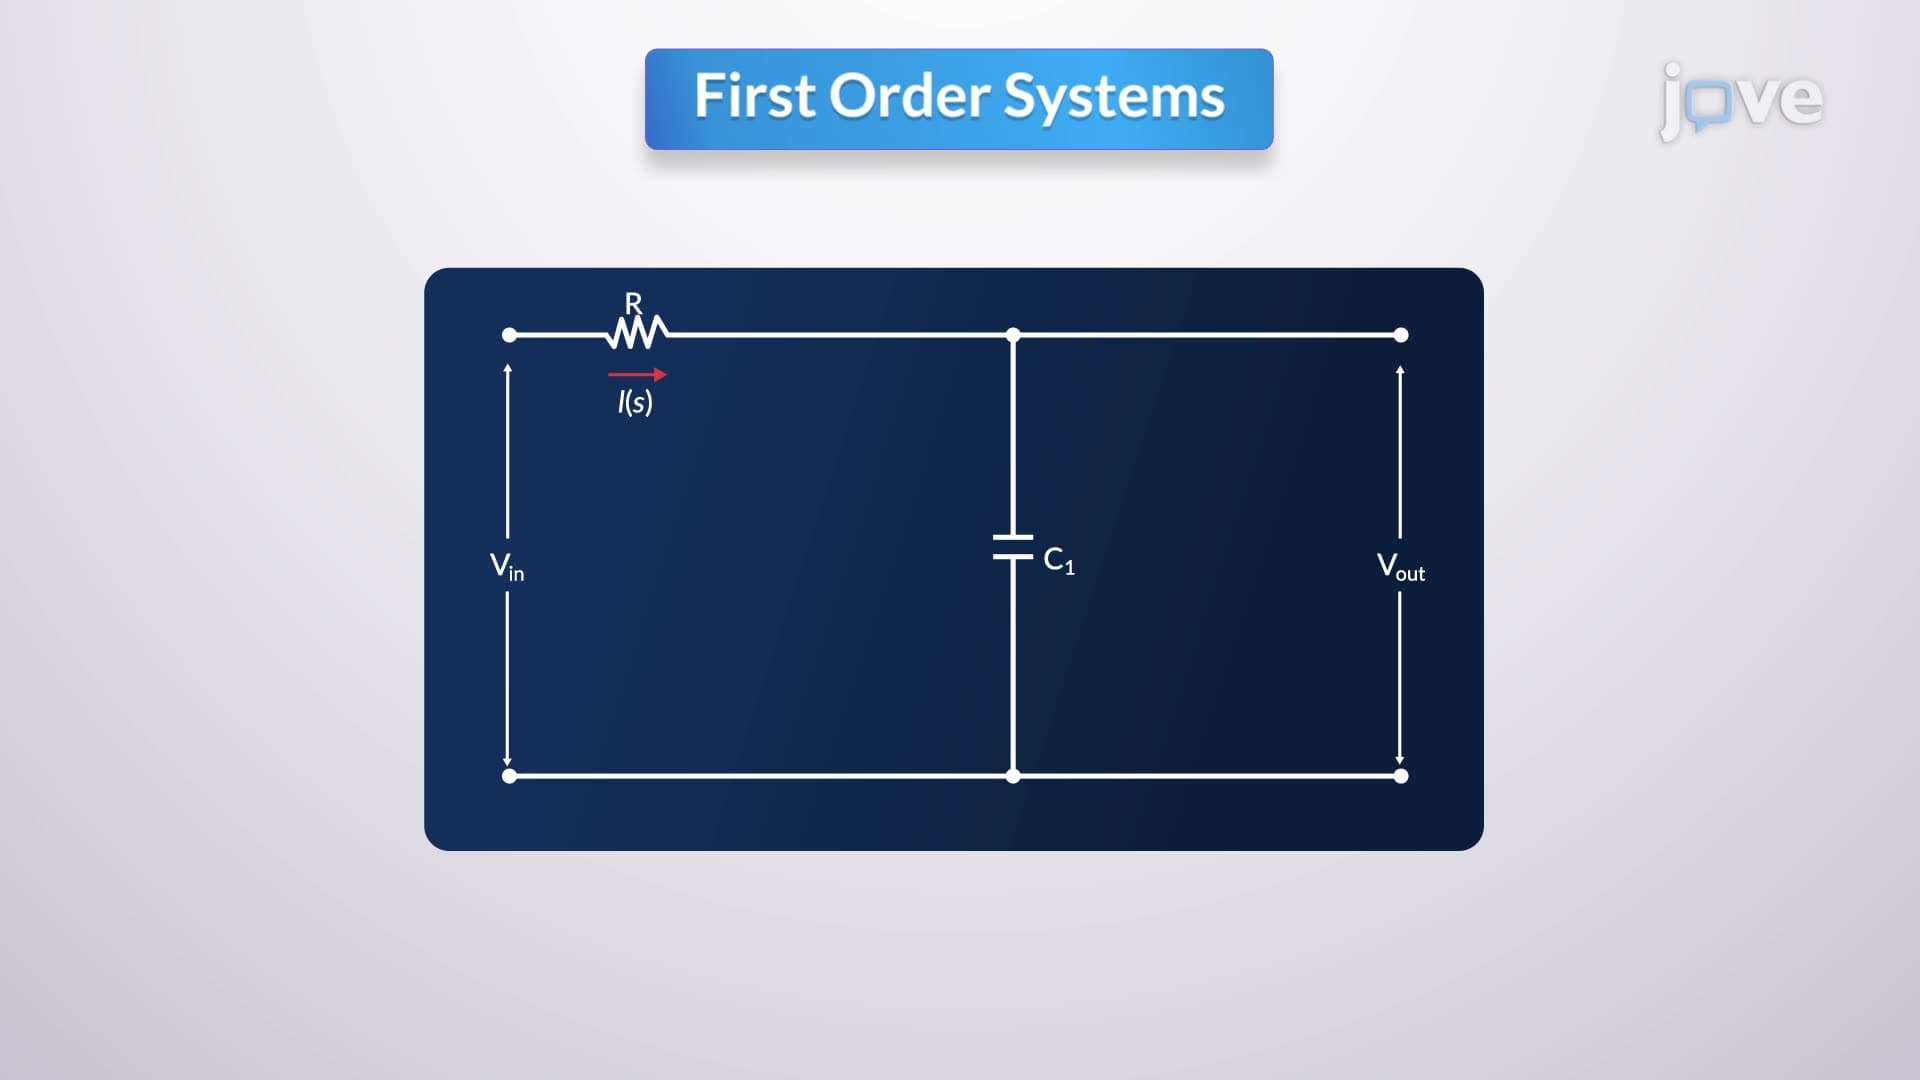
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:20
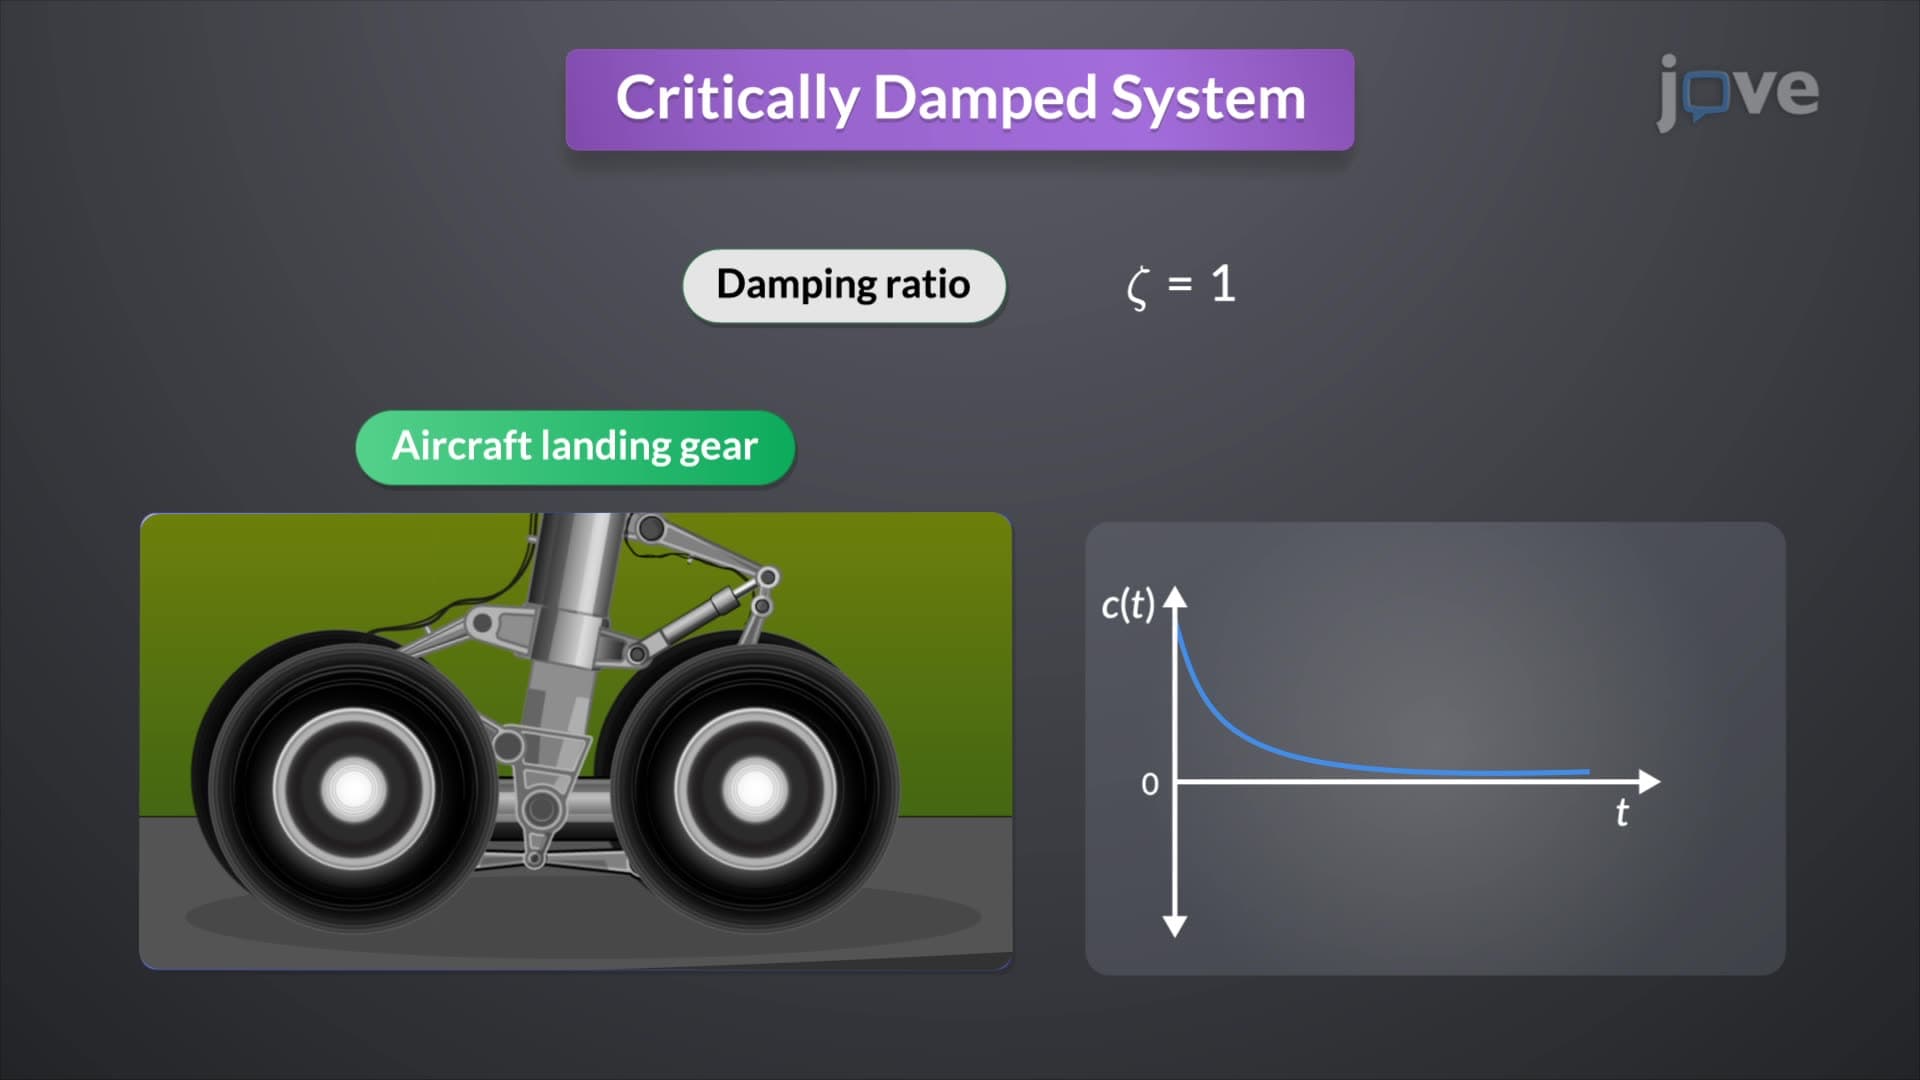
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:06
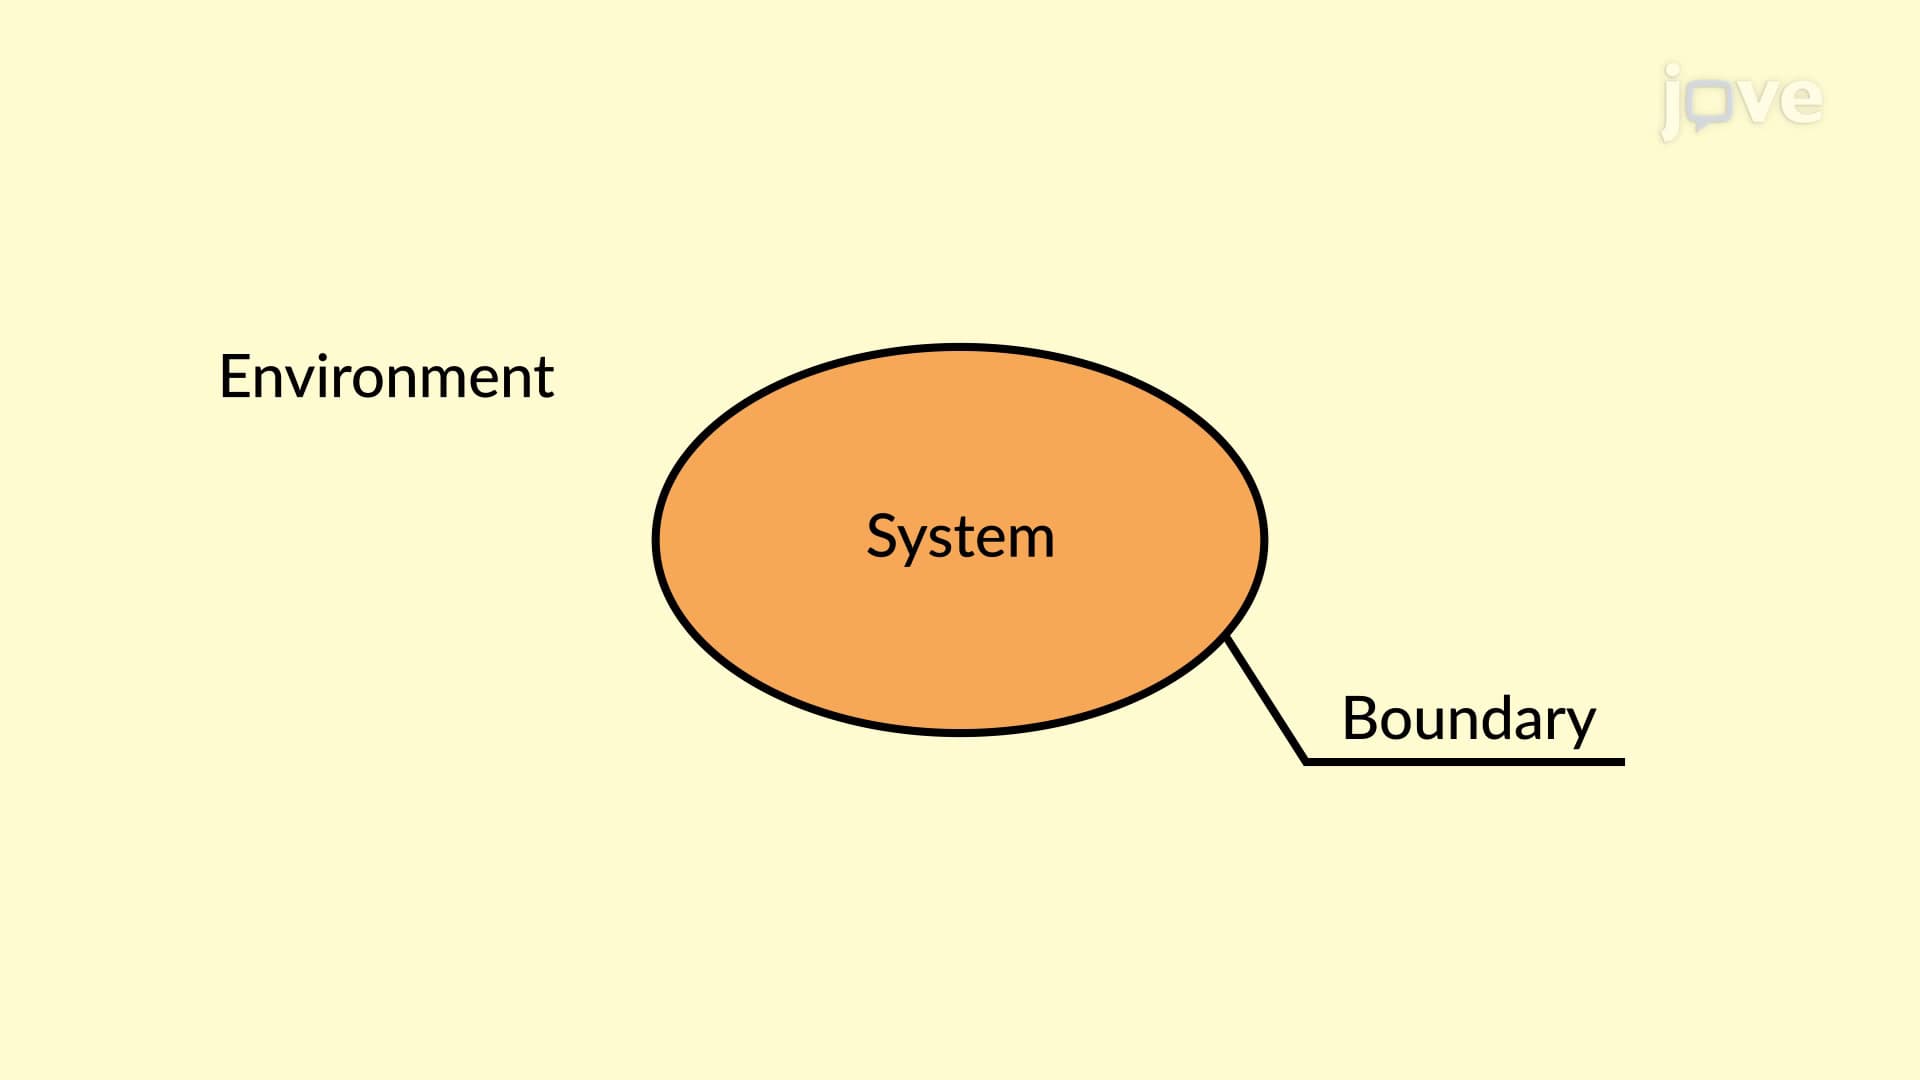
Thermodynamic Systems
Consider an example of tea boiling in a kettle. The...
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as: