Related Experiment Video
Updated: Feb 3, 2026

Preparation of Liquid Crystal Networks for Macroscopic Oscillatory Motion Induced by Light
Published on: September 20, 2017
A Light Spot Humanoid Motion Paradigm Modulated by the Change of Brightness to Recognize the Stride Motion Frequency
Xin Zhang1, Guanghua Xu1,2, Xun Zhang1
1School of Mechanical Engineering, Xi'an Jiaotong University, Xi'an, China.

Abstract:
The steady-state visual evoked potential (SSVEP)-based brain-computer interface (BCI) usually has the advantages of high information transfer rate (ITR) and no need for training. However, low frequencies, such as the human stride motion frequency, cannot easily induce SSVEP. To solve this problem, a light spot humanoid motion paradigm modulated by the change of brightness was designed in this study. The characteristics of the brain response to the motion paradigm modulated by the change of brightness were analyzed for the first time. The results showed that the designed paradigm could induce not only the high flicker frequency but also the modulation frequencies between the change of brightness and the motion in the primary visual cortex. Thus, the stride motion frequency can be recognized through the modulation frequencies by using the designed paradigm. Also, in an online experiment, this paradigm was employed to control a lower limb robot to achieve same frequency stimulation, which meant that the visual stimulation frequency was the same as the motion frequency of the robot. Also, canonical correlation analysis (CCA) was used to distinguish three different stride motion frequencies. The average accuracies of the classification in three walking speeds using the designed paradigm with the same and different high frequencies reached 87 and 95% respectively. Furthermore, the angles of the knee joint of the robot were obtained to demonstrate the feasibility of the electroencephalograph (EEG)-driven robot with same stimulation.
Related Concept Videos
 01:22
Equation of Motion: General Plane motion
Moreover, the body's center of mass experiences a rotational effect as a result of these couple moments. This rotation can be articulated as the...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:18
Projectile Motion: Example
When we speak of the range (R) of a projectile on...
 01:42
Simple Harmonic Motion and Uniform Circular Motion
There is an easy way to produce simple harmonic motion by using uniform circular motion. For instance, consider a ball attached to a uniformly rotating...
 01:15
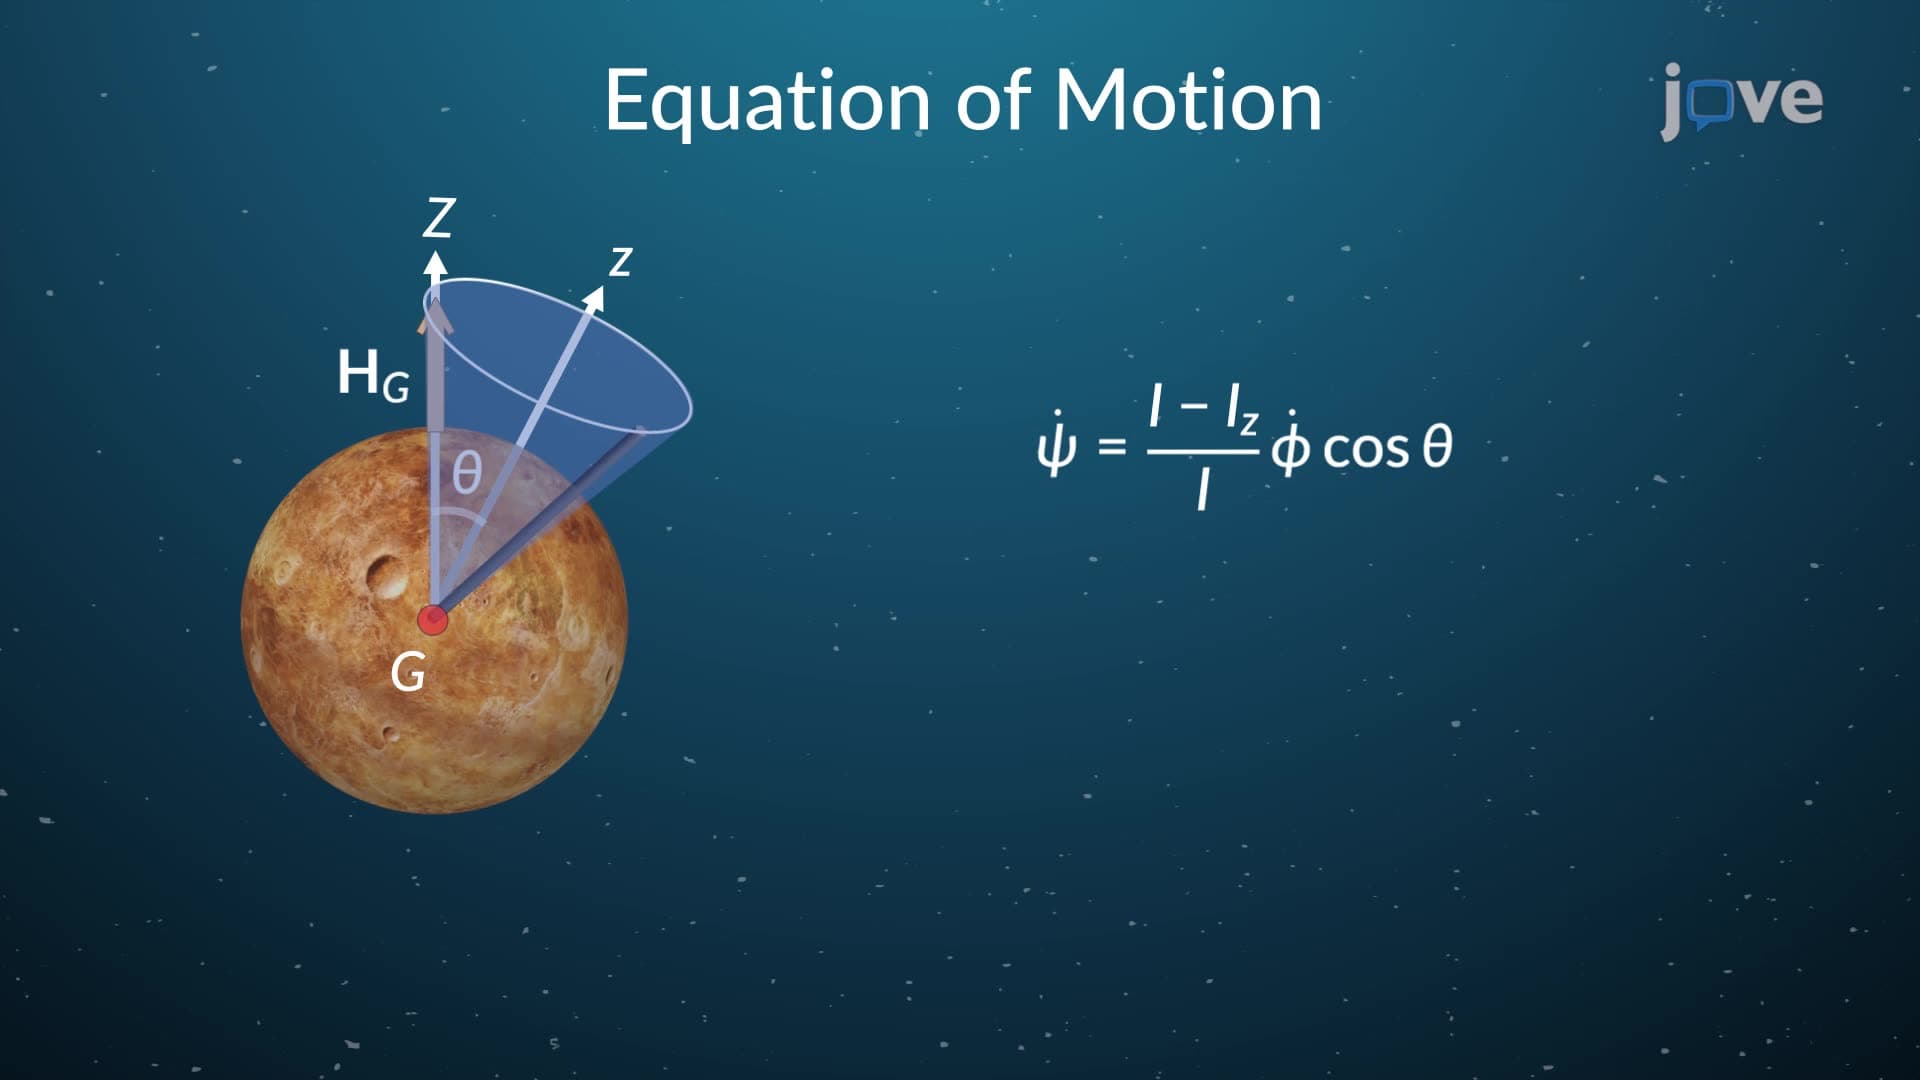
Torque Free Motion