Related Experiment Video
Updated: Feb 3, 2026

Mimicking and Measuring Occlusal Erosive Tooth Wear with the "Rub&Roll" and Non-contact Profilometry
Published on: February 2, 2018
Compliant rolling-contact architected materials for shape reconfigurability
Lucas A Shaw1, Samira Chizari1, Matthew Dotson1
1Mechanical and Aerospace Engineering, University of California, Los Angeles, Los Angeles, CA, 90095, USA.

Abstract:
Architected materials can achieve impressive shape-changing capabilities according to how their microarchitecture is engineered. Here we introduce an approach for dramatically advancing such capabilities by utilizing wrapped flexure straps to guide the rolling motions of tightly packed micro-cams that constitute the material's microarchitecture. This approach enables high shape-morphing versatility and extreme ranges of deformation without accruing appreciable increases in strain energy or internal stress. Two-dimensional and three-dimensional macroscale prototypes are demonstrated, and the analytical theory necessary to design the proposed materials is provided and packaged as a software tool. An approach that combines two-photon stereolithography and scanning holographic optical tweezers is demonstrated to enable the fabrication of the proposed materials at their intended microscale.
Related Concept Videos
 01:09
Rolling Without Slipping
 01:14
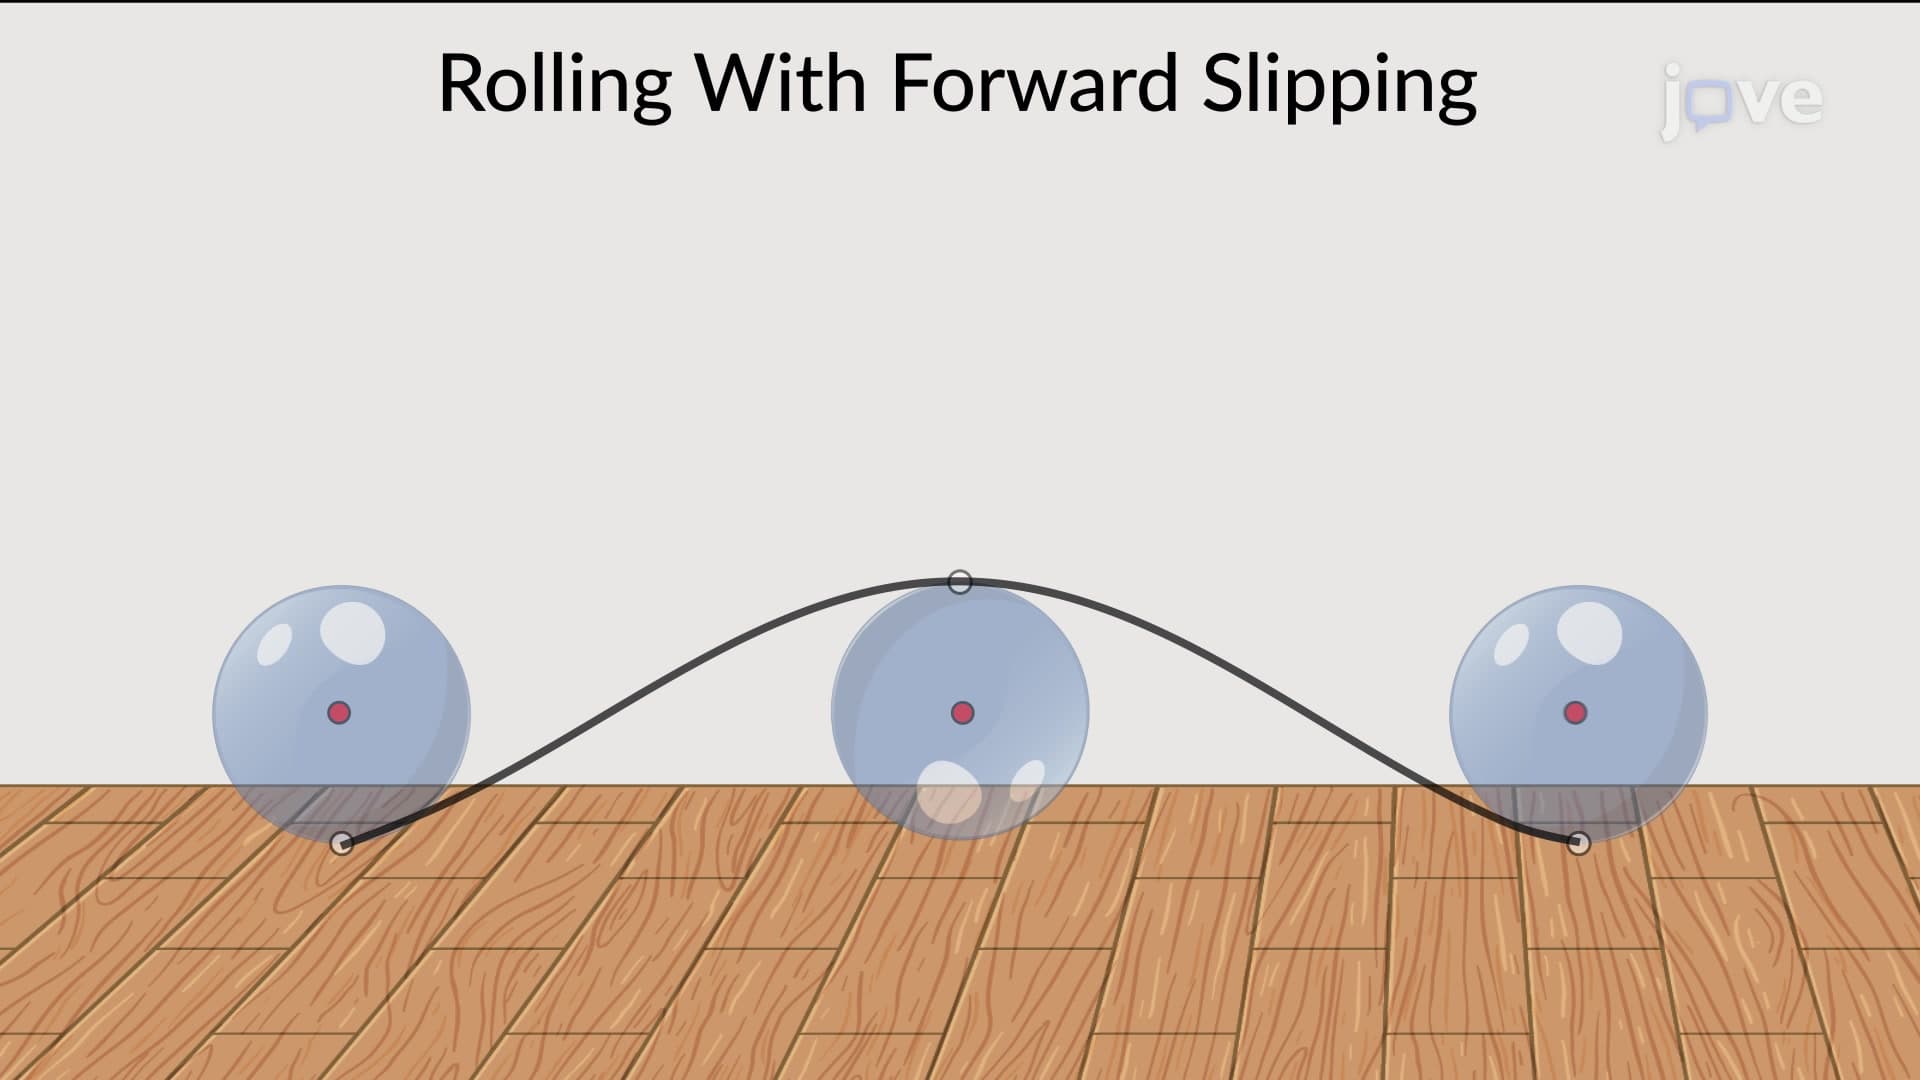
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
 01:21
Rolling Resistance
For instance, imagine a hard cylinder rolling on a comparatively soft surface. The cylinder's weight compresses the surface beneath it. As the cylinder moves, the material in front of it slows down due to...
 01:13
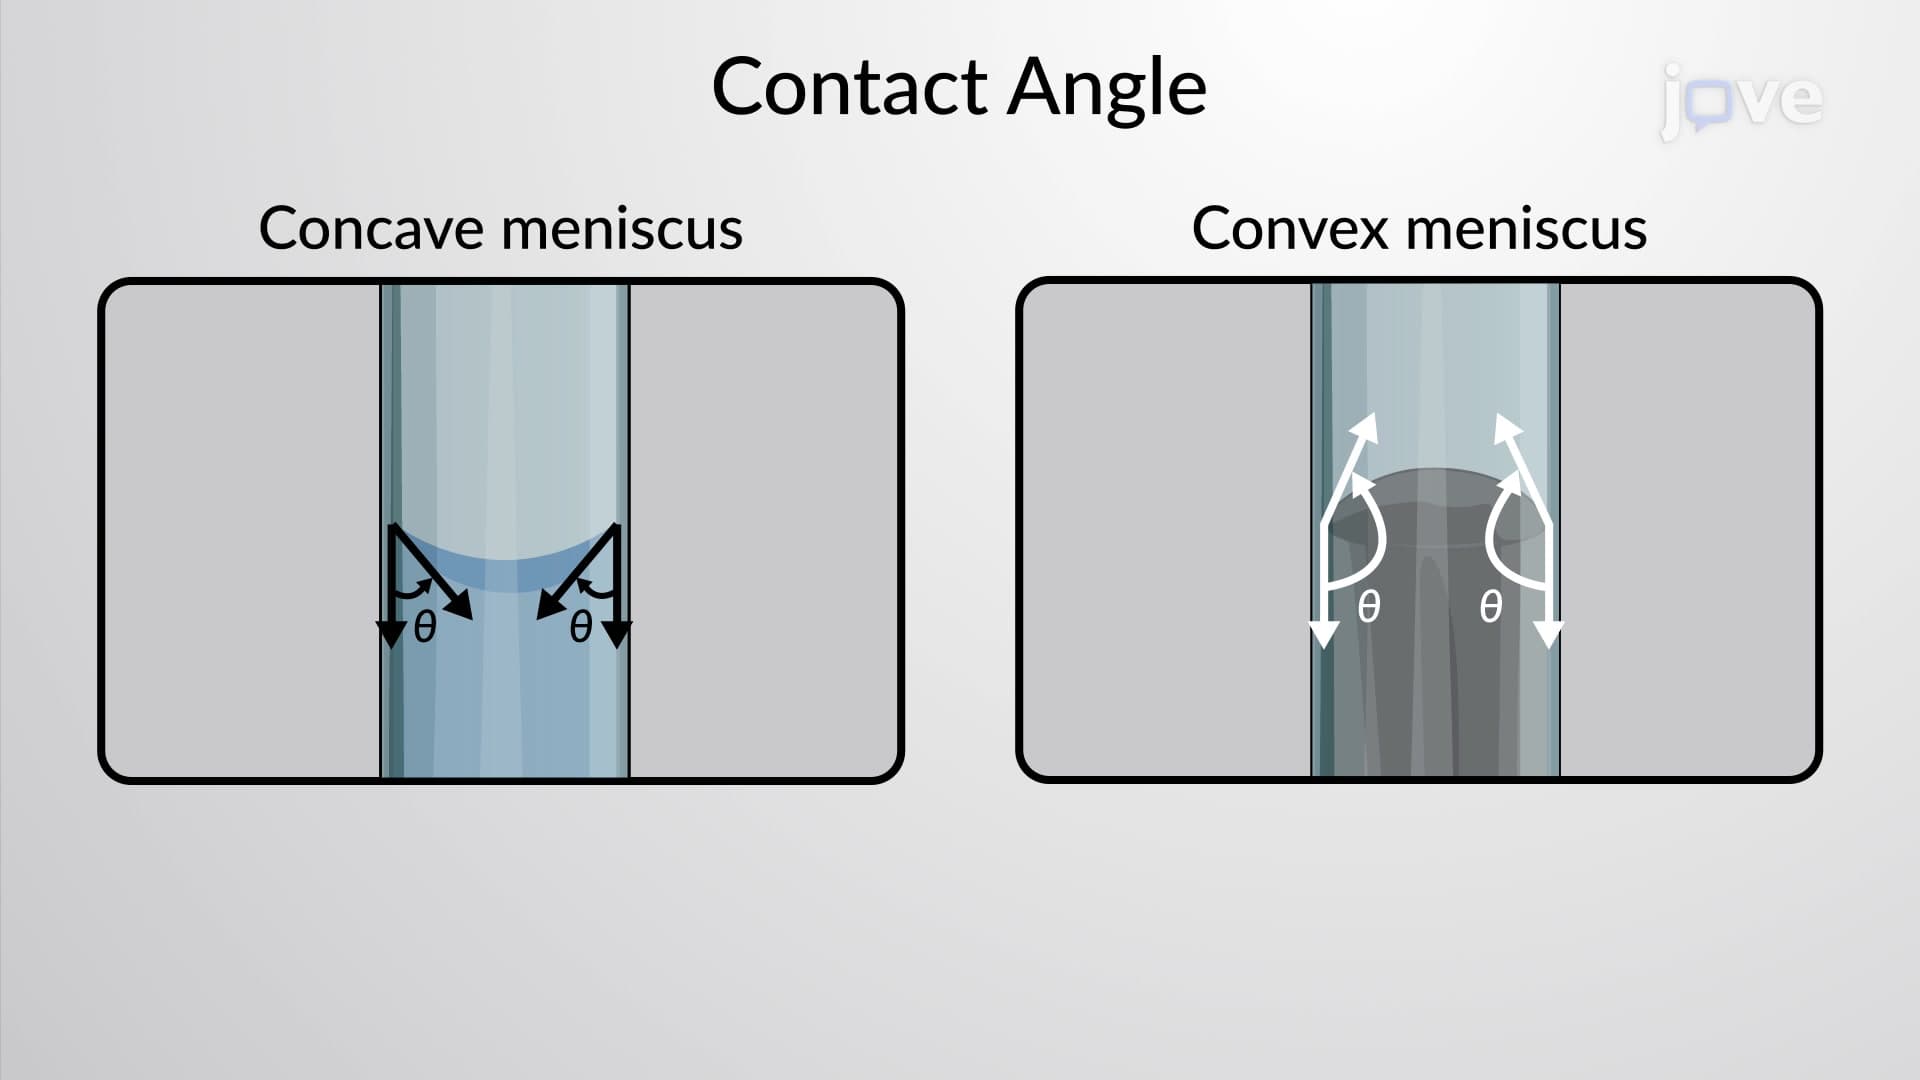
Contact Angle
The adhesive force is the molecular force between molecules of different materials, that is, between the molecules of the solid and the liquid. The cohesive...
 01:19
Contact-dependent Signaling
Gap Junctions
In animal cells, gap junctions are formed...
 03:37
Molecular Shape and Polarity