Related Experiment Video
Updated: Feb 2, 2026
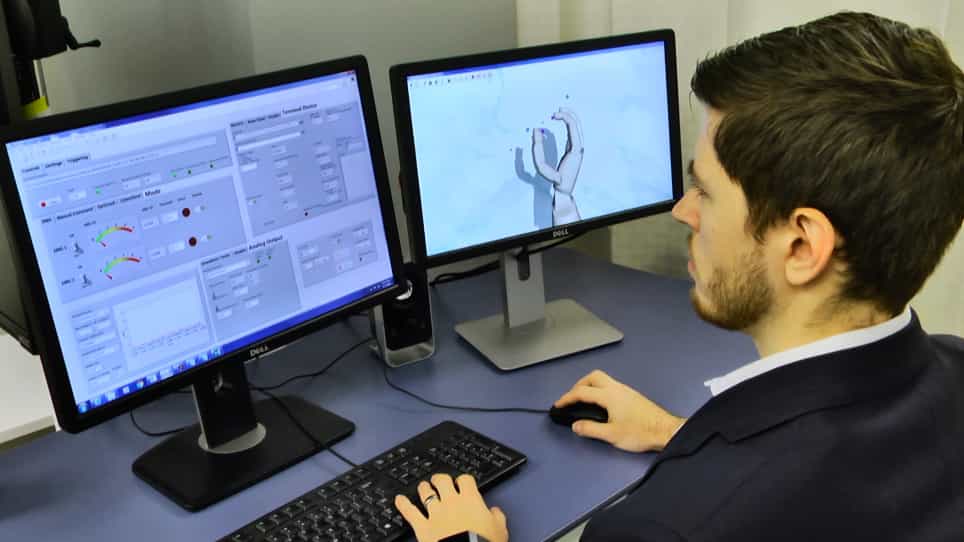

Characterization of the Sense of Agency over the Actions of Neural-machine Interface-operated Prostheses
Published on: January 7, 2019
Towards Ultra Low-Cost Myoactivated Prostheses
Neethu Sreenivasan1, Diego Felipe Ulloa Gutierrez1, Paolo Bifulco2
1School of Computing, Engineering and Mathematics, Western Sydney University, NSW, Australia.

Abstract:
In developing countries, due to the high cost involved, amputees have limited access to prosthetic limbs. This constitutes a barrier for this people to live a normal life. To break this barrier, we are developing ultra-low-cost closed-loop myoactivated prostheses that are easy to maintain manufacture and that do not require electrodes in contact with the skin to work effectively. In this paper, we present the implementation for a simple but functional hand prosthesis. Our simple design consists of a low-cost embedded microcontroller (Arduino), a wearable stretch sensor (adapted from electroresistive bands normally used for "insulation of gaskets" against EM fields), to detect residual muscle contraction as direct muscle volumetric shifts and a handful of common, not critical electronic components. The physical prosthesis is a 3D printed claw-style two-fingered hand (PLA plastic) directly geared to an inexpensive servomotor. To make our design easier to maintain, the gears and mechanical parts can be crafted from recovered materials. To implement a closed loop, the amount of closure of prosthesis is fed back to the user via a second stretch sensor directly connected to claw under the form of haptic feedback. Our concept design comprised of all the parts has an overall cost below AUD 30 and can be easily scaled up to more complicated devices suitable for other uses, i.e., multiple individual fingers and wrist rotation.
Related Concept Videos
 02:06
Social Exchange Theory
 01:55
Egoism and Altruism
 02:24
Comparative Excretory Systems
 00:48
Optimal Foraging
 01:25
The Anchoring-and-Adjustment Heuristic
 01:41
Affinity and Avidity