A Fuzzy Adaptive Tightly-Coupled Integration Method for Mobile Target Localization Using SINS/WSN
Related Experiment Video
Updated: Feb 2, 2026
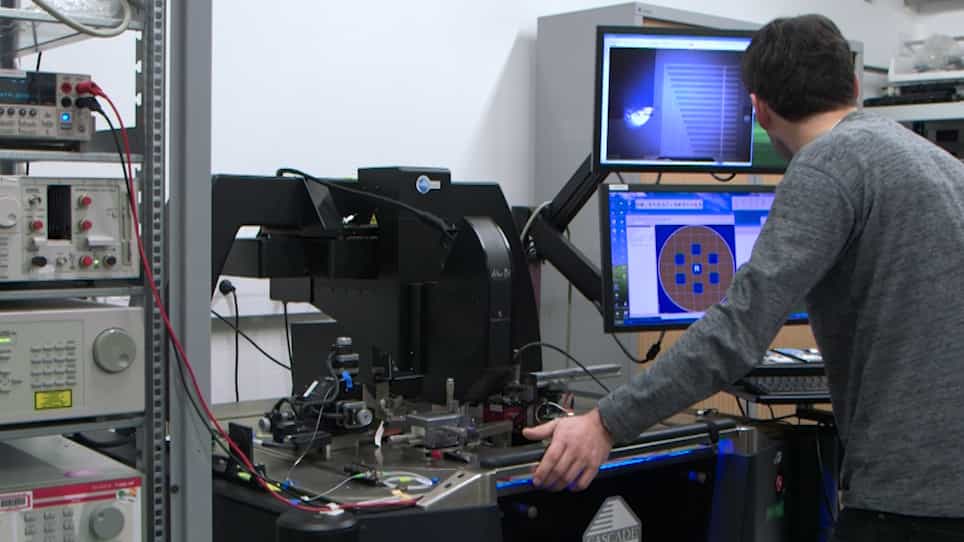
Characterization of SiN Integrated Optical Phased Arrays on a Wafer-Scale Test Station
Published on: April 1, 2020
Wei Li1, Hai Yang2, Mengbao Fan3
1School of Mechatronic Engineering, China University of Mining and Technology, Xuzhou 221116, Jiangsu, China. weilicmee@cumt.edu.cn.

Abstract:
In recent years, mobile target localization for enclosed environments has been a growing interest. In this paper, we have proposed a fuzzy adaptive tightly-coupled integration (FATCI) method for positioning and tracking applications using strapdown inertial navigation system (SINS) and wireless sensor network (WSN). The wireless signal outage and severe multipath propagation of WSN often influence the accuracy of measured distance and lead to difficulties with the WSN positioning. Note also that the SINS are known for their drifted error over time. Using as a base the well-known loosely-coupled integration method, we have built a tightly-coupled integrated positioning system for SINS/WSN based on the measured distances between anchor nodes and mobile node. The measured distance value of WSN is corrected with a least squares regression (LSR) algorithm, with the aim of decreasing the systematic error for measured distance. Additionally, the statistical covariance of measured distance value is used to adjust the observation covariance matrix of a Kalman filter using a fuzzy inference system (FIS), based on the statistical characteristics. Then the tightly-coupled integration model can adaptively adjust the confidence level for measurement according to the different measured accuracies of distance measurements. Hence the FATCI system is achieved using SINS/WSN. This innovative approach is verified in real scenarios. Experimental results show that the proposed positioning system has better accuracy and stability compared with the loosely-coupled and traditional tightly-coupled integration model for WSN short-term failure or normal conditions.
More Related Videos
Related Concept Videos
 01:29
Tight Junctions
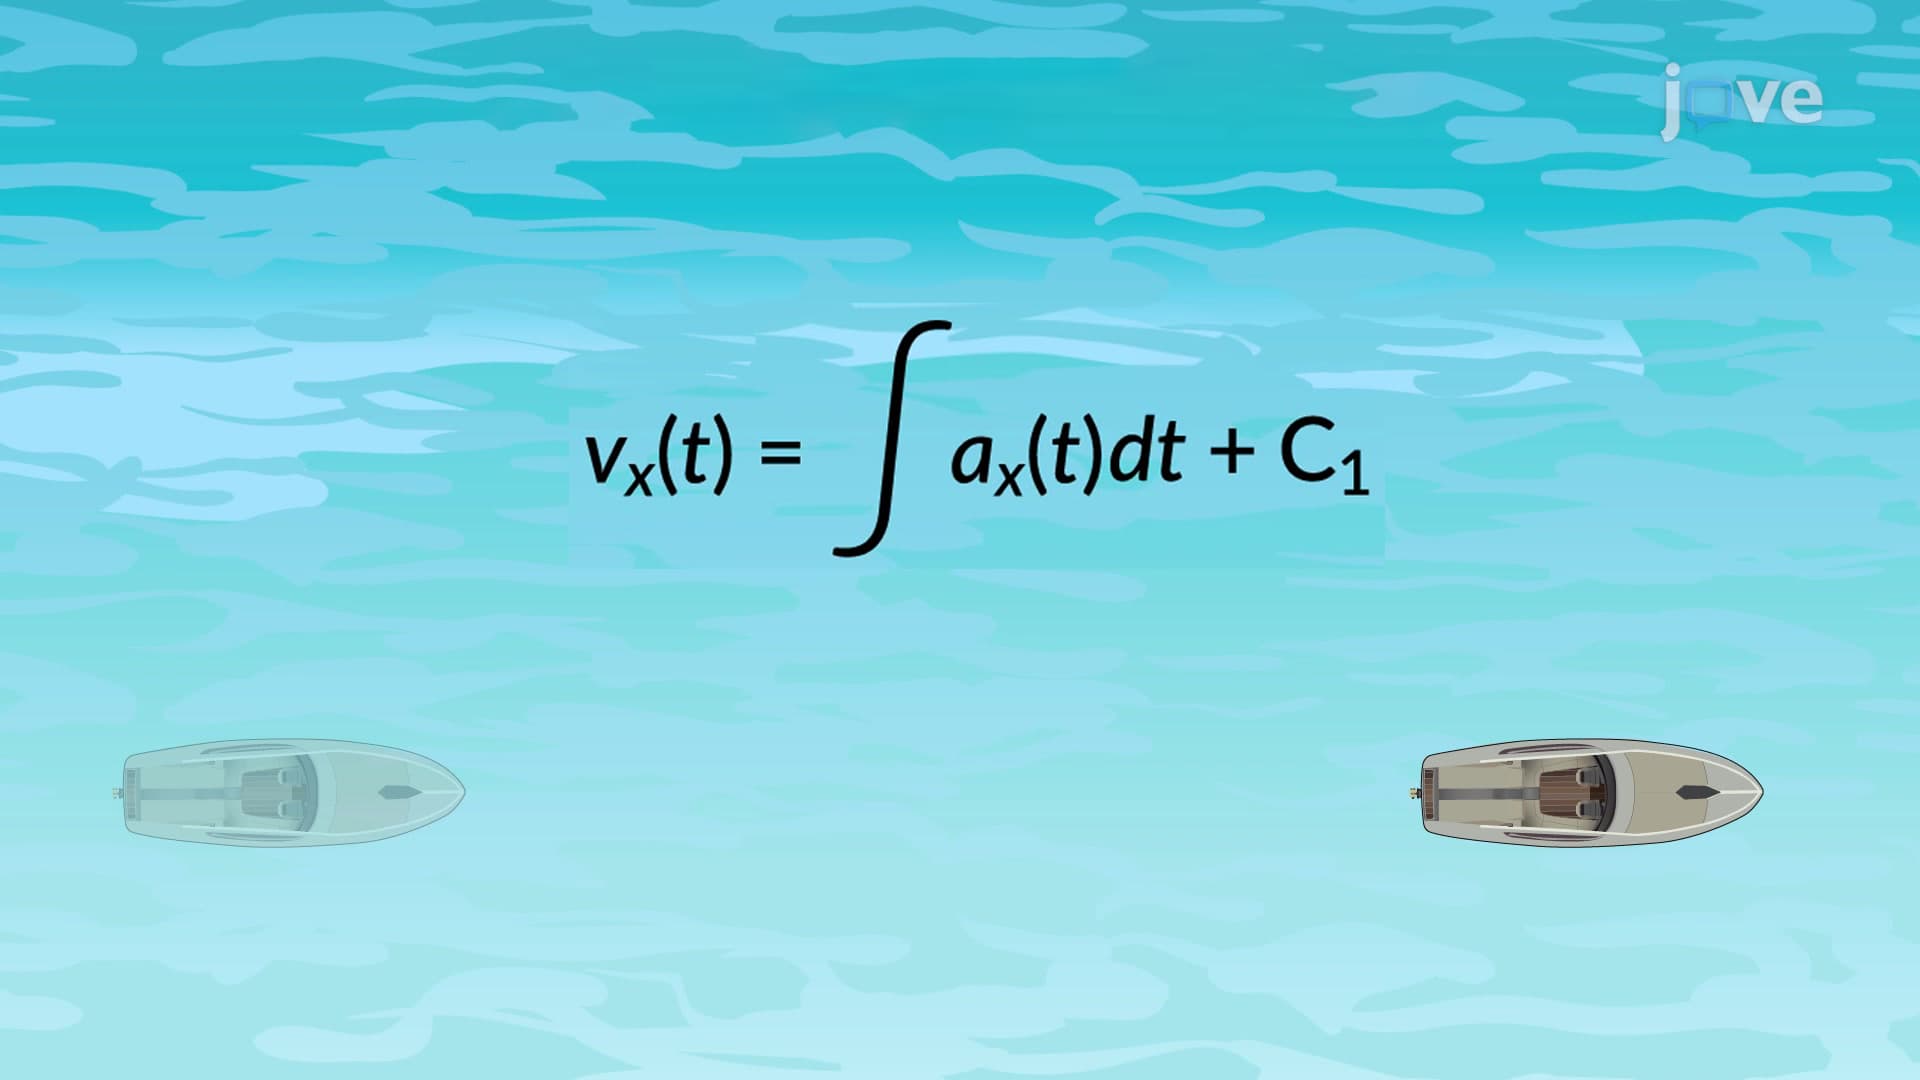 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:21
G-protein Coupled Receptors
 01:20
Spin–Spin Coupling: Two-Bond Coupling (Geminal Coupling)
The central atom need not be NMR-active because its electrons are affected by the electron polarization of the spin-active atoms. However, spin information is transmitted less effectively than in one-bond coupling, and 2J values are usually weaker than 1J values. The energy of...
 01:22
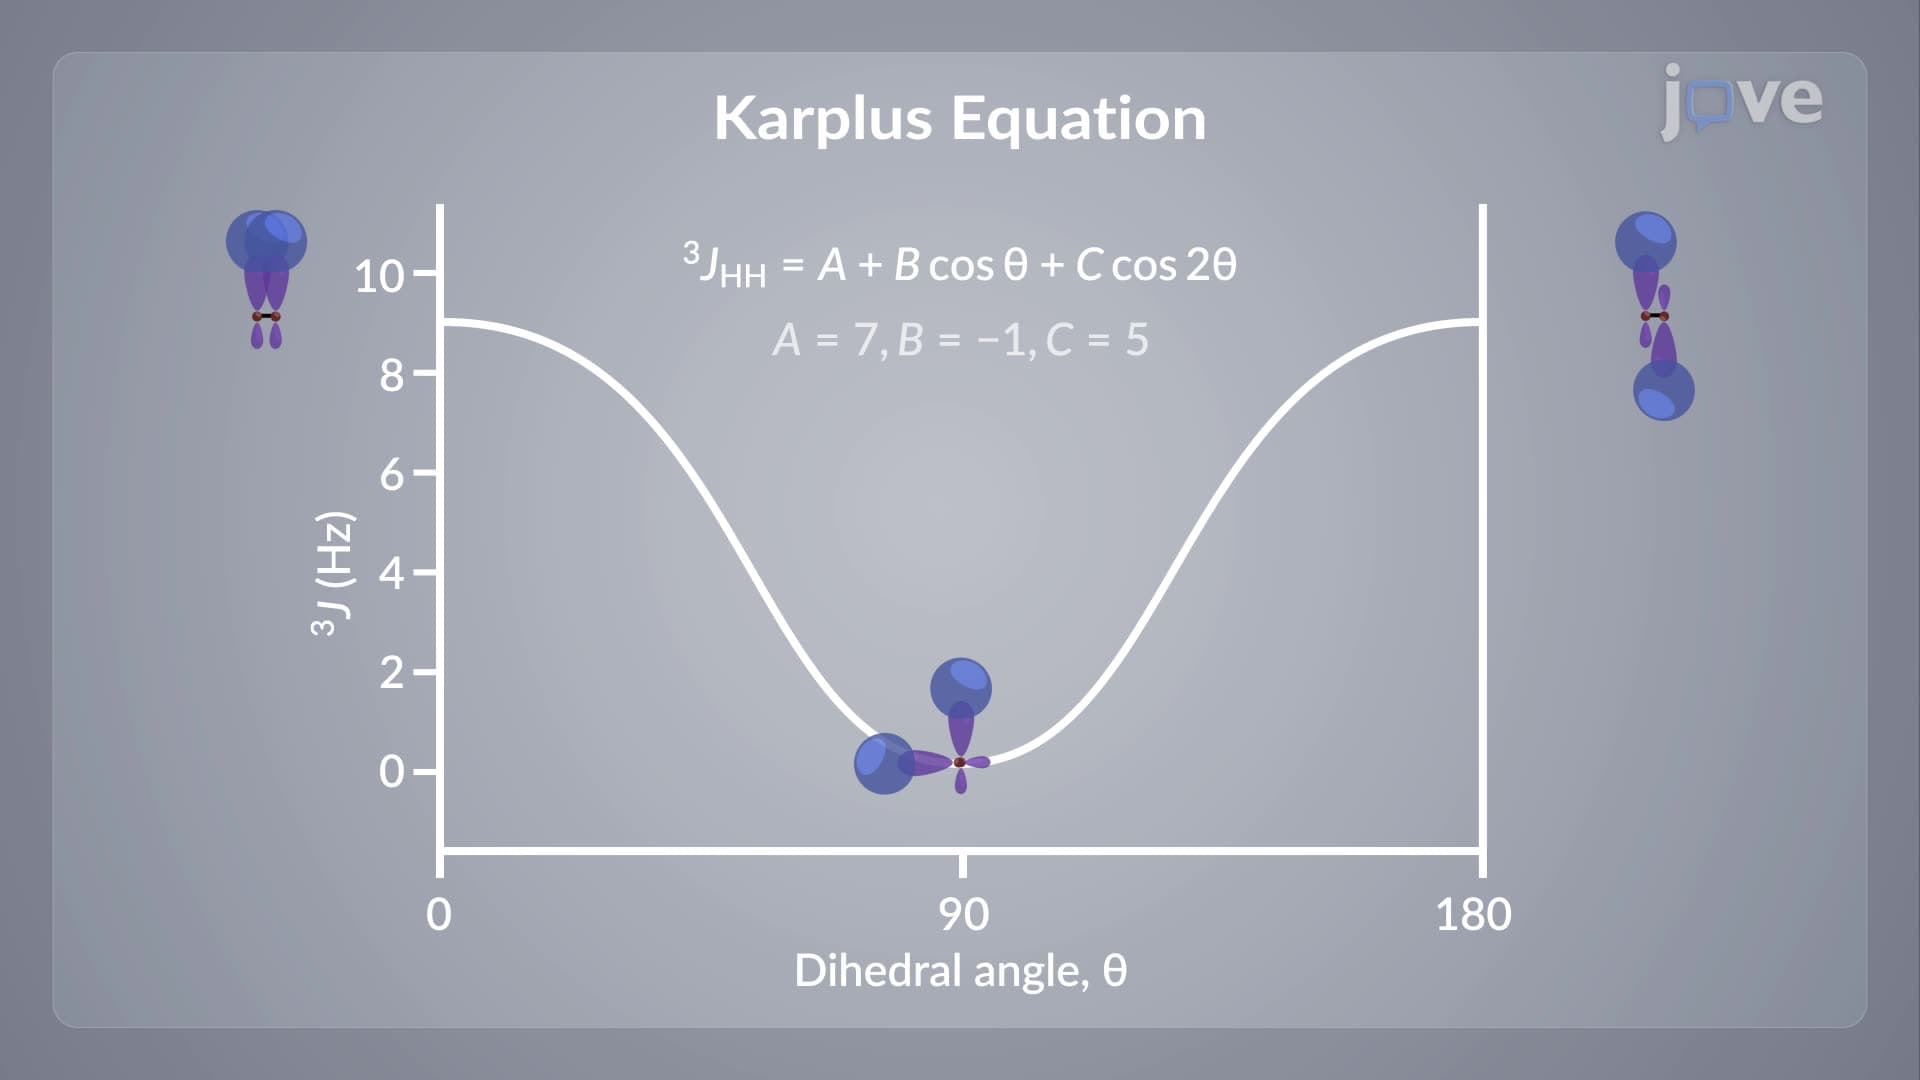
Spin–Spin Coupling: Three-Bond Coupling (Vicinal Coupling)
The extent of coupling depends on the C‑C bond length, the two H‑C‑C angles, any electron-withdrawing substituents, and the dihedral angle between the involved orbitals. The...
 01:17
Spin–Spin Coupling: One-Bond Coupling