Related Experiment Video
Updated: Feb 2, 2026

Frame-by-Frame Video Analysis of Idiosyncratic Reach-to-Grasp Movements in Humans
Published on: January 15, 2018
Exploring representations of human grasping in neural, muscle and kinematic signals
Andreea I Sburlea1, Gernot R Müller-Putz2
1Institute of Neural Engineering, Graz University of Technology, Graz, Austria.

Abstract:
Movement covariates, such as electromyographic or kinematic activity, have been proposed as candidates for the neural representation of hand control. However, it remains unclear how these movement covariates are reflected in electroencephalographic (EEG) activity during different stages of grasping movements. In this exploratory study, we simultaneously acquired EEG, kinematic and electromyographic recordings of human subjects performing 33 types of grasps, yielding the largest such dataset to date. We observed that EEG activity reflected different movement covariates in different stages of grasping. During the pre-shaping stage, centro-parietal EEG in the lower beta frequency band reflected the object's shape and size, whereas during the finalization and holding stages, contralateral parietal EEG in the mu frequency band reflected muscle activity. These findings contribute to the understanding of the temporal organization of neural grasping patterns, and could inform the design of noninvasive neuroprosthetics and brain-computer interfaces with more natural control.
More Related Videos
 09:41
Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
 11:14
A Novel Experimental and Analytical Approach to the Multimodal Neural Decoding of Intent During Social Interaction in Freely-behaving Human Infants
Published on: October 4, 2015
Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:26
Kinematic Equations - I
 01:16
Control Volume and System Representations
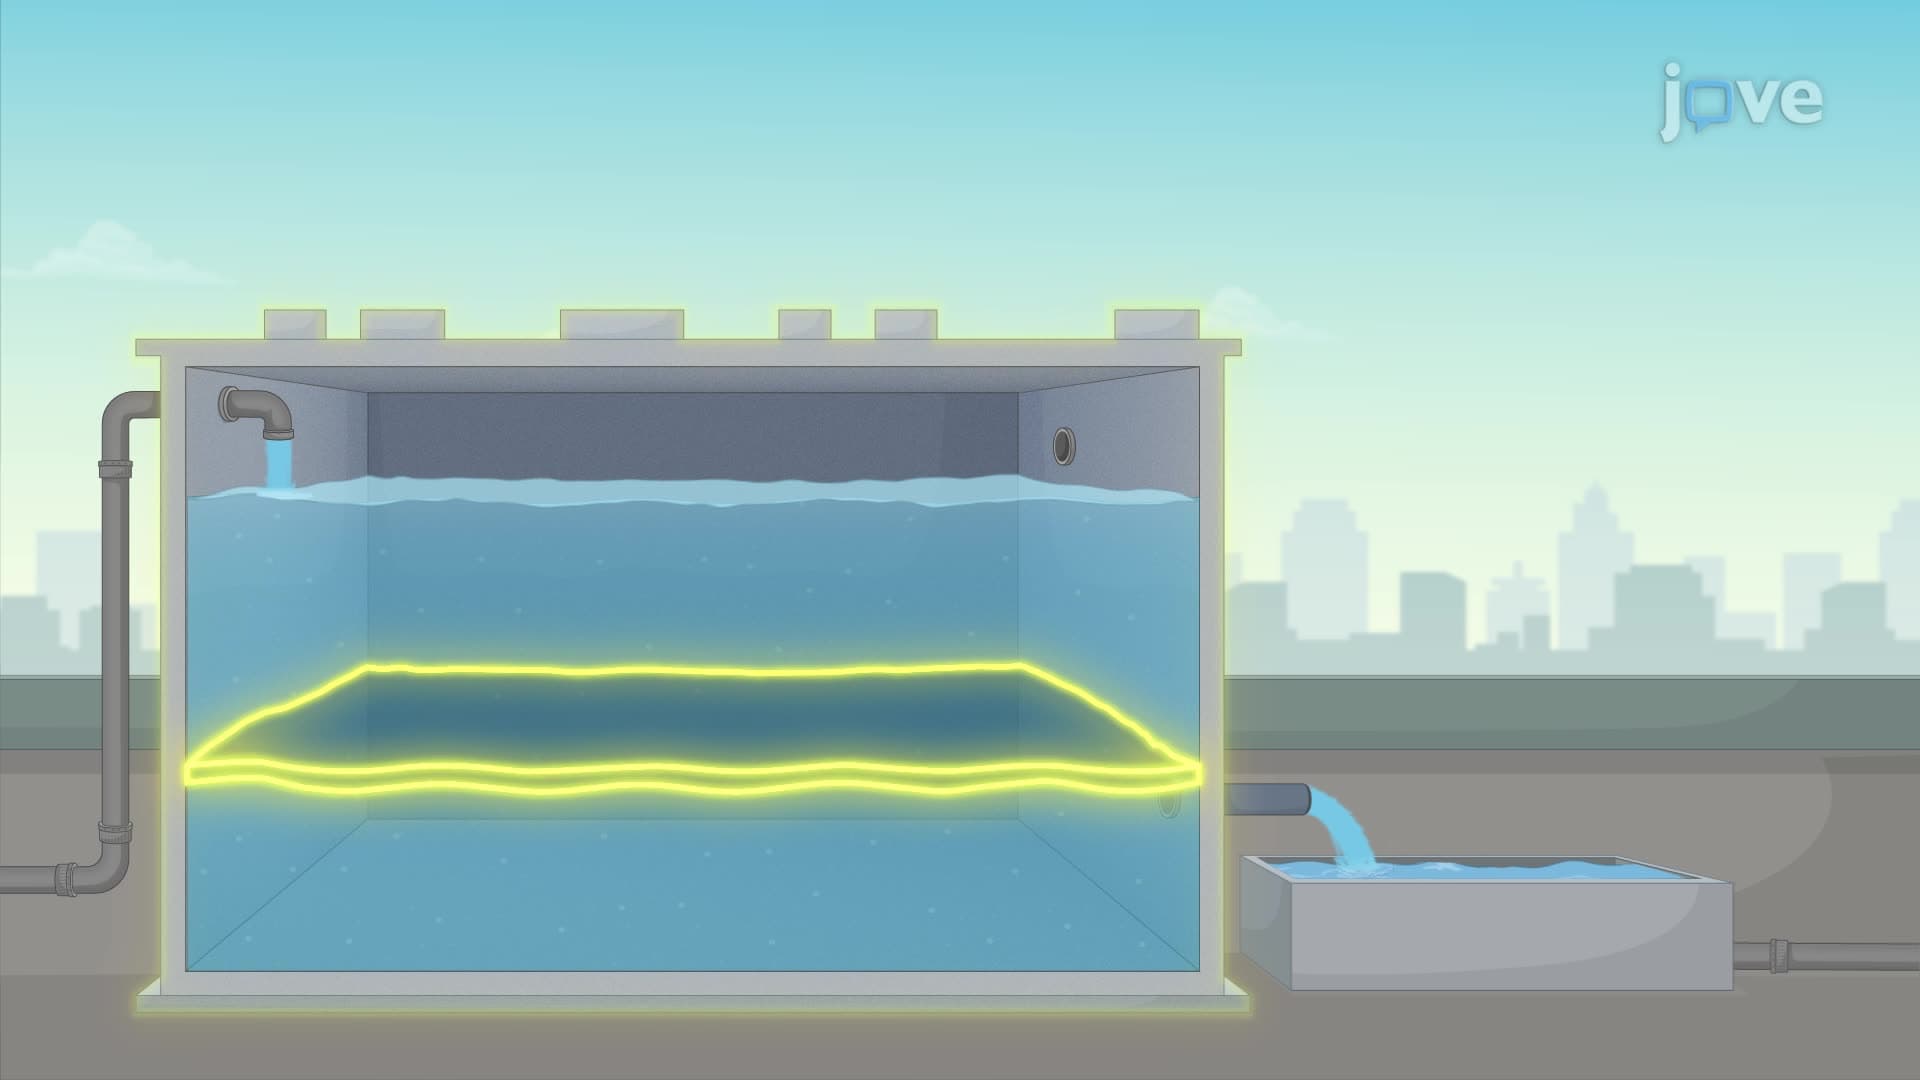
The control volume approach considers a stationary region in space through which fluid flows. This region is bounded by a control surface. For instance, in the case of water...
 01:28
Graphical Representation of Inequalities
 01:16
Vector Representation of Complex Numbers
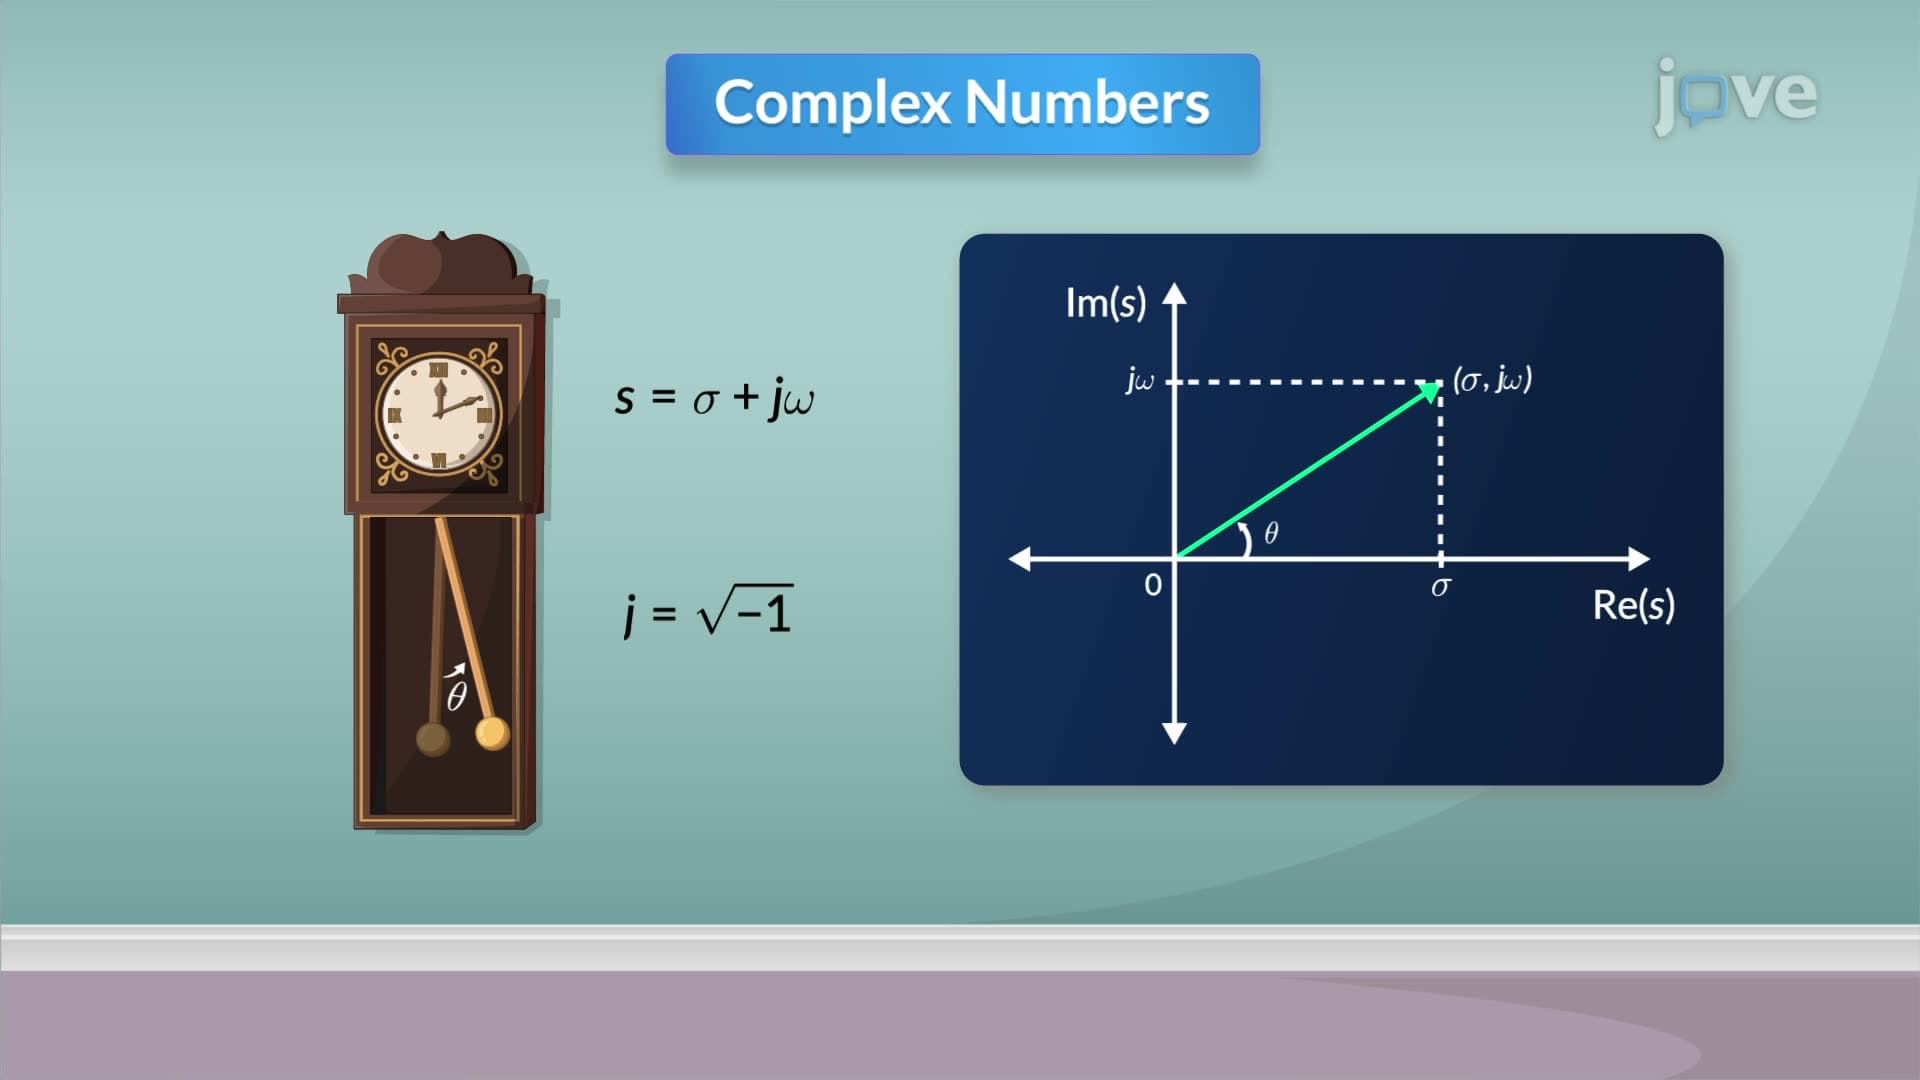
Consider a function defined as the product of the complex factors in the numerator divided by the product of the complex factors in the...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...