Related Experiment Video
Updated: Feb 2, 2026

Single-molecule Manipulation of G-quadruplexes by Magnetic Tweezers
Published on: September 19, 2017
Automatic Manipulation of Magnetically Actuated Helical Microswimmers in Static Environments
Jia Liu1,2,3, Tiantian Xu4,5,6, Chenyang Huang7,8,9
1Guangdong Provincial Key Laboratory of Robotics and Intelligent System, Shenzhen Institutes of Advanced Technology, Chinese Academy of Sciences, Shenzhen 518055, China. jia.liu1@siat.ac.cn.

Abstract:
Electromagnetically actuated microswimmers have been widely used in various biomedical applications due to their minor invasive traits and their easy access to confined environments. In order to guide the microswimmers autonomously towards a target, an obstacle-free path must be computed using path planning algorithms, meanwhile a motion controller must be formulated. However, automatic manipulations of magnetically actuated microswimmers are underdeveloped and still are challenging topics. In this paper, we develop an automatic manipulation system for magnetically actuated helical microswimmers in static environments, which mainly consists of a mapper, a path planner, and a motion controller. First, the mapper processes the captured image by morphological transformations and then labels the free space and the obstacle space. Second, the path planner explores the obstacle-free space to find a feasible path from the start to the goal by a global planning algorithm. Last, the motion controller guides the helical microswimmers along the desired path by a closed-loop algorithm. Experiments are conducted to verify the effectiveness of the proposed automatic manipulation. Furthermore, our proposed approach presents the first step towards applications of microswimmers for targeted medical treatments, such as micromanipulation, targeted therapy, and targeted drug delivery.
Related Concept Videos
 01:28
Automatic Processing and Automatic Social Behavior
 01:05
Static Equilibrium - I
 01:07
Static Equilibrium - II
 01:18
Static Friction
For example, consider a scenario where a truck is connected to a car by a rope, ready to tow it along a road. When no external force is applied by the truck, the car remains stationary and is said to be in static equilibrium. In this case, the forces acting on the car, such as gravity and the...
 01:28
Problem Solving in Statics
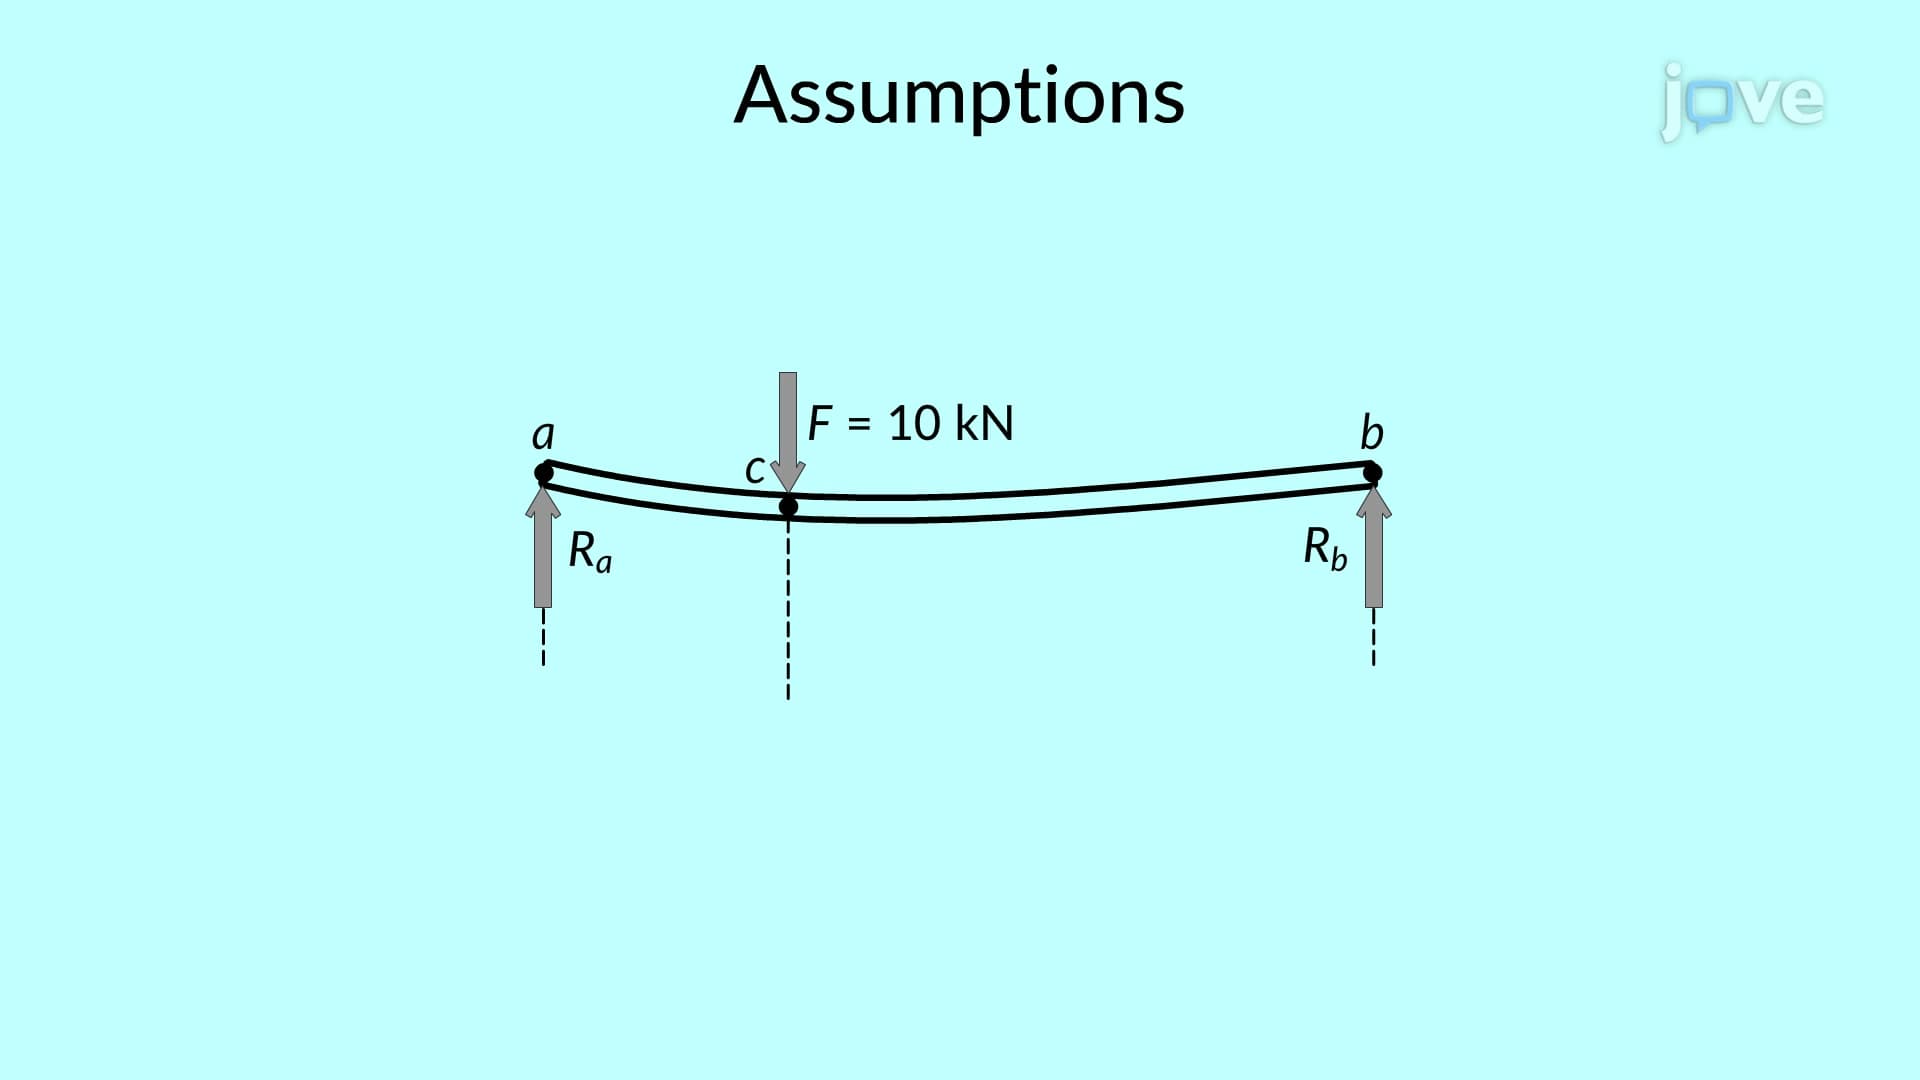
The physical situation and mathematical modeling must be considered; however, it is challenging to represent all physical situations using mathematical modeling. With the help of...
 01:16
Statically Indeterminate Problem Solving