Related Experiment Video
Updated: Feb 2, 2026

Correlative Microscopy for 3D Structural Analysis of Dynamic Interactions
Published on: June 24, 2013
Rigid Body Dynamics Algorithm for Modeling Random Packing Structures of Nonspherical and Nonconvex Pellets
Elyas M Moghaddam1, Esmail A Foumeny1, Andrzej I Stankiewicz1
1Process & Energy Department, Delft University of Technology, 2628CB Delft, The Netherlands.

Abstract:
Despite the common use of nonspherical catalyst pellets in chemical engineering applications, the packing structures of such pellets have not been as systematically studied and characterized as spherical packings. We propose a packing algorithm based on rigid body dynamics to simulate packing of nonspherical and possibly nonconvex pellets. The algorithm exerts a hard-body approach to model collision phenomena. The novelty is that the transition between moving and resting particles is controlled by a cutoff on the relative contact velocities, instead of artificially damping linear and angular velocities to stabilize the algorithm. The algorithm is used to synthesize packings of spheres, cylinders, and Raschig rings with tube-to-pellet diameter ratios 3-9.16. The packings are validated in terms of bulk porosity and radial void fraction distribution, finding satisfactory agreement with literature data. Denser packing structures are generated with high restitution coefficients and low friction coefficients. The confining tube walls play an important role, with highly fluctuating bulk porosities in narrow tubes.
More Related Videos
 08:49
Incorporating Target Protein Structure Flexibility and Dynamics in Computational Drug Discovery Using Ensemble-Based Docking Analysis
Published on: June 20, 2025
 11:53
Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
Related Concept Videos
 00:49
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:11
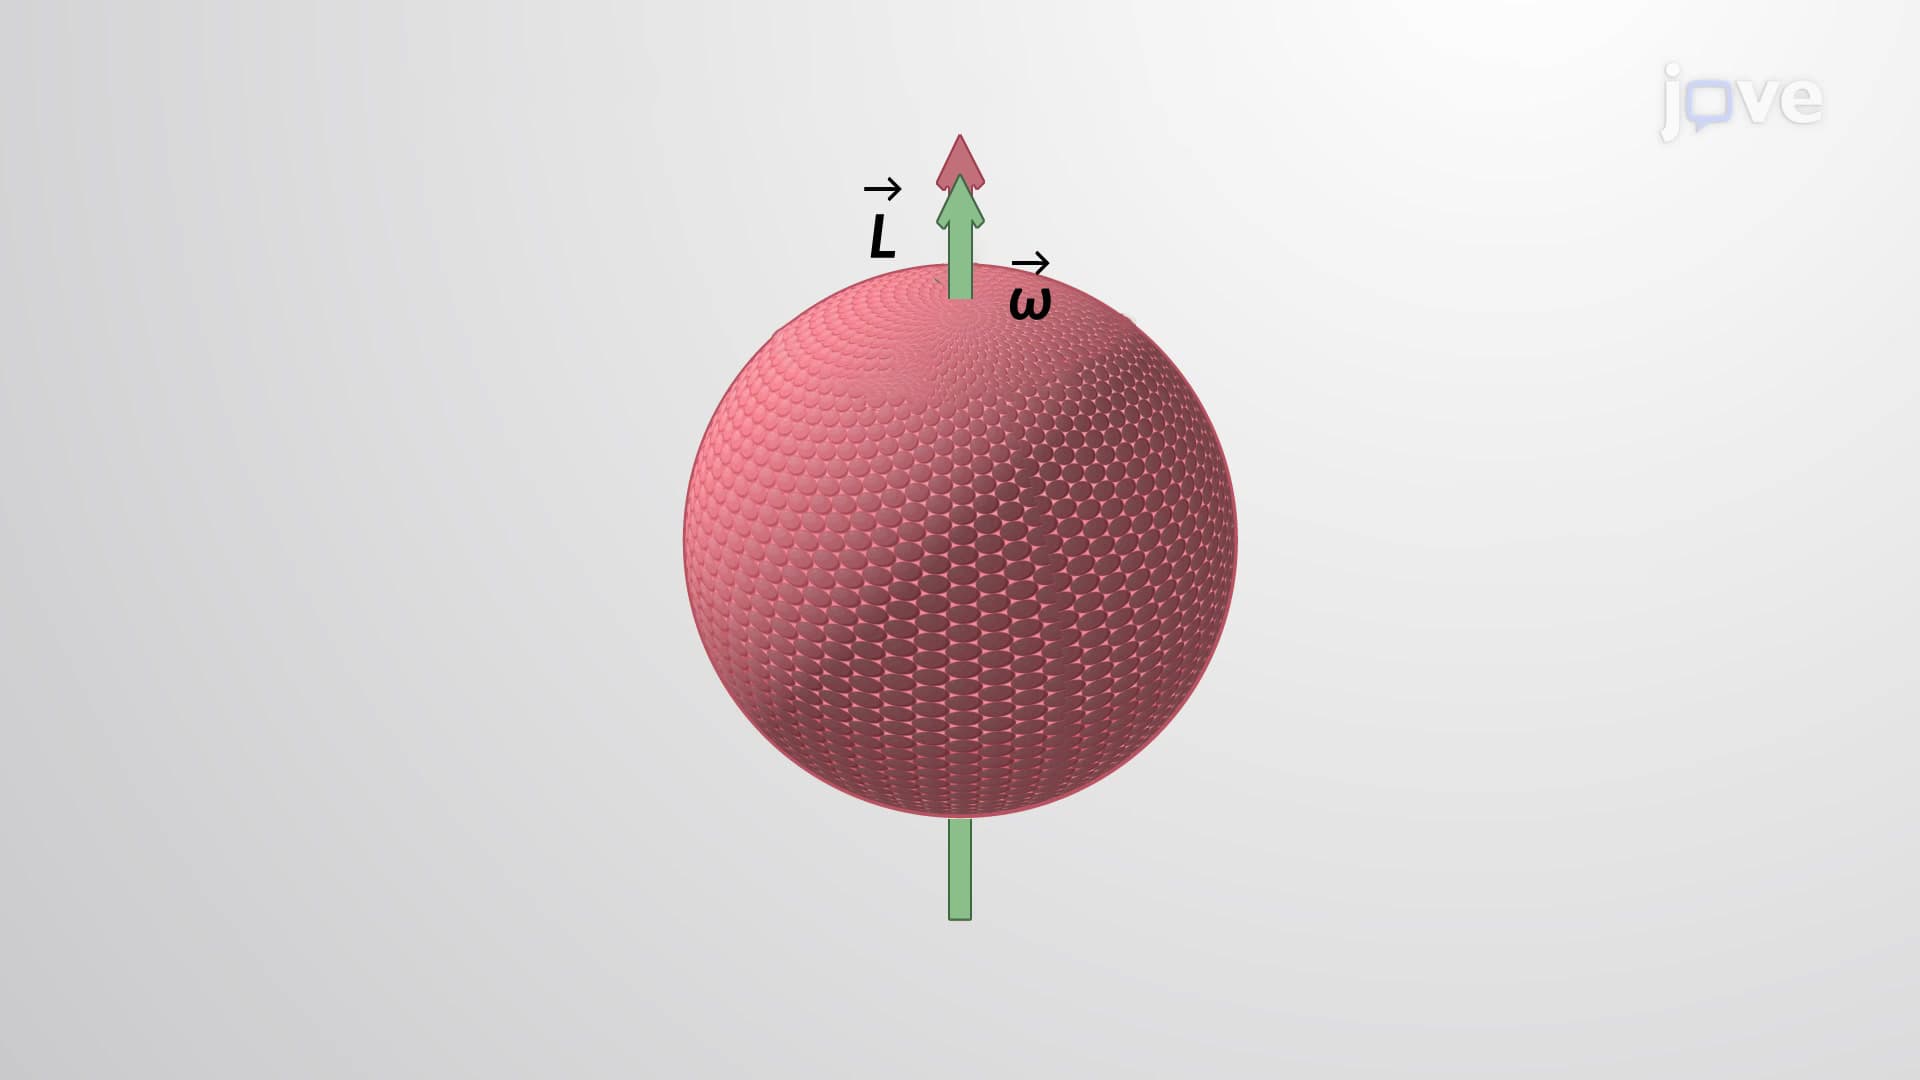
Angular Momentum: Rigid Body
This calculation can get complicated when tiny particles within the rigid body are not rotating in the same plane but have...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:13
Kinetic Energy for a Rigid Body
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different...