Zero-Shot Learning via Robust Latent Representation and Manifold Regularization
Related Experiment Video
Updated: Feb 2, 2026
Investigating the Effect of Visual Imagery and Learning Shape-Audio Regularities on Bouba and Kiki
Published on: September 13, 2019

Abstract:
Zero-shot learning (ZSL) for visual recognition aims to accurately recognize the objects of unseen classes through mapping the visual feature to an embedding space spanned by class semantic information. However, the semantic gap across visual features and their underlying semantics is still a big obstacle in ZSL. Conventional ZSL methods construct that the mapping typically focus on the original visual features that are independent of the ZSL tasks, thus degrading the prediction performance. In this paper, we propose an effective method to uncover an appropriate latent representation of data for the purpose of zero-shot classification. Specifically, we formulate a novel framework to jointly learn the latent subspace and cross-modal embedding to link visual features with their semantic representations. The proposed framework combines feature learning and semantics prediction, such that the learned data representation is more discriminative to predict the semantic vectors, hence improving the overall classification performance. To learn a robust latent subspace, we explicitly avoid the information loss by ensuring the reconstruction ability of the obtained data representation. An efficient algorithm is designed to solve the proposed optimization problem. To fully exploit the intrinsic geometric structure of data, we develop a manifold regularization strategy to refine the learned semantic representations, leading to further improvements of the classification performance. To validate the effectiveness of the proposed approach, extensive experiments are conducted on three ZSL benchmarks and encouraging results are achieved compared with the state-of-the-art ZSL methods.
Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:16
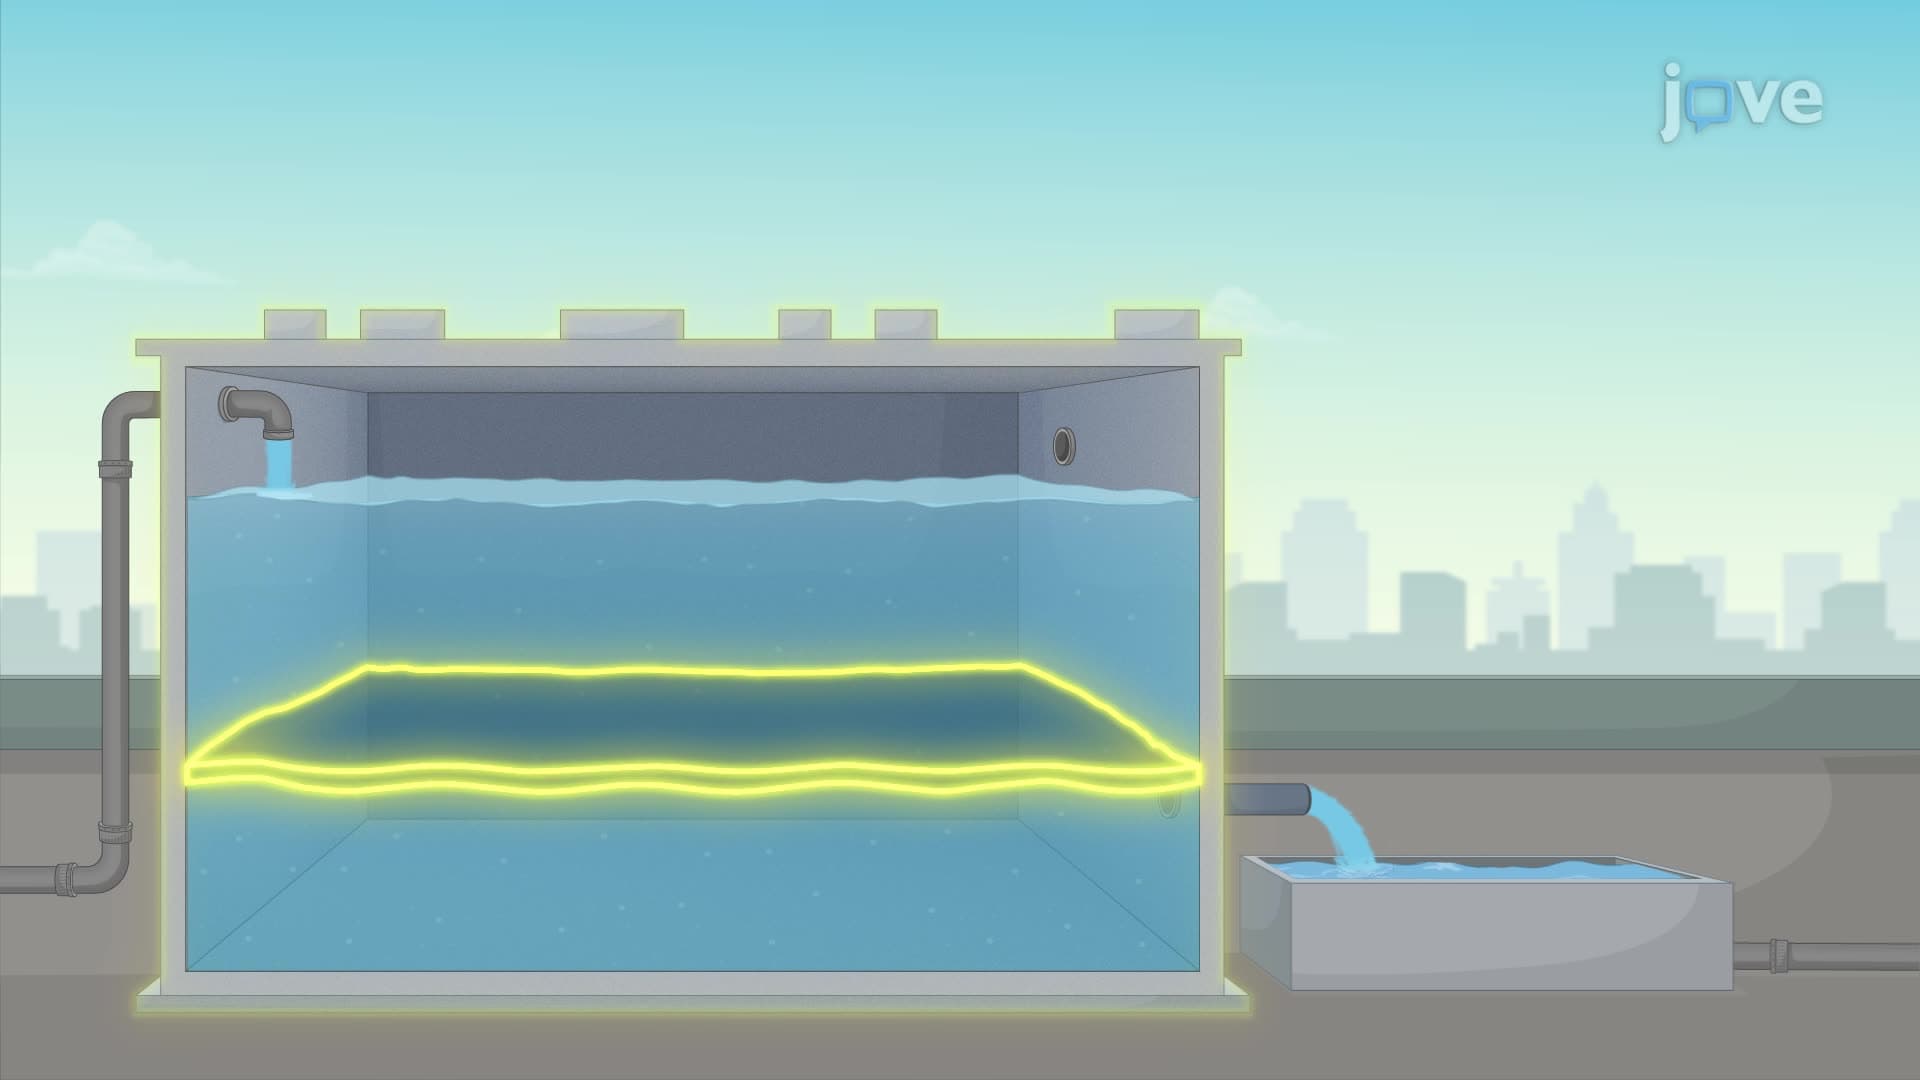
Control Volume and System Representations
The control volume approach considers a stationary region in space through which fluid flows. This region is bounded by a control surface. For instance, in the case of water...
 01:28
Graphical Representation of Inequalities
 01:16
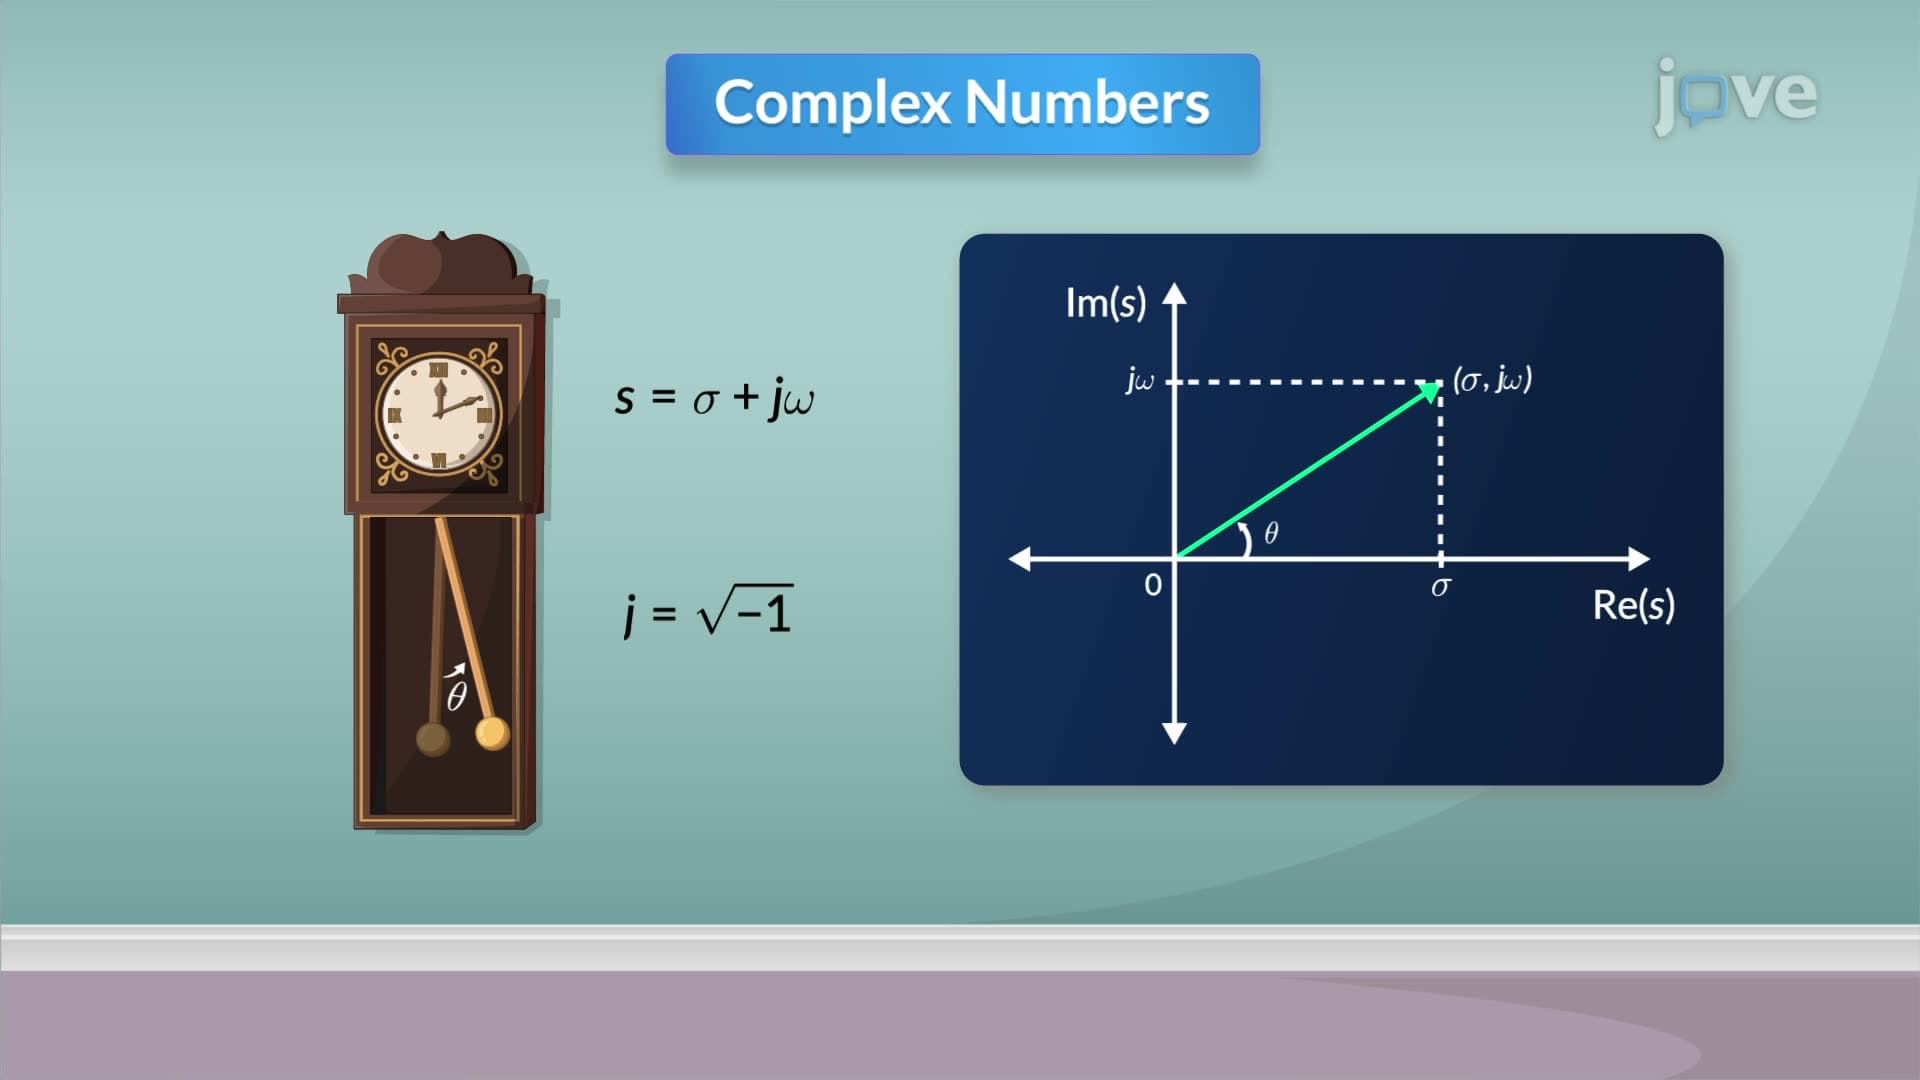
Vector Representation of Complex Numbers
Consider a function defined as the product of the complex factors in the numerator divided by the product of the complex factors in the...
 01:20
Graphical and Analytic Representation of Sinusoids
The first step is measuring the peak-to-peak value, which is twice the amplitude of the sinusoid. This provides information about the maximum voltage swing of the waveform.
Secondly, the period and angular frequency are determined. The period is the time taken for one complete cycle of the waveform, while...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...