Related Experiment Video
Updated: Feb 2, 2026

Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Research on an Improved Method for Foot-Mounted Inertial/Magnetometer Pedestrian-Positioning Based on the Adaptive
Qiuying Wang1, Juan Yin2, Aboelmagd Noureldin3
1College of Information and Communication Engineering, Harbin Engineering University, Harbin 150001, China. wangqiuying@hrbeu.edu.cn.

Abstract:
Foot-mounted Inertial Pedestrian-Positioning Systems (FIPPSs) based on Micro Inertial Measurement Units (MIMUs), have recently attracted widespread attention with the rapid development of MIMUs. The can be used in challenging environments such as firefighting and the military, even without augmenting with Global Navigation Satellite System (GNSS). Zero Velocity Update (ZUPT) provides a solution for the accumulated positioning errors produced by the low precision and high noise of the MIMU, however, there are some problems using ZUPT for FIPPS, include fast-initial alignment and unobserved heading misalignment angle, which are addressed in this paper. Our first contribution is proposing a fast-initial alignment algorithm for foot-mounted inertial/magnetometer pedestrian positioning based on the Adaptive Gradient Descent Algorithm (AGDA). Considering the characteristics of gravity and Earth's magnetic field, measured by accelerometers and magnetometers, respectively, when the pedestrian is standing at one place, the AGDA is introduced as the fast-initial alignment. The AGDA is able to estimate the initial attitude and enhance the ability of magnetic disturbance suppression. Our second contribution in this paper is proposing an inertial/magnetometer positioning algorithm based on an adaptive Kalman filter to solve the problem of the unobserved heading misalignment angle. The algorithm utilizes heading misalignment angle as an observation for the Kalman filter and can improve the accuracy of pedestrian position by compensating for magnetic disturbances. In addition, introducing an adaptive parameter in the Kalman filter is able to compensate the varying magnetic disturbance for each ZUPT instant during the walking phase of the pedestrian. The performance of the proposed method is examined by conducting pedestrian test trajectory using MTi-G710 manufacture by XSENS. The experimental results verify the effectiveness and applicability of the proposed method.
Related Concept Videos
 01:26
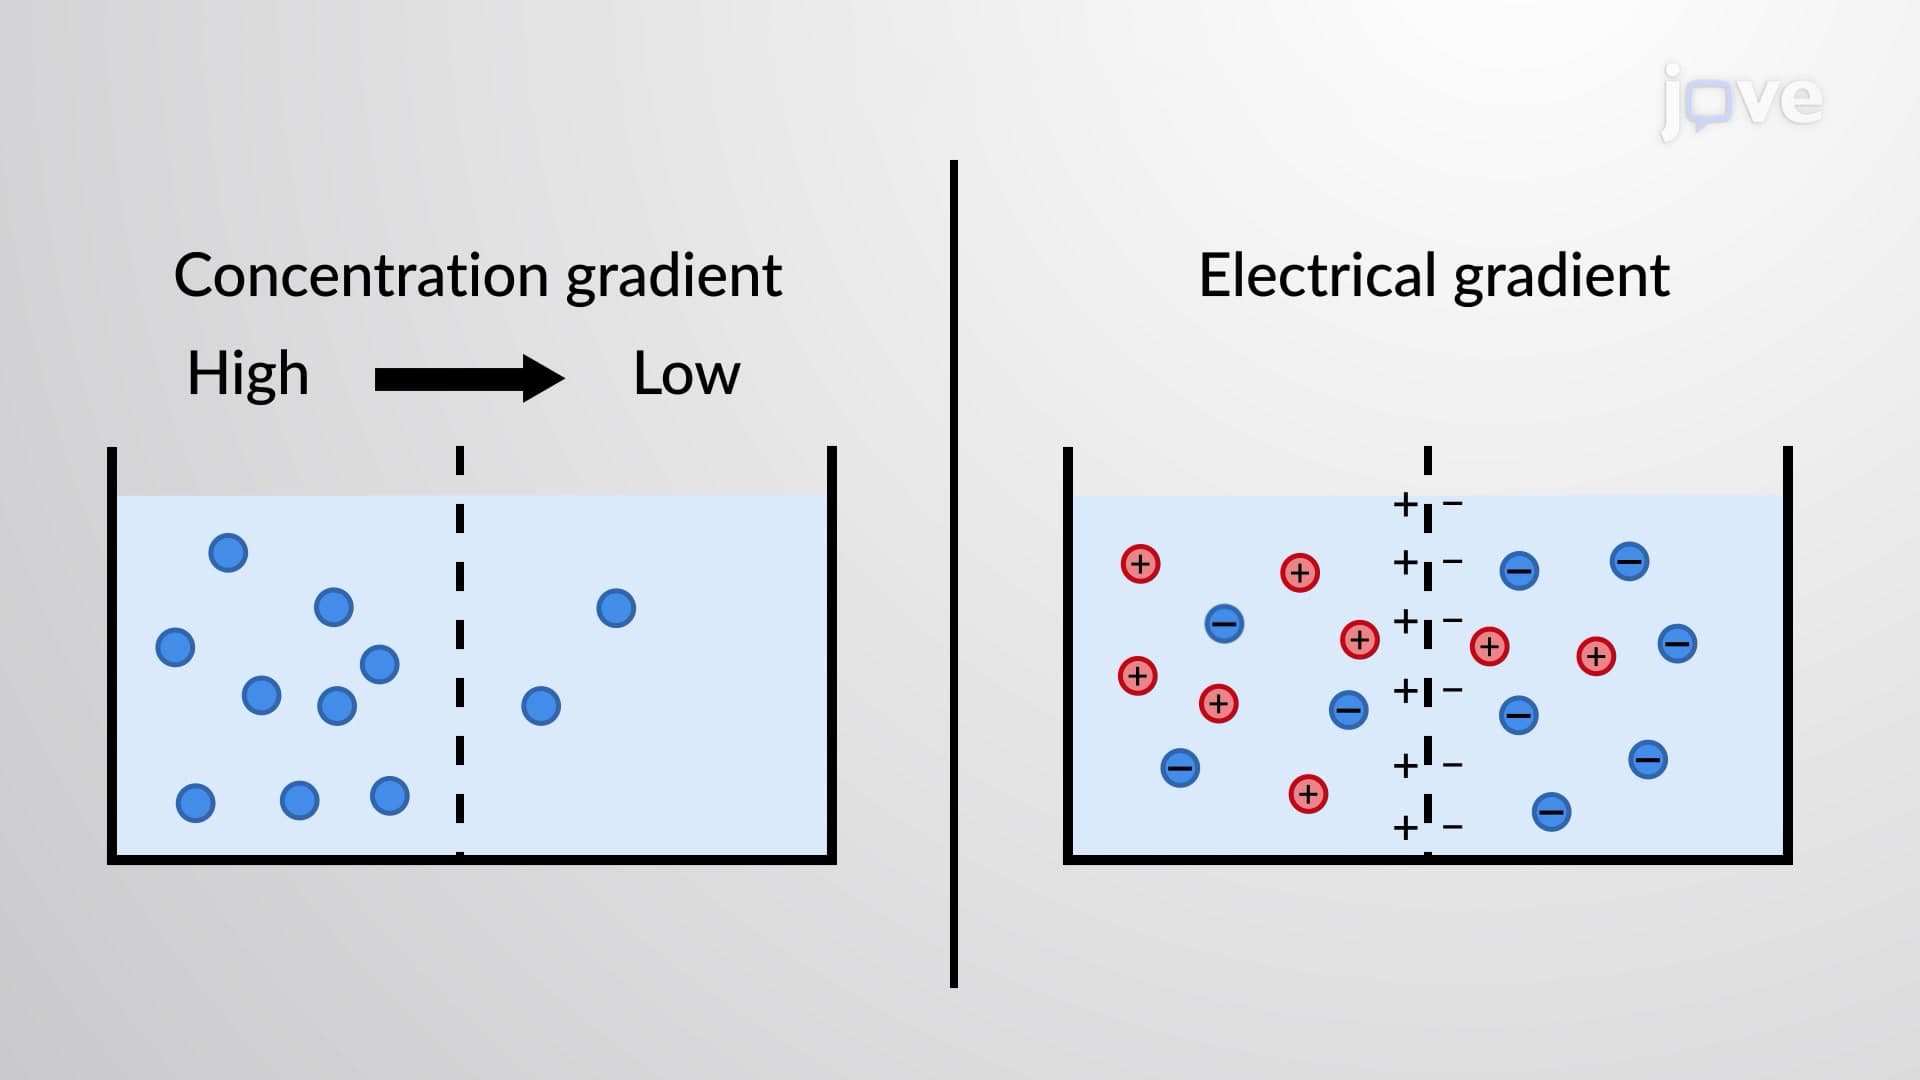
What is an Electrochemical Gradient?
The chemical gradient relies on differences in the abundance of a substance on the outside versus the inside of a cell and flows from areas of high to low ion concentration. In contrast, the electrical gradient revolves around an...
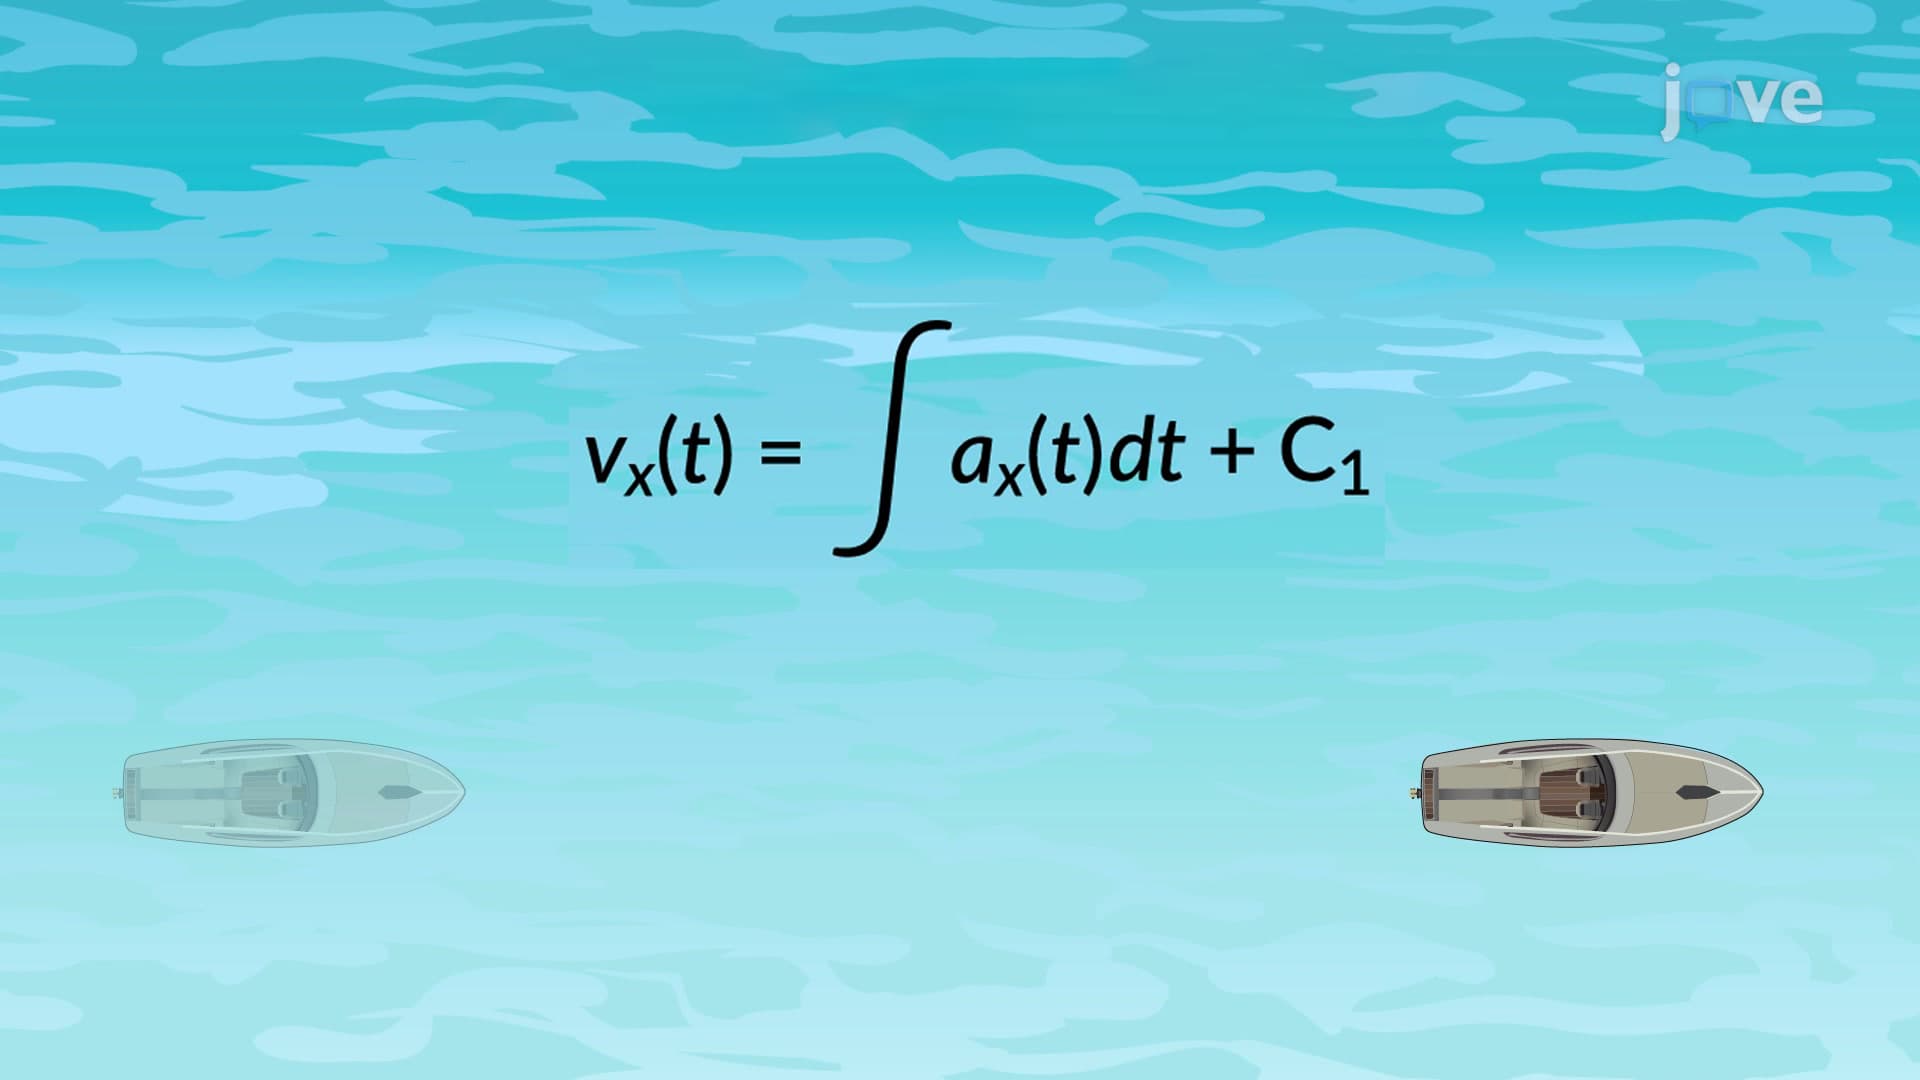 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:03
Inertial Frames of Reference
 01:27
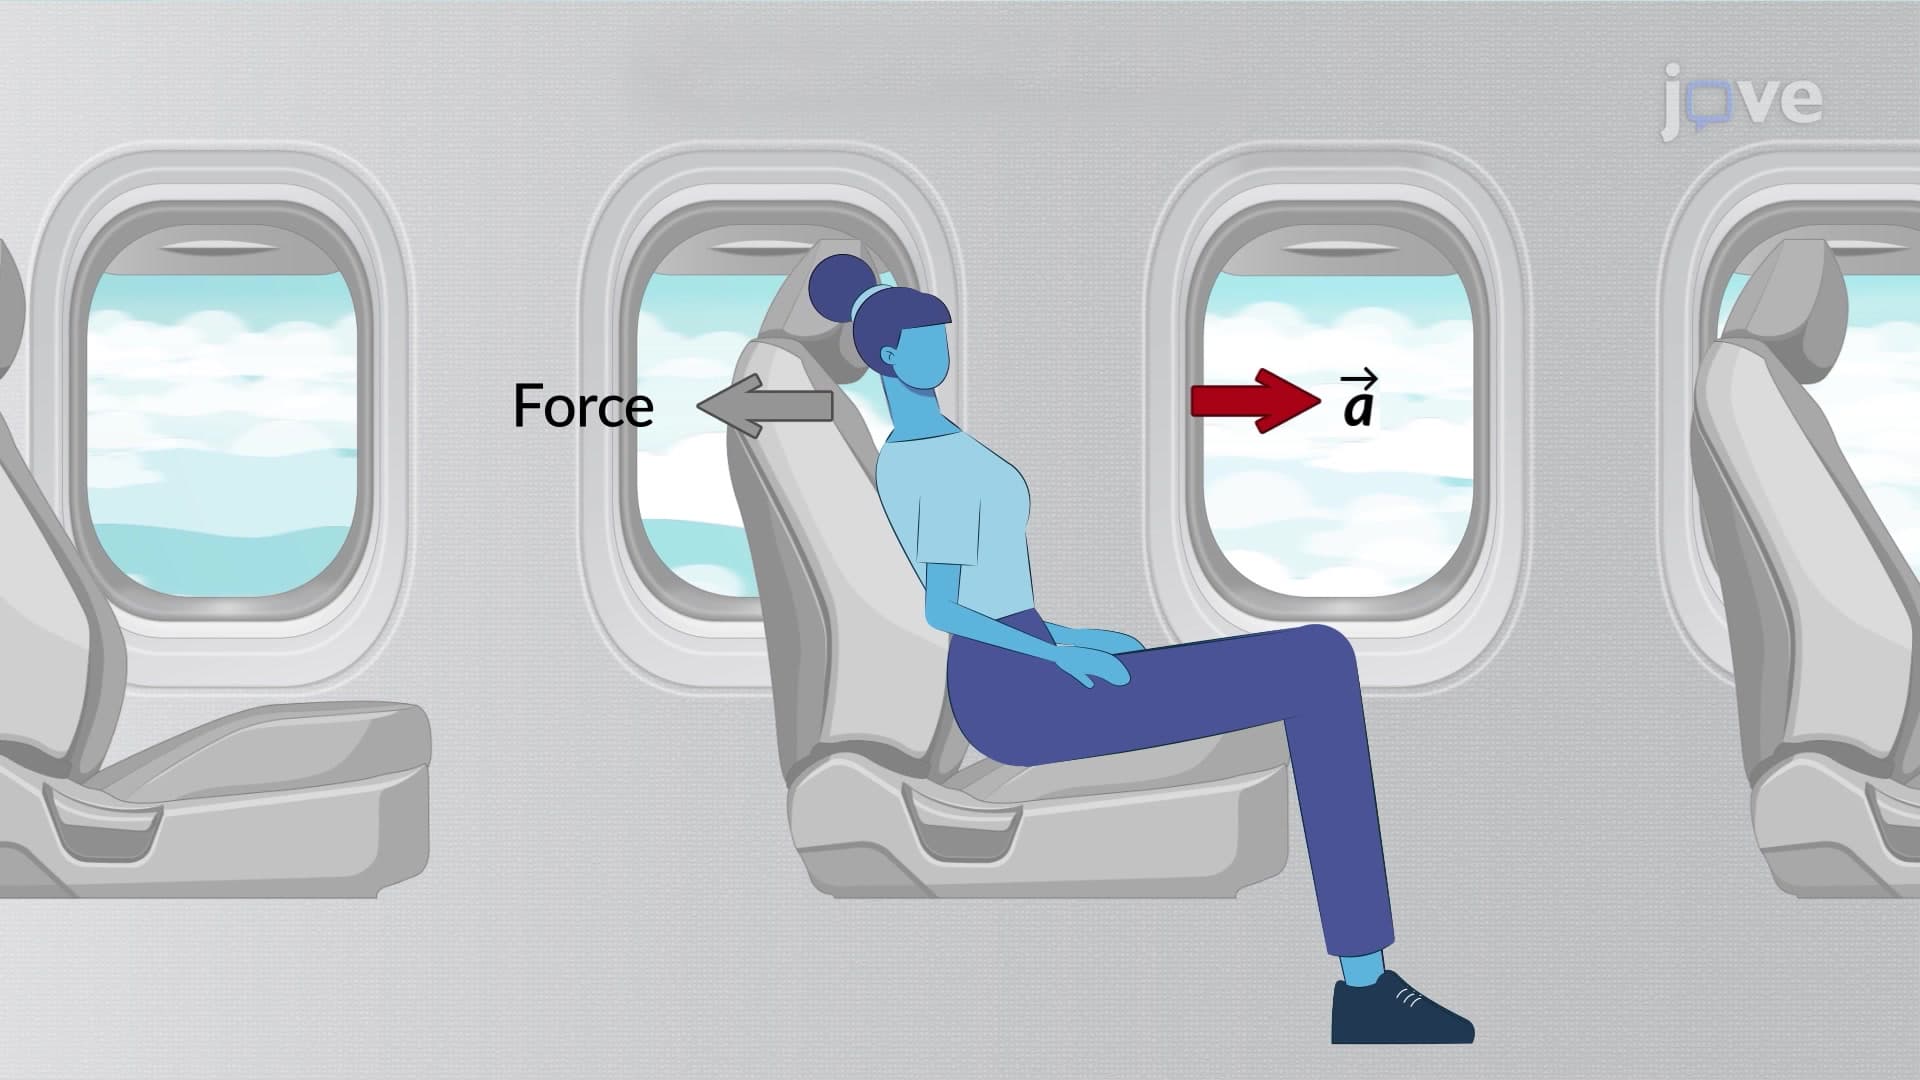
Non-inertial Frames of Reference
 01:34
Velocity and Position by Graphical Method
 01:28
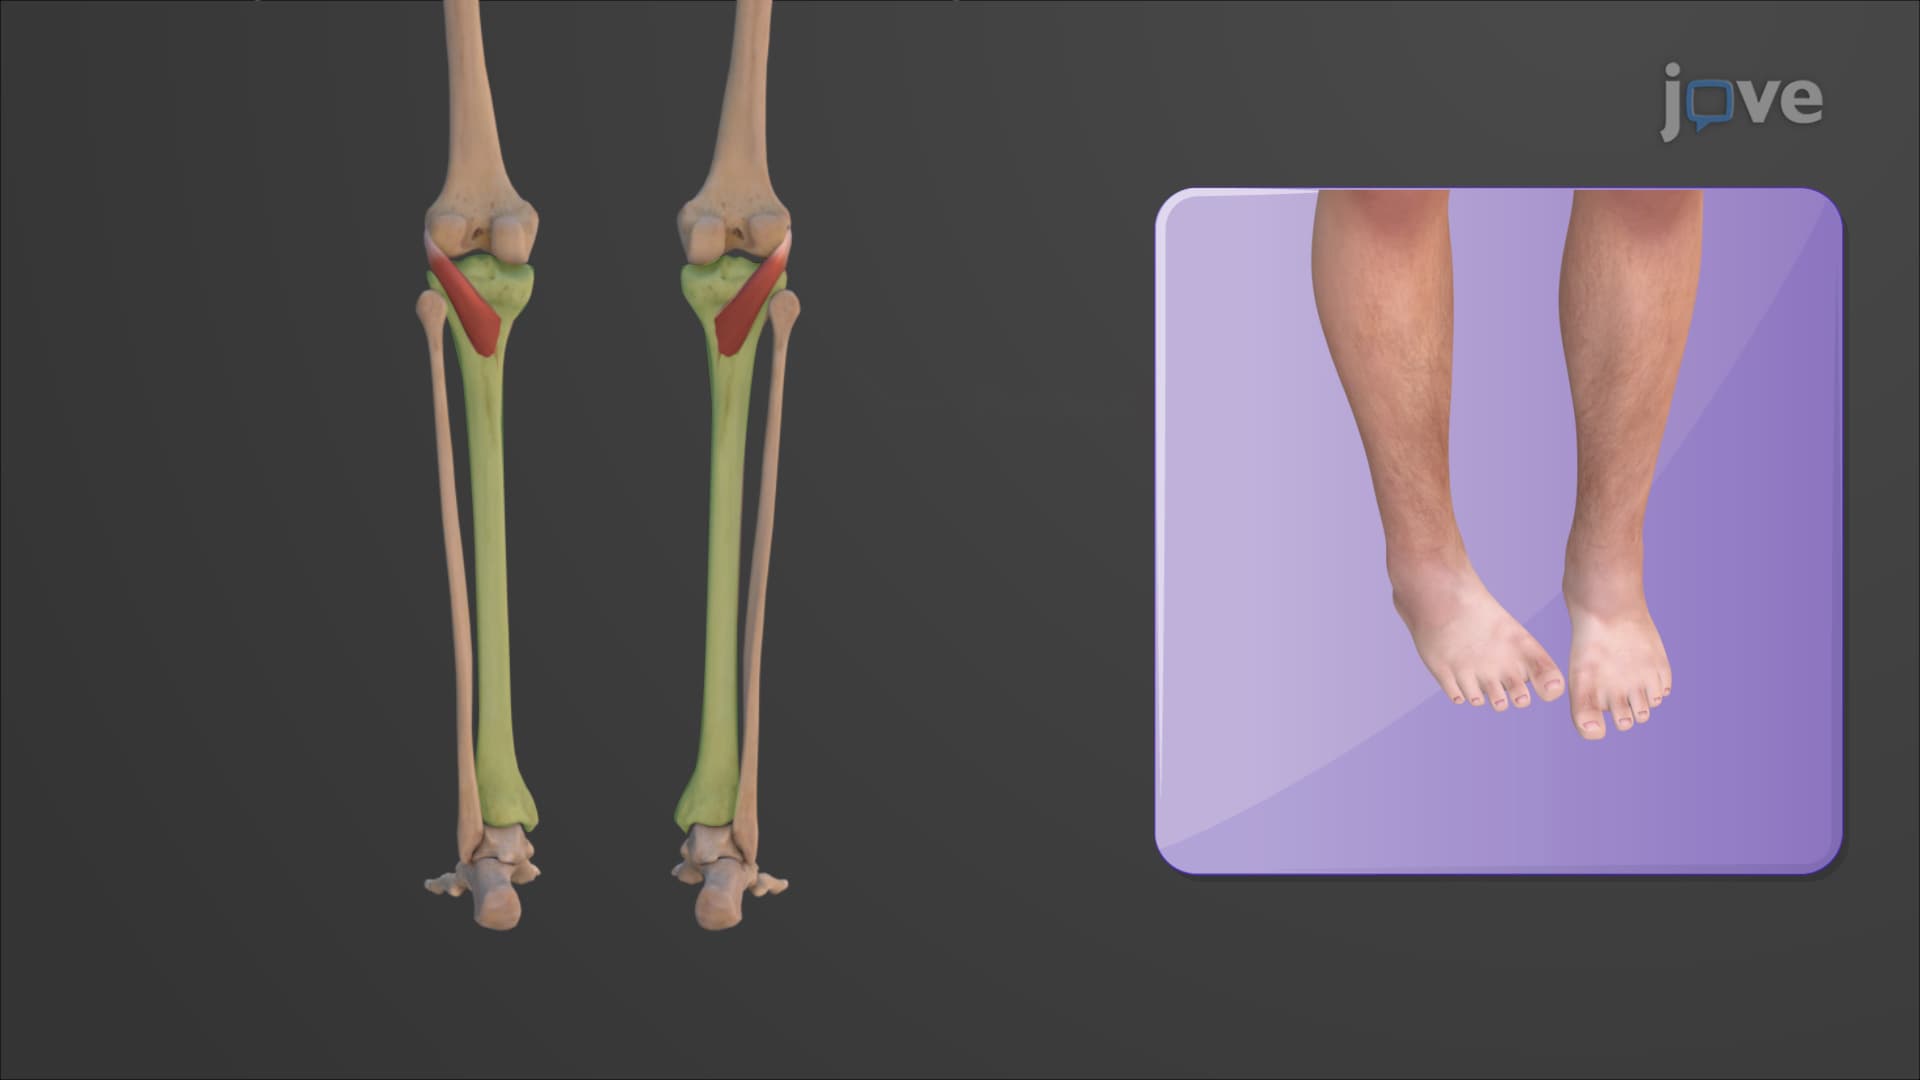
Muscles of the Leg that Move the Foot and Toes
Anterior Compartment
The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles....