Related Experiment Video
Updated: Feb 2, 2026


Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
Optimal trajectory generation for time-to-contact based aerial robotic perching
Haijie Zhang1, Bo Cheng, Jianguo Zhao
1Department of Mechanical Engineering, Colorado State University, Fort Collins, CO 80523, United States of America.

Abstract:
Many biological organisms (e.g. insects, birds, and mammals) rely on the perception of an informational variable called time-to-contact (TTC) to control their motion for various tasks such as avoiding obstacles, landing, or interception. TTC, defined as the required time to contact an object if the current velocity is maintained, has been recently leveraged for robot motion control in various tasks. However, most existing robotic applications of TTC simply control the TTC to be constant or constantly decreasing, without fully exploring the applicability for TTC. In this paper, we propose two-stage TTC based strategies and apply them to aerial robotic perching. With the proposed strategies, we can generate reference trajectories for TTC to realize the non-zero contact velocity required by perching, which is impossible for constant or constantly decreasing TTC strategy, but of critical importance for robust perching performance. We conduct simulations to verify the superiority of the proposed strategies in terms of shorter time for perching and satisfying more constraints. Further, with properly designed controllers, we perform experiments on a palm-size quadcopter to track the planned reference trajectories and realize aerial robotic perching. The research presented in this paper can be readily applied to the control of flying robot for perching with visual feedback, and can inspire more alternative forms of TTC based planning and control for robotic applications.
Related Concept Videos
 01:26
Orthogonal Trajectories
 01:22
Generation Time
 01:17
Transmission-based Precautions I: Contact, Enteric, and Droplets
Contact Precautions:
Contact precautions are the measures taken to prevent the transmission of infectious agents, especially epidemiologically important microorganisms such as MRSA or influenza, primarily transmitted through direct or indirect contact with an...
 01:13
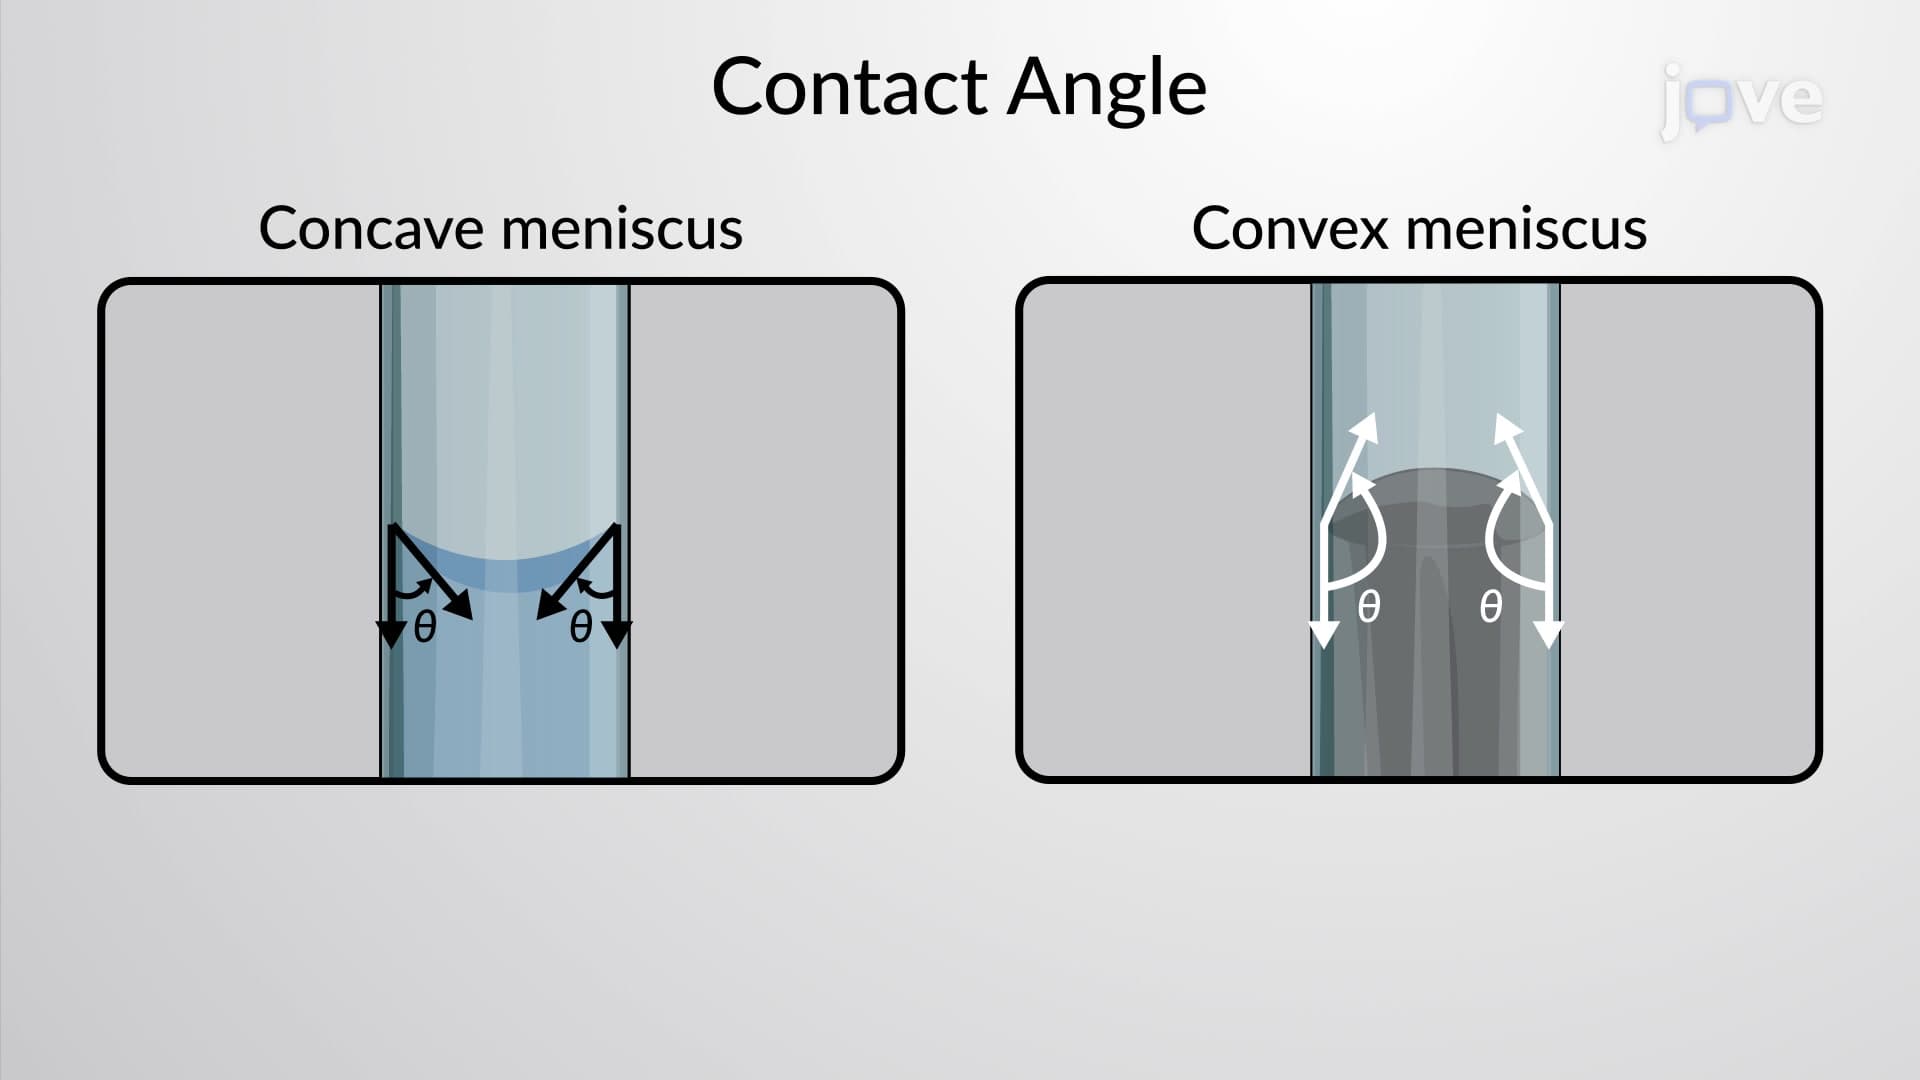
Contact Angle
The adhesive force is the molecular force between molecules of different materials, that is, between the molecules of the solid and the liquid. The cohesive...
 01:19
Contact-dependent Signaling
Gap Junctions
In animal cells, gap junctions are formed...
 00:48
Optimal Foraging