Related Experiment Video
Updated: Feb 1, 2026
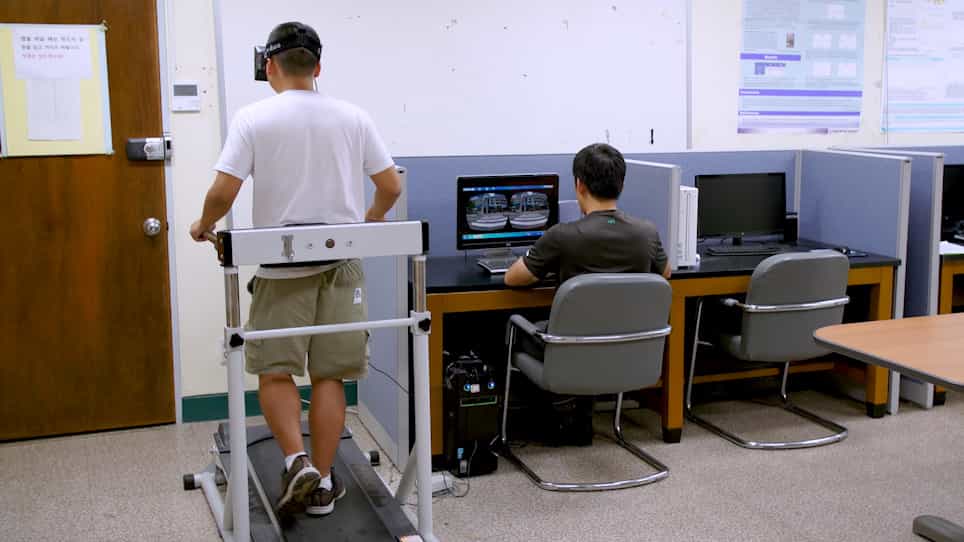
Using a Virtual Reality Walking Simulator to Investigate Pedestrian Behavior
Published on: June 9, 2020
Locomotor circumvention strategies in response to static pedestrians in a virtual and physical environment
Marco A Bühler1, Anouk Lamontagne1
1School of Physical & Occupational Therapy, McGill University, Montreal, QC, Canada; CRIR - Feil and Oberfeld Research Centre, Jewish Rehabilitation Hospital, Laval, QC, Canada.

Background:
Circumvention of pedestrians is an essential requirement of community ambulation and can be challenging to reproduce in laboratory or clinical settings. Virtual reality (VR) is a powerful tool that allows investigations, assessments or training of such tasks under ecological but controlled conditions. The extent to which current VR technologies can elicit responses similar to those observed in the physical world, however, remains to be determined.
Research Questions:
(1) To what extent does the circumvention of static pedestrians in VR differ from that observed in the physical environment (PE)? and; (2) To what extent does the inter-trial variability of obstacle circumvention outcomes differ in VR vs. the PE?
Methods:
Healthy young participants (n = 13) were assessed while walking and avoiding a collision with an interferer that stood either at 3.0 and 3.5 m from the participant's starting position (experimental trials) or that exited to the side (catch trials). The task was performed in the PE and VE, in a random order. A female collaborator acted as interferer in the PE and her kinematics was used to create the avatar used in the VE.
Results:
Compared to the PE, the circumvention of a static pedestrian in VR was characterized by larger obstacle clearances and slower walking speeds. Characteristics of circumvention strategy such as the preferred side of circumvention, response to obstacle position and pattern of speed adaptation were similar between VR and the PE. Inter-trial variability for the different outcomes were also similar between the two environments.
Significance:
Differences in obstacle clearance and speed indicate the use of "safer" circumvention strategies in VR. However, the patterns of locomotor adaptation that were largely similar between the two environments which suggests that VR is a valuable tool to study, assess and possibly train complex locomotor tasks such as obstacle avoidance.
Related Concept Videos
 01:05
Static Equilibrium - I
 01:07
Static Equilibrium - II
 01:18
Static Friction
For example, consider a scenario where a truck is connected to a car by a rope, ready to tow it along a road. When no external force is applied by the truck, the car remains stationary and is said to be in static equilibrium. In this case, the forces acting on the car, such as gravity and the...
 01:20
Virtual Work
In static equilibrium, a body can experience an imaginary or virtual movement, such as displacement or rotation. The virtual work done by a force is equal to the dot product of force and virtual displacement in the direction of the force. When it comes to virtually rotating a...
 01:28
Problem Solving in Statics
The physical situation and mathematical modeling must be considered; however, it is challenging to represent all physical situations using mathematical modeling. With the help of...
 01:16
Statically Indeterminate Problem Solving