Related Experiment Video
Updated: Feb 1, 2026

Watershed Planning within a Quantitative Scenario Analysis Framework
Published on: July 24, 2016
Multi-UAV Path Planning for Autonomous Missions in Mixed GNSS Coverage Scenarios
Flavia Causa1, Giancarmine Fasano2, Michele Grassi3
1Department of Industrial Engineering, University of Naples Federico II, Piazzale Tecchio 80, 80125 Naples, Italy. flavia.causa@unina.it.

Abstract:
This paper presents an algorithm for multi-UAV path planning in scenarios with heterogeneous Global Navigation Satellite Systems (GNSS) coverage. In these environments, cooperative strategies can be effectively exploited when flying in GNSS-challenging conditions, e.g., natural/urban canyons, while the different UAVs can fly as independent systems in the absence of navigation issues (i.e., open sky conditions). These different flight environments are taken into account at path planning level, obtaining a distributed multi-UAV system that autonomously reconfigures itself based on mission needs. Path planning, formulated as a vehicle routing problem, aims at defining smooth and flyable polynomial trajectories, whose time of flight is estimated to guarantee coexistence of different UAVs at the same challenging area. The algorithm is tested in a simulation environment directly derived from a real-world 3D scenario, for variable number of UAVs and waypoints. Its solution and computational cost are compared with optimal planning methods. Results show that the computational burden is almost unaffected by the number of UAVs, and it is compatible with near real time implementation even for a relatively large number of waypoints. The provided solution takes full advantage from the available flight resources, reducing mission time for a given set of waypoints and for increasing UAV number.
Related Concept Videos
 01:22
Mean free path and Mean free time
 01:21
Path Between Thermodynamics States
 01:22
Autonomic Nervous System
The ANS comprises two main divisions: the sympathetic and parasympathetic divisions. These divisions function antagonistically to maintain a dynamic...
 03:48
Behavior of Gas Molecules: Molecular Diffusion, Mean Free Path, and Effusion
 01:10
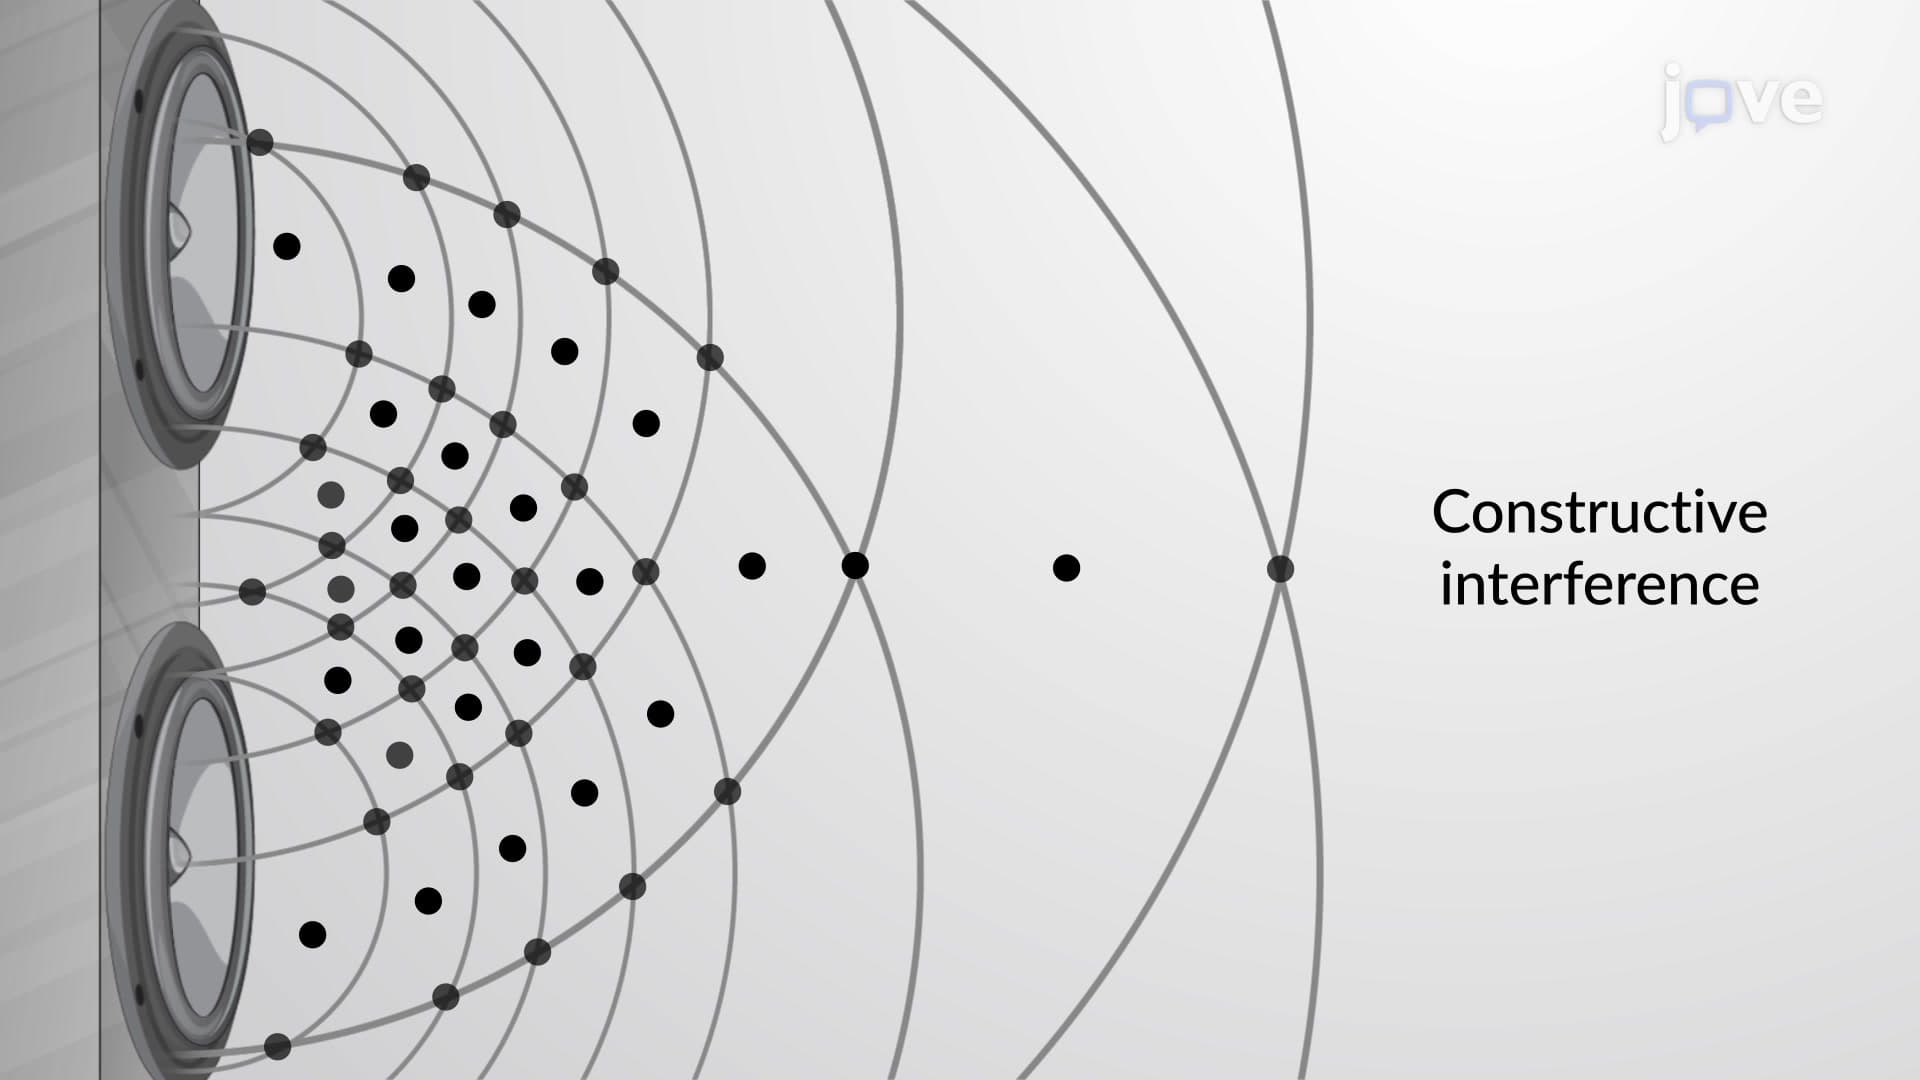
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
 01:23
Sampling Plans
Random sampling is a method where each member of the population has an equal chance of being selected for the sample. It involves selecting individuals randomly, often using random number generators or lottery-type methods. For example, when analyzing the properties of a...