The locomotor kinematics and ground reaction forces of walking giraffes
Christopher Basu1, Alan M Wilson2, John R Hutchinson2
1Structure & Motion Laboratory, Royal Veterinary College, Hawkshead Lane, North Mymms, Hatfield, Herts AL9 7TA, UK christopherbasu@gmail.com.

Abstract:
Giraffes (Giraffa camelopardalis) possess specialised anatomy. Their disproportionately elongate limbs and neck confer recognised feeding advantages, but little is known about how their morphology affects locomotor function. In this study, we examined the stride parameters and ground reaction forces from three adult giraffes in a zoological park, across a range of walking speeds. The patterns of GRFs during walking indicate that giraffes, similar to other mammalian quadrupeds, maintain a forelimb-biased weight distribution. The angular excursion of the neck has functional links with locomotor dynamics in giraffes, and was exaggerated at faster speeds. The horizontal accelerations of the neck and trunk were out of phase compared with the vertical accelerations, which were intermediate between in and out of phase. Despite possessing specialised morphology, giraffes' stride parameters were broadly predicted from dynamic similarity, facilitating the use of other quadrupedal locomotion models to generate testable hypotheses in giraffes.
Related Concept Videos
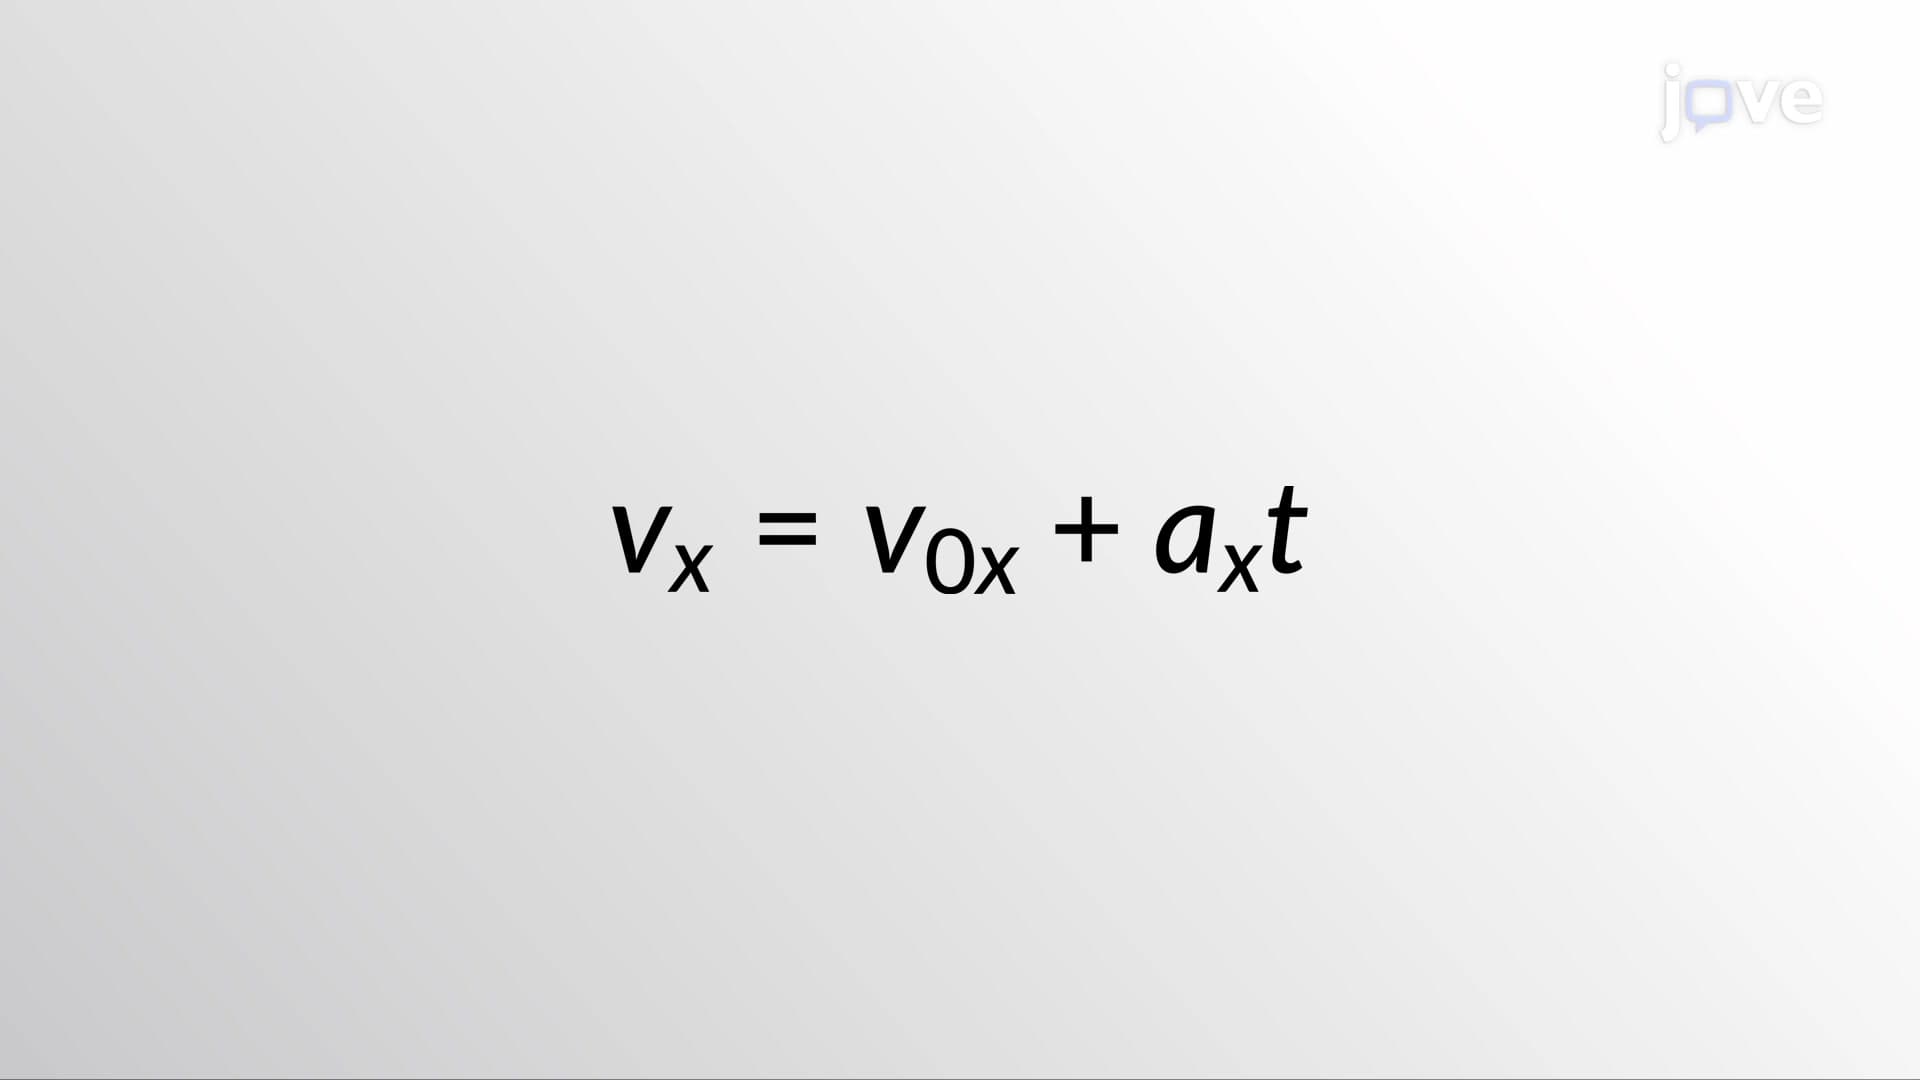 01:26
Kinematic Equations - I
 02:36
Electromotive Force
 01:12
Taping Over Different Ground Profiles
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...