Related Experiment Video
Updated: Feb 1, 2026

Structural Design and Manufacturing of a Cruiser Class Solar Vehicle
Published on: January 30, 2019
Nonlinear methods of vehicle velocity determination based on inverse systems and tensor products of Legendre
P Kubiak1, P Mierzejewska1, M Krukowski2
1Department of Vehicles and Fundamentals of Machine Design, Lodz University of Technology, 116 Żeromski Str., 90-924 Lodz, Poland.

Abstract:
The article presents research on the methods of crash velocity determination based on the Compact car class. The database used in the research is provided by the NHTSA (National Highway Traffic Safety Administration) and includes numerous frontal crash tests, which allowed the determination of the mathematical model parameters. Two methods are presented that enable the determination of vehicle velocity before the collision. The first researched method is the so-called inversed system method and is based on the assumption that the relationship between bk coefficient Cs is an inverse function. The second line of research focuses on the tensor product method, which is grounded in the Legendre polynomials, orthogonal on the interval [-1, 1] (Axler, 1997; Cheney and Kincaid, 2002). The article presents the calculation algorithm for both cases and the results with reference to the NHTSA database (Sharma et al., 2007; Siddall and Day, 1996). The application of the least square method provides more precise results in both cases than in previously researched solutions, with a slight advantage of the tensor product method. The obtained mean relative error of the velocity determination using the inverse system method is approximately 16,22% for the linear model and 10,58% for the nonlinear model. In the case of the tensor product method the errors for linear and nonlinear models are respectively 6,74% and 6,3%.
Related Concept Videos
 01:27
Real Zeros of Polynomials
 01:26
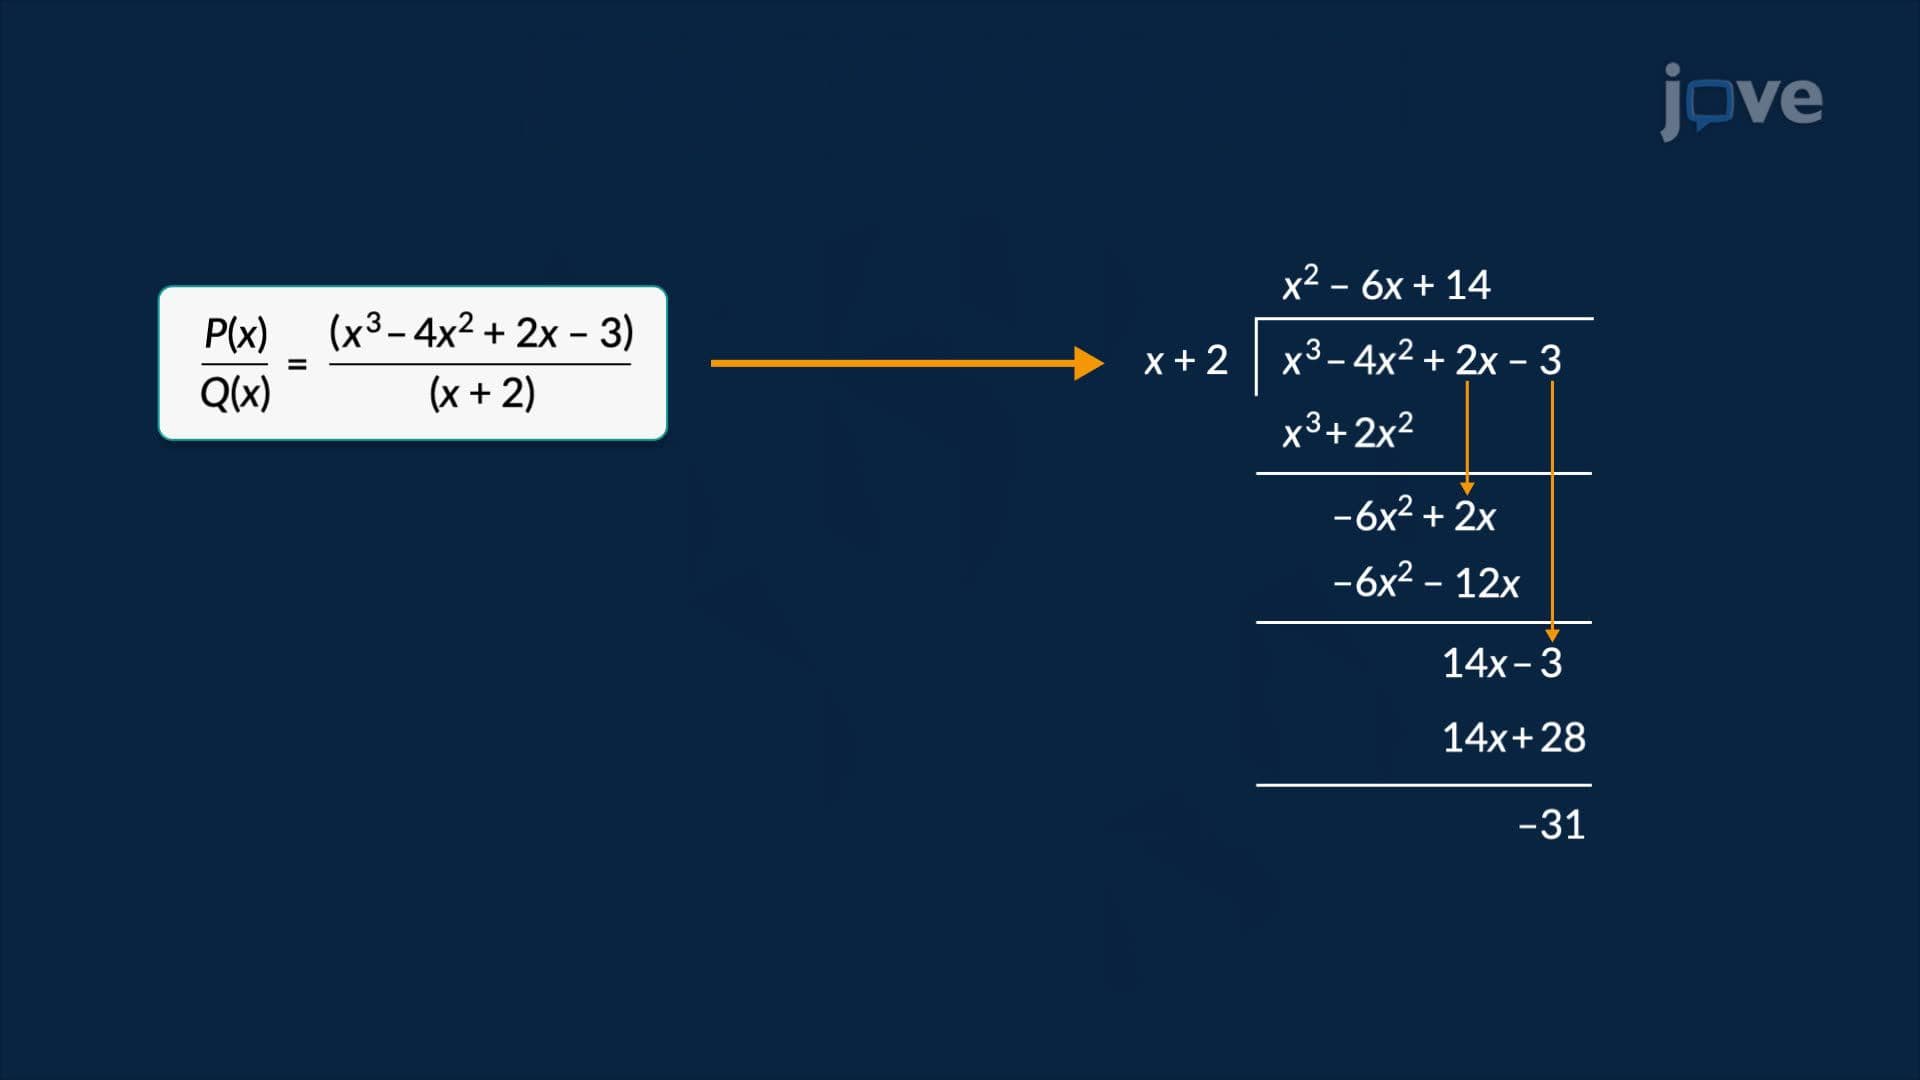
Long Division of Polynomials
 01:22
Nonlinear Pharmacokinetics: Causes of Nonlinearity
Nonlinear drug absorption can occur when the process is rate-limited by solubility, carrier-mediated transport systems, or saturation of the presystemic gut wall or hepatic metabolism. For instance, high doses of riboflavin...
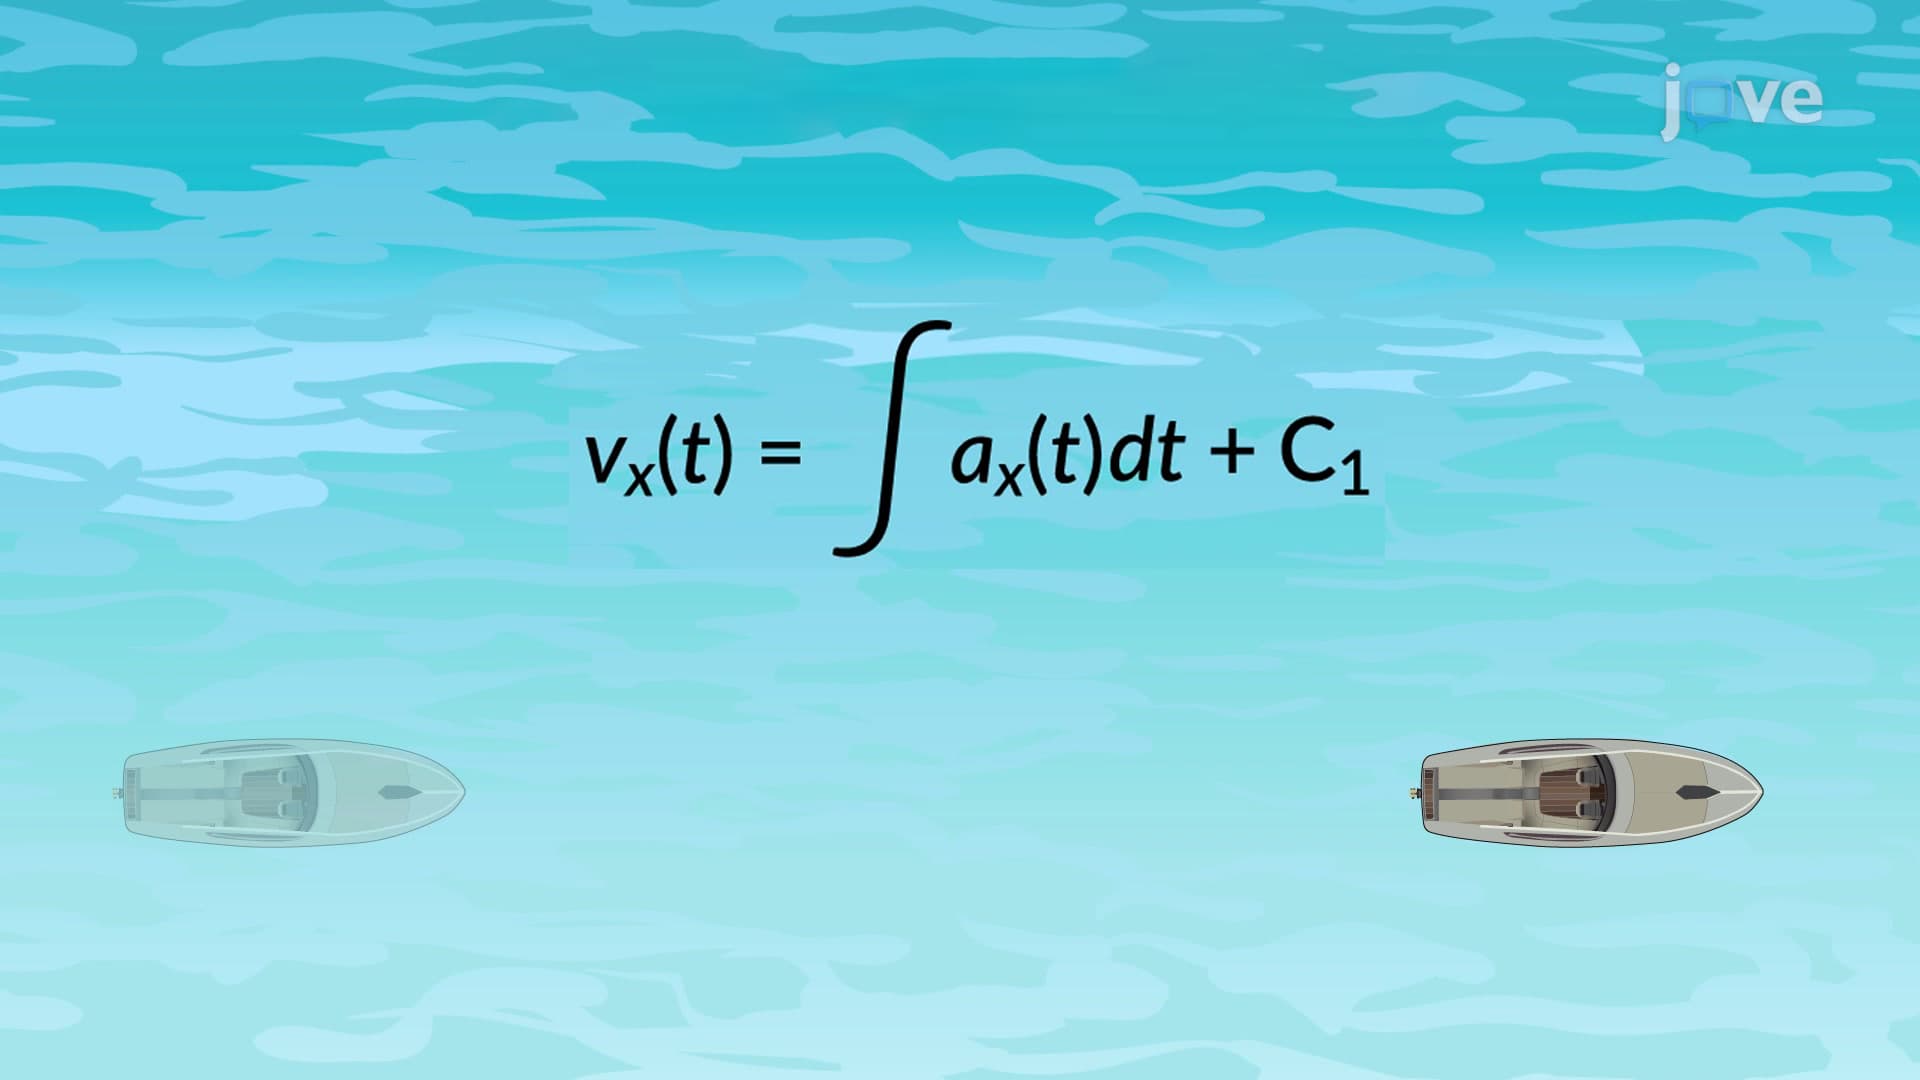 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:27
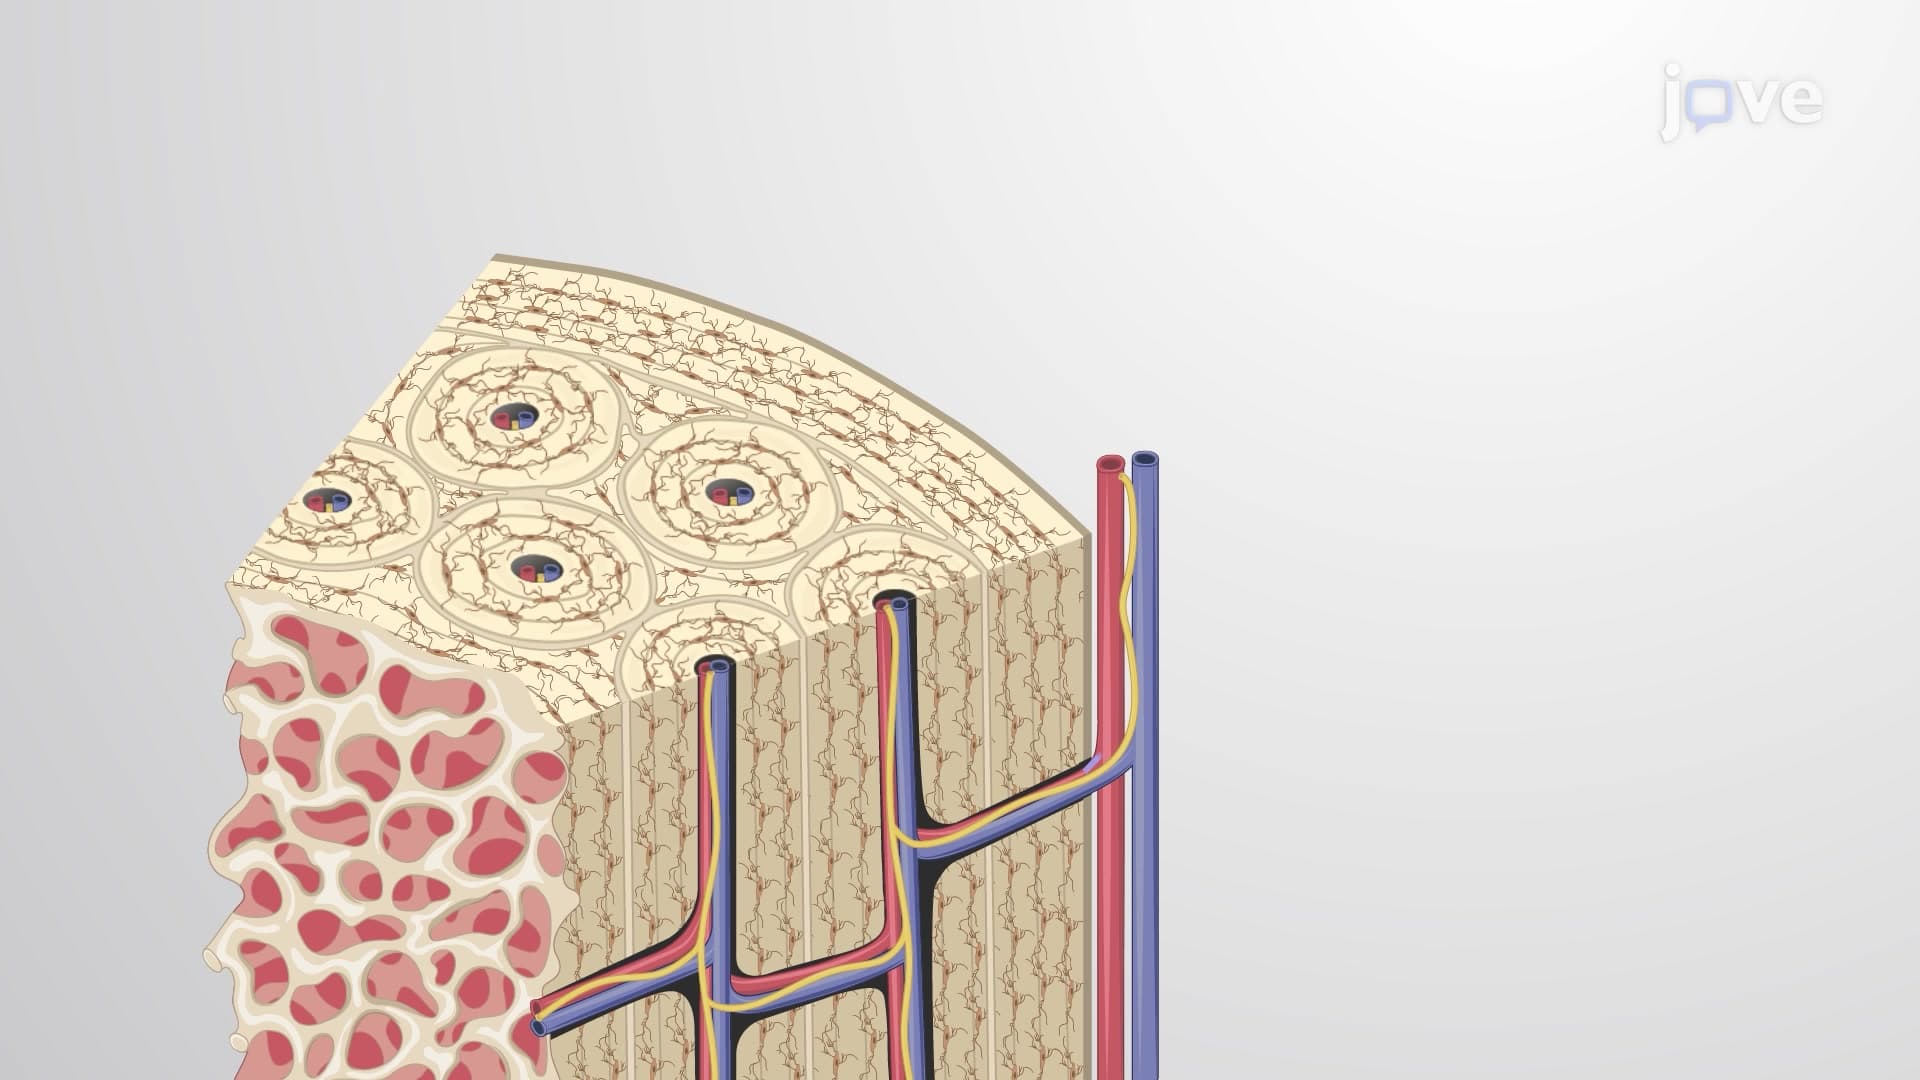
Compact Bone
Compact bone, also called cortical bone, is the denser, stronger of the two types of bone tissue. It is found under the periosteum and in the diaphyses of long bones, where it provides support and protection. The microscopic structural unit of compact bone is called an osteon, or haversian system. Each osteon is composed of concentric rings of calcified...
 01:34
Velocity and Position by Graphical Method