Related Experiment Video
Updated: Jan 31, 2026

Three Dimensional Vestibular Ocular Reflex Testing Using a Six Degrees of Freedom Motion Platform
Published on: May 23, 2013
Motion planning strategies in human control of non-rigid objects with internal degrees of freedom
Mikhail Svinin1, Igor Goncharenko1, Victor Kryssanov1
1College of Information Science and Engineering, Ritsumeikan University, 1-1-1 Nojihigashi, Kusatsu, Shiga 525-8577, Japan.

Abstract:
The paper deals with modeling of human-like reaching movements in dynamic environments. A simple but not trivial example of reaching in a dynamic environment is the rest-to-rest manipulation of a multi-mass flexible object with the elimination of residual vibrations. Two approaches to the prediction of reaching movements are formulated in position and force actuation settings. In the first approach, either the position of the hand or the hand force is specified by the lowest order polynomial satisfying the boundary conditions of the reaching task. The second approach is based on the minimization of either the hand jerk or the hand force-change, with taking into account the dynamics of the flexible object. To verify the resulting four mathematical models, an experiment on the manipulation of a ten-masses flexible object of low stiffness is conducted. The experimental results show that the second approach gives a significantly better prediction of human movements, with the minimum hand force-change model having a slight but consistent edge over the minimum hand jerk one.
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:02
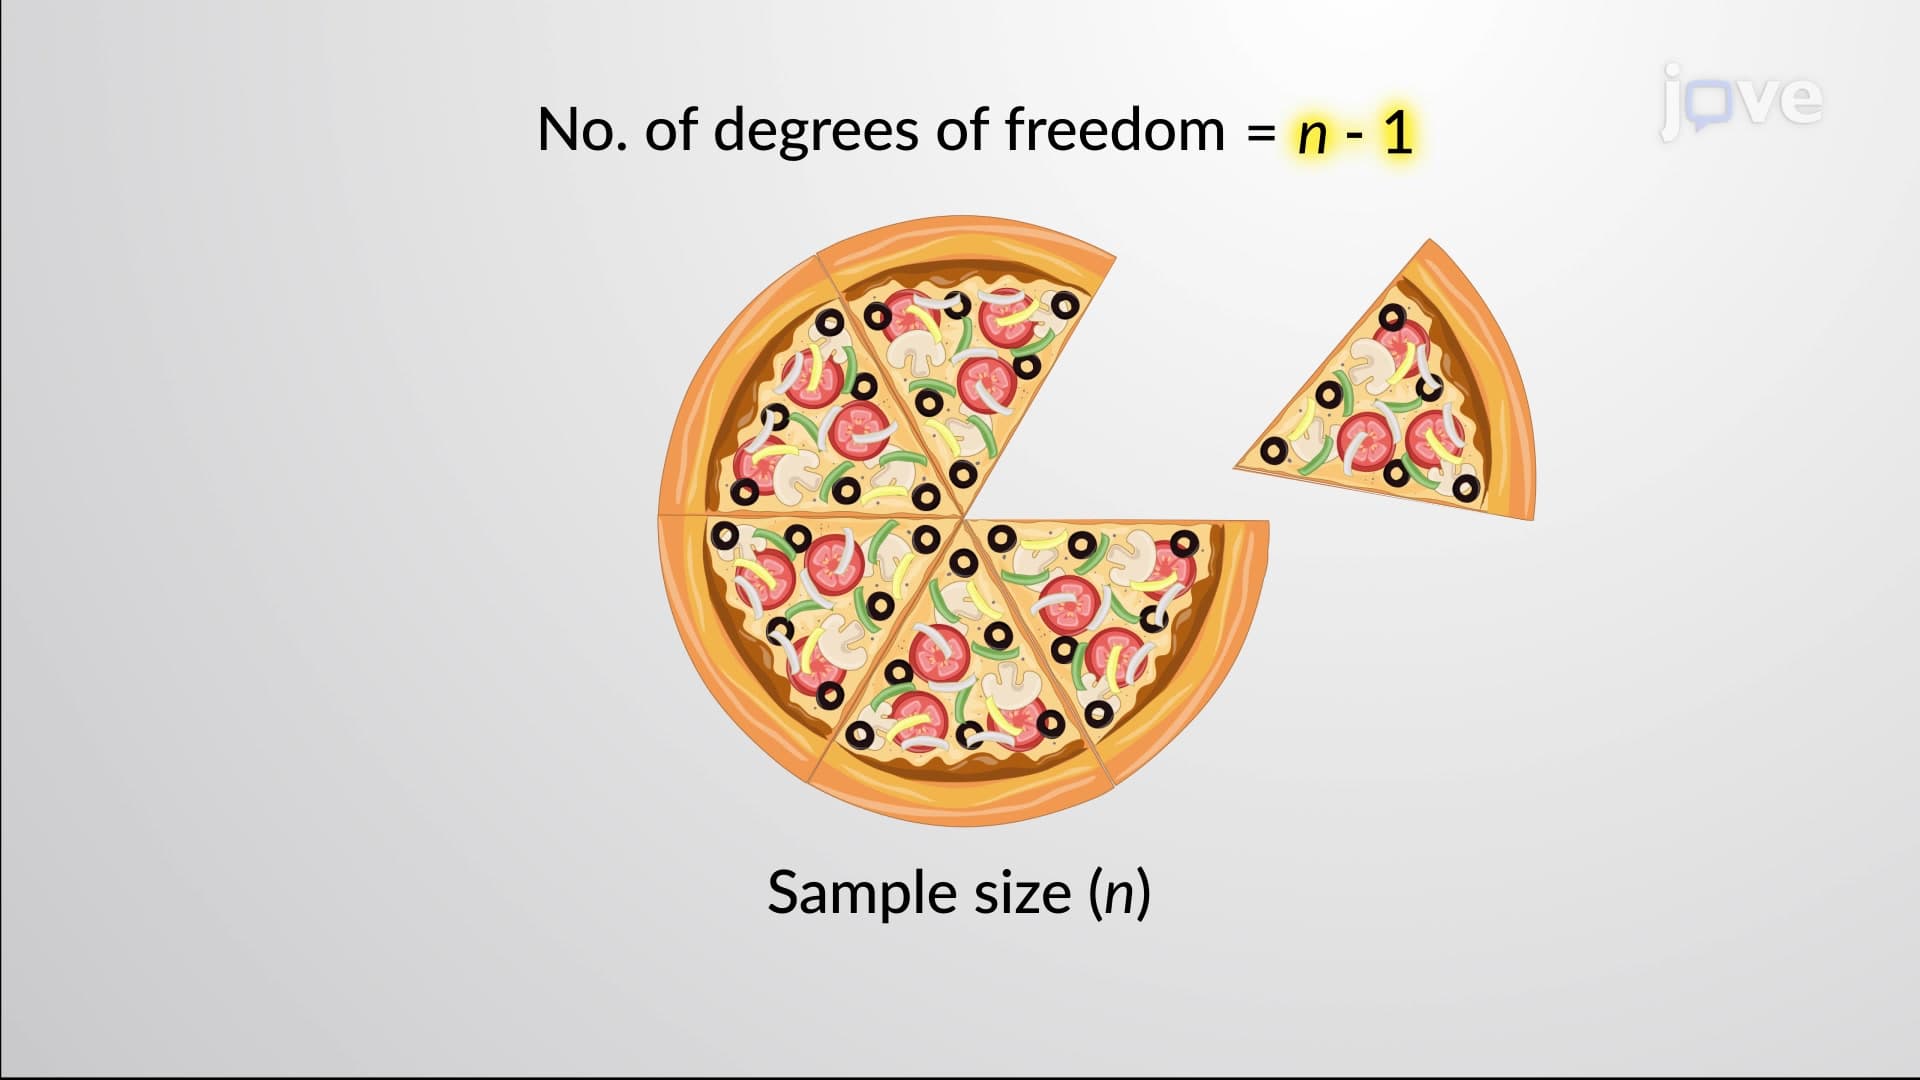
Degrees of Freedom
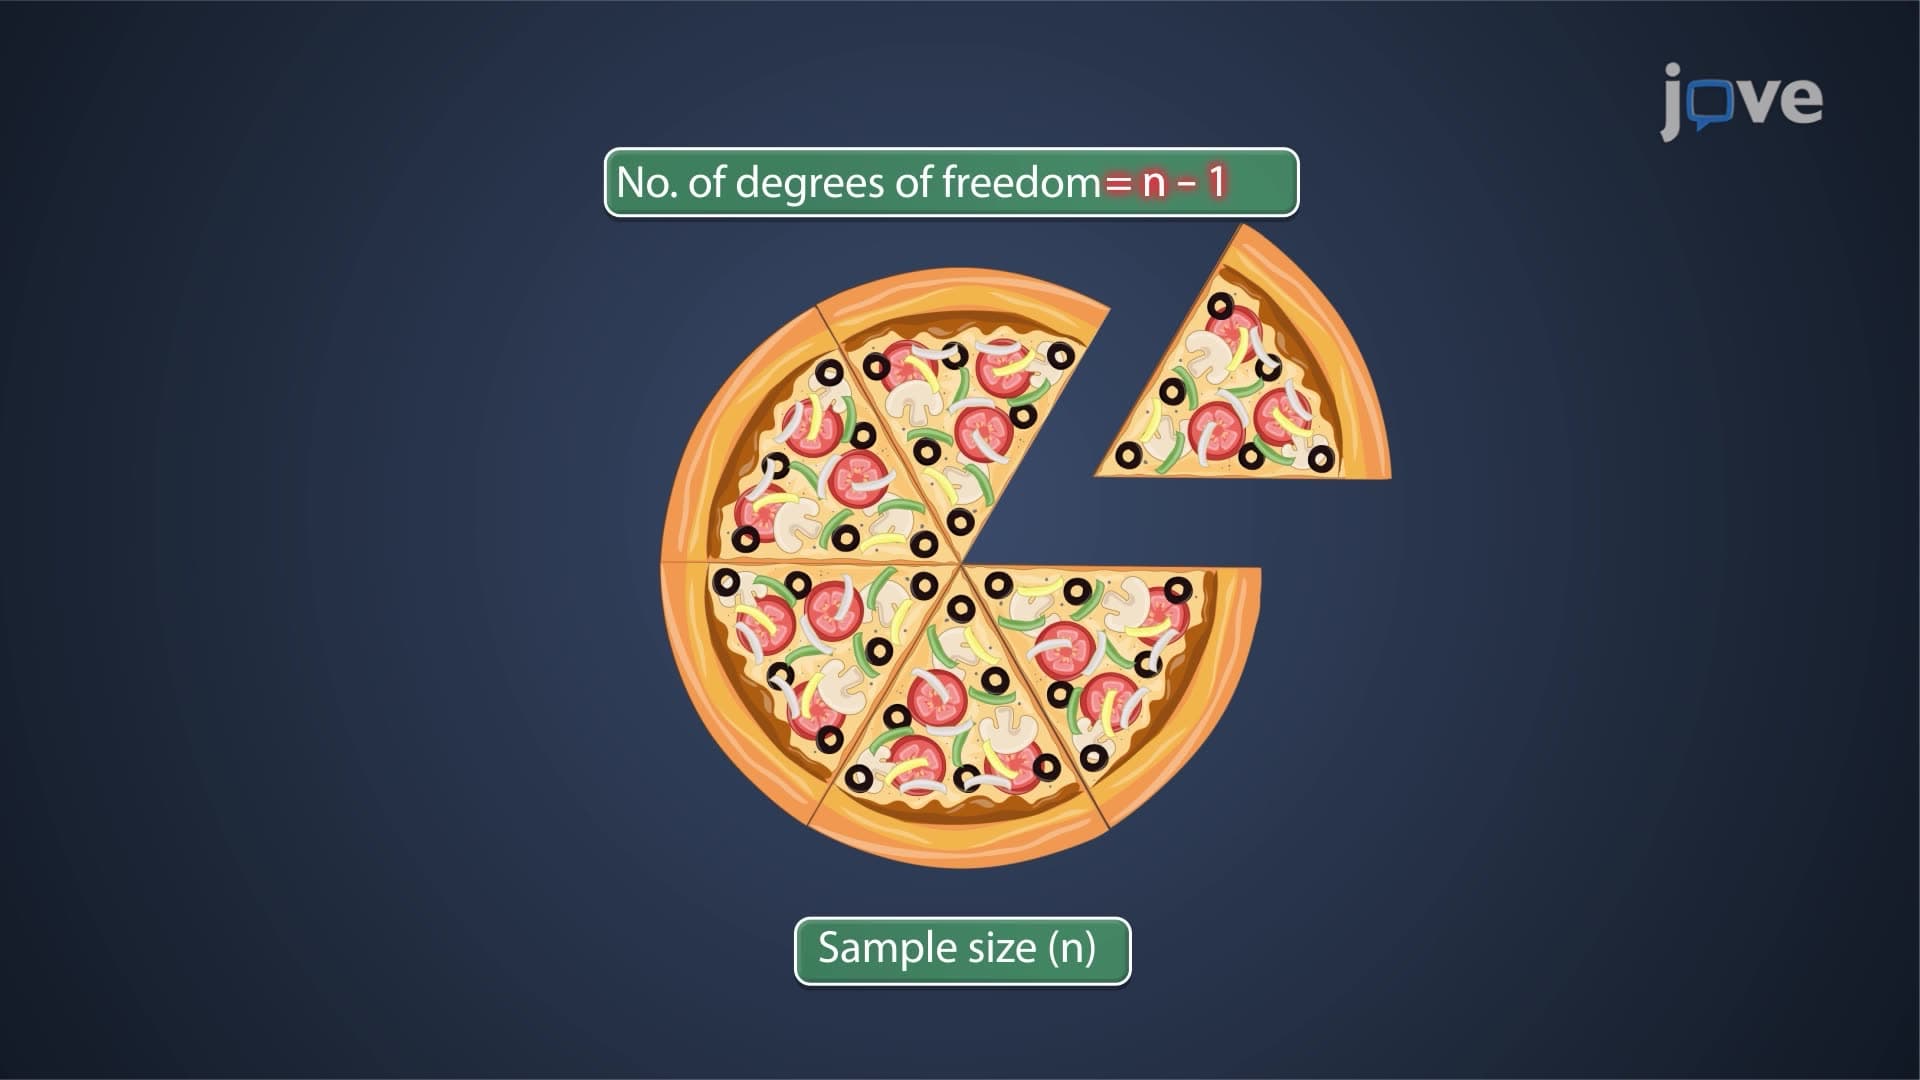
For example, suppose there are three unknown numbers whose mean is 10; although we can freely assign values to the first and second numbers, the value of the last number can not be arbitrarily assigned.
 01:02
Degrees of Freedom
For example, suppose there are three unknown numbers whose mean is 10; although we can freely assign values to the first and second numbers, the value of the last number can not be arbitrarily...
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 02:05
Degree of Unsaturation
The degree of unsaturation for hydrocarbons is U = (2C + 2 − H) / 2, where C is the number of carbon atoms and H is the number of hydrogen atoms.