Related Experiment Video
Updated: Jan 31, 2026

Control of Eating Behavior Using a Novel Feedback System
Published on: May 8, 2018
Dynamic output feedback H∞ control for 2D fuzzy systems
Lizhen Li1, Xiaofeng Li2, Shuxia Ye3
1The School of Mathematics and Physics, Shanghai University of Electric Power, Shanghai 200090, China.

Abstract:
In this paper, the dynamic output feedback H∞ control problem is considered for two-dimensional discrete fuzzy systems described by the second Fornasini-Marchesini state-space model. By introducing novel slacked matrices, sufficient criteria are established to guarantee an H∞ noise attenuation of the resulting closed-loop system. Then the proposed output feedback H∞ controller design method is applied to one-dimensional discrete-time fuzzy systems. It is worth mentioning that there is no rank constraints to system matrices. Moreover, the sufficient criteria are expressed as strict linear matrix inequalities, which can be effectively solved via MATLAB LMI toolbox. Finally, the effectiveness and advantage of the proposed approach are shown through two simulation examples.
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:10
Control Systems
At the heart...
 01:23
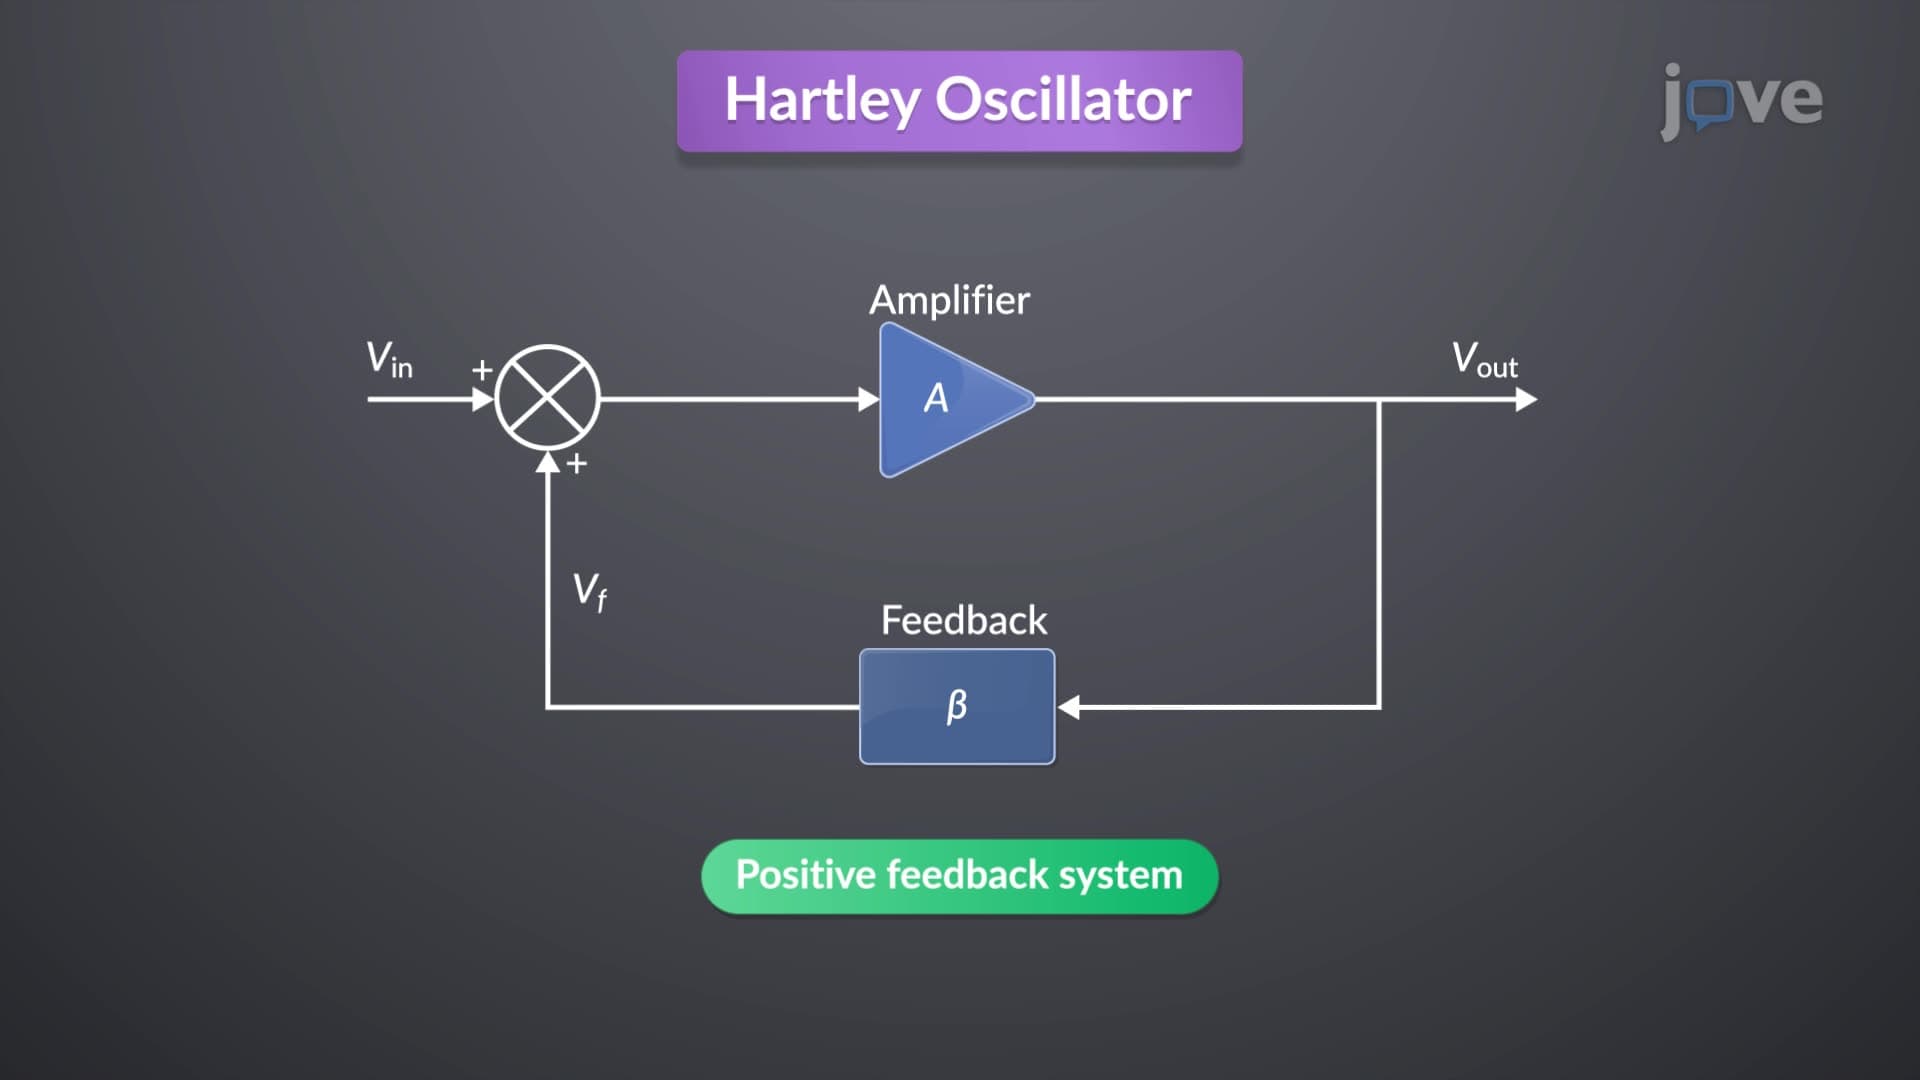
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 00:46
Feedback Inhibition
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...