Related Experiment Video
Updated: Jan 31, 2026
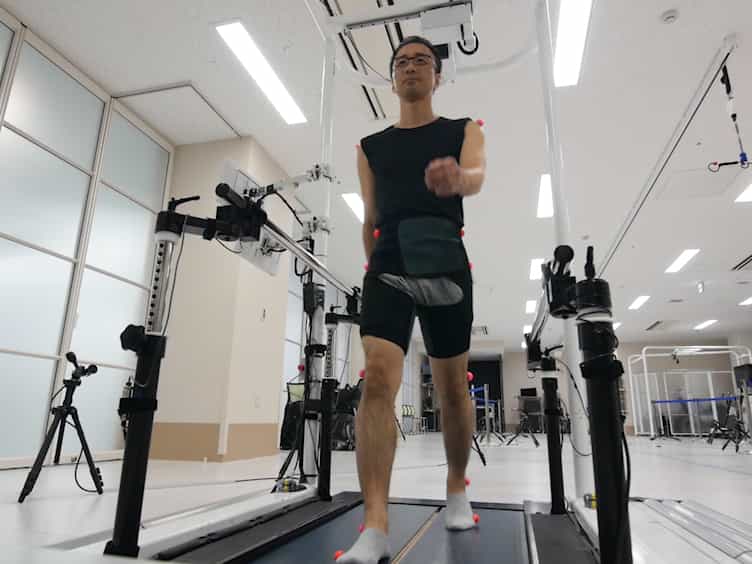

Clinical-oriented Three-dimensional Gait Analysis Method for Evaluating Gait Disorder
Published on: March 4, 2018
An Inverse Dynamics Optimization Formulation With Recursive B-Spline Derivatives and Partition of Unity Contacts:

Abstract:
In this study, an inverse dynamics optimization formulation and solution procedure is developed for musculoskeletal simulations. The proposed method has three main features: high order recursive B-spline interpolation, partition of unity, and inverse dynamics formulation. First, joint angle and muscle force profiles are represented by recursive B-splines. The formula for high order recursive B-spline derivatives is derived for state variables calculation. Second, partition of unity is used to handle the multicontact indeterminacy between human and environment during the motion. The global forces and moments are distributed to each contacting point through the corresponding partition ratio. Third, joint torques are inversely calculated from equations of motion (EOM) based on state variables and contacts to avoid numerical integration of EOM. Therefore, the design variables for the optimization problem are joint angle control points, muscle force control points, knot vector, and partition ratios for contacting points. The sum of muscle stress/activity squared is minimized as the cost function. The constraints are imposed for human physical constraints and task-based constraints. The proposed formulation is demonstrated by simulating a trajectory planning problem of a planar musculoskeletal arm with six muscles. In addition, the gait motion of a two-dimensional musculoskeletal model with sixteen muscles is also optimized by using the approach developed in this paper. The gait optimal solution is obtained in about 1 min central processing unit (CPU) time. The predicted kinematics, kinetics, and muscle forces have general trends that are similar to those reported in the literature.

Related Concept Videos
 01:25
Inverse Hyperbolic Functions and Their Derivatives
 01:30
Derivatives of Inverse Trigonometric Functions
 01:19
Contact-dependent Signaling
Gap Junctions
In animal cells, gap junctions are formed...
 01:31
Muscles that Move the Arm
The pectoralis major has two origins. Its clavicular head originates on the medial half of the clavicle. In contrast, the sternocostal head originates on the costal cartilages of ribs 1-6, the sternum, and the aponeurosis of the external oblique of the...
 01:29
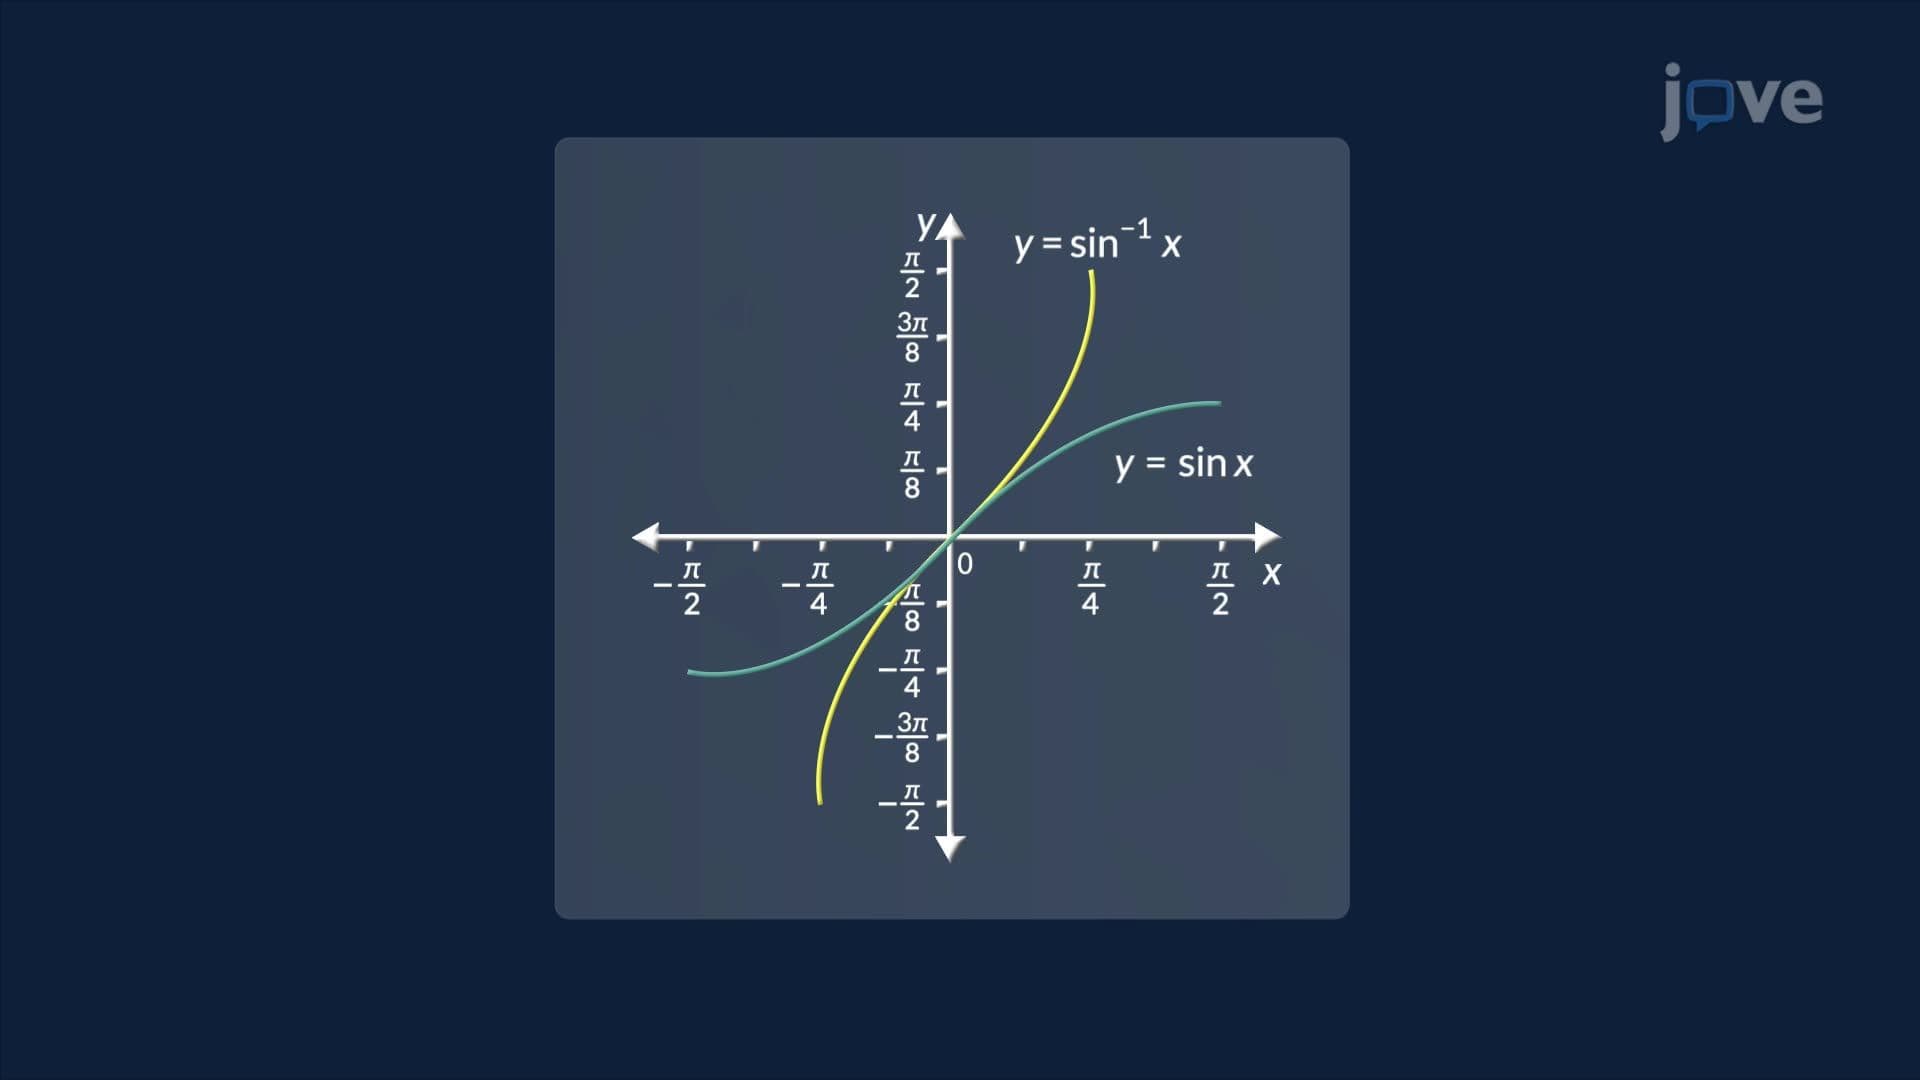
Inverse Trigonometric Functions
 01:13
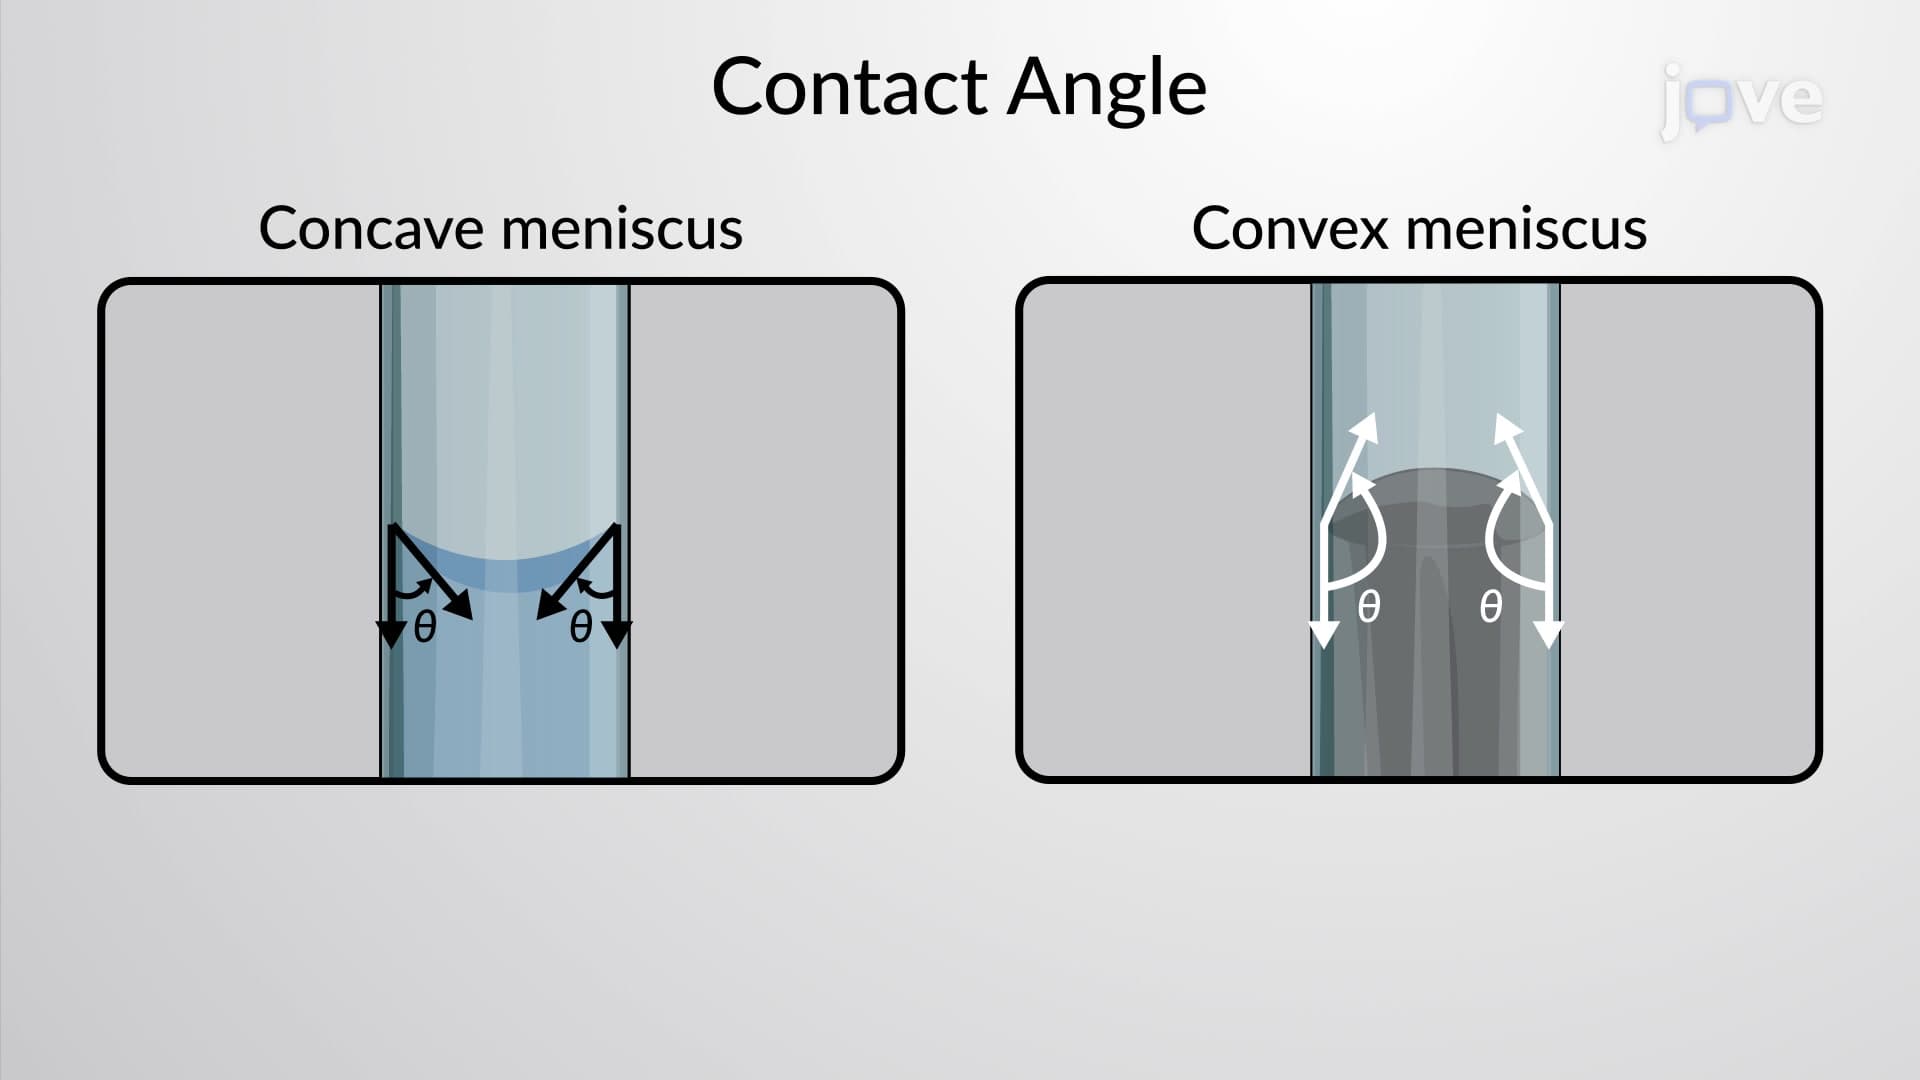
Contact Angle
The adhesive force is the molecular force between molecules of different materials, that is, between the molecules of the solid and the liquid. The cohesive...