Related Experiment Video
Updated: Jan 31, 2026

TMS: Using the Theta-Burst Protocol to Explore Mechanism of Plasticity in Individuals with Fragile X Syndrome and Autism
Published on: December 28, 2010
Efficient Lazy Theta* Path Planning over a Sparse Grid to Explore Large 3D Volumes with a Multirotor UAV
Margarida Faria1, Ricardo Marín2, Marija Popović3
1Center for Advanced Aerospace Technologies, Calle Wilbur y Orville Wright, 19, 41300 La Rinconada, Sevilla, Spain. mfaria@catec.aero.

Abstract:
Exploring large, unknown, and unstructured environments is challenging for Unmanned Aerial Vehicles (UAVs), but they are valuable tools to inspect large structures safely and efficiently. The Lazy Theta* path-planning algorithm is revisited and adapted to generate paths fast enough to be used in real time and outdoors in large 3D scenarios. In real unknown scenarios, a given minimum safety distance to the nearest obstacle or unknown space should be observed, increasing the associated obstacle detection queries, and creating a bottleneck in the path-planning algorithm. We have reduced the dimension of the problem by considering geometrical properties to speed up these computations. On the other hand, we have also applied a non-regular grid representation of the world to increase the performance of the path-planning algorithm. In particular, a sparse resolution grid in the form of an octree is used, organizing the measurements spatially, merging voxels when they are of the same state. Additionally, the number of neighbors is trimmed to match the sparse tree to reduce the number of obstacle detection queries. The development methodology adopted was Test-Driven Development (TDD) and the outcome was evaluated in real outdoors flights with a multirotor UAV. In the results, the performance shows over 90 percent decrease in overall path generation computation time. Furthermore, our approach scales well with the safety distance increases.
Related Concept Videos
 01:22
Mean free path and Mean free time
 01:21
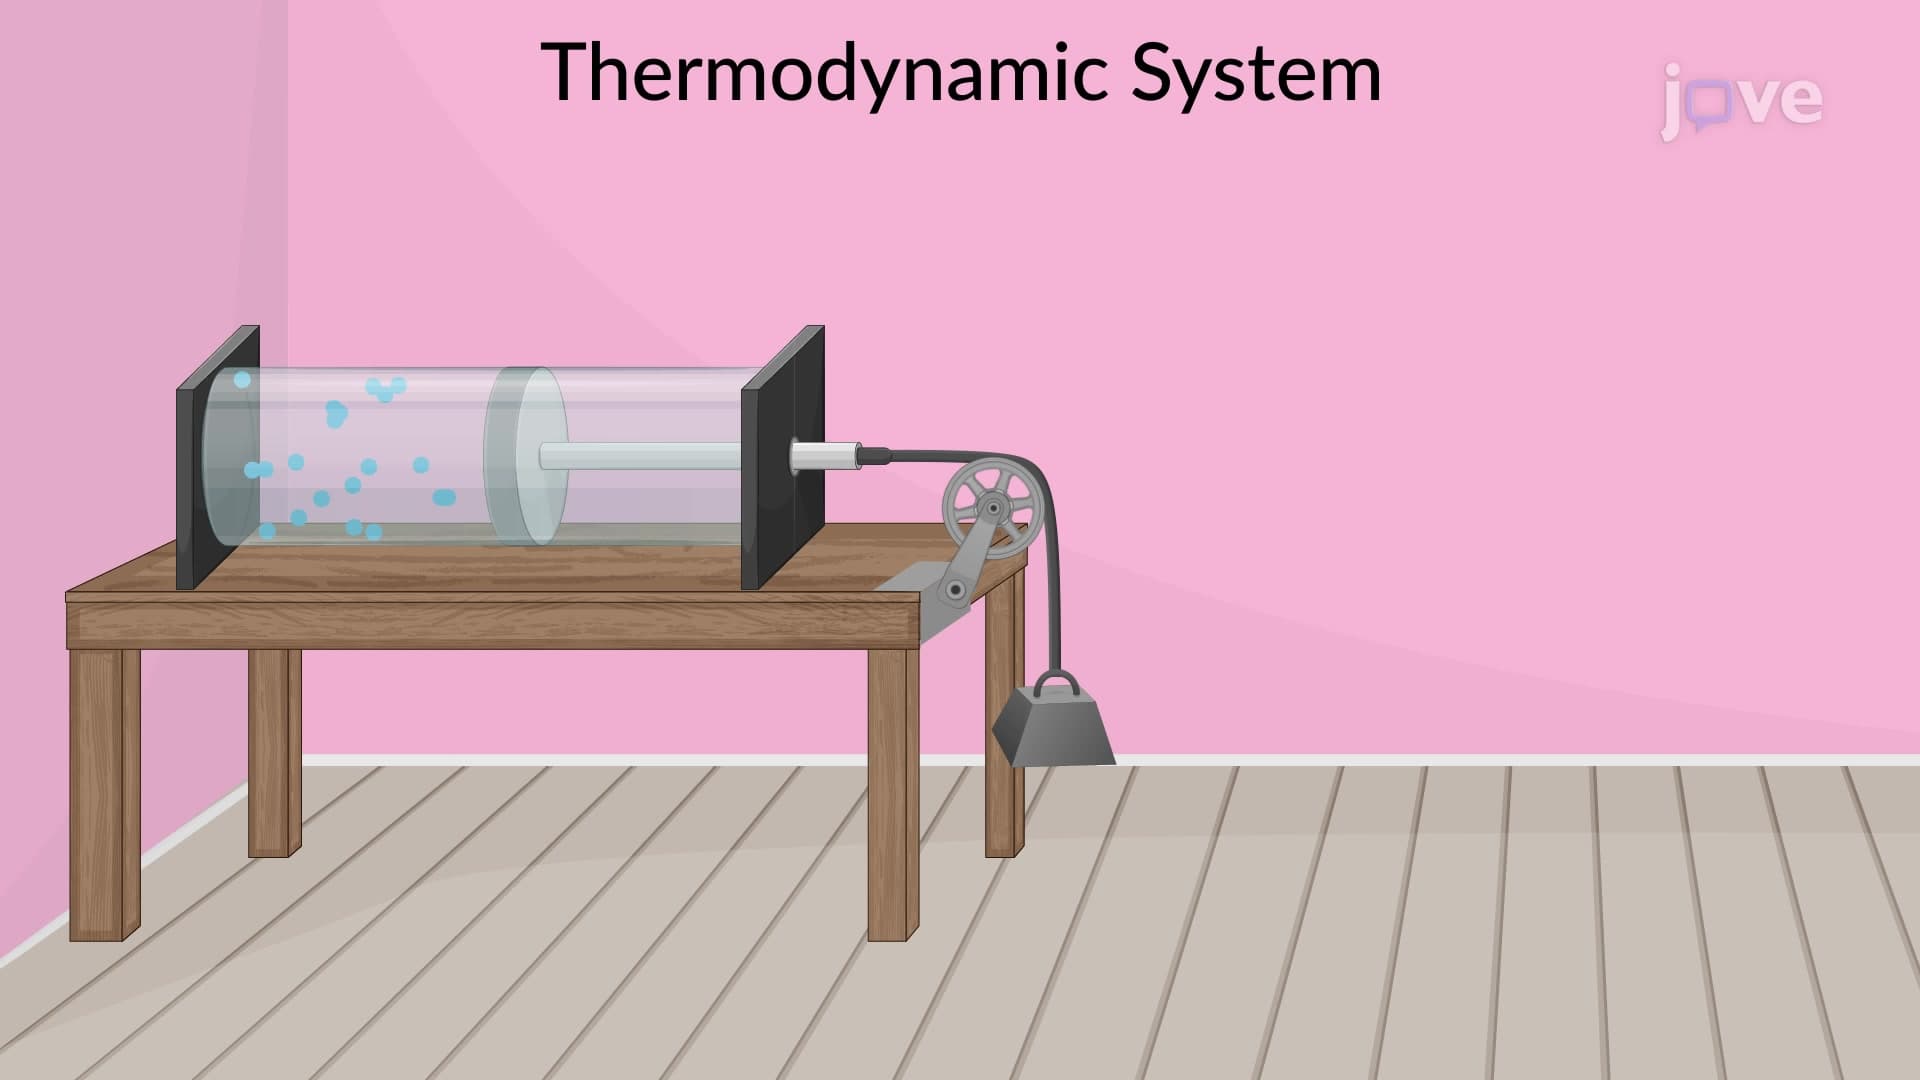
Path Between Thermodynamics States
 01:10
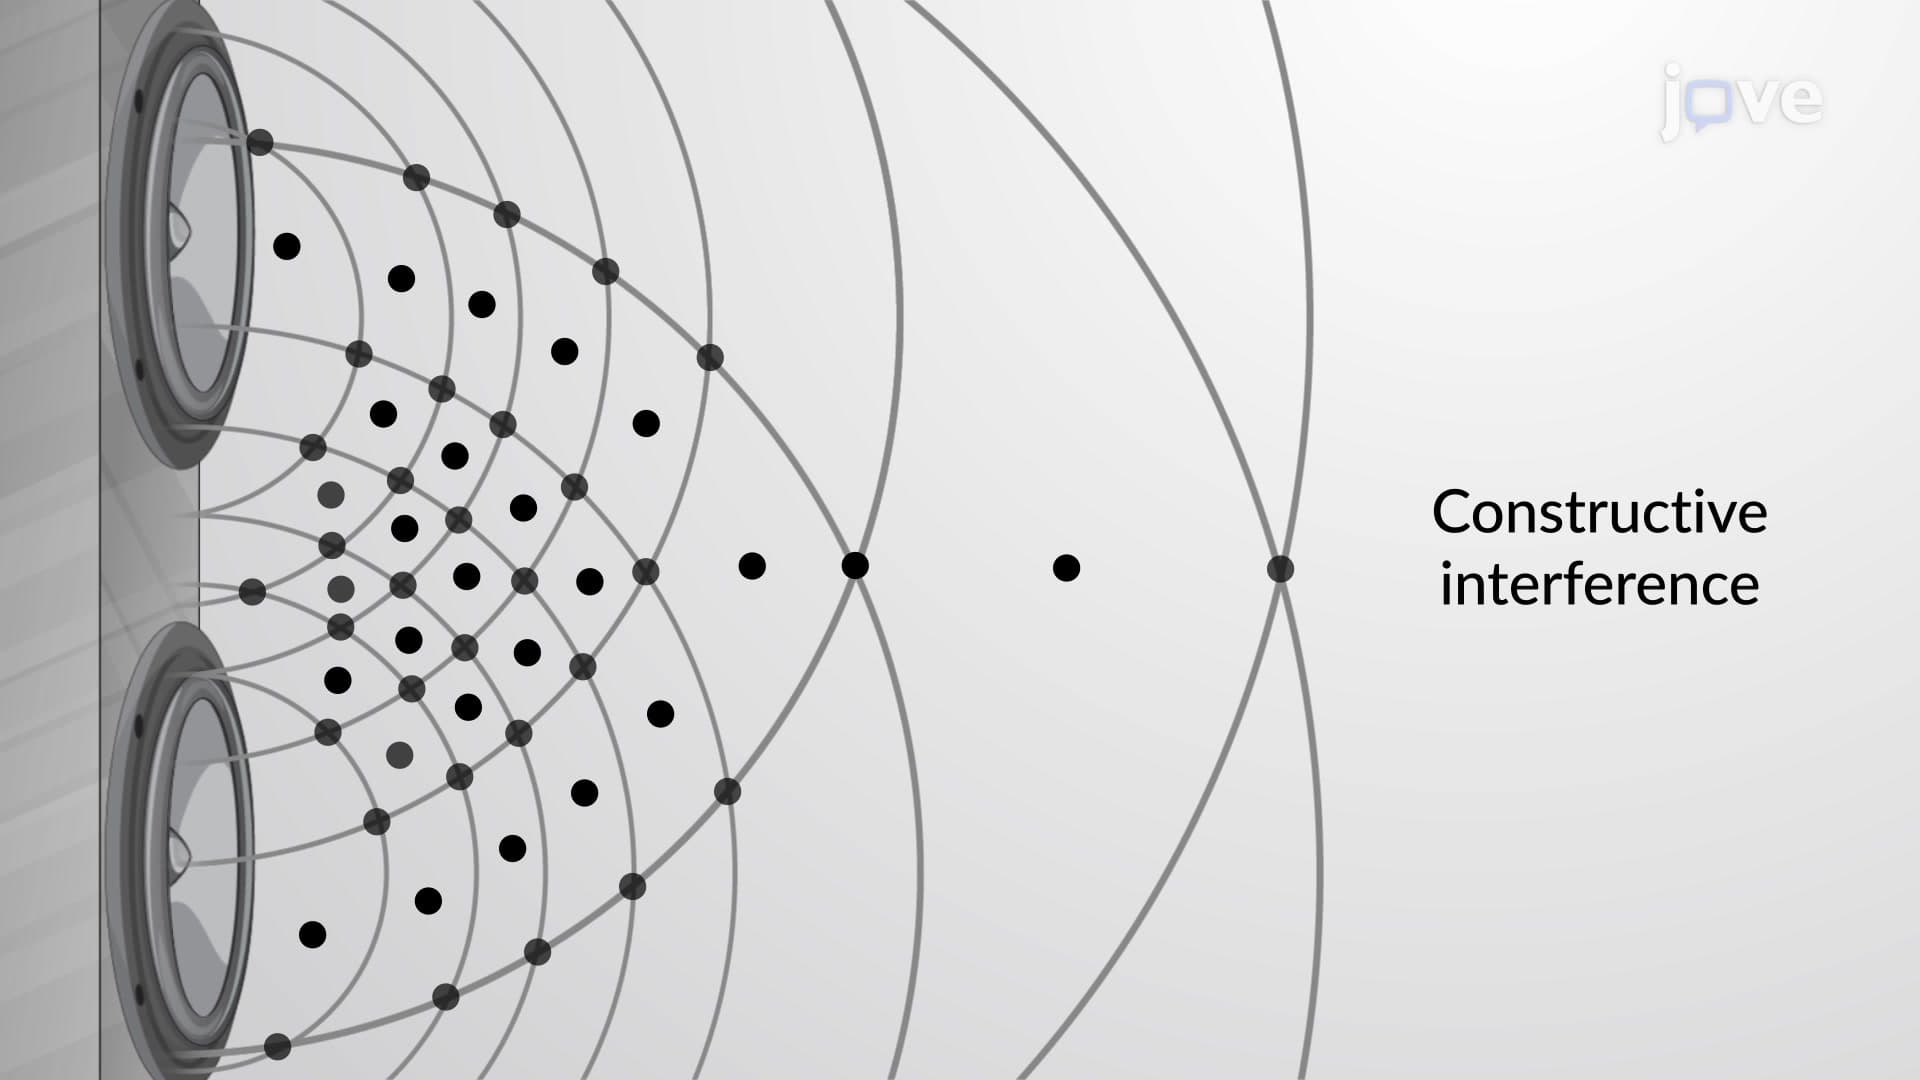
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
 03:48
Behavior of Gas Molecules: Molecular Diffusion, Mean Free Path, and Effusion
 01:23
Sampling Plans
Random sampling is a method where each member of the population has an equal chance of being selected for the sample. It involves selecting individuals randomly, often using random number generators or lottery-type methods. For example, when analyzing the properties of a...
 01:21
Planning Nursing Care I