Related Experiment Video
Updated: Jan 30, 2026
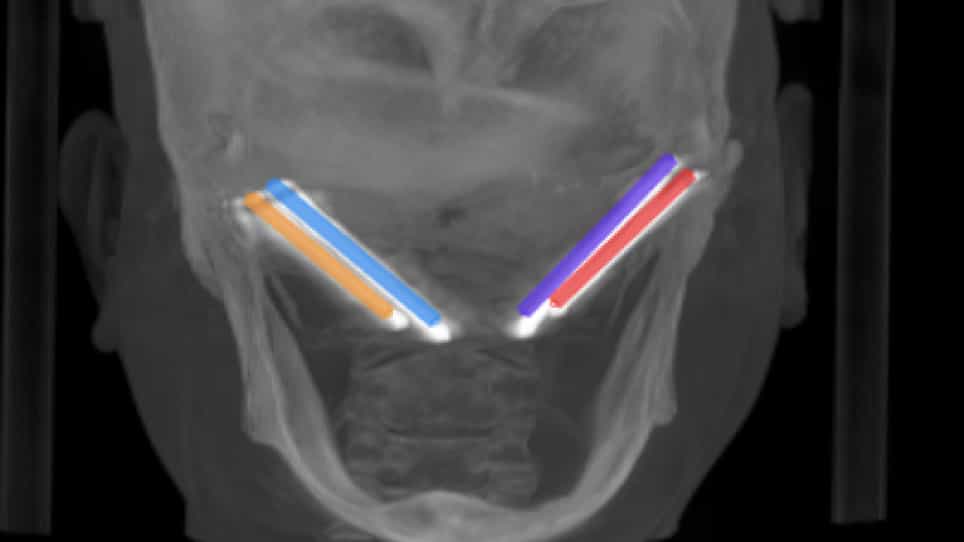

Real-Time Dynamic Navigation System for the Precise Quad-Zygomatic Implant Placement in a Patient with a Severely Atrophic Maxilla
Published on: October 18, 2021
Optimization based trajectory planning for real-time 6DoF robotic patient motion compensation systems
Xinmin Liu1, Rodney D Wiersma1
1Department of Radiation and Cellular Oncology, The University of Chicago, Chicago, IL 60637, United States of America.

Purpose:
Robotic stabilization of a therapeutic radiation beam with respect to a dynamically moving tumor target can be accomplished either by moving the radiation source, the patient, or both. As the treatment beam is on during this process, the primary goal is to minimize exposure of normal tissue to radiation as much as possible when moving the target back to the desired position. Due to the complex mechanical structure of 6 degree-of-freedom (6DoF) robots, it is not intuitive as to what 6 dimensional (6D) correction trajectory is optimal in achieving such a goal. With proportional-integrative-derivative (PID) and other controls, the potential exists that the controller may generate a trajectory that is highly curved, slow, or suboptimal in that it leads to unnecessary exposure of healthy tissue to radiation. This work investigates a novel feedback planning method that takes into account a robot's mechanical joint structure, patient safety tolerances, and other system constraints, and performs real-time optimization to search the entire 6D trajectory space in each time cycle so it can respond with an optimal 6D correction trajectory.
Methods:
Computer simulations were created for two 6DoF robotic patient support systems: a Stewart-Gough platform for moving a patient's head in frameless maskless stereotactic radiosurgery, and a linear accelerator treatment table for moving a patient in prostate cancer radiation therapy. Motion planning was formulated as an optimization problem and solved at real-time speeds using the L-BFGS algorithm. Three planning methods were investigated, moving the platform as fast as possible (platform-D), moving the target along a straight-line (target-S), and moving the target based on the fastest descent of position error (target-D). Both synthetic motion and prior recorded human motion were used as input data and output results were analyzed.
Results:
For randomly generated 6D step-like and sinusoidal synthetic input motion, target-D planning demonstrated the smallest net trajectory error in all cases. On average, optimal planning was found to have a 45% smaller target trajectory error than platform-D control, and a 44% smaller target trajectory error than target-S planning. For patient head motion compensation, only target-D planning was able to maintain a ≤0.5mm and ≤0.5deg clinical tolerance objective for 100% of the treatment time. For prostate motion, both target-S planning and target-D planning outperformed platform-D control.
Conclusions:
A general 6D target trajectory optimization framework for robotic patient motion compensation systems was investigated. The method was found to be flexible as it allows control over various performance requirements such as mechanical limits, velocities, acceleration, or other system control objectives.
More Related Videos
Related Concept Videos
 01:26
Orthogonal Trajectories
 02:50
Dosage Compensation
In addition to sexual development, the X chromosome has genes involved in autosomal functions such as brain development and the immune system. Therefore, males and females with distinct numbers of X chromosomes will...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:24
Nursing Process for Patient and Caregiver Teaching II: Planning and Implementation
 01:28
Compensation Mechanisms
Respiratory Compensation
This mechanism addresses metabolic-induced pH imbalances by adjusting breathing rates. Respiratory compensation begins within minutes of detecting a pH...
 02:57
Real Time RT-PCR
The real-time quantification of the number of amplified products is...