Related Experiment Video
Updated: Jan 30, 2026

A Minimally Invasive, Accurate, and Efficient Technique for Intrathymic Injection in Mice
Published on: August 23, 2022
SDVL: Efficient and Accurate Semi-Direct Visual Localization
Eduardo Perdices1, José María Cañas2
1RoboticsLab-URJC, Universidad Rey Juan Carlos, Fuenlabrada, 28943 Madrid, Spain. eperdices@gsyc.urjc.es.

Abstract:
Visual Simultaneous Localization and Mapping (SLAM) approaches have achieved a major breakthrough in recent years. This paper presents a new monocular visual odometry algorithm able to localize in 3D a robot or a camera inside an unknown environment in real time, even on slow processors such as those used in unmanned aerial vehicles (UAVs) or cell phones. The so-called semi-direct visual localization (SDVL) approach is focused on localization accuracy and uses semi-direct methods to increase feature-matching efficiency. It uses inverse-depth 3D point parameterization. The tracking thread includes a motion model, direct image alignment, and optimized feature matching. Additionally, an outlier rejection mechanism (ORM) has been implemented to rule out misplaced features, improving accuracy especially in partially dynamic environments. A relocalization module is also included but keeping the real-time operation. The mapping thread performs an automatic map initialization with homography, a sampled integration of new points and a selective map optimization. The proposed algorithm was experimentally tested with international datasets and compared to state-of-the-art algorithms.
More Related Videos
Related Concept Videos
 01:09
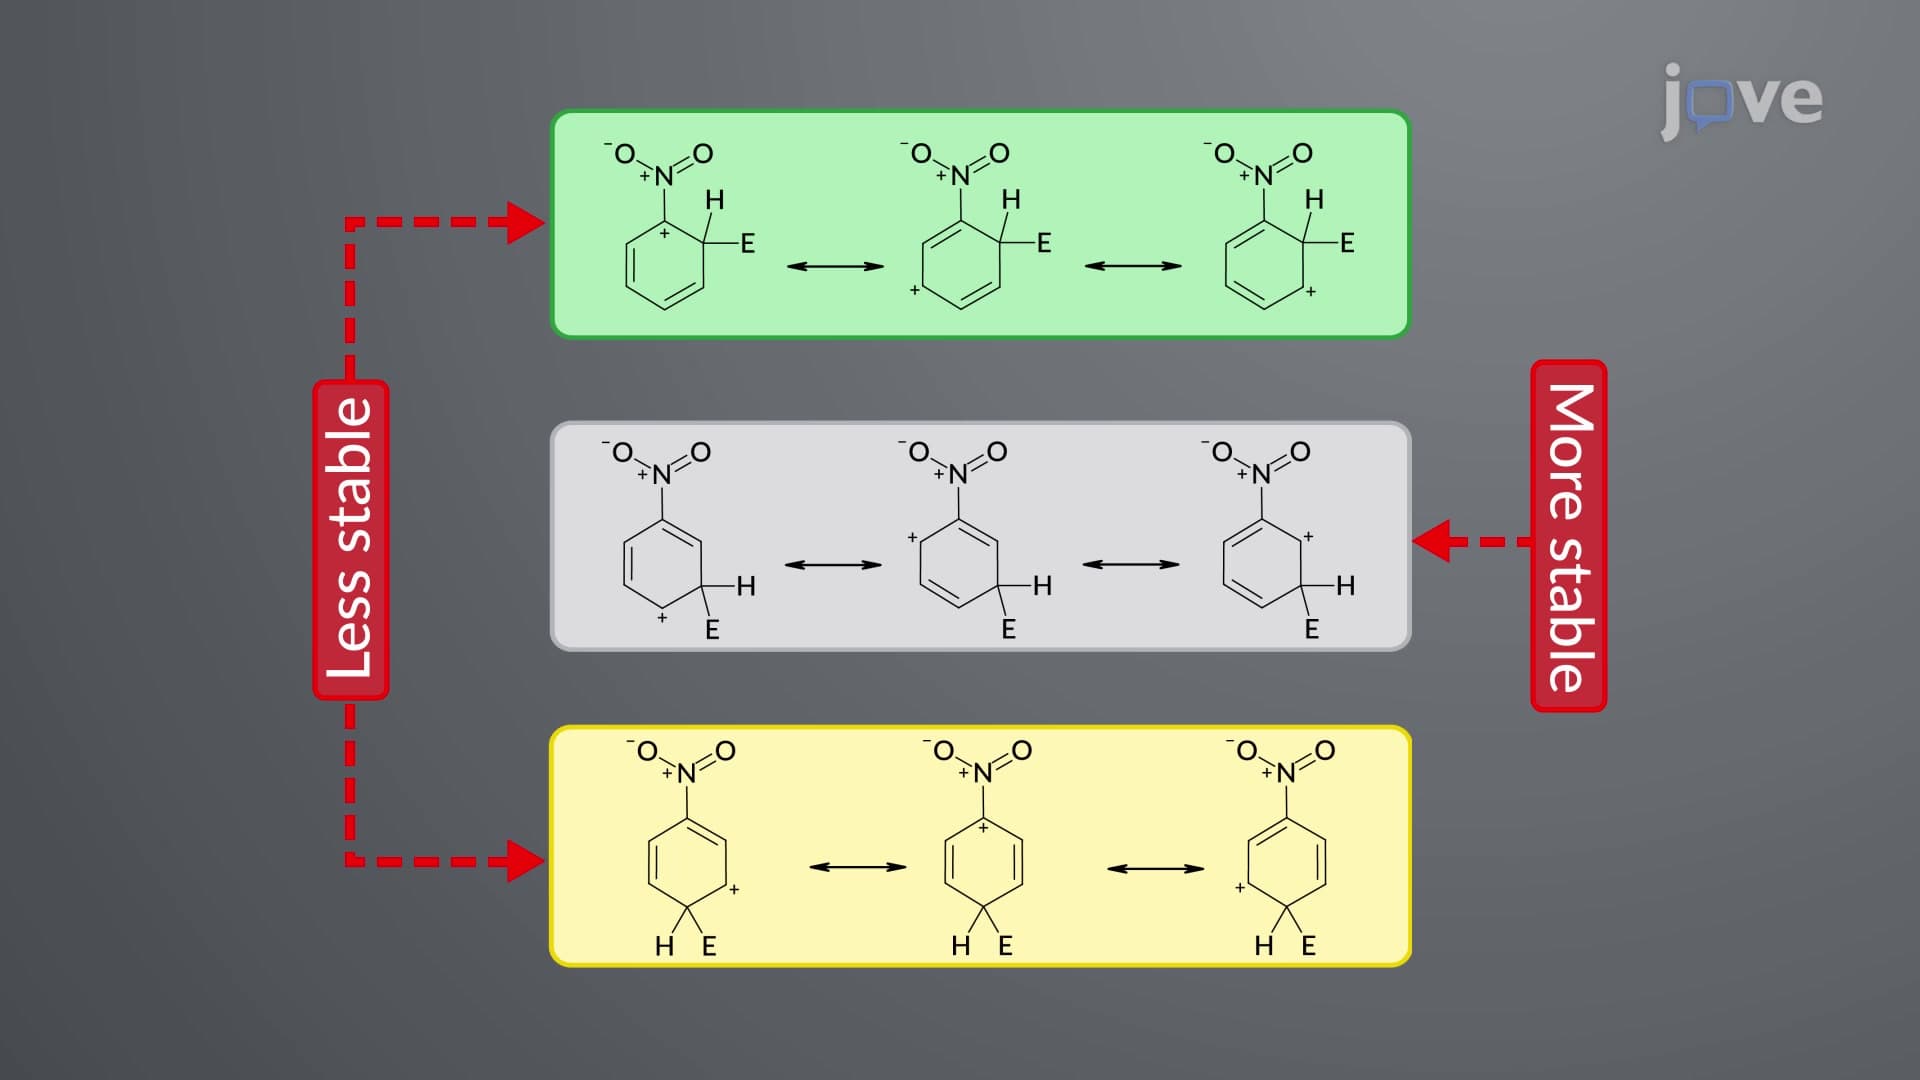
Directing Effect of Substituents: meta-Directing Groups
 01:14
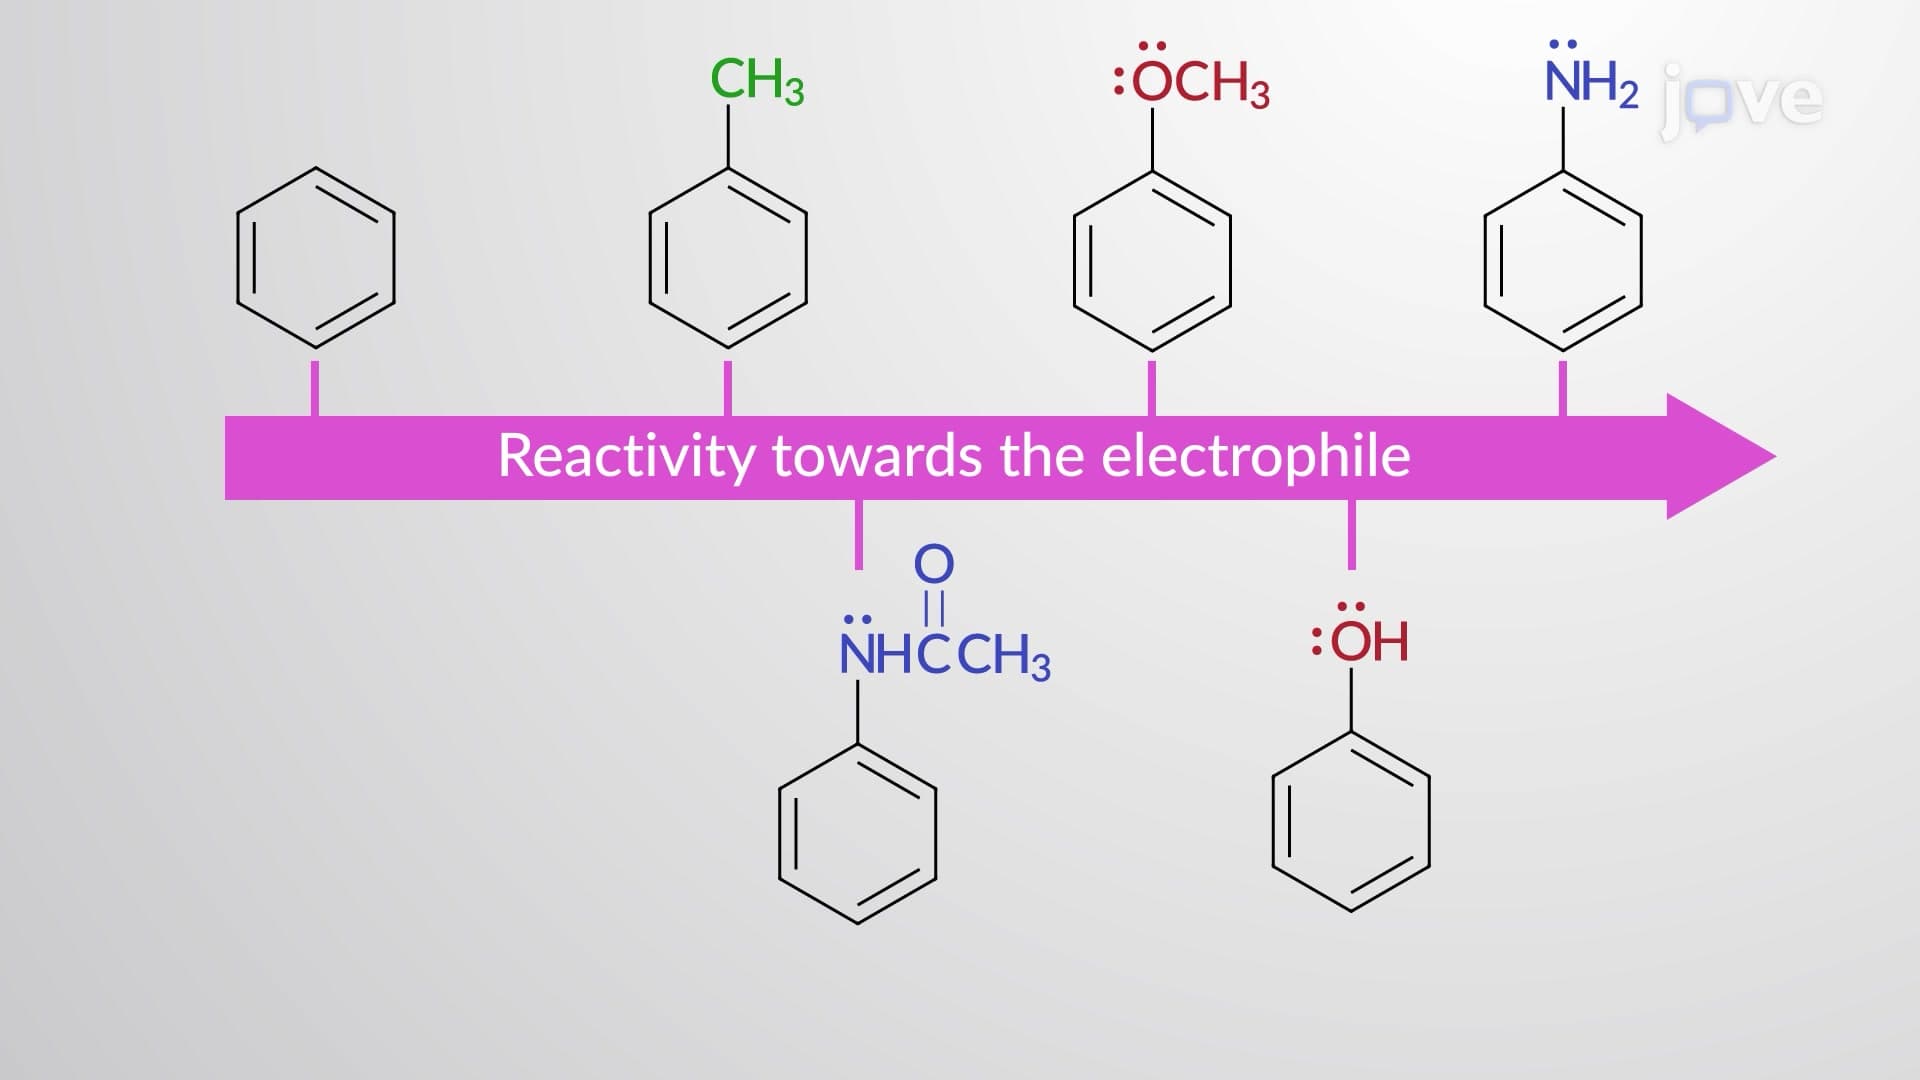
Directing Effect of Substituents: ortho–para-Directing Groups
 01:22
Local Attraction
 01:01
Production Efficiency
 00:46
Trophic Efficiency
 01:14
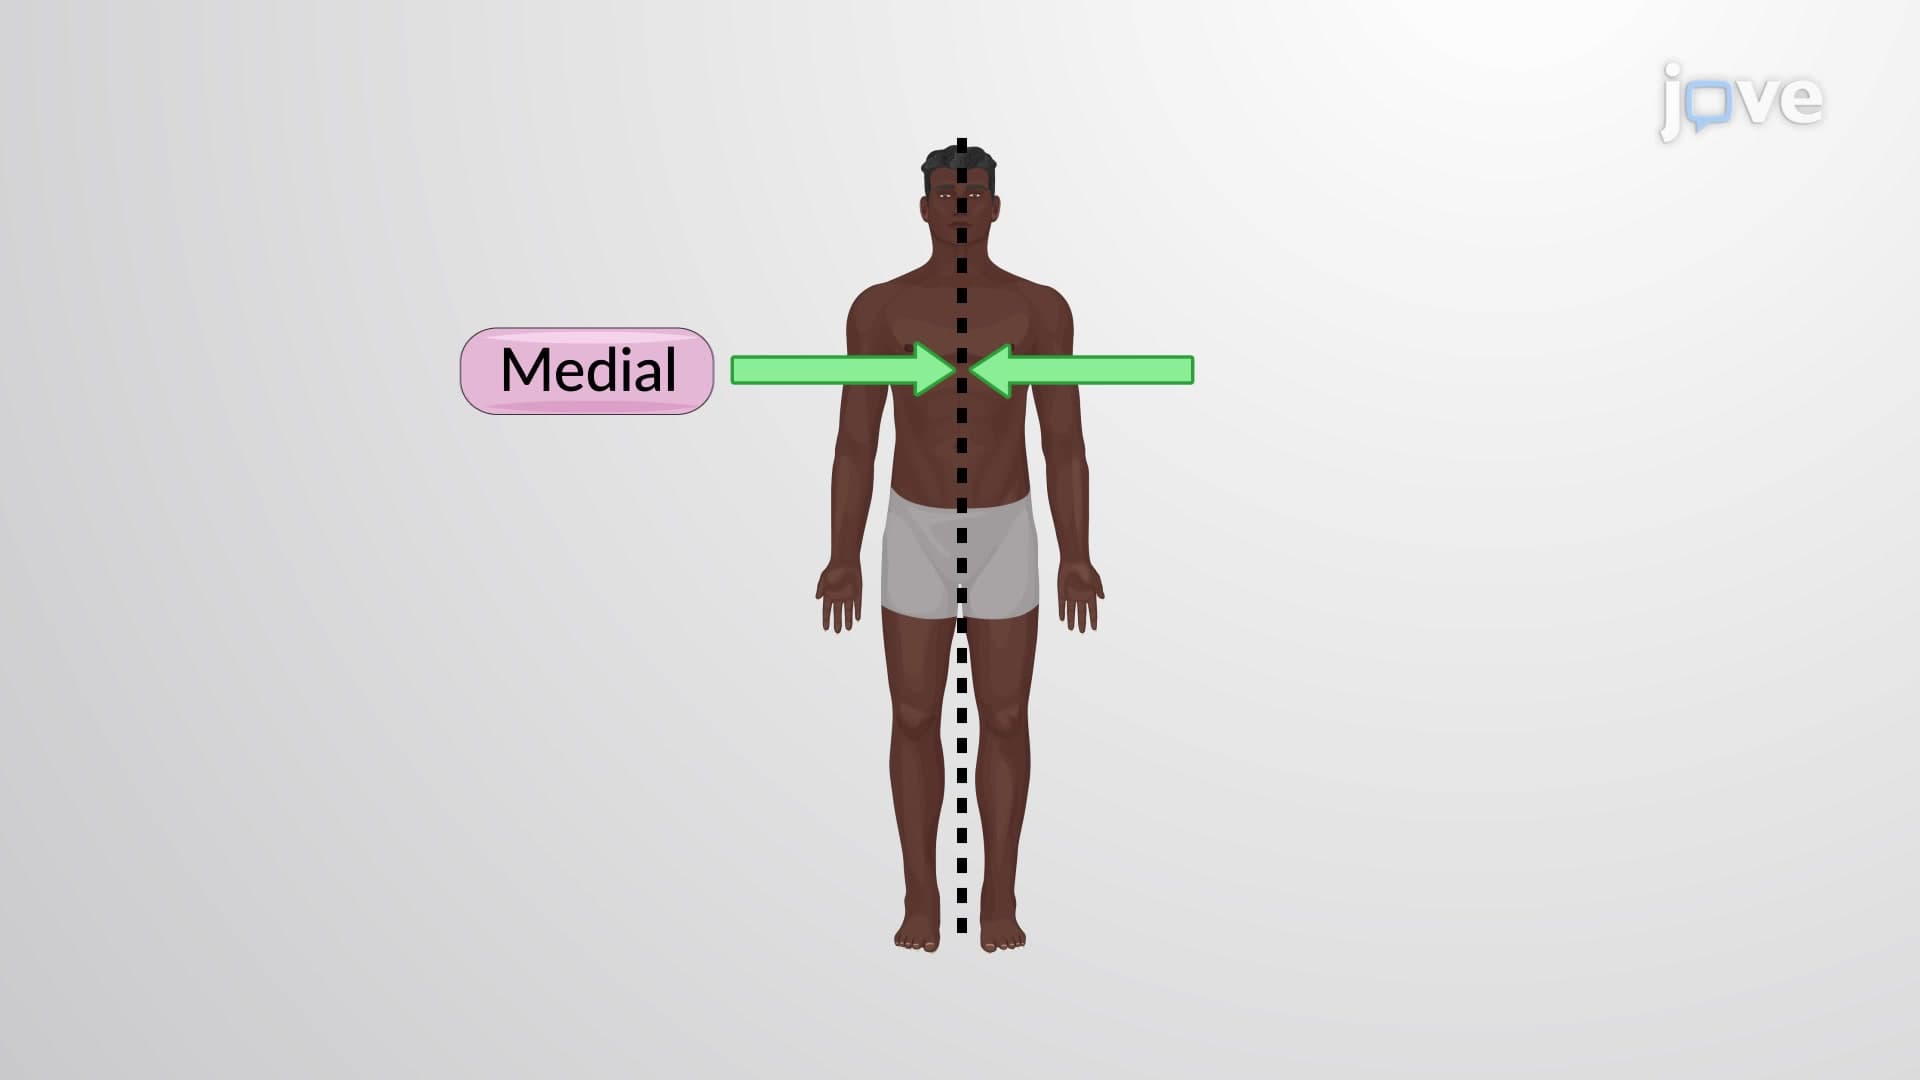
Directional Terms