Related Experiment Video
Updated: Jan 30, 2026
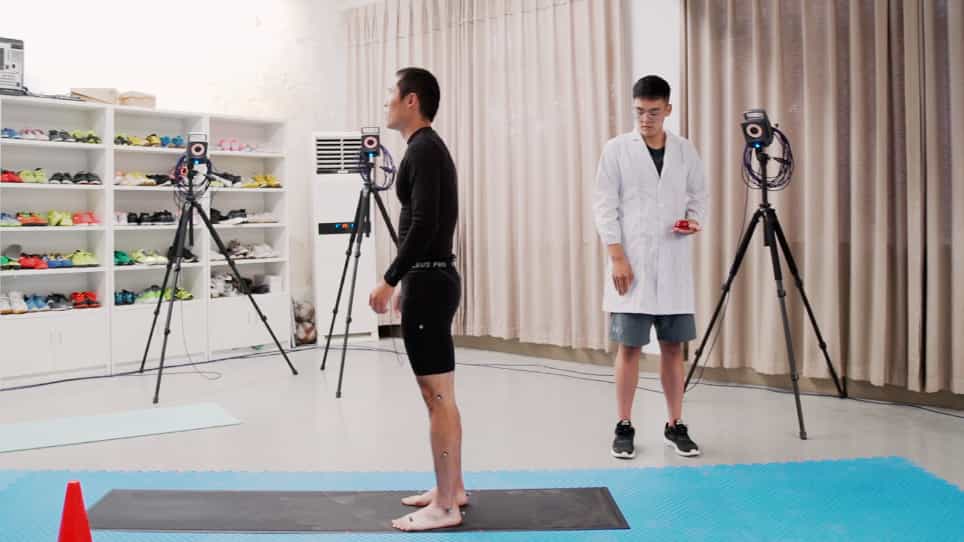

Lower-Limb Biomechanical Characteristics Associated with Unplanned Gait Termination Under Different Walking Speeds
Published on: August 25, 2020
Neuromusculoskeletal model that walks and runs across a speed range with a few motor control parameter changes based
Shinya Aoi1, Tomohiro Ohashi2, Ryoko Bamba2
1Department of Aeronautics and Astronautics, Graduate School of Engineering, Kyoto University, Kyoto daigaku-Katsura, Nishikyo-ku, Kyoto, 615-8540, Japan. shinya_aoi@kuaero.kyoto-u.ac.jp.

Abstract:
Humans walk and run, as well as change their gait speed, through the control of their complicated and redundant musculoskeletal system. These gaits exhibit different locomotor behaviors, such as a double-stance phase in walking and flight phase in running. The complex and redundant nature of the musculoskeletal system and the wide variation in locomotion characteristics lead us to imagine that the motor control strategies for these gaits, which remain unclear, are extremely complex and differ from one another. It has been previously proposed that muscle activations may be generated by linearly combining a small set of basic pulses produced by central pattern generators (muscle synergy hypothesis). This control scheme is simple and thought to be shared between walking and running at different speeds. Demonstrating that this control scheme can generate walking and running and change the speed is critical, as bipedal locomotion is dynamically challenging. Here, we provide such a demonstration by using a motor control model with 69 parameters developed based on the muscle synergy hypothesis. Specifically, we show that it produces both walking and running of a human musculoskeletal model by changing only seven key motor control parameters. Furthermore, we show that the model can walk and run at different speeds by changing only the same seven parameters based on the desired speed. These findings will improve our understanding of human motor control in locomotion and provide guiding principles for the control design of wearable exoskeletons and prostheses.
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:14
What is a Hypothesis?
 00:59
Range
15.9; 16.1; 15.2; 14.8; 15.8; 15.9; 16.0; 15.5
Measurements of the amount of soda in a 16-ounce can vary since different subjects record these measurements or since the exact amount - 16 ounces of liquid, was not...
 01:17
Wald-Wolfowitz Runs Test II
For binary data, runs are identified using symbols such as + and −, or equivalently, 1s and 0s. In...
 01:48
Classification of Skeletal Muscle Fibers
Slow-Twitch Muscle Fibers
Slow oxidative, muscle fibers appear red due to large numbers of capillaries and high levels of...
 01:11
Types of Hypothesis Testing
When the null and alternative hypotheses are stated, it is observed that the null hypothesis is a neutral statement against which the alternative hypothesis is tested. The alternative hypothesis is a claim that instead has a certain direction. If the null hypothesis claims that p = 0.5, the alternative hypothesis would be an opposing statement to this and can be put either p > 0.5, p < 0.5, or p...