Related Experiment Video
Updated: Jan 30, 2026

Design and Characterization Methodology for Efficient Wide Range Tunable MEMS Filters
Published on: February 4, 2018
A Bayesian Filtering Approach for Error Mitigation in Ultra-Wideband Ranging
Jing Xin1, Kaiyuan Gao2, Mao Shan3
1Shaanxi Key Laboratory of Complex System Control and Intelligent Information Processing, Xi'an University of Technology, Xi'an 710048, China. xinj@xaut.edu.cn.

Abstract:
Ultra-wideband (UWB) sensors have been widely used in multi-robot systems for cooperative tracking and positioning purposes due to their advantages such as high ranging accuracy and good real-time performance. In order to reduce the influence of non-line-of-sight (NLOS) UWB communication caused by the presence of obstacles on ranging accuracy in indoor environments, the paper proposes a novel Bayesian filtering approach for UWB ranging error mitigation. Nonparametric UWB sensor models, namely received signal strength (RSS) model and time of arrival (TOA) model, are constructed to capture the probabilistic noise characteristics under the influence of different obstruction conditions and materials within a typical indoor environment. The proposed Bayesian filtering approach can be used either as a standalone error mitigation approach for peer-to-peer (P2P) ranging, or as a part of a higher level Bayesian state estimation framework. Experiments were conducted to validate and evaluate the proposed approach in two configurations, i.e., inter-robot ranging, and mobile robot tracking in a wireless sensor network. The experimental results show that the proposed method can accurately identify the line-of-sight (LOS) and NLOS scenarios with wood and metal obstacles in a probabilistic representation and effectively improve the ranging/tracking accuracy. In addition, the low computational overhead of the approach makes it attractive in real-time systems.
Related Concept Videos
 00:59
Range
15.9; 16.1; 15.2; 14.8; 15.8; 15.9; 16.0; 15.5
Measurements of the amount of soda in a 16-ounce can vary since different subjects record these measurements or since the exact amount - 16 ounces of liquid, was not...
 01:27
Passive Filters
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
 01:15
Systematic Error: Methodological and Sampling Errors
Sampling errors originate from improper sampling methods or the wrong sample population. These errors can be minimized by refining the sampling strategy. Defective instruments or faulty calibrations are the sources of instrumental...
 01:25
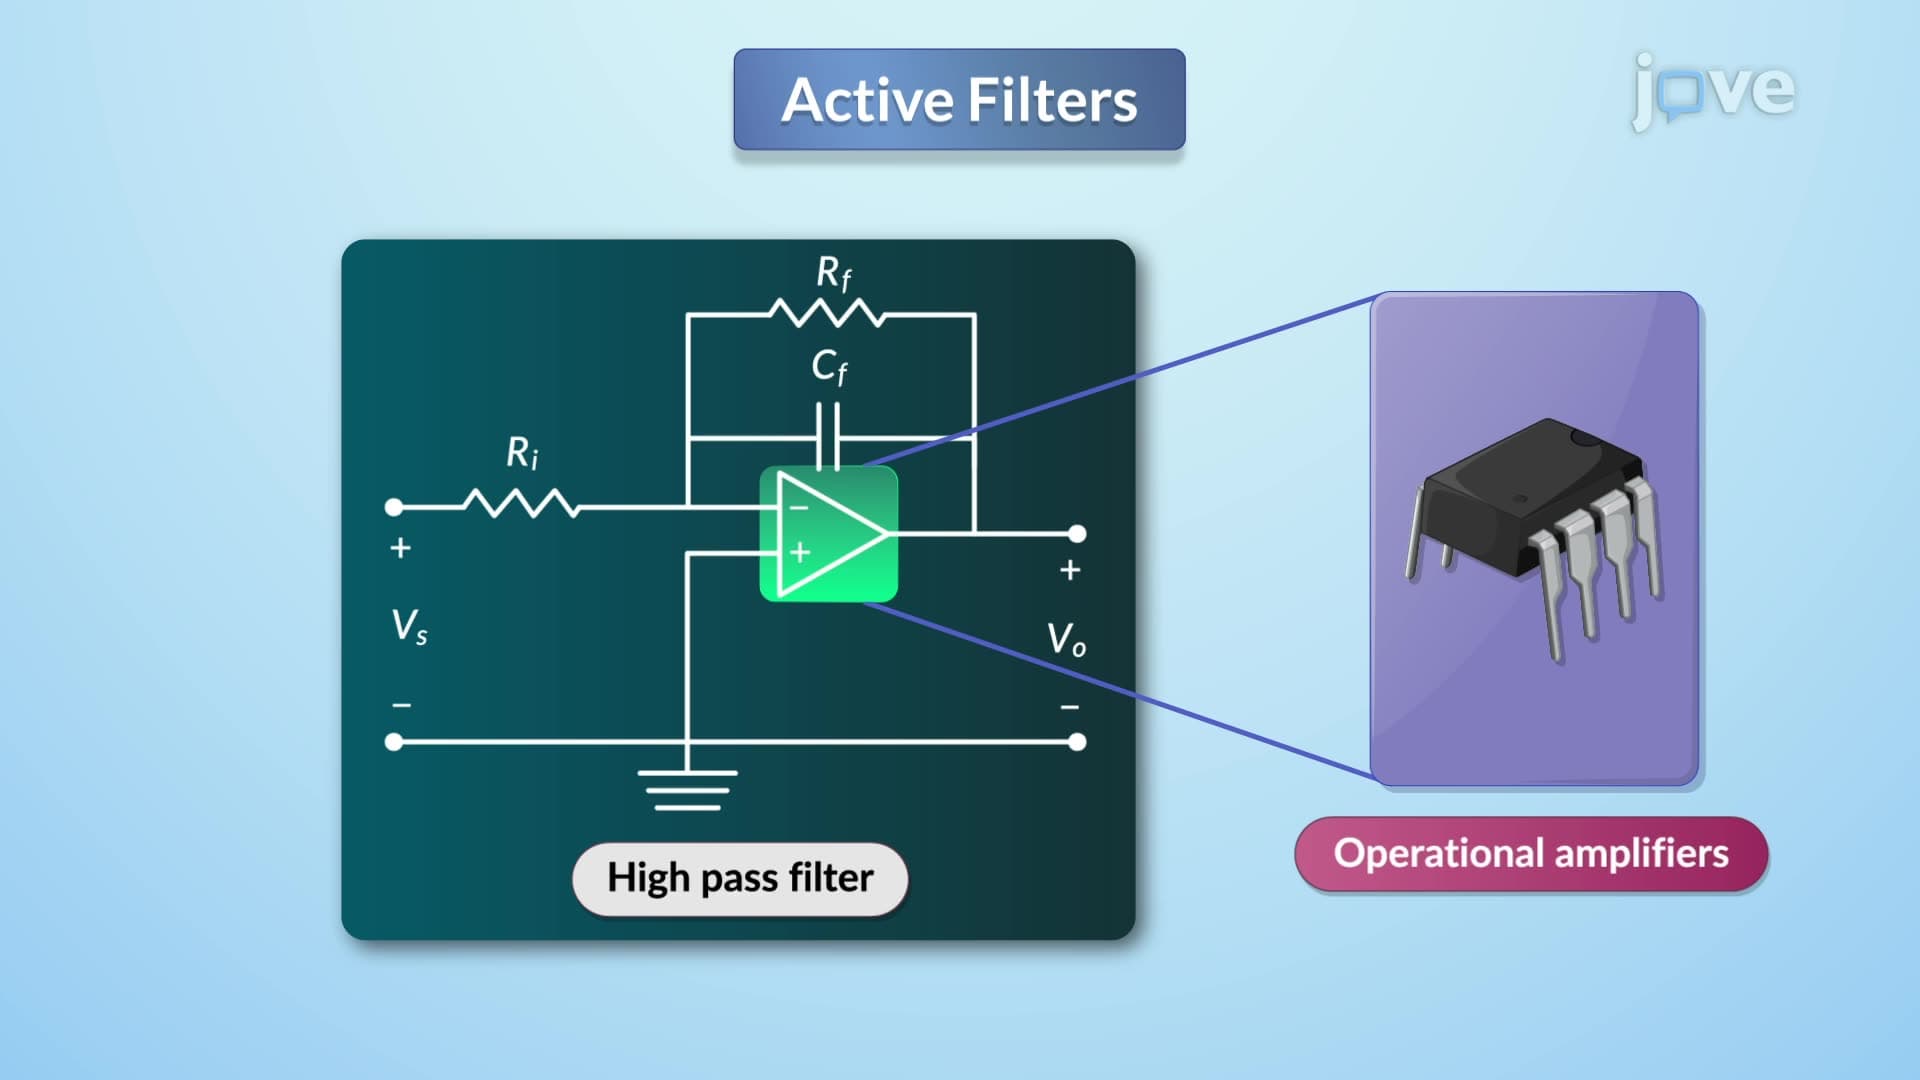
Active Filters
 01:14
Fundamental Attribution Error
 01:04
Random Error