Shared right-hemispheric representations of sensorimotor goals in dynamic task environments
Related Experiment Video
Updated: Jan 30, 2026
Task Interruption and Resumption Paradigm for Testing the Activation and Pursuit of an Abstract Thinking Goal
Published on: April 18, 2017
Ada Le1, Francis Benjamin Wall1, Gina Lin1
1Department of Psychology, University of Toronto Scarborough, 1265 Military Trail, Toronto, ON, M1C 1A4, Canada.

Abstract:
Functional behaviour affords that we form goals to integrate sensory information about the world around us with suitable motor actions, such as when we plan to grab an object with a hand. However, much research has tested grasping in static scenarios where goals are pursued with repetitive movements, whereas dynamic contexts require goals to be pursued even when changes in the environment require a change in the actions to attain them. To study grasp goals in dynamic environments here, we employed a task where the goal remained the same but the execution of the movement changed; we primed participants to grasp objects either with their right or left hand, and occasionally they had to switch to grasping with both. Switch costs should be minimal if grasp goal representations were used continuously, for example, within the left dominant hemisphere. But remapped or re-computed goal representations should delay movements. We found that switching from right-hand grasping to bimanual grasping delayed reaction times but switching from left-hand grasping to bimanual grasping did not. Further, control experiments showed that the lateralized switch costs were not caused by asymmetric inhibition between hemispheres or switches between usual and unusual tasks. Our results show that the left hemisphere does not serve a general role of sensorimotor grasp goal representation. Instead, sensorimotor grasp goals appear to be represented at intermediate levels of abstraction, downstream from cognitive task representations, yet upstream from the control of the grasping effectors.
More Related Videos
 11:09
RBDT: A Computerized Task System based in Transposition for the Continuous Analysis of Relational Behavior Dynamics in Humans
Published on: July 17, 2021
 15:00
The Impact of Motor Task Conditions on Goal-Directed Arm Reaching Kinematics and Trunk Compensation in Chronic Stroke Survivors
Published on: May 2, 2021
Related Concept Videos
 01:26
Psychosis: Goals of Pharmacotherapy
 01:05
Cerebral Hemispheres
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:16
Control Volume and System Representations
The control volume approach considers a stationary region in space through which fluid flows. This region is bounded by a control surface. For instance, in the case of water...
 01:28
Graphical Representation of Inequalities
 01:16
Vector Representation of Complex Numbers
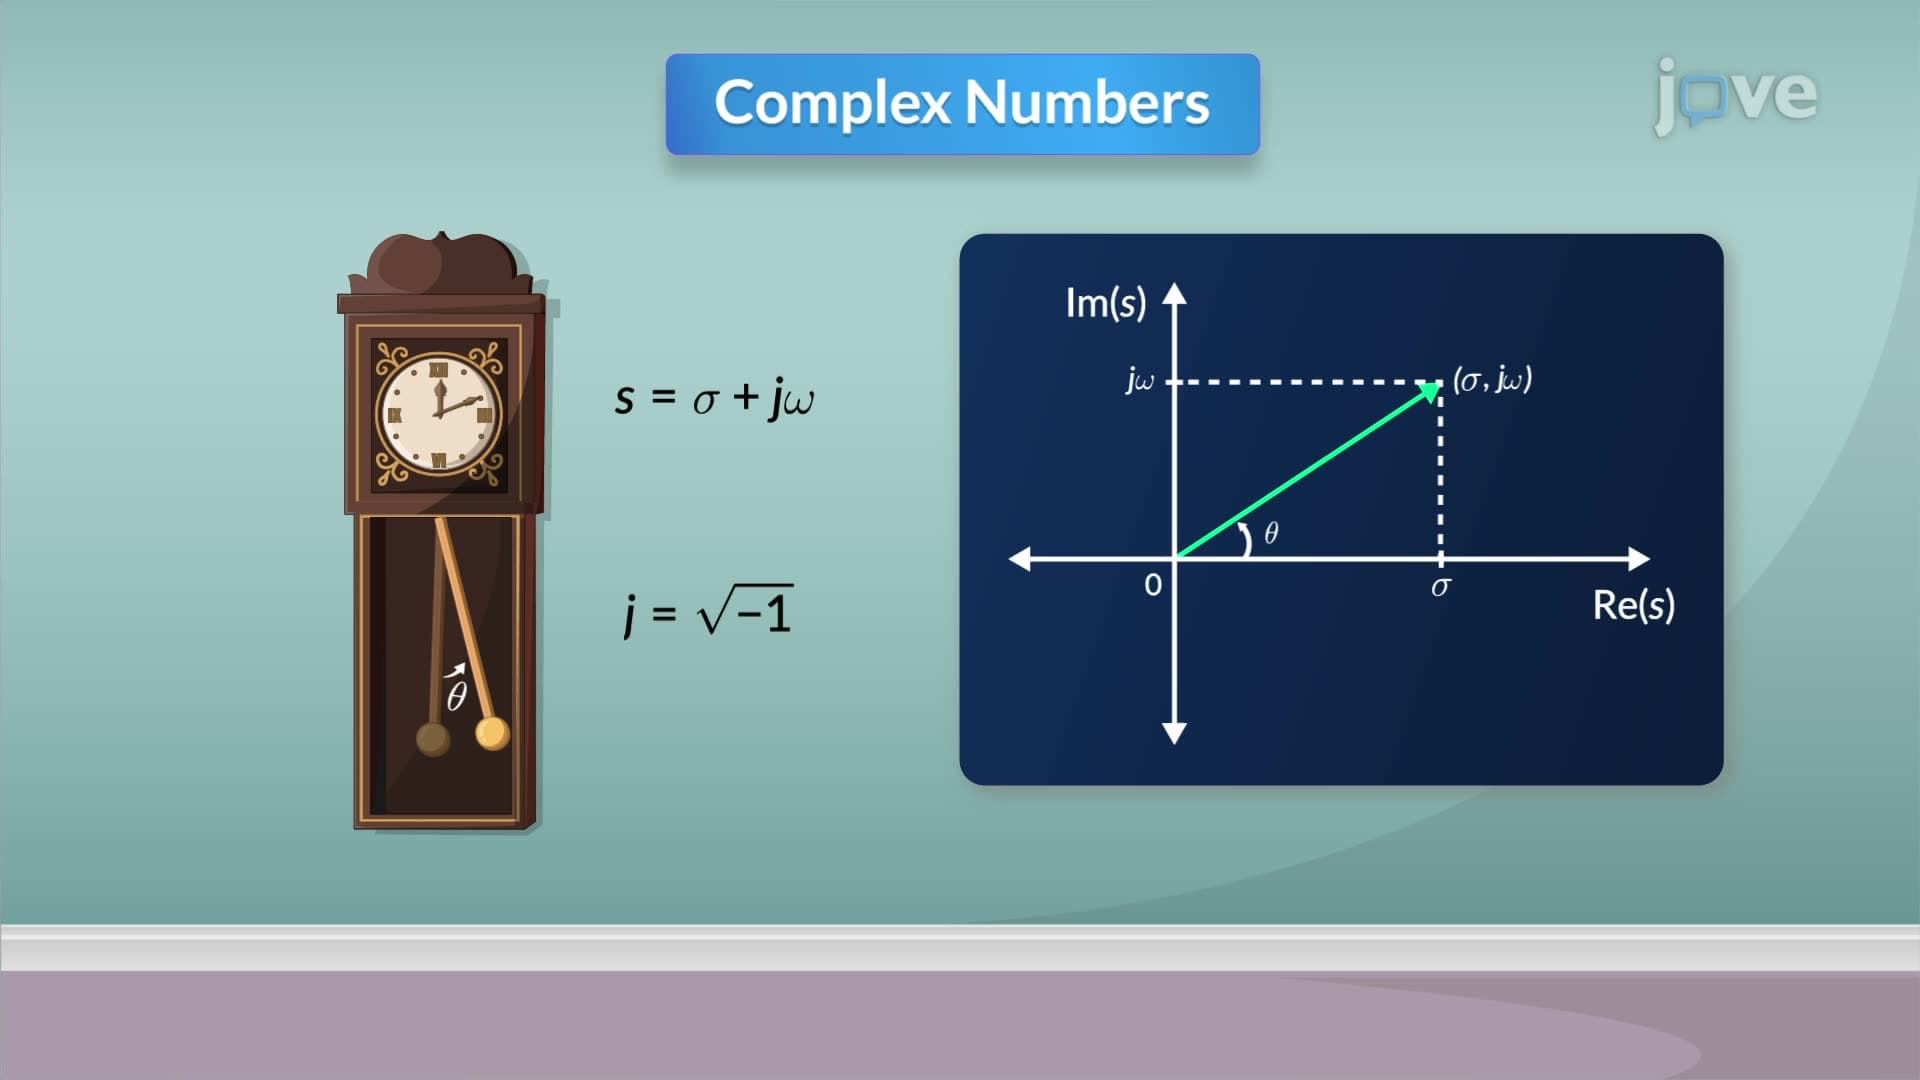
Consider a function defined as the product of the complex factors in the numerator divided by the product of the complex factors in the...