Related Experiment Video
Updated: Jan 30, 2026
Movement Retraining using Real-time Feedback of Performance
Published on: January 17, 2013
Real-time self-adaptive calibration method for high speed acquisition system
Hao Zeng1, Peng Ye1, Wentao Wei1
1School of Automation Engineering, University of Electronic Science and Technology of China, Chengdu 611731, China.

Abstract:
The main factors that enable capture of complex and transient signals in real-time are improved sampling rates and processing speeds. The time-interleaved architecture is an effective method that allows systems to break through the speed bottleneck of single analog-to-digital converters (ADCs) and go beyond the state-of-the-art process technology limit. However, the performance of the acquisition system may be reduced because of the offset, gain, and time mismatch errors that occur in time-interleaved ADC systems. To correct these errors, this paper first proposes a self-adaptive correction algorithm and then introduces real-time solutions for this algorithm. Finally, the proposed calibration method is implemented in a digital phosphor oscilloscope. Simulations and experimental testing indicate that this system shows good real-time performance and provides a high dynamic performance with an effective number of bits of 7.3 bits and a signal-to-noise ratio of 45.5574 dB.
Related Concept Videos
 02:57
Real Time RT-PCR
The real-time quantification of the number of amplified products is...
 01:11
Glassware Calibration
Volumetric flasks: Volumetric flasks are designed to prepare aqueous solutions of precise volumes accurately with a calibration line on the neck. To calibrate a volumetric flask, it is important to fill it with distilled...
 01:12
Instrument Calibration
Analytical Balance Calibration
An analytical balance measures mass and requires regular calibration to...
 02:16
Light Acquisition
 01:10
Calibration Curves: Correlation Coefficient
 01:19
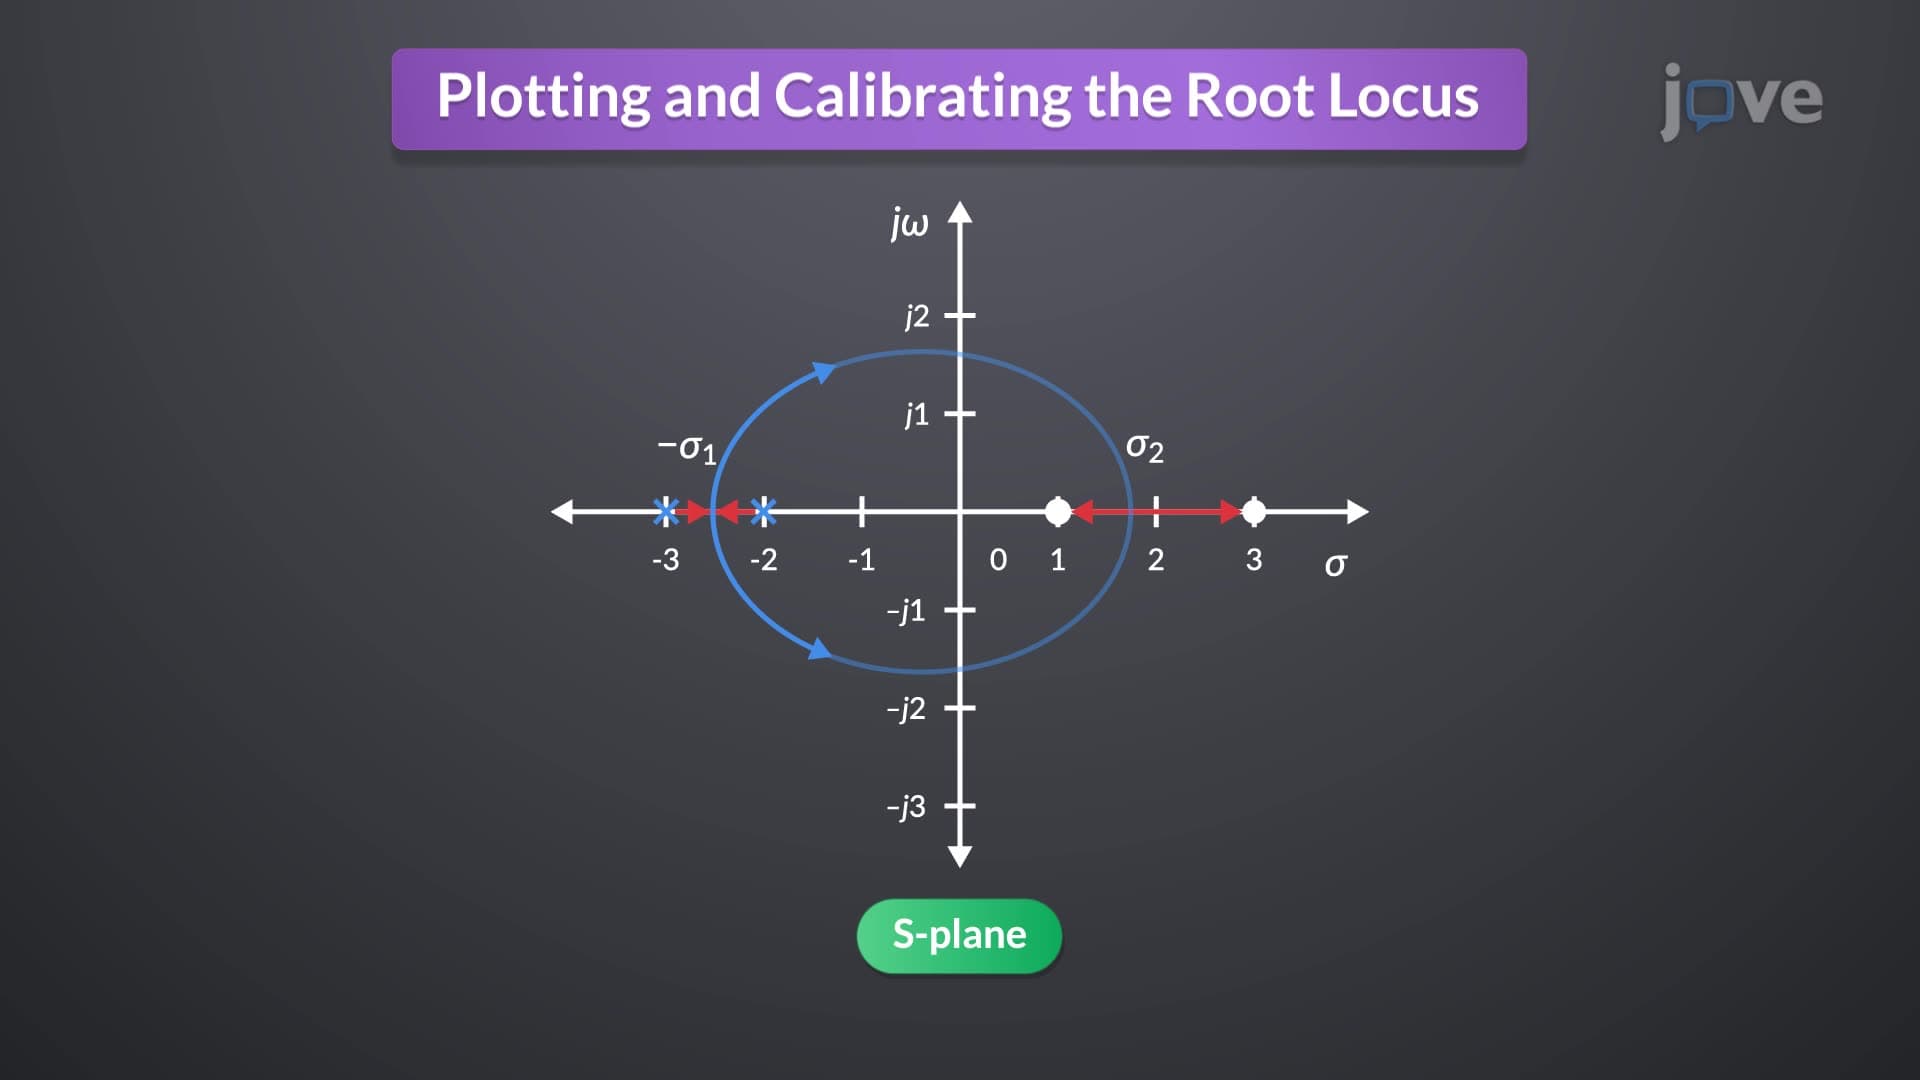
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...