Related Experiment Video
Updated: Jan 29, 2026
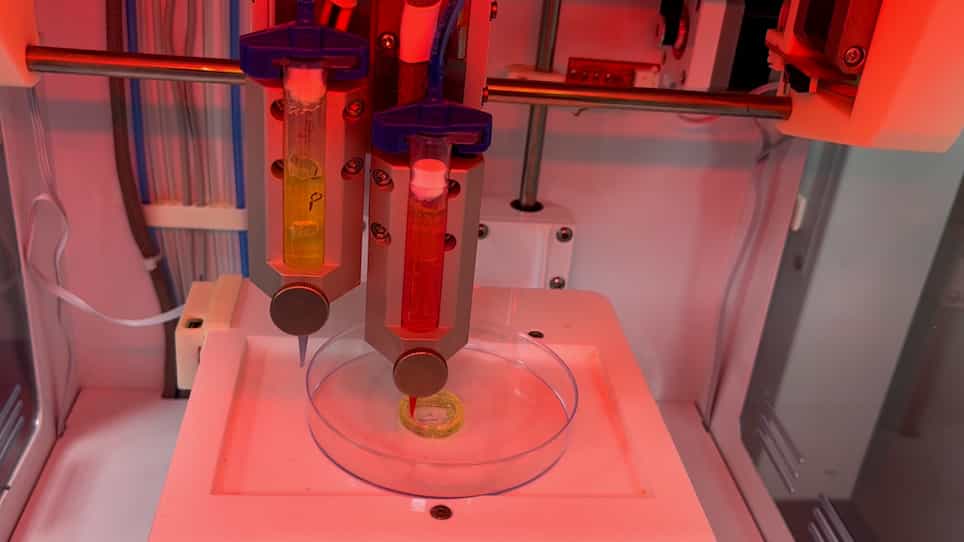
Four-Dimensional Printing of Stimuli-Responsive Hydrogel-Based Soft Robots
Published on: January 13, 2023
A Fully Three-Dimensional Printed Inchworm-Inspired Soft Robot with Magnetic Actuation
1Department of Mechanical & Industrial Engineering, University of Illinois at Chicago, Chicago, Illinois.

Abstract:
In the field of robotics, researchers are aiming to develop soft or partially soft bodied robots that utilize the motion and control system of various living organisms in nature. These robots have the potential to be robust and versatile, even safer for human interaction compared to traditional rigid robots. Soft robots based on biomimetic principles are being designed for real life applications by paying attention to different shape, geometry, and actuation systems in these organisms that respond to surrounding environments and stimuli. Especially, caterpillars or inchworms have garnered attention due to their soft compliant structure and crawling locomotion system making them ideal for maneuvering in congested spaces as a transport function. Currently, there are two major challenges with design and fabrication of such soft robots: using an efficient actuation system and developing a simple manufacturing process. Different actuation systems have been explored, which include shape memory alloy based coils and hydraulic and pneumatic actuators. However, the intrinsic limitations due to overall size and control system of these actuators prevent their integration in flexibility, lightweight, and compact manner, limiting practical and untethered applications. In comparison, magnetic actuation demonstrates simple wireless noncontact control. In terms of manufacturing process, additive manufacturing has emerged as an effective tool for obtaining structural complexity with high resolution, accuracy, and desired geometry. This study proposes a fully three-dimensional (3D) printed, monolithic, and tetherless inchworm-inspired soft robot that uses magnetic actuation for linear locomotion and crawling. Its structure is multimaterial heterogeneous particle-polymer composite with locally programmed material compositions. This soft robot is directly printed in one piece from a 3D computer model, without any manual assembly or complex processing steps, and it can be controlled by an external wireless force. This article presents its design and manufacturing with the novel magnetic field assisted projection stereolithography technique. Analytical models and numerical simulations of the crawling locomotion of the soft robot are also presented and compared with the experimental results of the 3D printed prototype. The overall locomotion mechanism of the magnetically actuated soft robot is evaluated with friction tests and stride efficiency analysis.

Related Concept Videos
 01:30
Mechanism of Breathing I: Inspiration
The respiratory system, an essential network for breathing, comprises the conducting and respiratory zones, each playing a crucial role in the overall process of respiration. Let us explore the detailed mechanism of inspiration, or inhalation, which is the first phase of the respiratory cycle.
Pathway of Air during Inspiration
During inspiration, air enters our body through the nose or mouth and moves through the conducting zone,...
 03:40
Dimensional Analysis
Conversion Factors and Dimensional Analysis
The unit...
 01:27
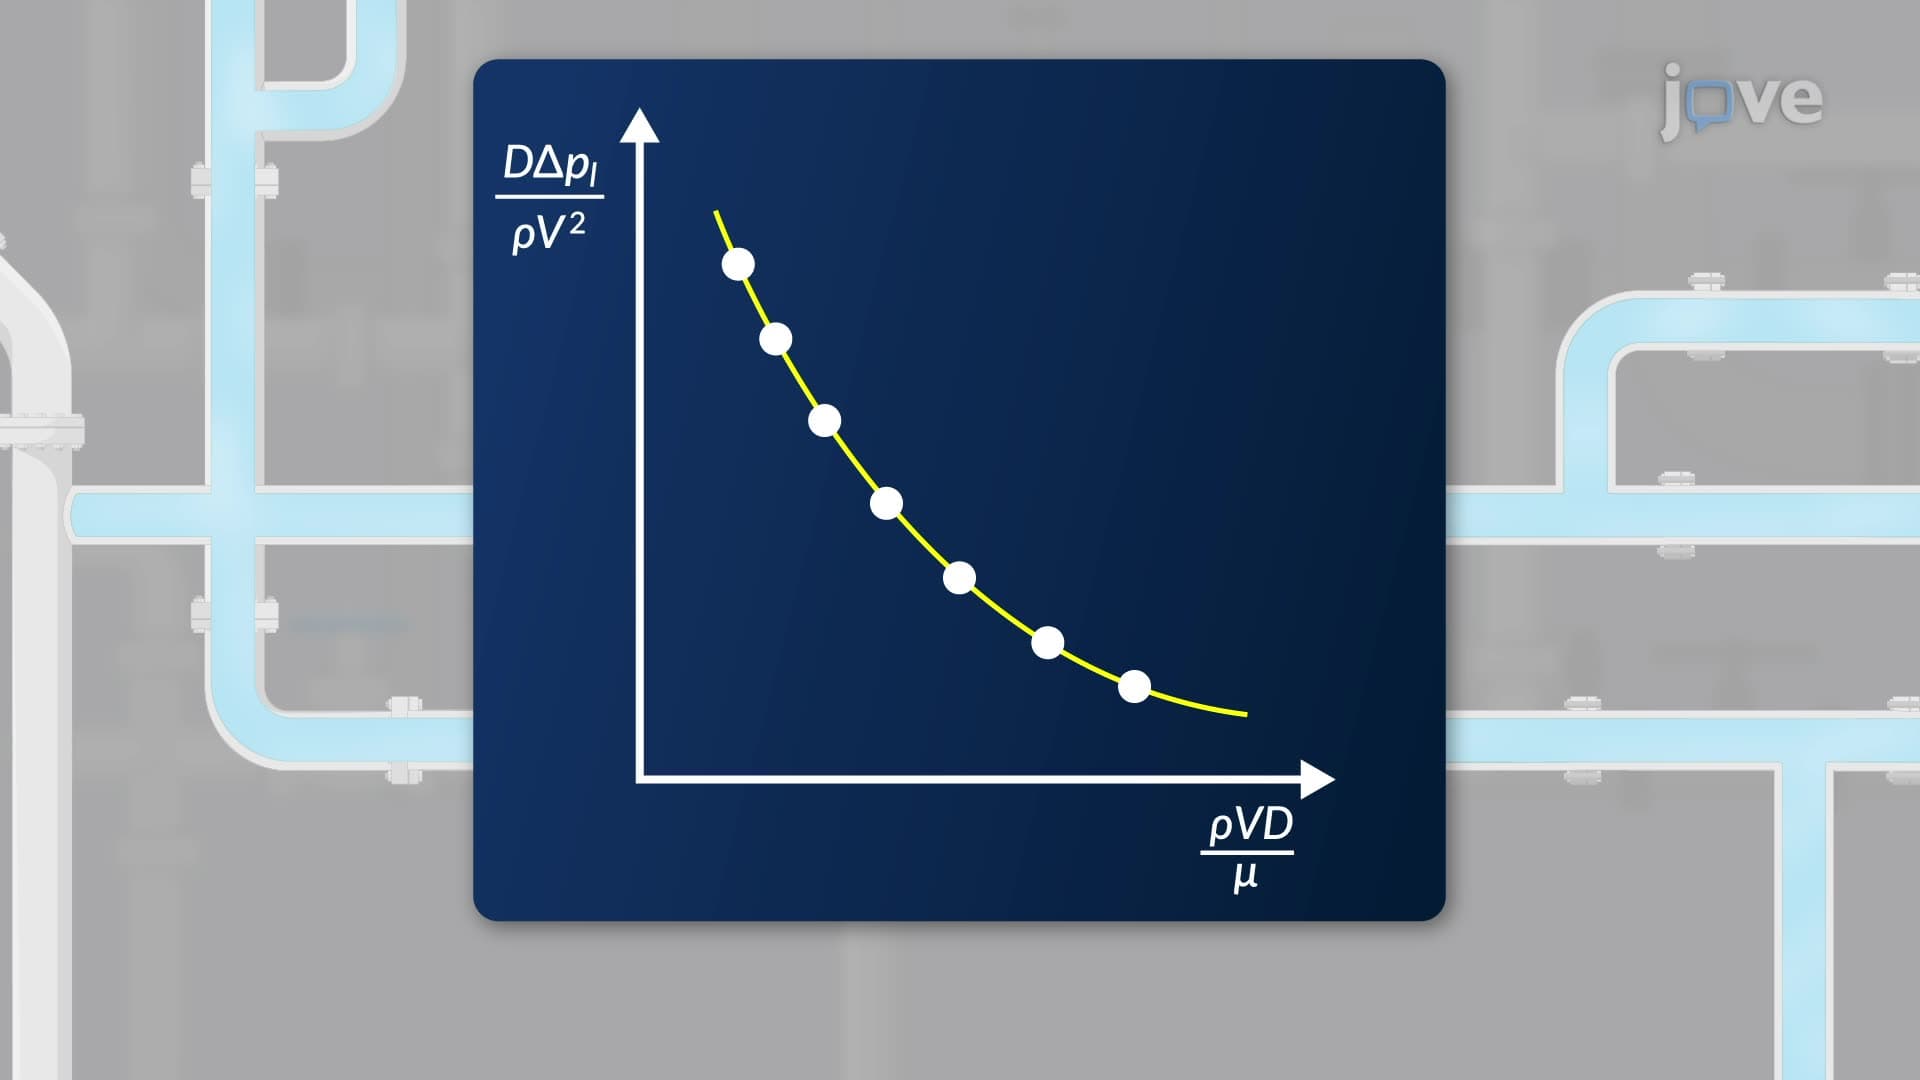
Dimensional Analysis
In fluid mechanics, dimensional...
 01:23
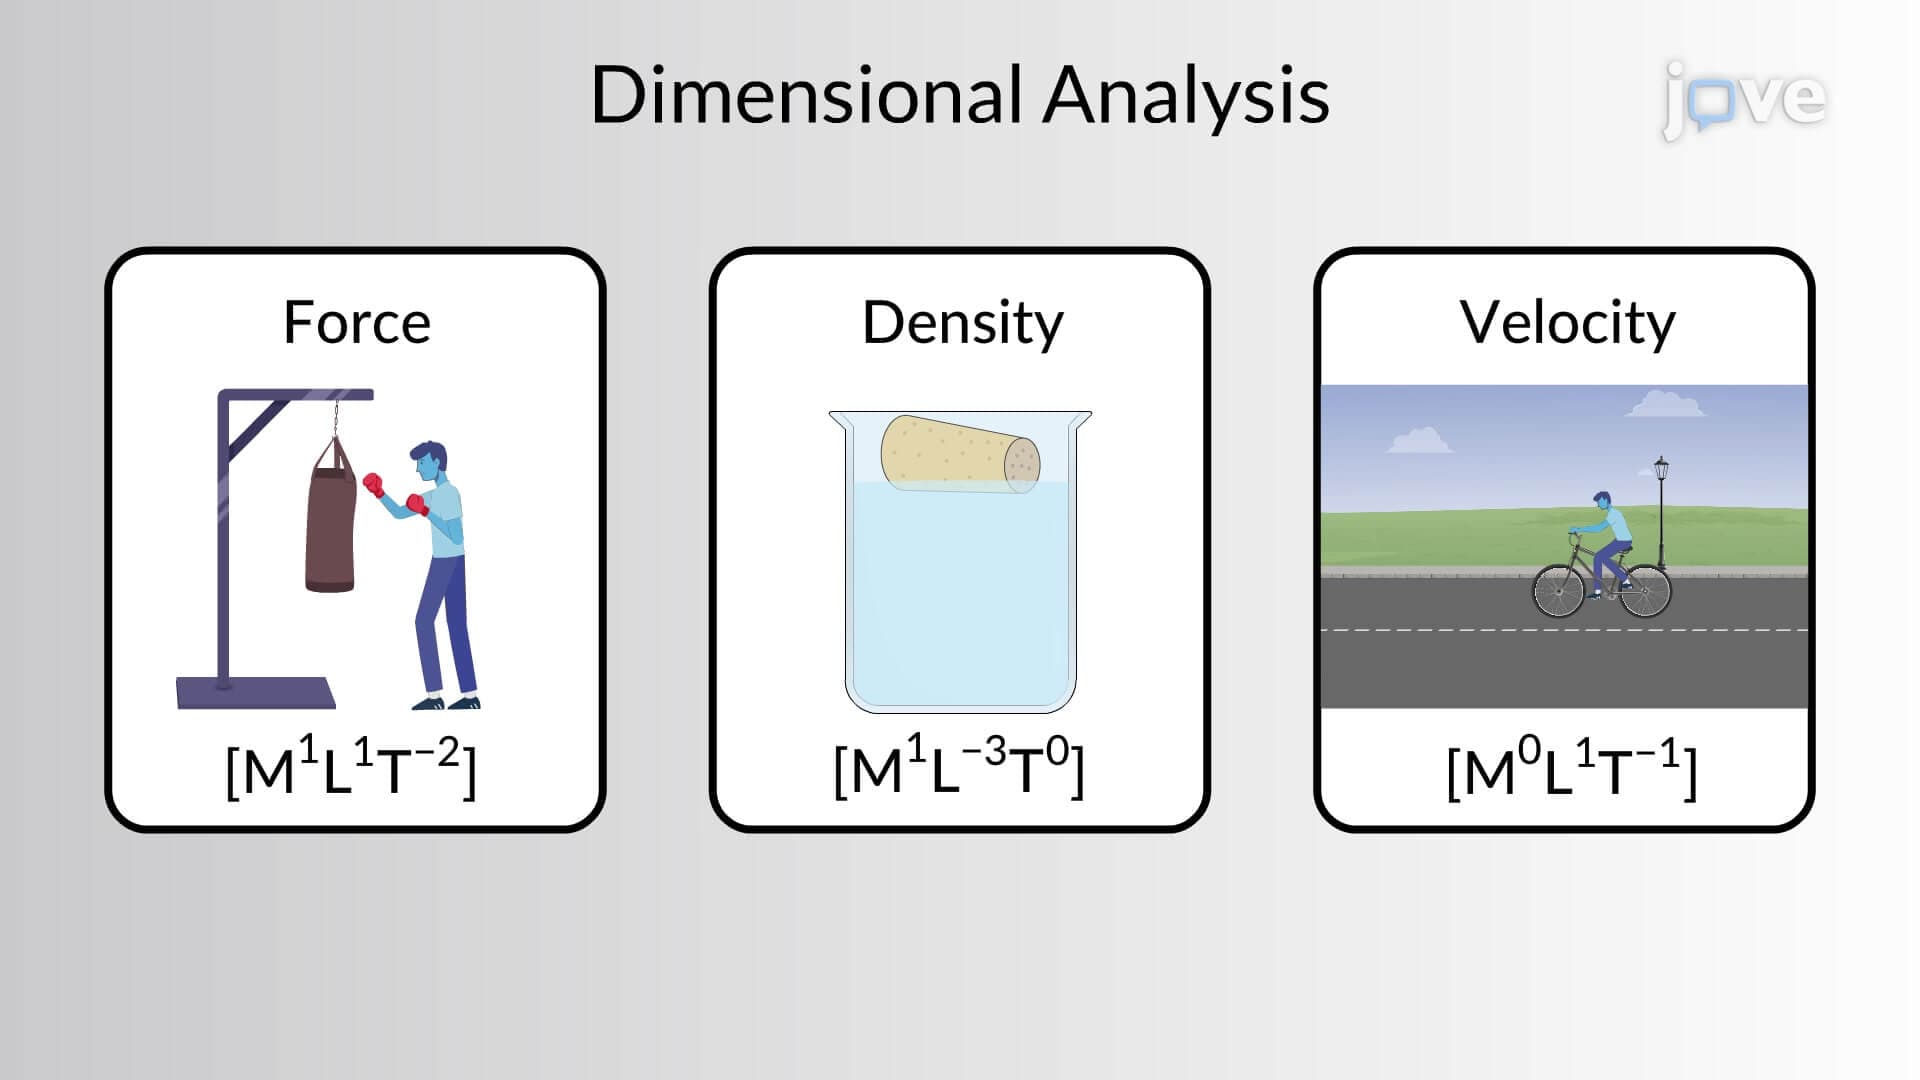
Dimensional Analysis
Dimensional analysis allows us to analyze and compare physical quantities on a...
 02:19
Dimensional Analysis
 03:02
Colors and Magnetism
When atoms or molecules absorb light at the proper frequency, their electrons are excited to higher-energy orbitals. For many main group atoms and molecules, the absorbed photons are in the ultraviolet range of the electromagnetic spectrum, which cannot be detected by the human eye. For coordination compounds, the energy difference between the d orbitals often allows photons in the visible range to be absorbed and emitted, which is seen as colors by the human...