Related Experiment Video
Updated: Jan 29, 2026
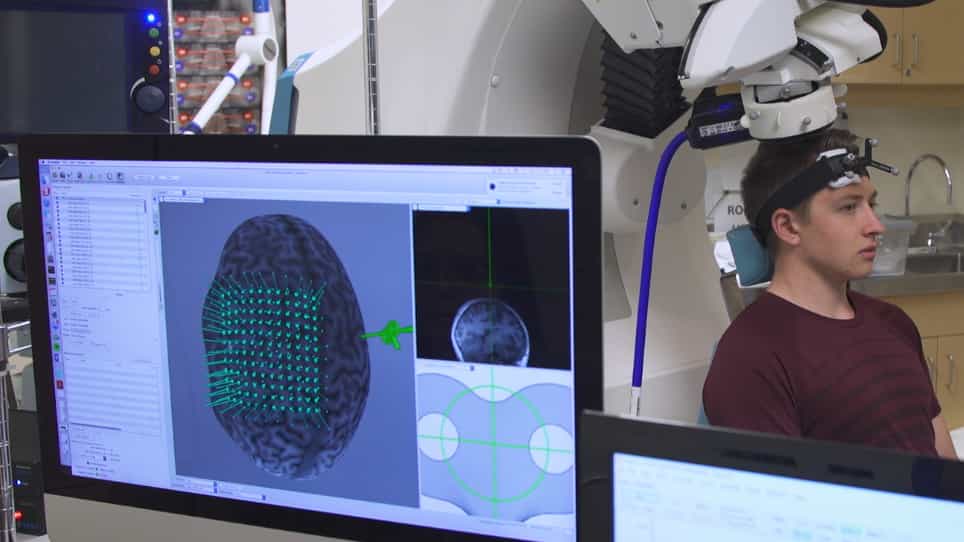

Non-Invasive Modulation and Robotic Mapping of Motor Cortex in the Developing Brain
Published on: July 1, 2019
Merging information in the entorhinal cortex: what can we learn from robotics experiments and modeling?
Philippe Gaussier1, Jean Paul Banquet2, Nicolas Cuperlier2
1ETIS - UMR 8051, Université Paris-Seine, Université de Cergy-Pontoise, ENSEA, CNRS, Cergy-Pontoise 95302, France gaussier@ensea.fr.

Abstract:
Place recognition is a complex process involving idiothetic and allothetic information. In mammals, evidence suggests that visual information stemming from the temporal and parietal cortical areas ('what' and 'where' information) is merged at the level of the entorhinal cortex (EC) to build a compact code of a place. Local views extracted from specific feature points can provide information important for view cells (in primates) and place cells (in rodents) even when the environment changes dramatically. Robotics experiments using conjunctive cells merging 'what' and 'where' information related to different local views show their important role for obtaining place cells with strong generalization capabilities. This convergence of information may also explain the formation of grid cells in the medial EC if we suppose that: (1) path integration information is computed outside the EC, (2) this information is compressed at the level of the EC owing to projection (which follows a modulo principle) of cortical activities associated with discretized vector fields representing angles and/or path integration, and (3) conjunctive cells merge the projections of different modalities to build grid cell activities. Applying modulo projection to visual information allows an interesting compression of information and could explain more recent results on grid cells related to visual exploration. In conclusion, the EC could be dedicated to the build-up of a robust yet compact code of cortical activity whereas the hippocampus proper recognizes these complex codes and learns to predict the transition from one state to another.


Related Concept Videos
 01:12
What is an Experiment?
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:21
Association Areas of the Cortex
Prefrontal Association Area: This area is located in the frontal lobe and is involved in planning, decision-making, and moderating social behavior. It connects with primary motor areas,...
 01:19
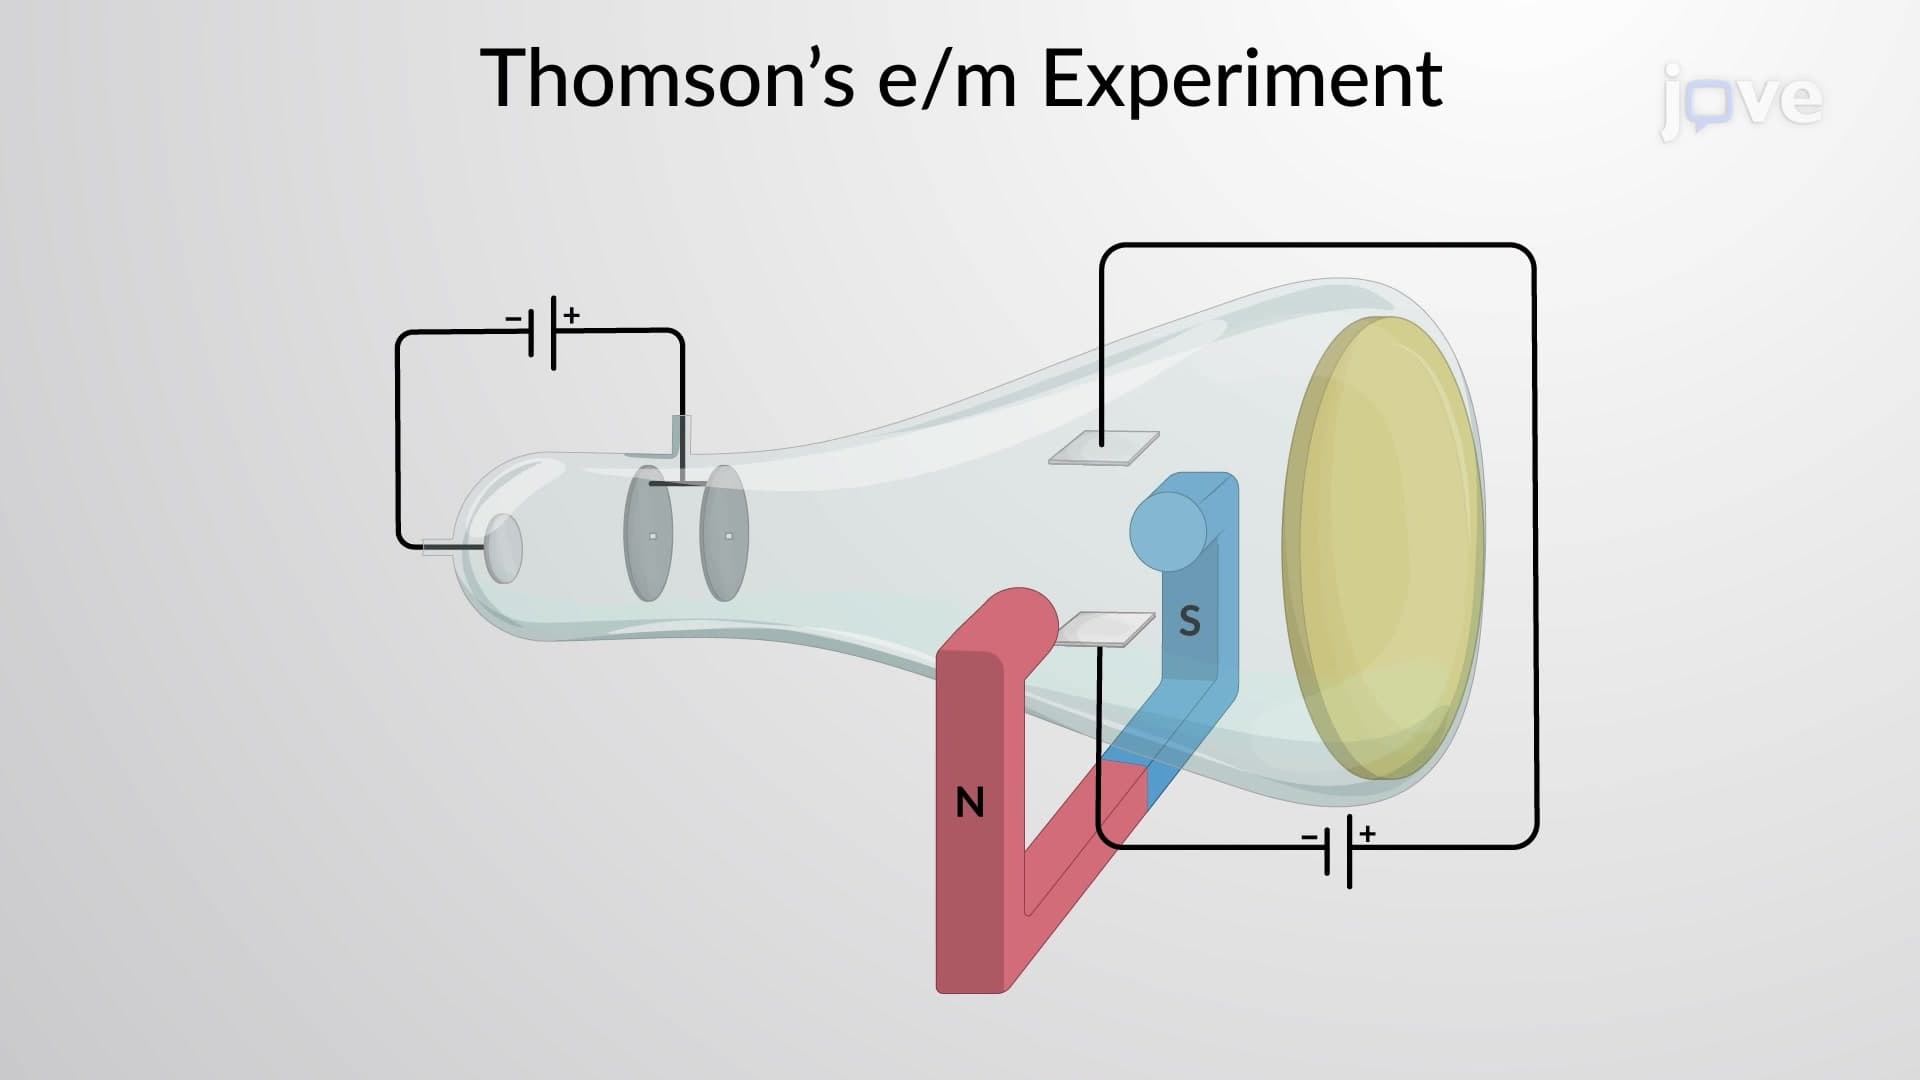
Thomson's e/m Experiment
A particle with charge q, speed v, and mass m enters an area from the top, where the magnetic and electric fields are perpendicular both to the particle's motion and to one another. The magnetic...
 01:13
Controls in Experiments
 01:13
Randomized Experiments
Simple randomization
Simple...