Related Experiment Video
Updated: Jan 29, 2026
Plasma Polishing as a New Polishing Option to Reduce the Surface Roughness of Porous Titanium Alloy for 3D Printing
Published on: April 28, 2023
Research and Method of Roughness Prediction of a Curvilinear Surface after Titanium Alloy Turning
Andrzej Matras, Wojciech Zębala1, Magdalena Machno
1Production Engineering Institute, Mechanical Faculty, Cracow University of Technology, 31-155 Kraków, Poland. zebala@mech.pk.edu.pl.

Abstract:
This paper deals with the optimization of process parameters (such as cutting speed and feed rate) to minimize surface roughness in the turning of a titanium alloy (Ti-6Al-4V) workpiece with spherical shape. In the first part of the article, based on the results analysis, a mathematical model is developed. It is shown that cutting speed has little effect on the surface roughness. The second part of the paper presents the application of the developed method to optimize cutting data such as feed rate in order to obtain the surface roughness parameters Ra and Rz of the curvilinear surface of the titanium alloy workpiece at acceptable and aligned, values regardless of the surface shape and its tilted angle. A case study verifies the correctness of the proposed method. The machining time was substantially shortened in comparison to the non-optimized cutting process.
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
 02:27
Predicting Molecular Geometry
 01:34
Directing Proteins to the Rough Endoplasmic Reticulum
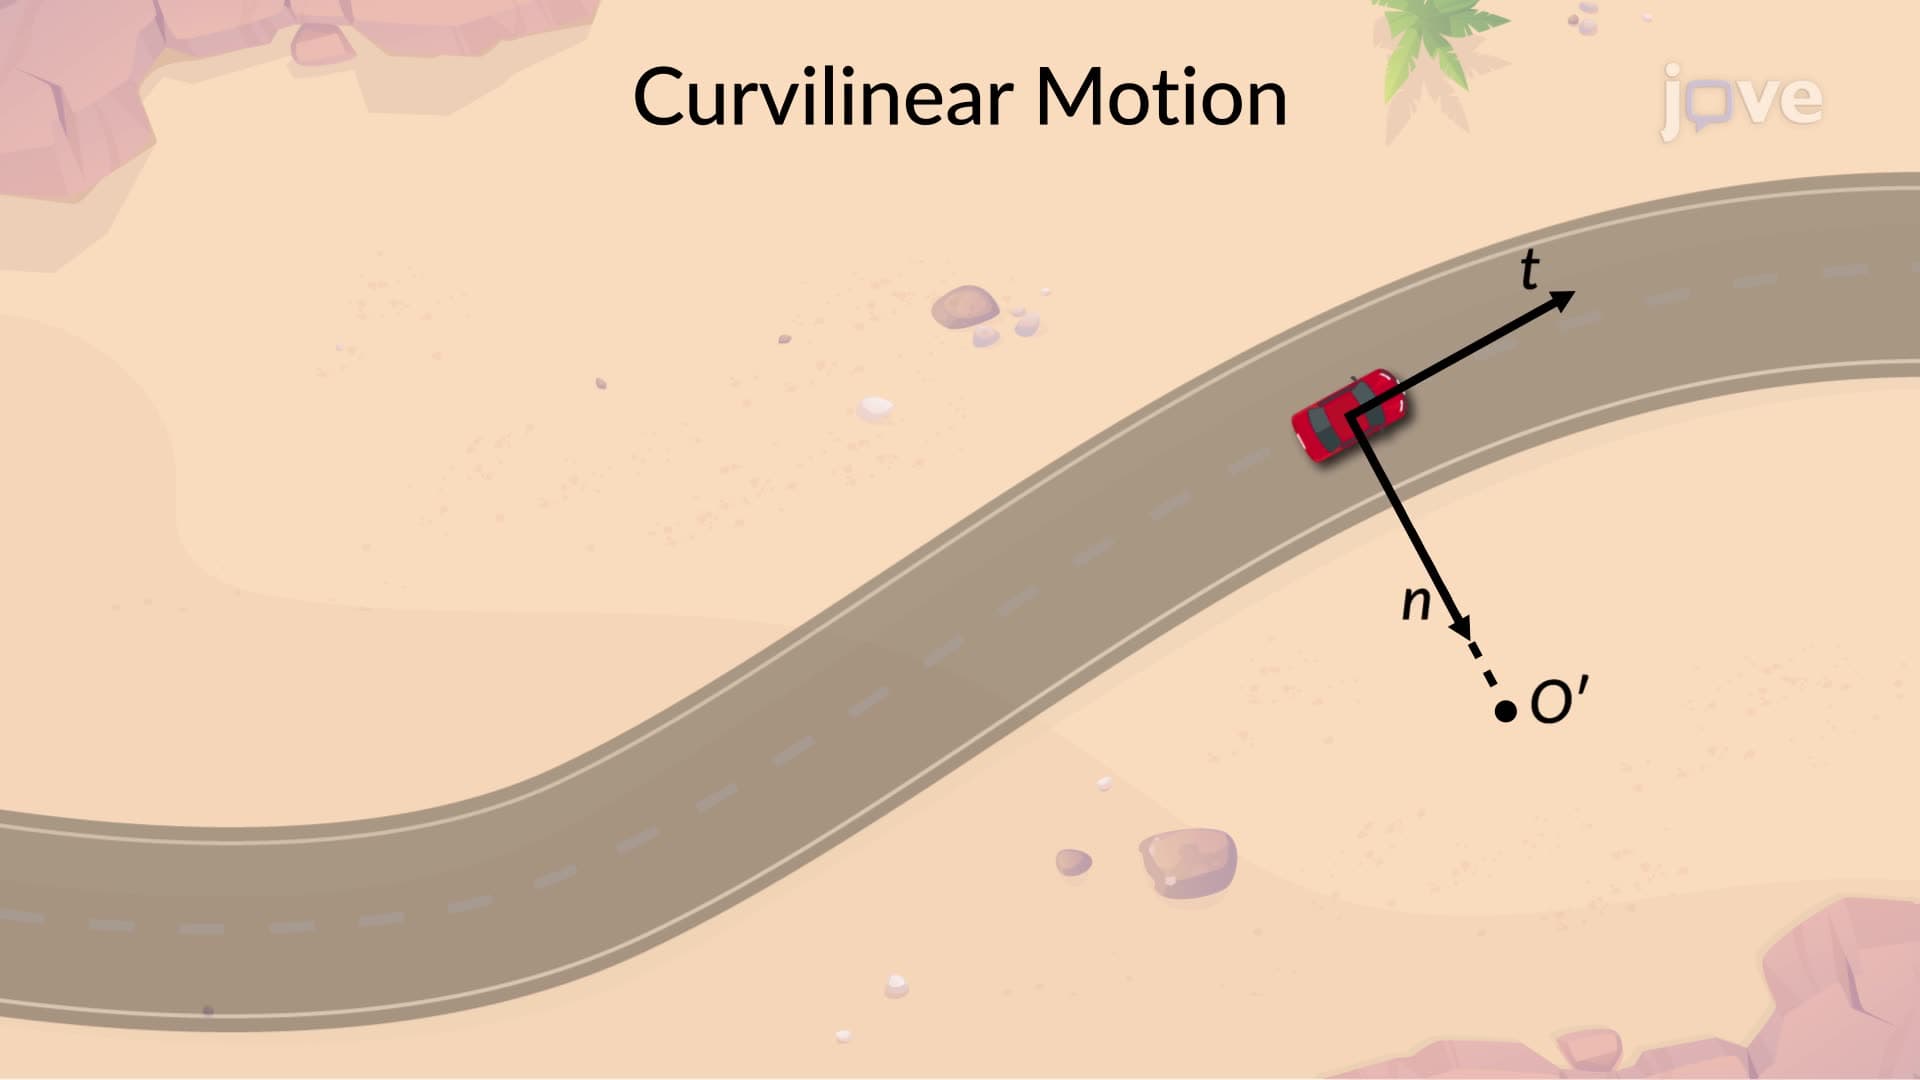 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:03
Prediction Intervals
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.