An Extreme Case of Systemic Metallosis After Implantation of a Hip Prosthesis
Related Experiment Video
Updated: Jan 29, 2026
08:40
Author Spotlight: A Novel 3D-Printed Titanium Implant for Minimally Invasive Treatment of Hip Dysplasia in Young Dogs
Published on: April 19, 2024
3.7K
Deutsches Arzteblatt International
|February 16, 2019

Abstract
No abstract available in PubMed .
More Related Videos
 10:00
Techniques for Processing Eyes Implanted with a Retinal Prosthesis for Localized Histopathological Analysis: Part 2 Epiretinal Implants with Retinal Tacks
Published on: February 14, 2015
12.7K
 08:46
A Standardized Method for Measuring Internal Lung Surface Area via Mouse Pneumonectomy and Prosthesis Implantation
Published on: July 26, 2017
13.9K
Related Concept Videos
 01:22
Absolute and Local Extreme Values
63
The highest and lowest values of a function, relative to a reference axis, are known as extreme values. These include absolute maximum and absolute minimum values, which represent the highest and lowest points the function reaches across its entire domain. Within a restricted portion of the function, the highest and lowest values are referred to as local maximum and local minimum values, respectively.Periodic functions, such as sine and cosine, show extreme values at infinitely many points due...
63
 01:18
Second Order systems II
406
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
406
 01:21
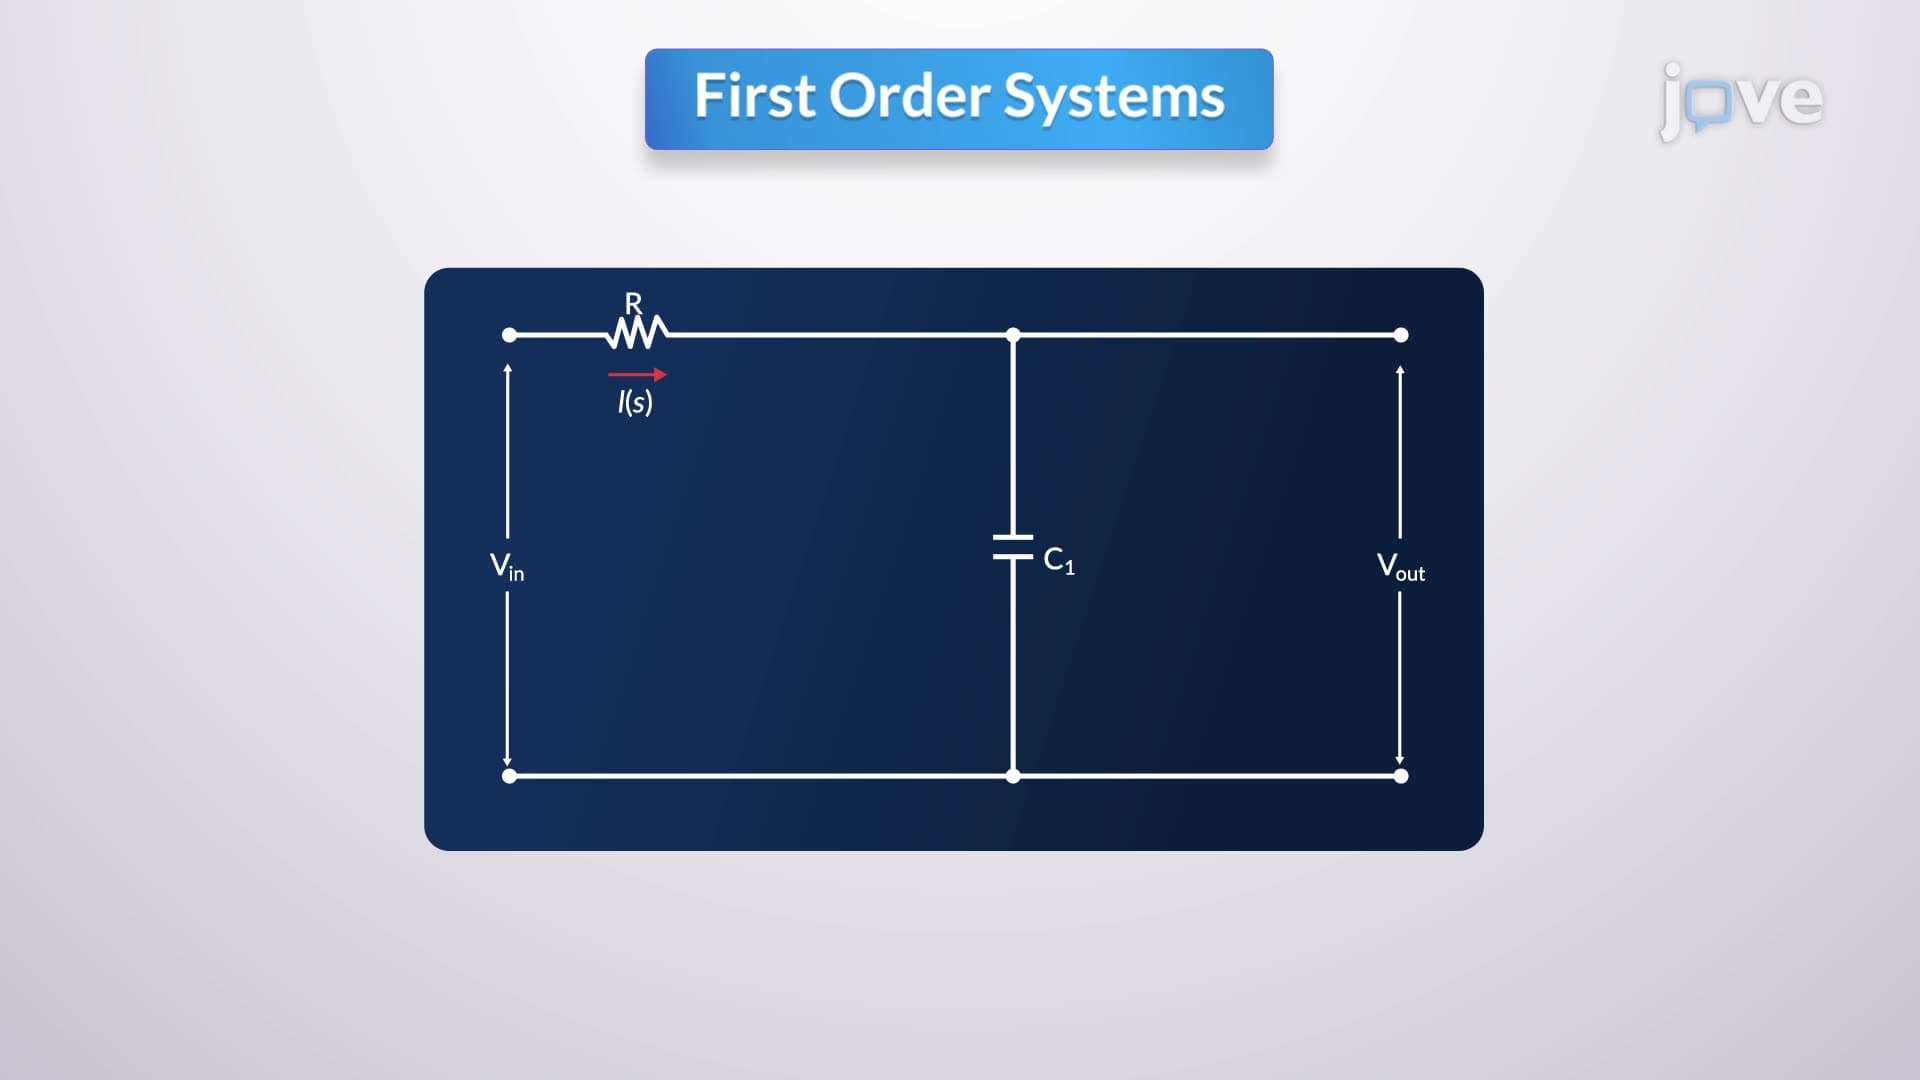
First Order Systems
426
First-order systems, such as RC circuits, are foundational in understanding dynamic systems due to their straightforward input-output relationship. Analyzing their responses to different input functions under zero initial conditions reveals significant insights into system behavior.
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
426
 01:20
Second Order systems I
591
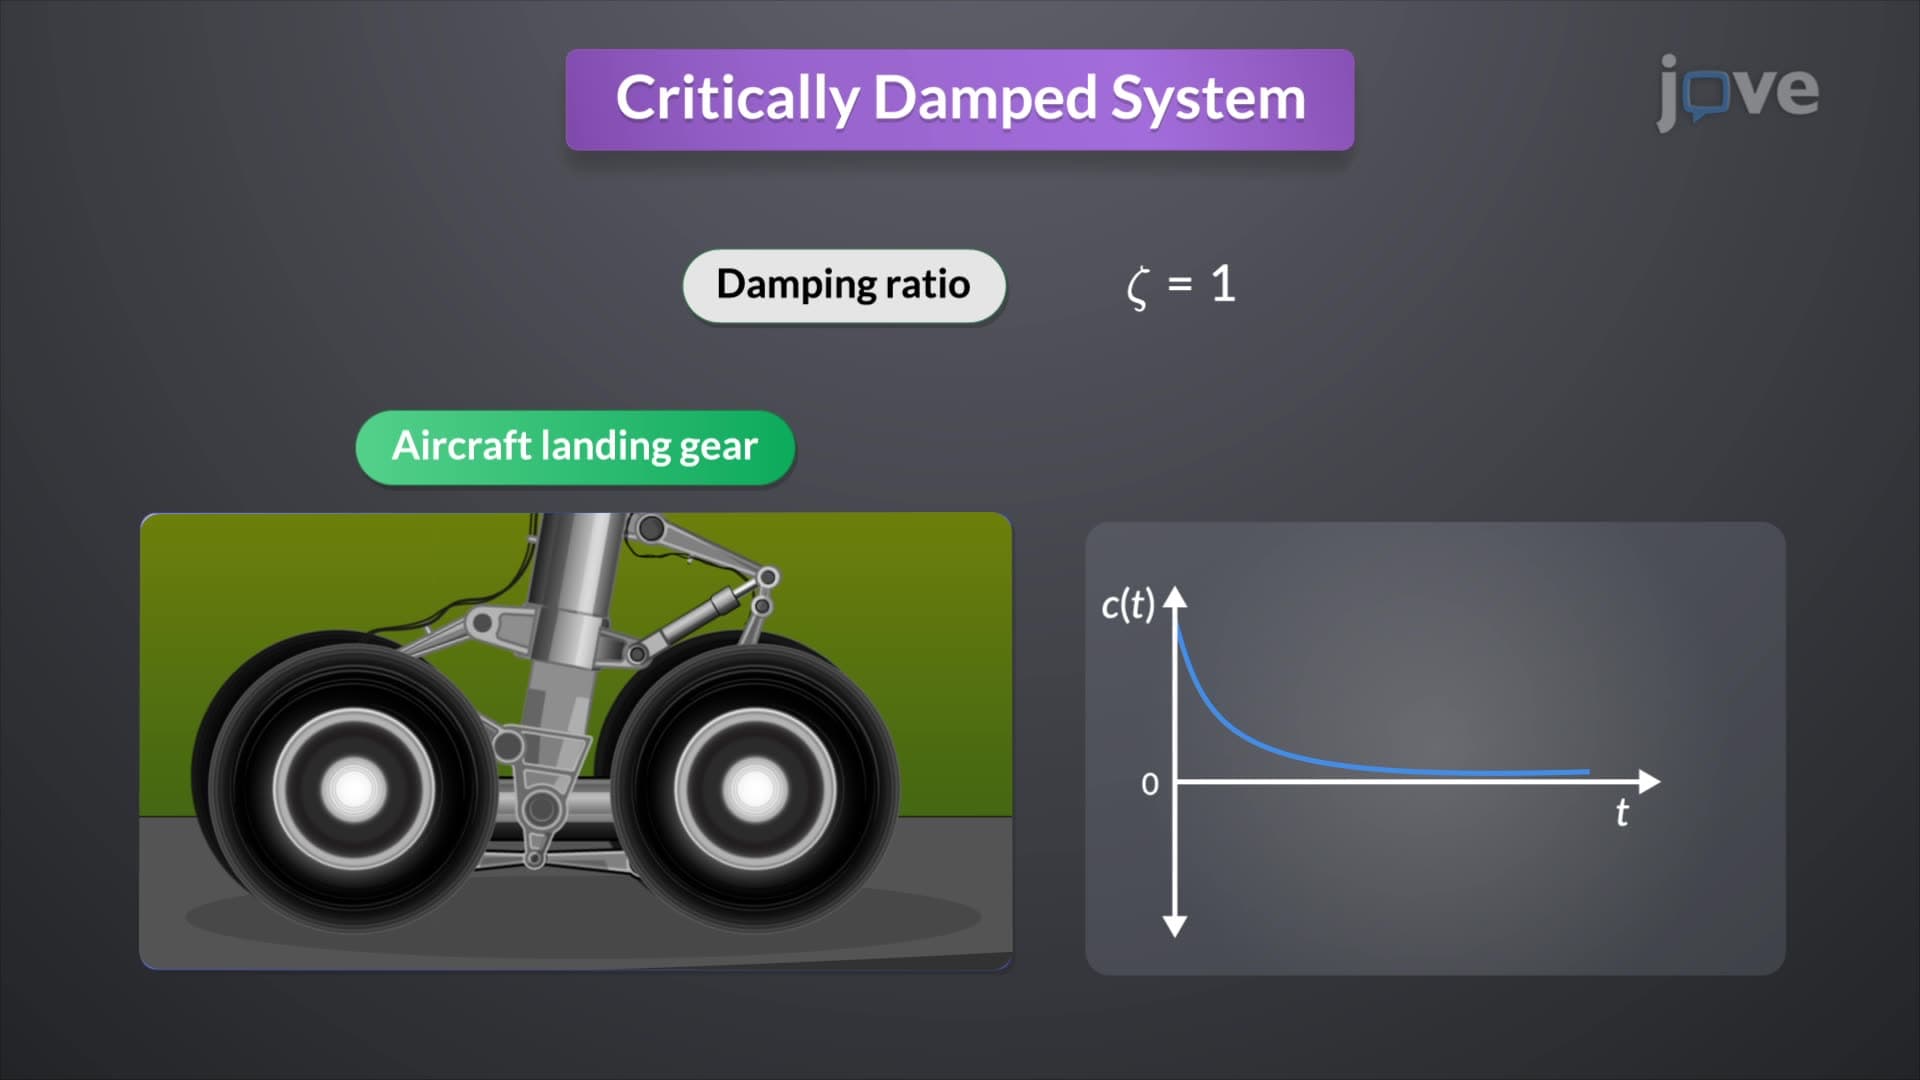
A servo system exemplifies a second-order system, featuring a proportional controller and load elements that ensure the output position aligns with the input position. The relationship between these components is described by a second-order differential equation. Applying the Laplace transform under zero initial conditions yields the transfer function, showing how inputs are converted to outputs in the system.
By reinterpreting the system, one can derive the closed-loop transfer function, which...
By reinterpreting the system, one can derive the closed-loop transfer function, which...
591
 01:06
Thermodynamic Systems
7.9K
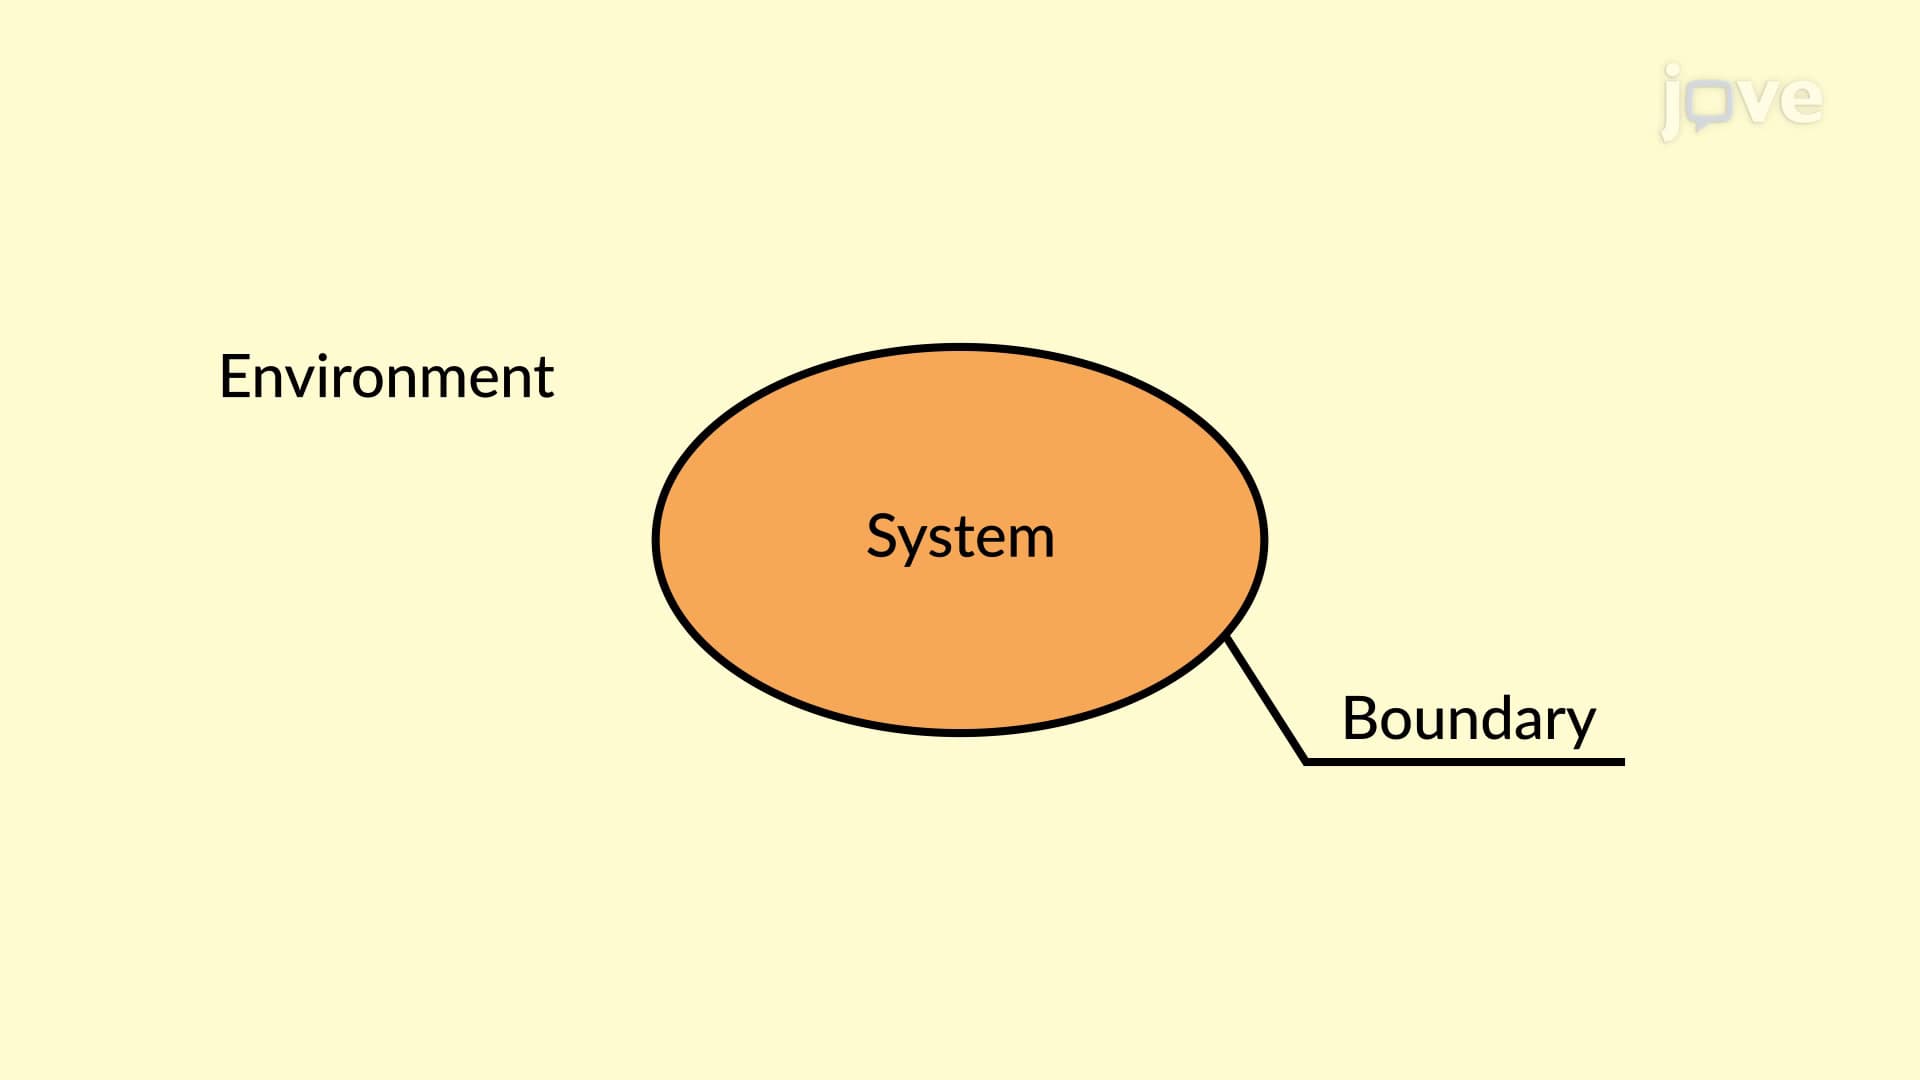
A thermodynamic system is a set of objects whose thermodynamic properties are of interest. The system is considered to be embedded in its surroundings or the environment. The system and its environment can exchange heat and do work on each other through a boundary that separates them. However, the immediate surroundings of the system interact with it directly and therefore have a much stronger influence on its behavior and properties.
Consider an example of tea boiling in a kettle. The...
Consider an example of tea boiling in a kettle. The...
7.9K
 01:26
Classification of Systems-I
592
Linearity is a system property characterized by a direct input-output relationship, combining homogeneity and additivity.
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
592