Related Experiment Video
Updated: Jan 28, 2026

A Tactile Automated Passive-Finger Stimulator TAPS
Published on: June 3, 2009
Linear Integration of Tactile and Non-tactile Inputs Mediates Estimation of Fingertip Relative Position
Simone Toma1, Daisuke Shibata2, Francesco Chinello3,4
1School of Biological and Health Systems Engineering, Arizona State University, Tempe, AZ, United States.

Abstract:
While skin, joints and muscles receptors alone provide lower level information about individual variables (e.g., exerted limb force and limb displacement), the distance between limb endpoints (i.e., relative position) has to be extracted from high level integration of somatosensory and motor signals. In particular, estimation of fingertip relative position likely involves more complex sensorimotor transformations than those underlying hand or arm position sense: the brain has to estimate where each fingertip is relative to the hand and where fingertips are relative to each other. It has been demonstrated that during grasping, feedback of digit position drives rapid adjustments of fingers force control. However, it has been shown that estimation of fingertips' relative position can be biased by digit forces. These findings raise the question of how the brain combines concurrent tactile (i.e., cutaneous mechanoreceptors afferents induced by skin pressure and stretch) and non-tactile (i.e., both descending motor command and joint/muscle receptors signals associated to muscle contraction) digit force-related inputs for fingertip distance estimation. Here we addressed this question by quantifying the contribution of tactile and non-tactile force-related inputs for the estimation of fingertip relative position. We asked subjects to match fingertip vertical distance relying only on either tactile or non-tactile inputs from the thumb and index fingertip, and compared their performance with the condition where both types of inputs were combined. We found that (a) the bias in the estimation of fingertip distance persisted when tactile inputs and non-tactile force-related signals were presented in isolation; (b) tactile signals contributed the most to the estimation of fingertip distance; (c) linear summation of the matching errors relying only on either tactile or non-tactile inputs was comparable to the matching error when both inputs were simultaneously available. These findings reveal a greater role of tactile signals for sensing fingertip distance and suggest a linear integration mechanism with non-tactile inputs for the estimation of fingertip relative position.
Related Concept Videos
 01:27
Tactile and Chemical Senses
 01:09
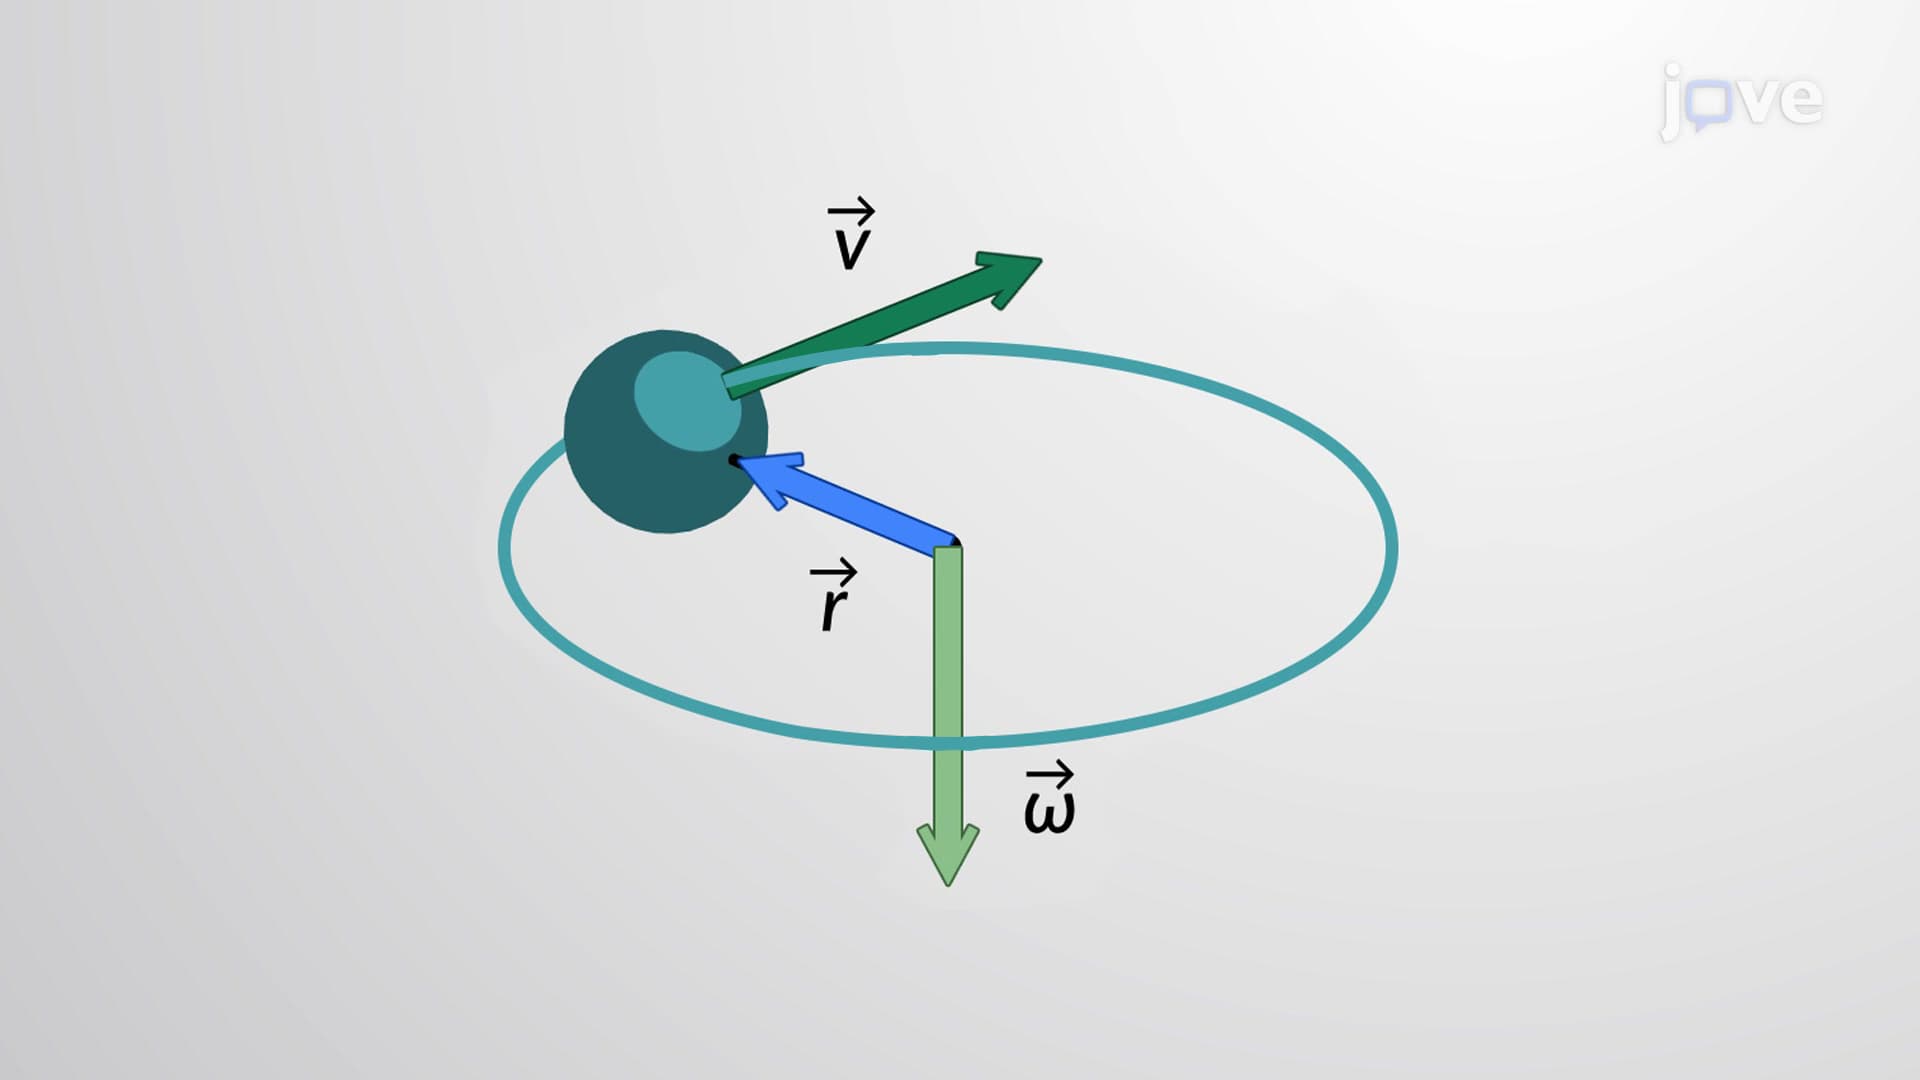
Relating Angular And Linear Quantities - I
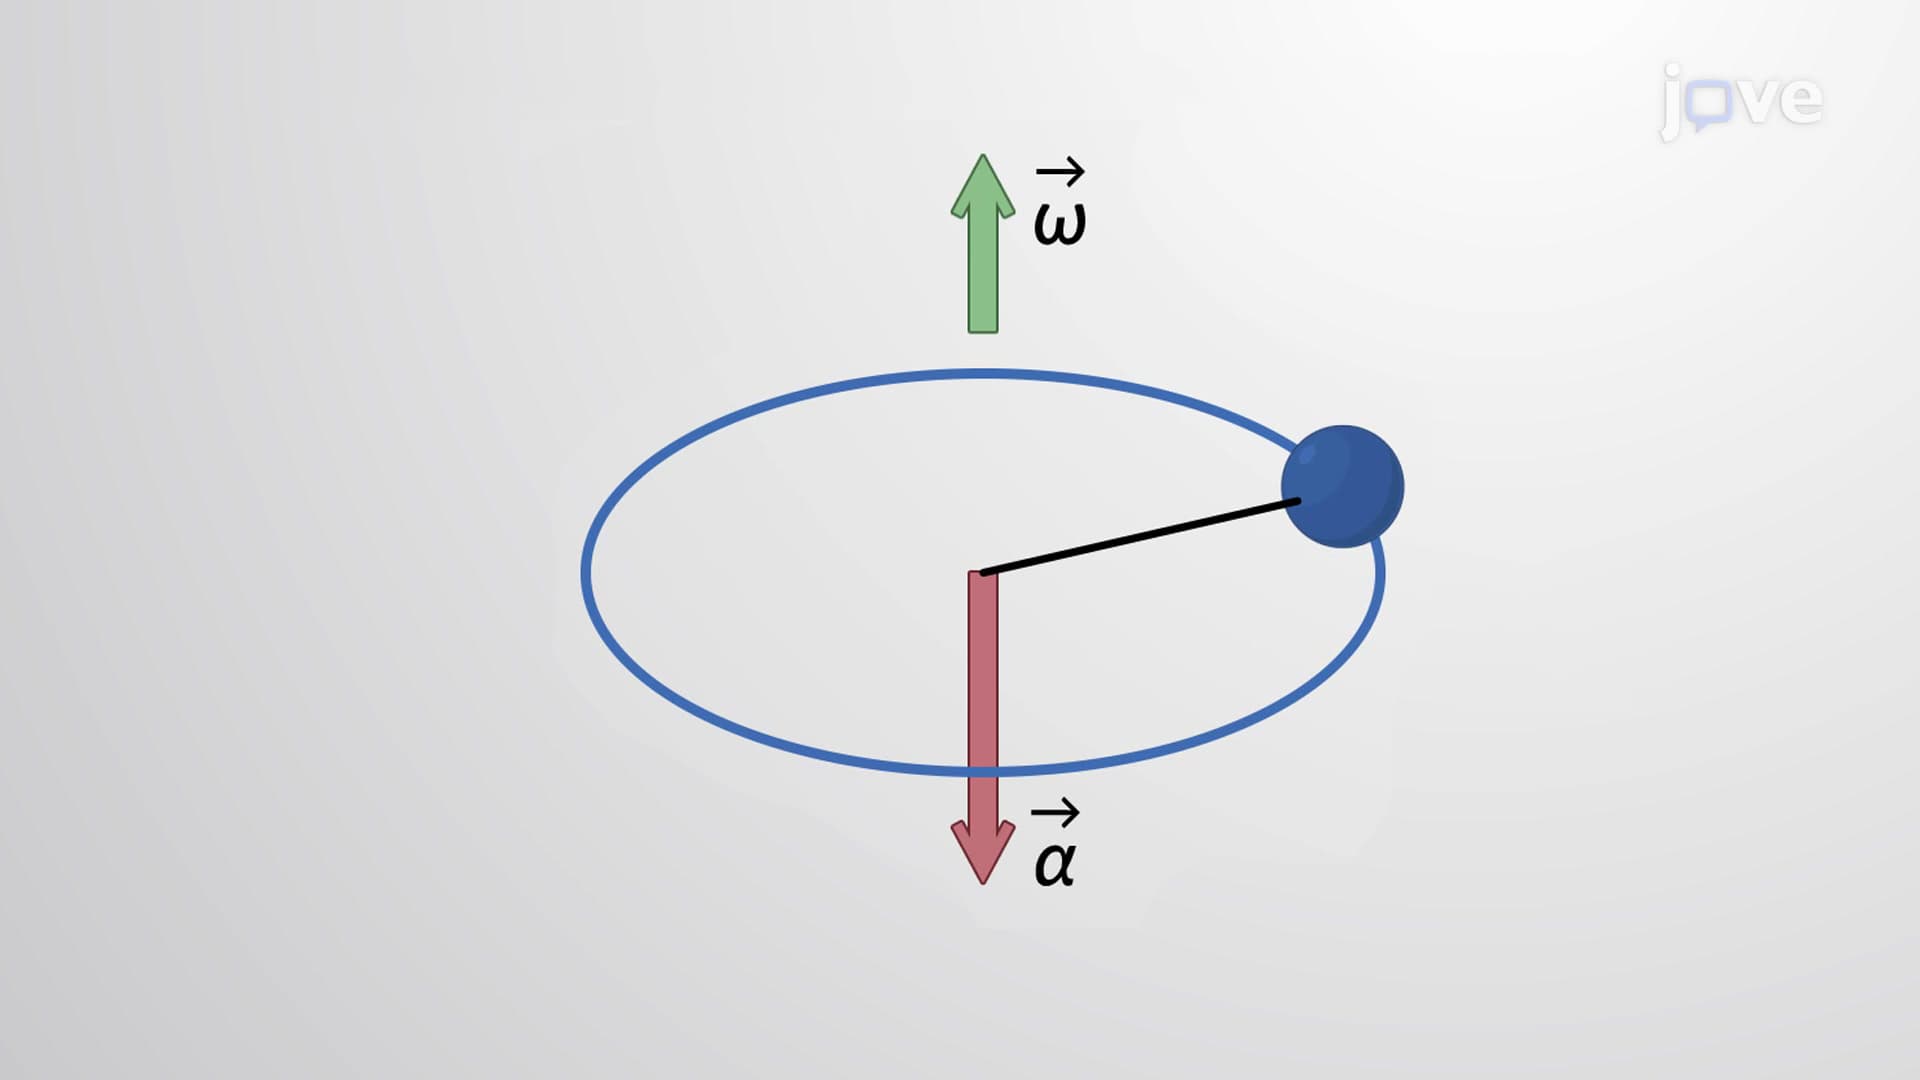
When comparing the linear and rotational variables individually, the linear variable of position has physical units of meters, whereas the angular position variable has dimensionless units of radians, as it is the ratio of two lengths. The linear velocity...
 01:05
Relating Angular And Linear Quantities - II
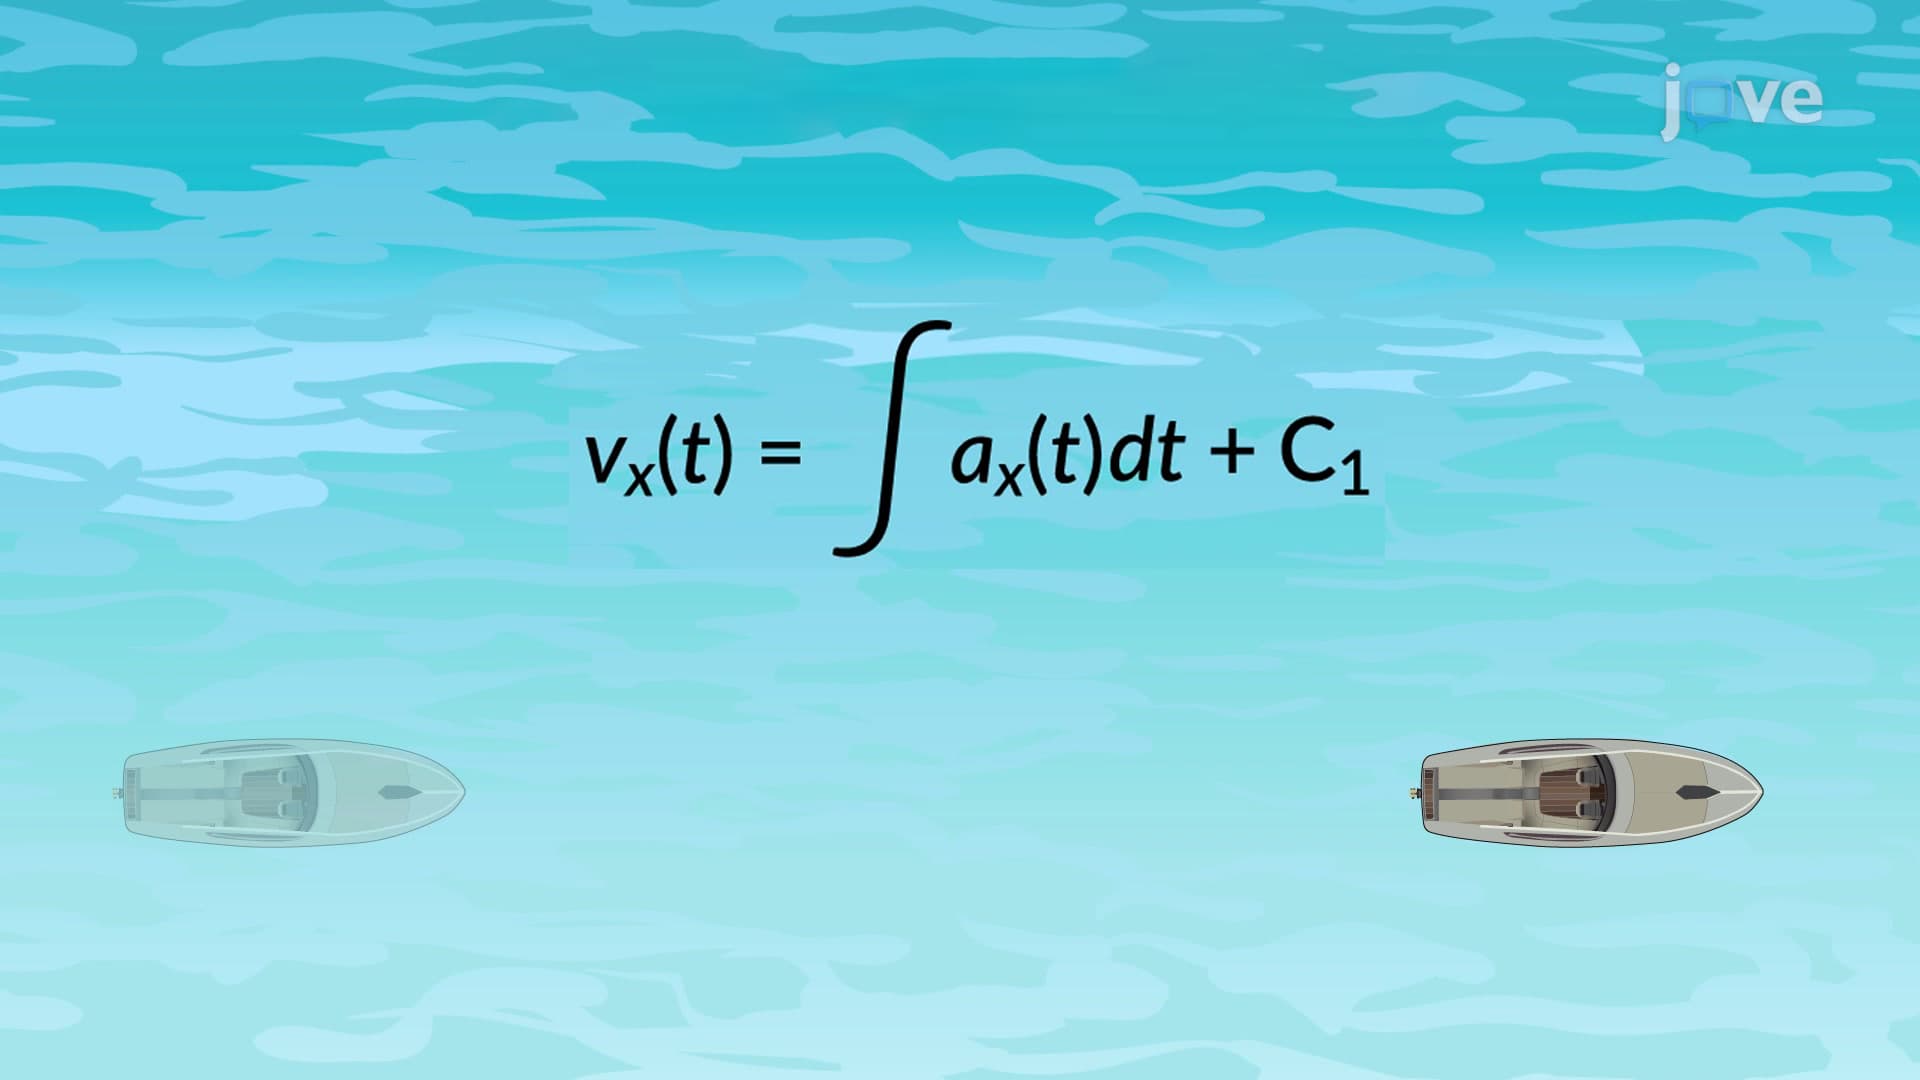 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 02:32
Position-effect Variegation
 02:39
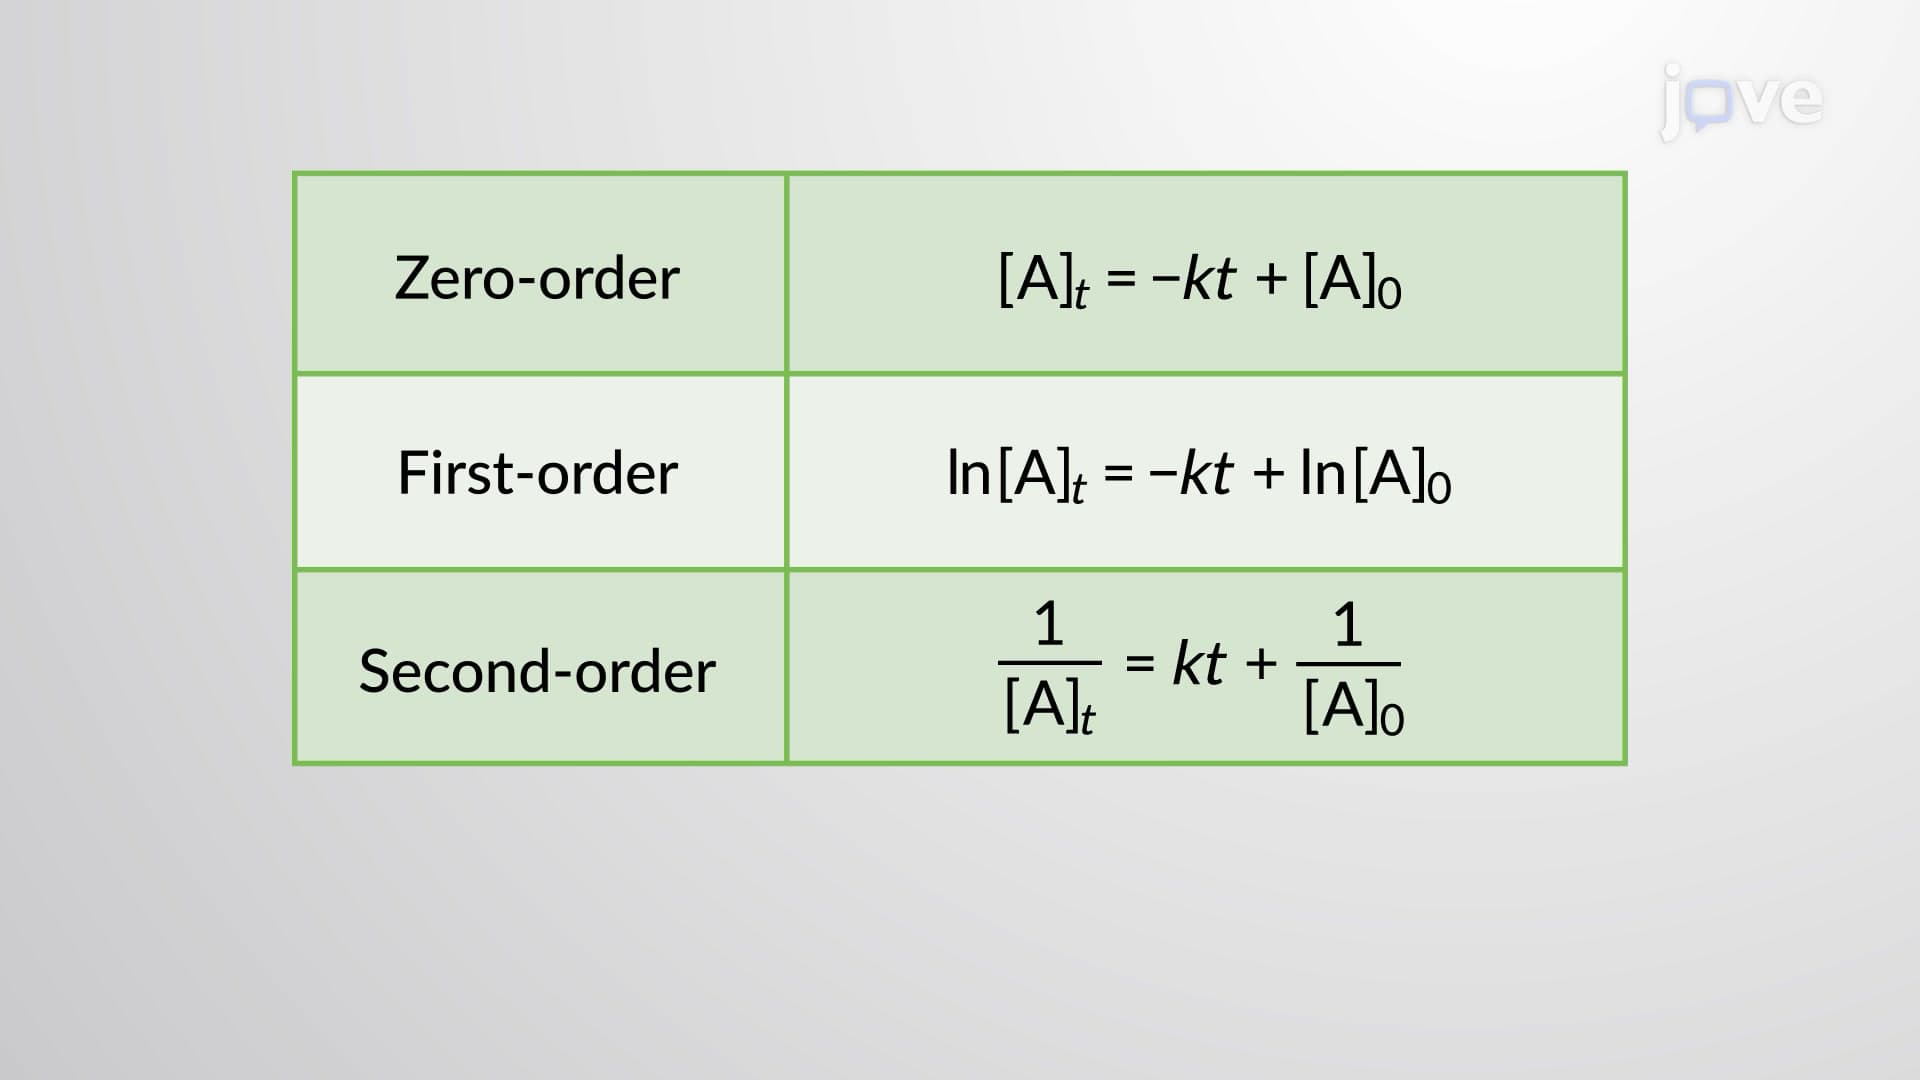
The Integrated Rate Law: The Dependence of Concentration on Time