Parameters identification and trajectory control for a hydraulic system
Hao Feng1, Chenbo Yin1, Wei Ma1
1United Institute of Excavator Key Technology, Nanjing Tech University, Nanjing 211816, China; Institute of Automobile and Construction Machinery, Nanjing Tech University, Nanjing 211816, China.

Abstract:
In order to improve the tracking accuracy of a hydraulic system, an improved ant colony optimization algorithm (IACO) is proposed to optimize the values of proportional-integral-derivative (PID) controller. In addition, this paper presents an experimental study on the parameters identification to deduce accurate numerical values of the hydraulic system, which also determines the relationship between control signal and output displacement. Firstly, the basic principle of the hydraulic system and the mathematical model of the electro-hydraulic proportional control system are analyzed. Based on the theoretical models, the transfer function of the control system is obtained by recursive least square identification method (RLS). Then, the key parameters of the control system model are obtained. Some improvements are proposed to avoid premature convergence and slow convergence rate of ACO: the transition probability is revised based adjacent search mechanism, dynamic pheromone evaporation coefficient adjustment strategy is adopted, pheromone update rule and parameters optimization range are also improved. Then the proposed IACO tuning based PID controller and the identification parameters are modeled and simulated using MATLAB/Simulink and AMESim co-simulation platform. Comparisons of IACO, standard ACO and Ziegler-Nichols (Z-N)PID controllers are carried out with different references as step signal and sinusoidal wave using the co-simulation platform. The simulation results of the bucket system using the proposed controller demonstrates improved settling time, rise time and the convergence speed with a new objective function J. Finally, experiments with leveling operations are performed on a 23 ton robotic excavator. The experimental results show that the proposed controller improves the trajectory accuracy of the leveling operation by 28% in comparison to the standard ACO-PID controller.

Related Concept Videos
 01:16
Hydraulic Jump: Problem Solving
 01:29
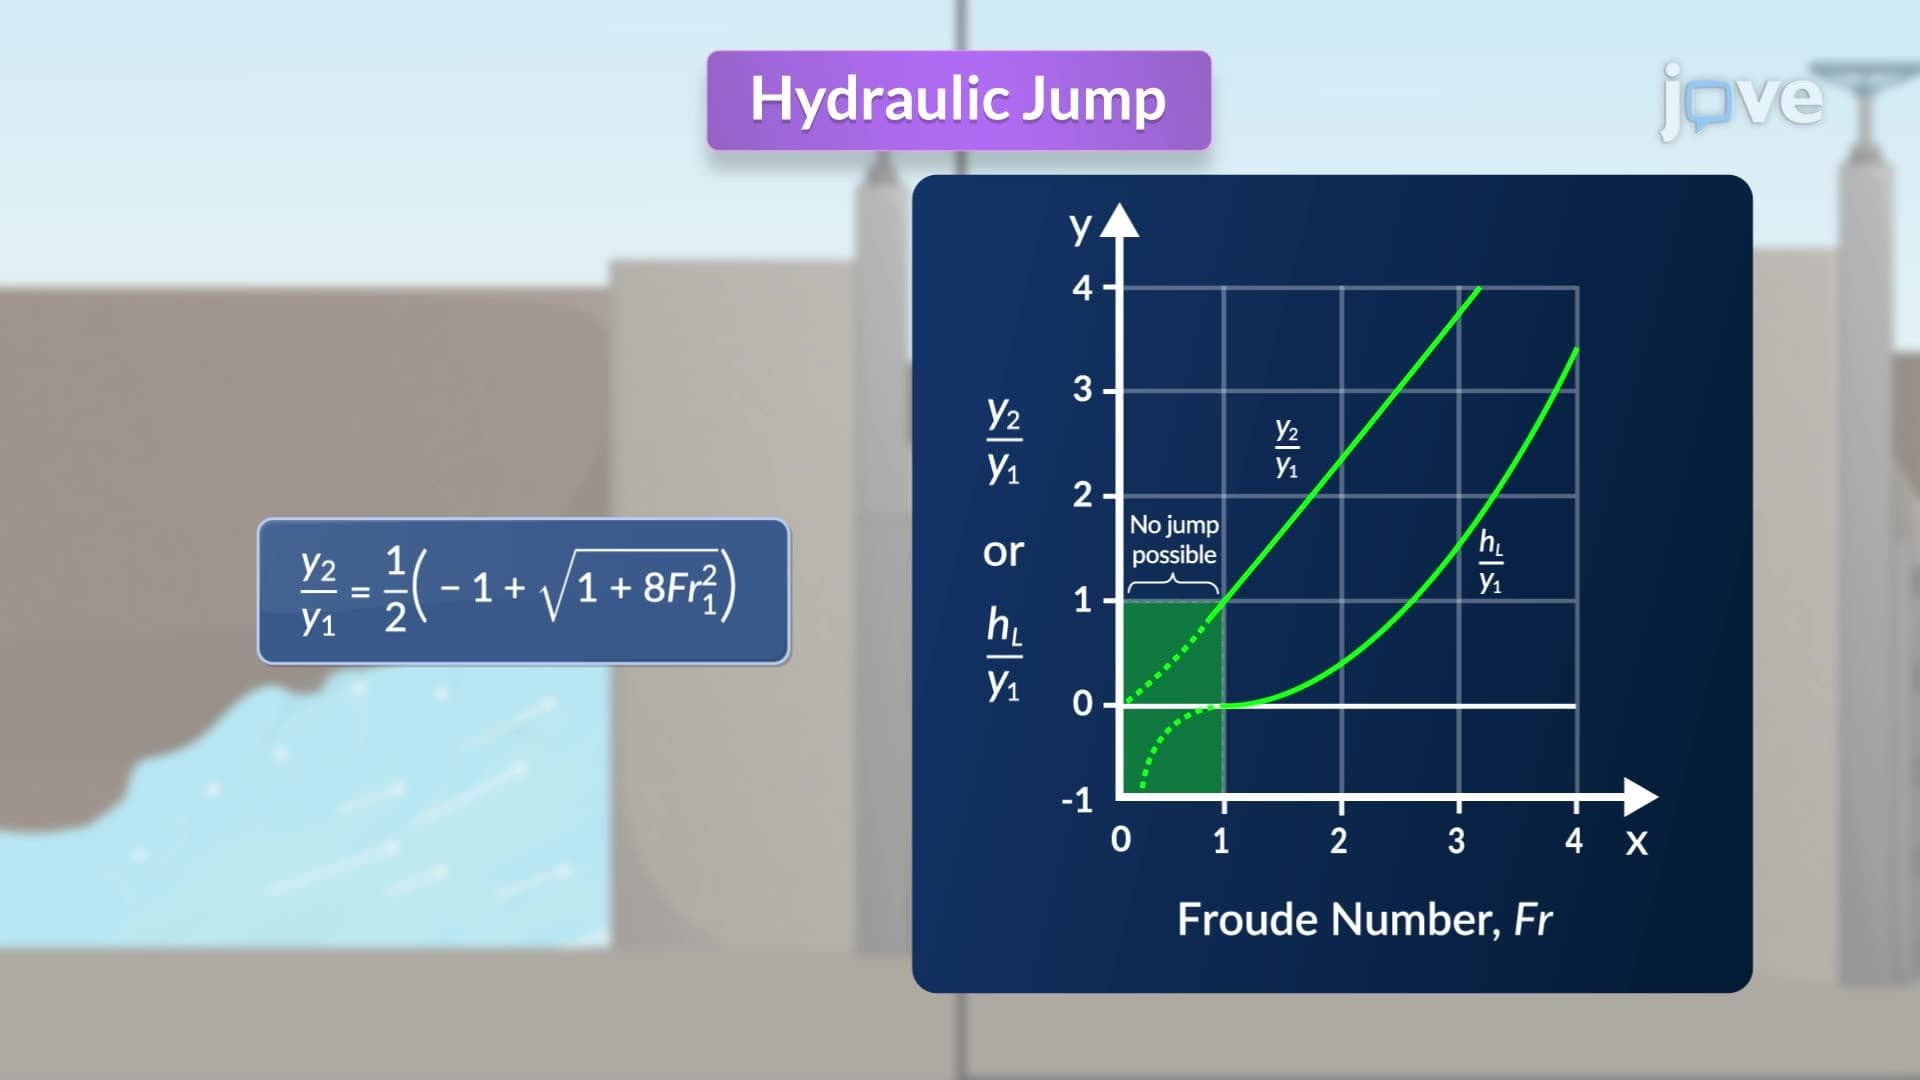
Hydraulic Jump
 01:27
Energy Line and Hydraulic Gradient Line
 01:10
Wave Parameters
 01:21
Design Example: Creating a Hydraulic Model of a Dam Spillway
 01:26
Distributions to Estimate Population Parameter