Data-Driven Robust Control of Discrete-Time Uncertain Linear Systems via Off-Policy Reinforcement Learning
Related Experiment Video
Updated: Jan 28, 2026
The Double-H Maze: A Robust Behavioral Test for Learning and Memory in Rodents
Published on: July 8, 2015

Abstract:
This paper presents a model-free solution to the robust stabilization problem of discrete-time linear dynamical systems with bounded and mismatched uncertainty. An optimal controller design method is derived to solve the robust control problem, which results in solving an algebraic Riccati equation (ARE). It is shown that the optimal controller obtained by solving the ARE can robustly stabilize the uncertain system. To develop a model-free solution to the translated ARE, off-policy reinforcement learning (RL) is employed to solve the problem in hand without the requirement of system dynamics. In addition, the comparisons between on- and off-policy RL methods are presented regarding the robustness to probing noise and the dependence on system dynamics. Finally, a simulation example is carried out to validate the efficacy of the presented off-policy RL approach.
Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:26
Discrete-time Fourier transform
One of the notable...
 01:16
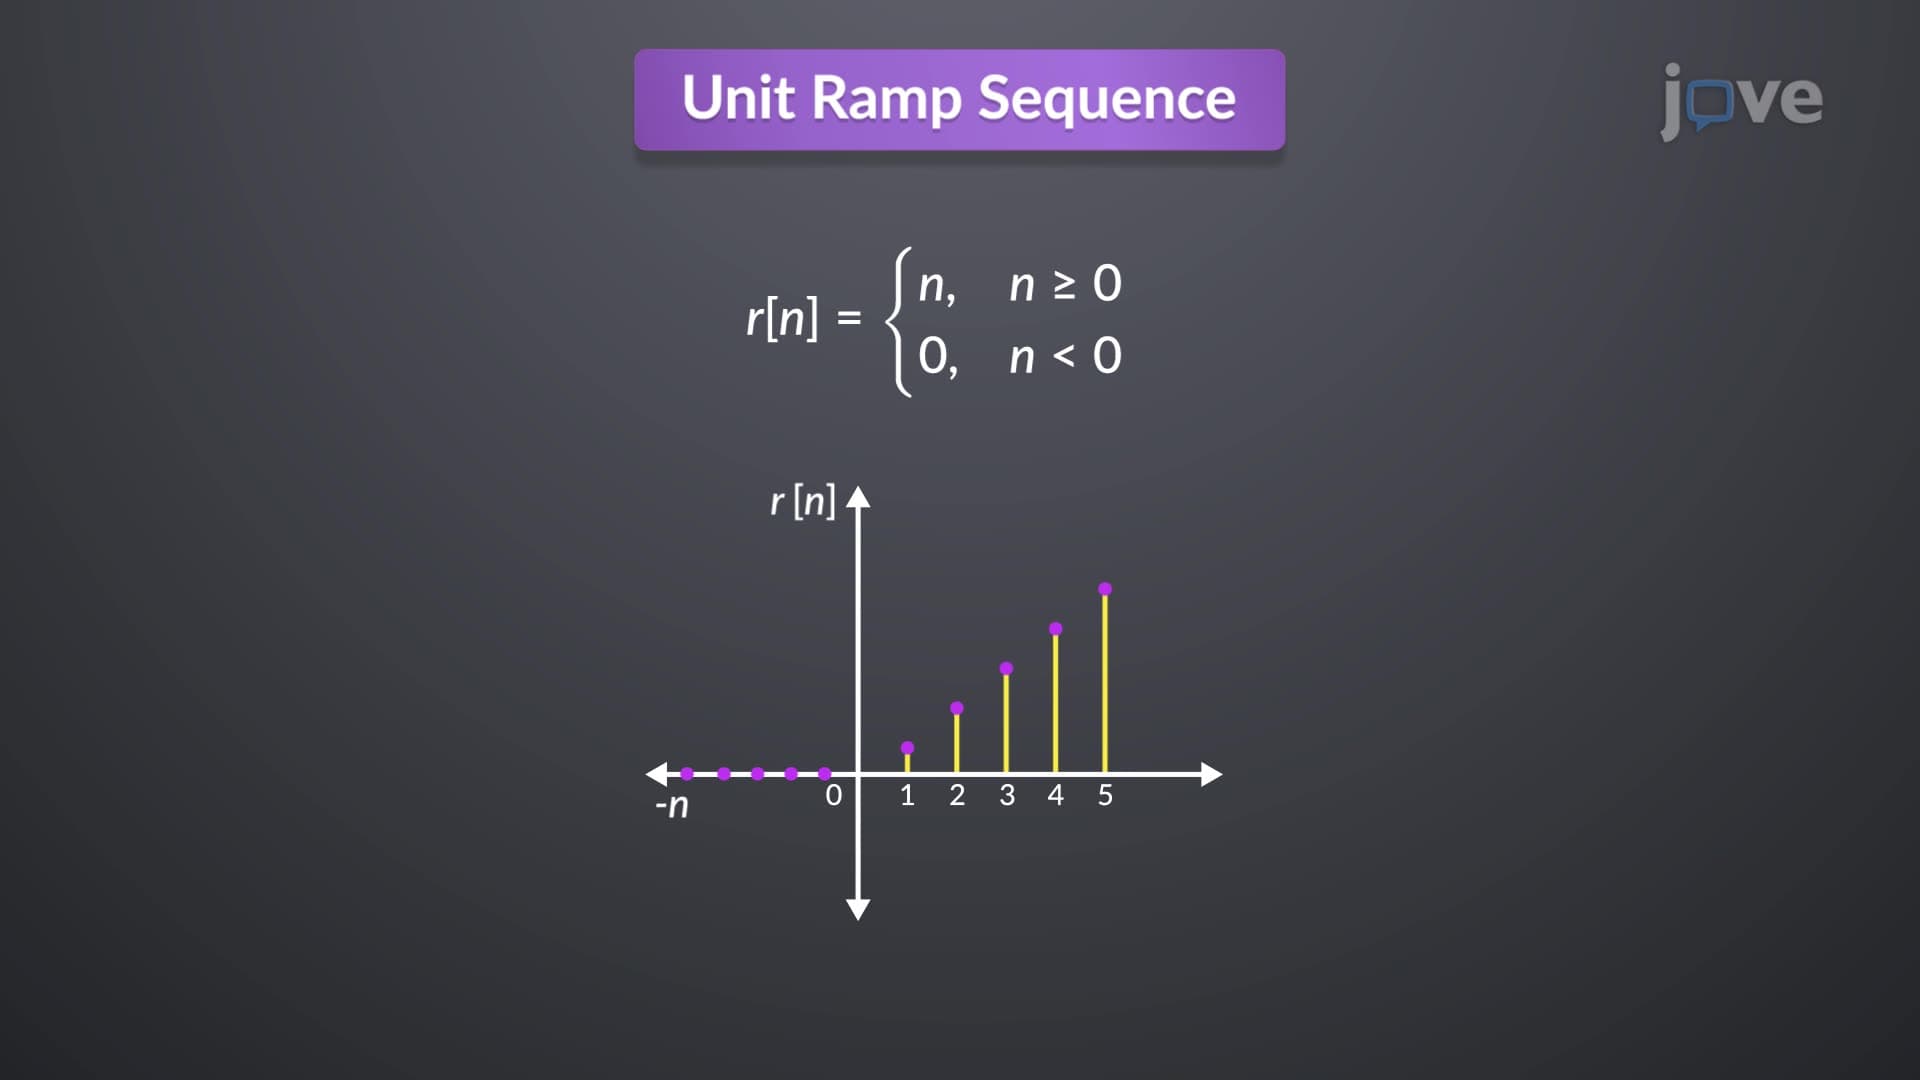
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:20
Discrete-Time Fourier Series
For a discrete-time periodic signal x[n]...
 01:13
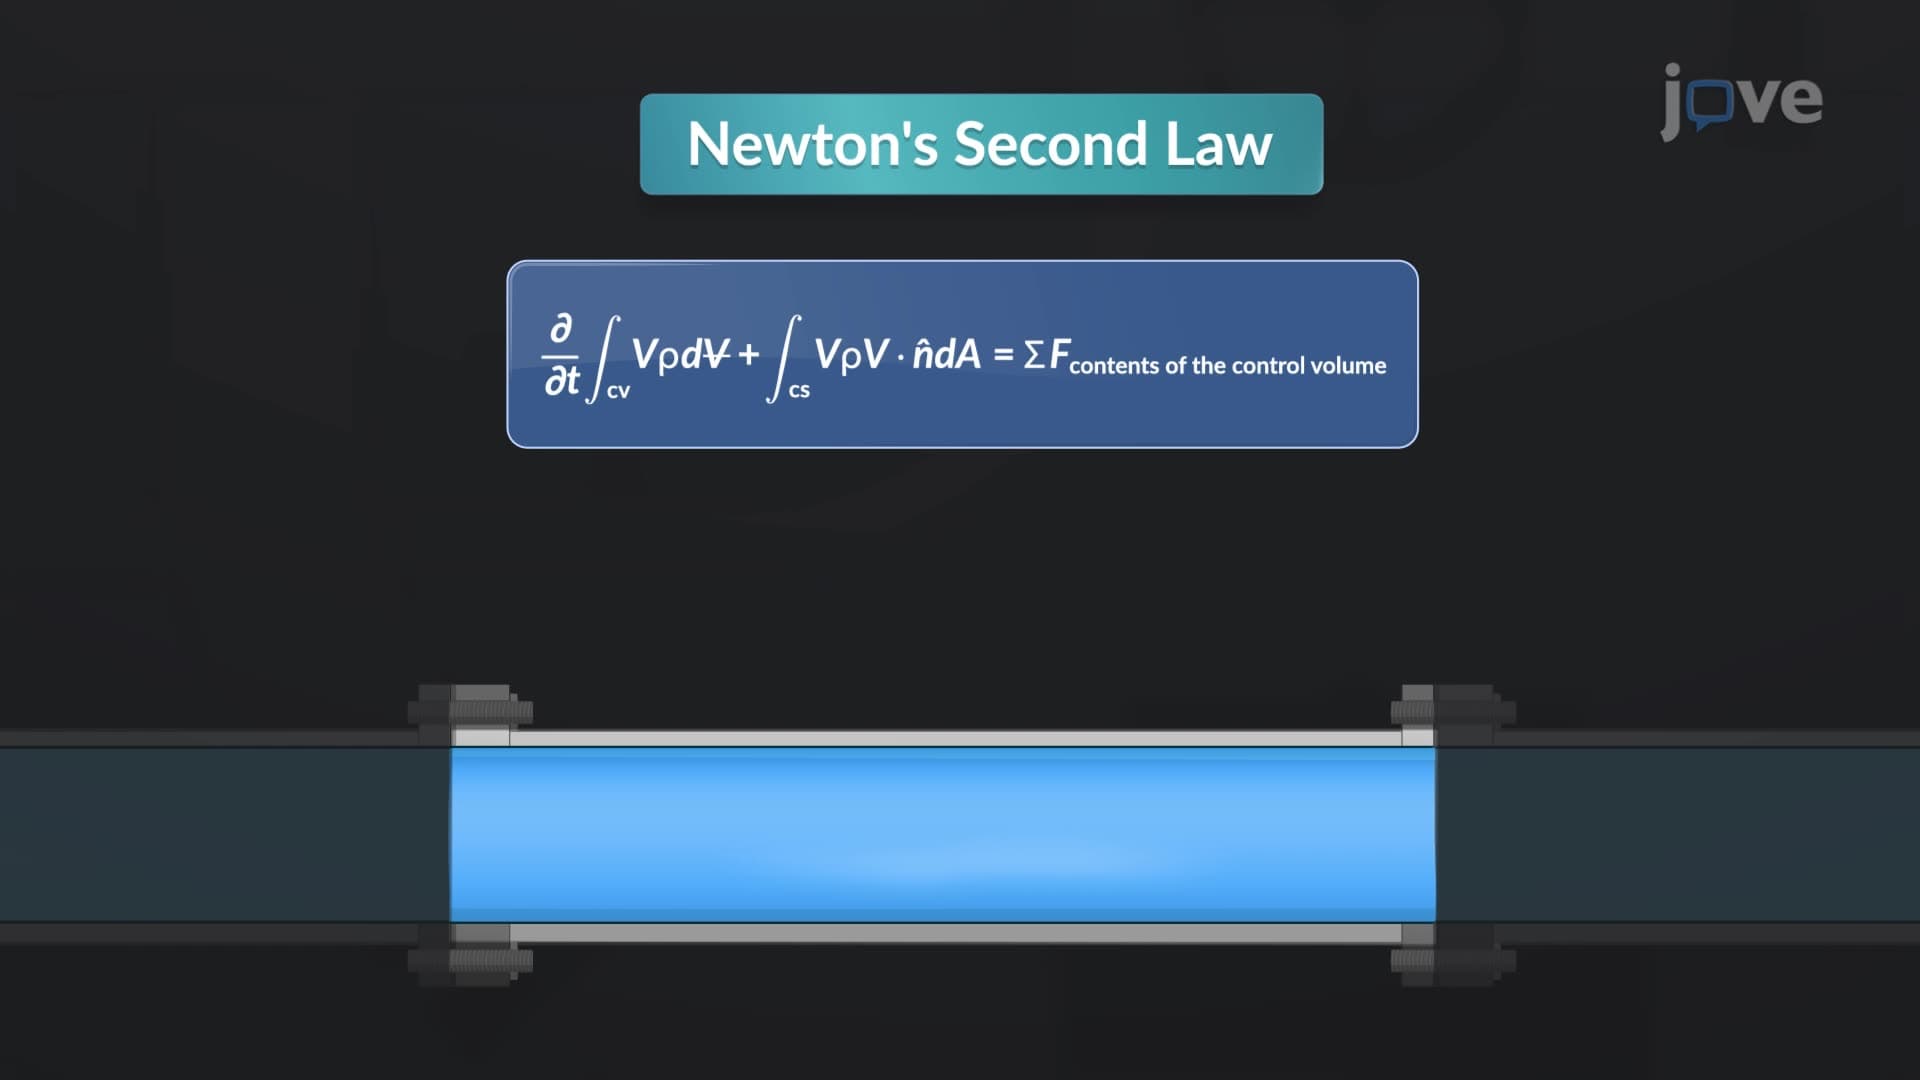
Linear Momentum in Control Volume