Admittance-Based Adaptive Cooperative Control for Multiple Manipulators With Output Constraints
Related Experiment Video
Updated: Jan 28, 2026
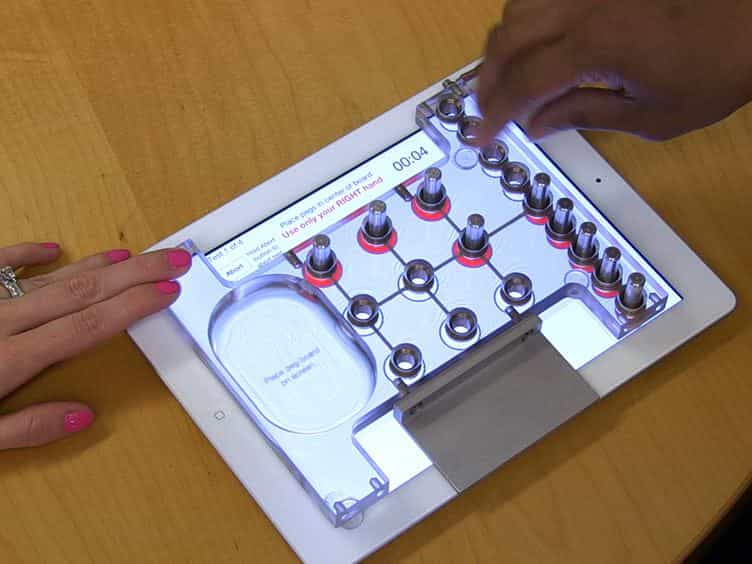
The Multiple Sclerosis Performance Test MSPT: An iPad-Based Disability Assessment Tool
Published on: June 30, 2014

Abstract:
This paper proposes a novel adaptive control methodology based on the admittance model for multiple manipulators transporting a rigid object cooperatively along a predefined desired trajectory. First, an admittance model is creatively applied to generate reference trajectory online for each manipulator according to the desired path of the rigid object, which is the reference input of the controller. Then, an innovative integral barrier Lyapunov function is utilized to tackle the constraints due to the physical and environmental limits. Adaptive neural networks (NNs) are also employed to approximate the uncertainties of the manipulator dynamics. Different from the conventional NN approximation method, which is usually semiglobally uniformly ultimately bounded, a switching function is presented to guarantee the global stability of the closed loop. Finally, the simulation studies are conducted on planar two-link robot manipulators to validate the efficacy of the proposed approach.
Related Concept Videos
 01:58
Cooperative Allosteric Transitions
01:58Cooperative Allosteric Transitions
01:58Cooperative Allosteric Transitions
 02:13
Cooperative Binding of Transcription Regulators
02:13Cooperative Binding of Transcription Regulators
 01:26
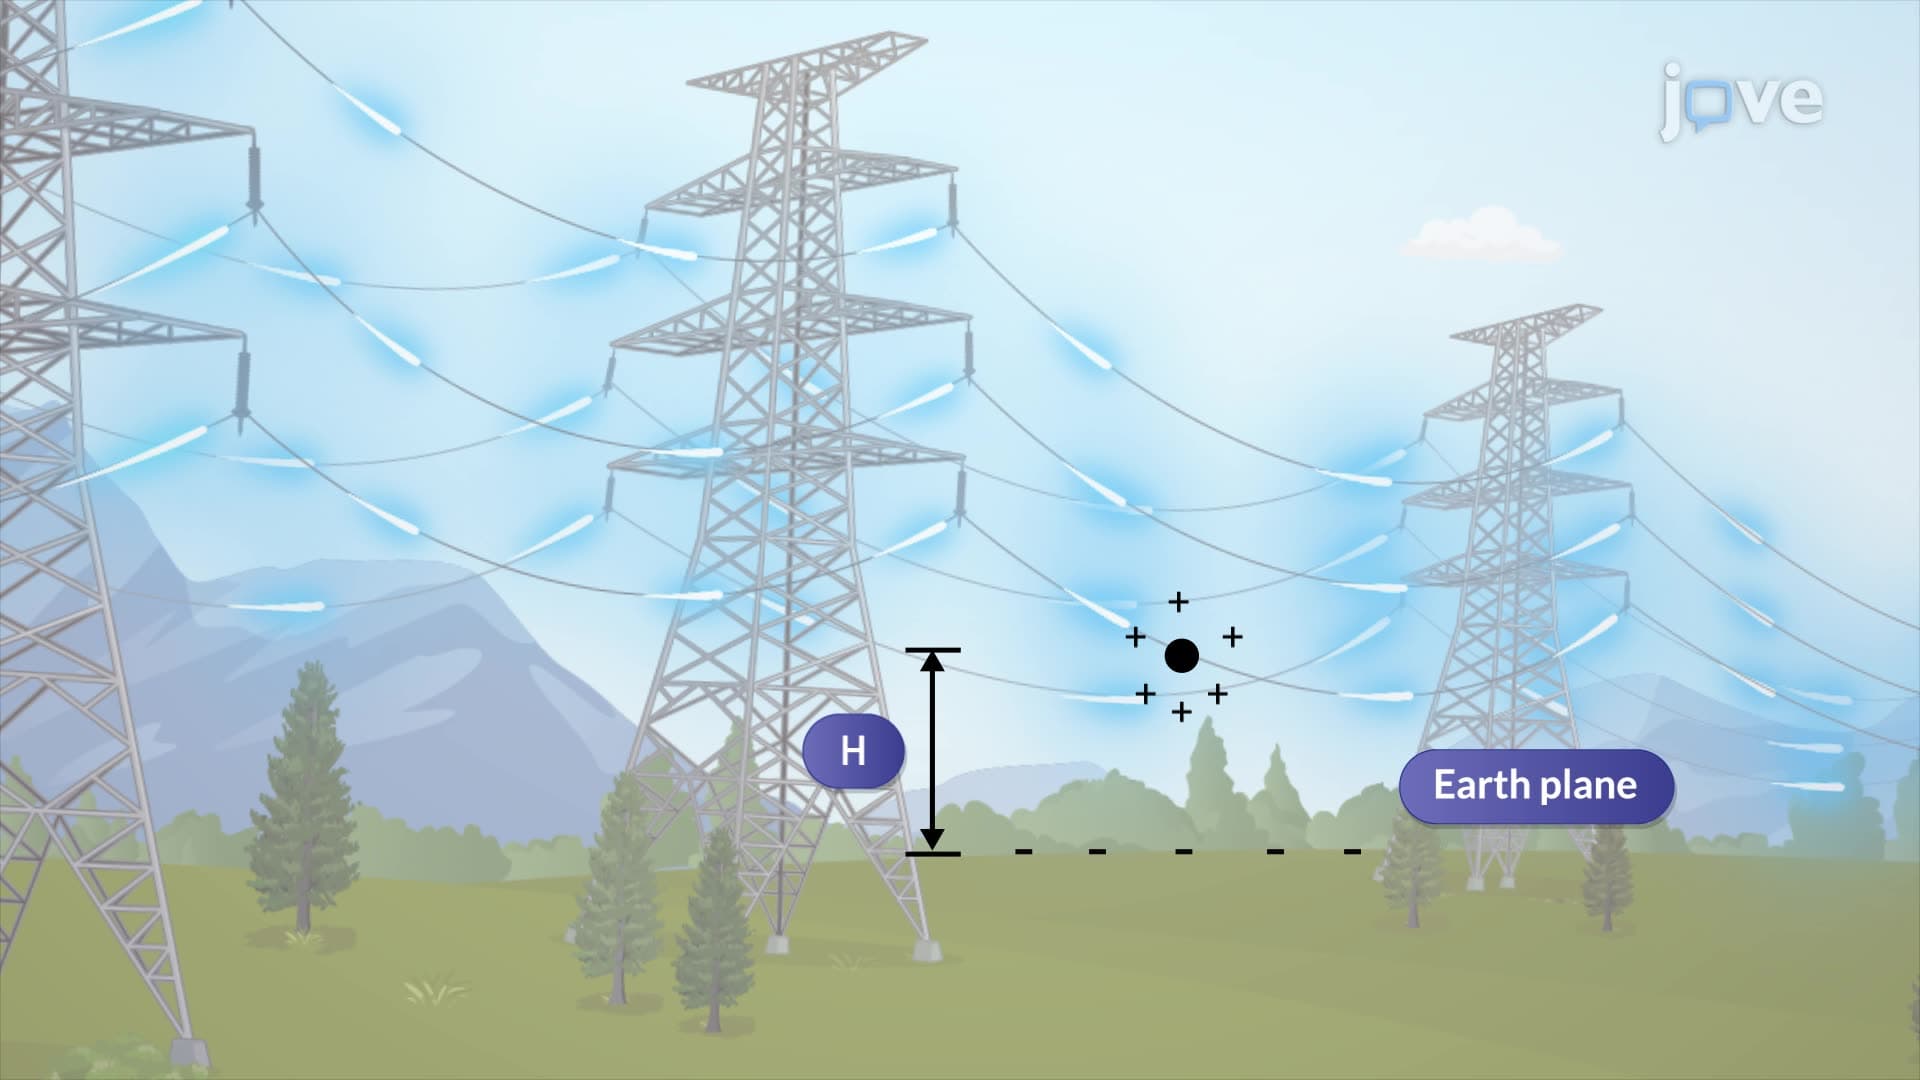
Shunt Admittances
To model this effect, the method of images is employed. This method involves replacing the Earth with an image conductor that mirrors the original...