Related Experiment Video
Updated: Jan 28, 2026
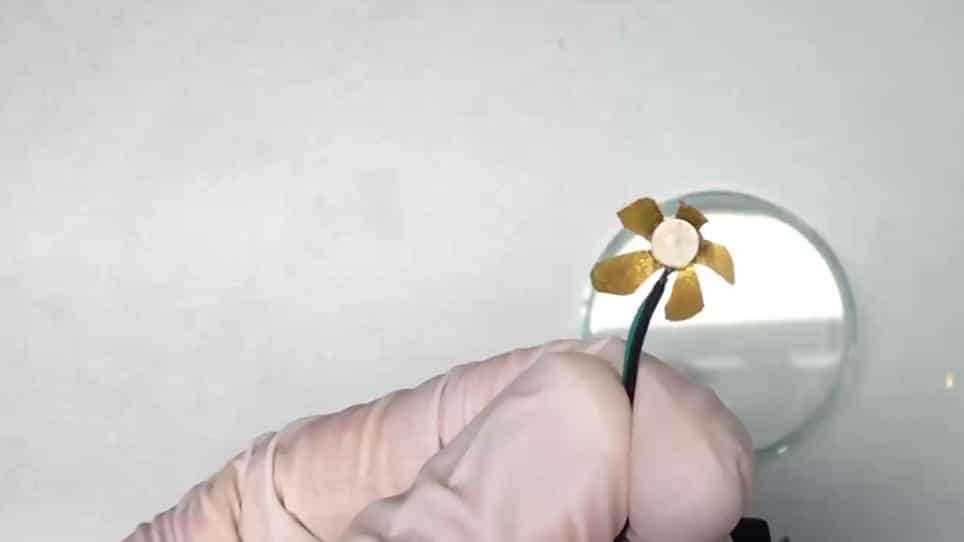
Fabrication of Carbon-Based Ionic Electromechanically Active Soft Actuators
Published on: April 25, 2020
Soft Actuators with Stiffness and Shape Modulation Using 3D-Printed Conductive Polylactic Acid Material
Mohammed Al-Rubaiai1, Thassyo Pinto1, Chunqi Qian2
11 Department of Electrical and Computer Engineering, Michigan State University, East Lansing, Michigan.

Abstract:
The field of soft robotics has seen increasing interest and developments in recent years. Stiffness tuning is a desirable characteristic for soft robots since it enables adaptively modulating the load-bearing capability, shape, and locomotion behavior of the robots. In this article a compact and cost-effective mechanism for stiffness tuning is proposed based on a three-dimensional printed conductive polylactic acid (CPLA) material, and its potential in soft robotics is demonstrated through a soft pneumatic actuator (SPA) capable of stiffness and shape modulation. In particular, the conductive nature of the CPLA material allows convenient control of temperature and stiffness through Joule heating. Mechanical, thermoplastic, and electrical properties of the CPLA are first characterized. The material shows 98.6% reduction of Young's modulus, from 1 GPa at room temperature (25°C) to 13.6 MPa at 80°C, which is fully recovered after the material is cooled down to its initial temperature, and its glass transition temperature is 55°C, at which its Young's modulus is at 60% of that under room temperature. The experimentally identified material parameters are then used in finite-element modeling and simulation to investigate the behavior of a SPA integrated with a CPLA layer. A soft actuator with three virtual joints enabled by CPLA is prototyped, and bending experiments are conducted to both demonstrate the effectiveness of stiffness tuning and shape control and support the efficacy of the finite element model. Finally, a gripper composed of two soft actuators as fingers is fabricated to demonstrate localized gripping posture and the ability to carry load in a desired locked posture even when the pressure input is turned off, after the CPLA is cooled down.
Related Concept Videos
 03:37
Molecular Shape and Polarity
 01:18
Molecular Shapes
Two regions of electron density in a diatomic...
 02:52
VSEPR Theory and the Basic Shapes
 01:28
Conduct Disorder
 01:19
Conduction System of the Heart
The pacemaker cells are located in two primary nodes: the sinoatrial (SA) node and the atrioventricular (AV) node. The SA node pacemaker cells can autonomously depolarize, triggering an action potential that leads to the...
 01:20
Conduction System of the Heart
This system relies on the unique properties of nodal and Purkinje cells:...